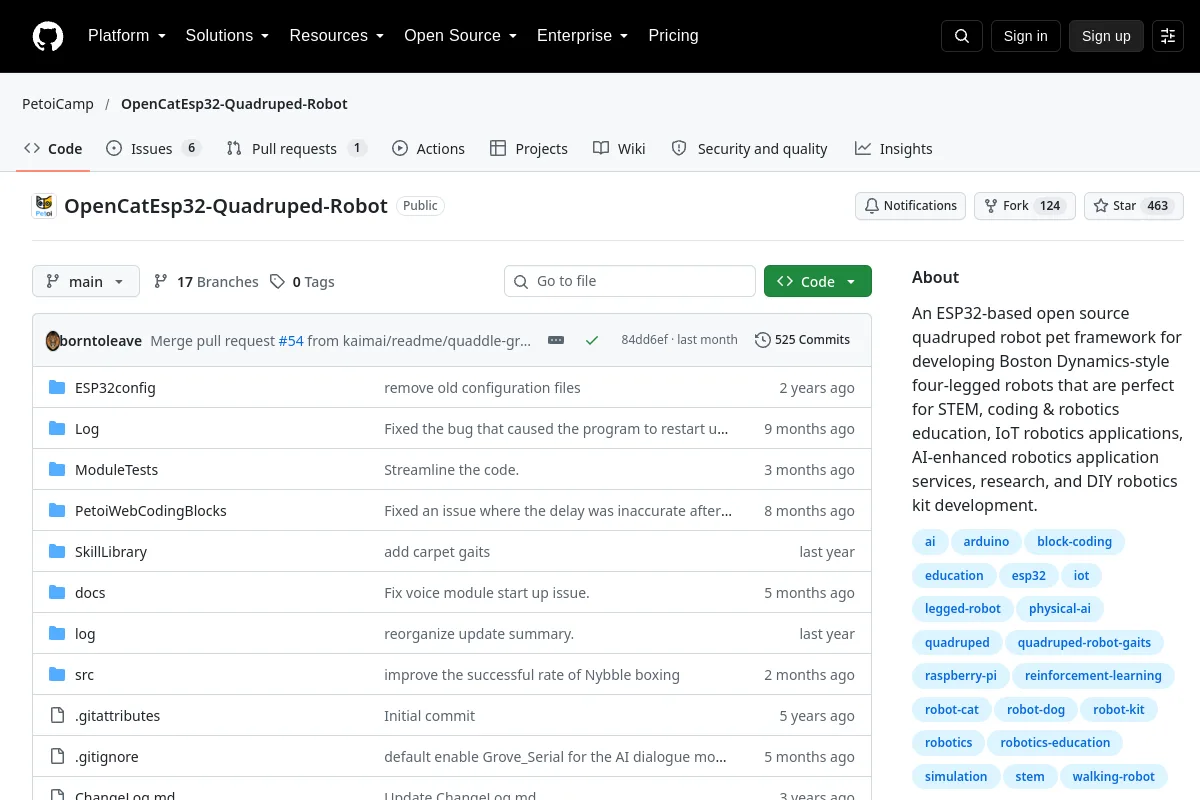
An ESP32-based open source quadruped robot pet framework for developing Boston Dynamics-style four-legged robots that are perfect for STEM, coding & robotics education, IoT robotics applications…
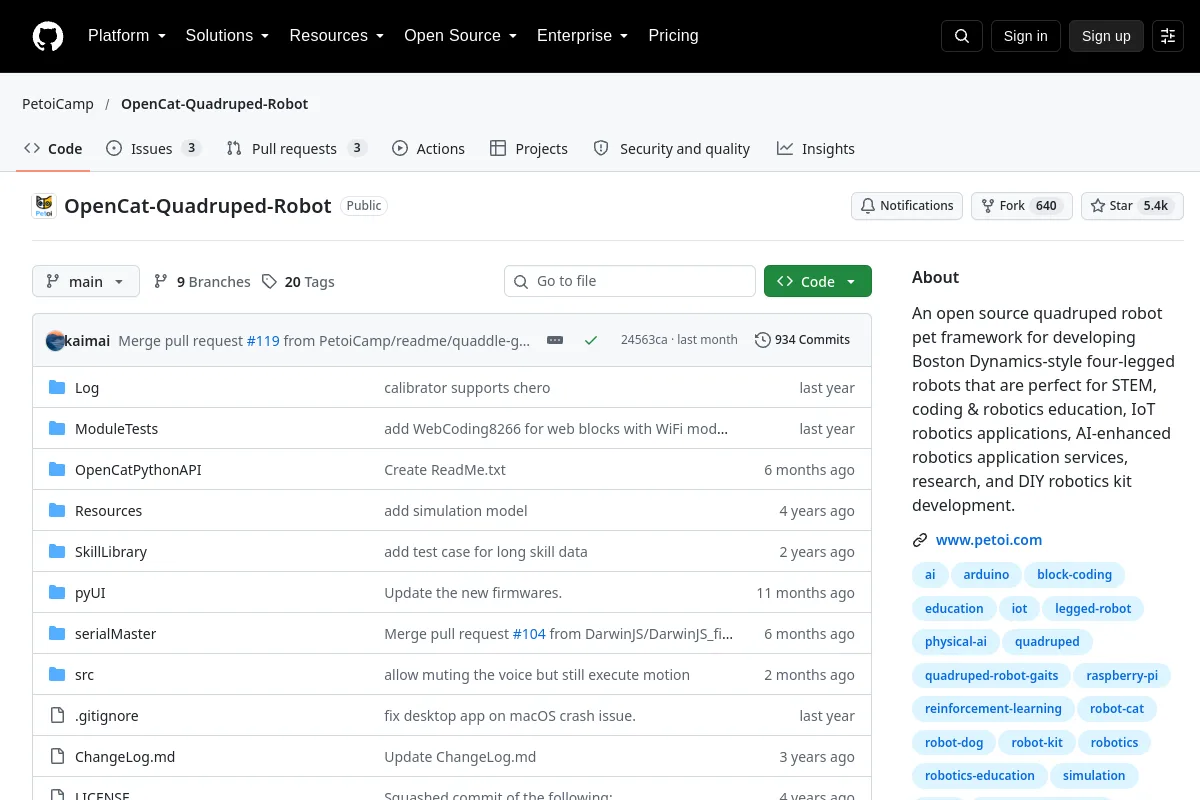
An ESP32-based open source quadruped robot pet framework for developing Boston Dynamics-style four-legged robots that are perfect for STEM, coding & robotics education, IoT robotics applications…
Publisher purpose: An ESP32-based open source quadruped robot pet framework for developing Boston Dynamics-style four-legged robots that are perfect for STEM, coding & robotics education, IoT robotics applications, AI-enhanced robotics application services, research, and DIY robotics kit development.
Inspect design files, bill of materials, assembly instructions and electrical/mechanical interfaces. Availability, price and compatibility must be confirmed for the specific build.
Project information
Maintainer
PetoiCamp
Primary language
C++
Repository code license
MIT
Model-weight license
Not recorded
Dataset license
Not recorded
Hardware design license
Not recorded
Maintenance
Not archived in the last recorded metadata
Last observed repository push
2026-09-08
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
OpenCatESP32 — OpenCat Framework on ESP32/BiBoard
Quaddle mini robot dog — launching on Kickstarter Sept 2, 2026
An open source quadruped robot pet framework for developing Boston Dynamics-style four-legged robots that are perfect for STEM, coding & robotics education, IoT robotics applications, AI-enhanced…
 Repository
 Open source