 Repository
 Open source
gym gazebo2 · AcutronicRobotics
An archived toolkit for RL experiments with ROS 2 and Gazebo.
Simulation & physicsTHE EMBODIED AI DIRECTORY
Explore physics engines and simulation platforms for developing and testing robotic systems.
Repository
Open source
An archived toolkit for RL experiments with ROS 2 and Gazebo.
Simulation & physics Repository
 Open source
Framework for developing OpenAI Gym robotics environments simulated with Ignition Gazebo
Simulation & physics Repository
 Open source
Reproducible reinforcement-learning experiments in Gazebo.
Simulation & physics Repository
 Open source
URDF models of humans created to perform human robot interaction experiments.
Simulation & physics Repository
 Open source
A human-vehicle simulation platform for autonomous-system and interaction experiments.
Simulation & physics Repository
 Open source
Integration of Motoman CSDA10f dual arm robot with ROS, Moveit and Gazebo, with aims of creating a robotics developing platform for Invite GmbH, pre-configured to be simple to use and learn.
Simulation & physics Repository
 Open source
An independent extension based on IsaacLab. It provides support for Robot Manipulation tasks (Robot Arm and Dextrous Hand).
Simulation & physics Repository
 Open source
A differentiable physics engine and multibody dynamics library for control and robot learning.
Simulation & physics Repository
 Open source
Python/C++ articulated-robot simulator with Gym interfaces for reinforcement learning.
Simulation & physics Repository
 Open source
C++ rigid-body physics and collision detection library.
Simulation & physics Repository
 Open source
Codebase for Kinova Gen3 training in Isaac Lab, sim2real transfer and ROS deployment.
Simulation & physics Repository
 Open source
RL training library for humanoid locomotion and manipulation. Built on top of MuJoCo and JAX.
Simulation & physics Repository
 Open source
A Genesis–LeRobot bridge for running, recording and evaluating robot policies.
Simulation & physics Repository
 Open source
Perceptive Learning for Legged Robots in IsaacLab. | LocoTouch: Learning Dynamic Quadrupedal Transport with Tactile Sensing (CoRL'25)
Simulation & physics Repository
 Open source
Python SDK for LuckyEngine robotics simulation
Simulation & physics Repository
 Open source
LLM-first, 3D-native robotics and simulation workspace.
Simulation & physics Repository
 Open source
Base Mujoco Gymnasium environment for easily controlling any robot arm with operational space control. Built with dm-control PyMJCF for easy configuration.
Simulation & physics Repository
 Open source
Elevating FRC Java Robot Simulations to the Next Level with Physics Engines
Simulation & physics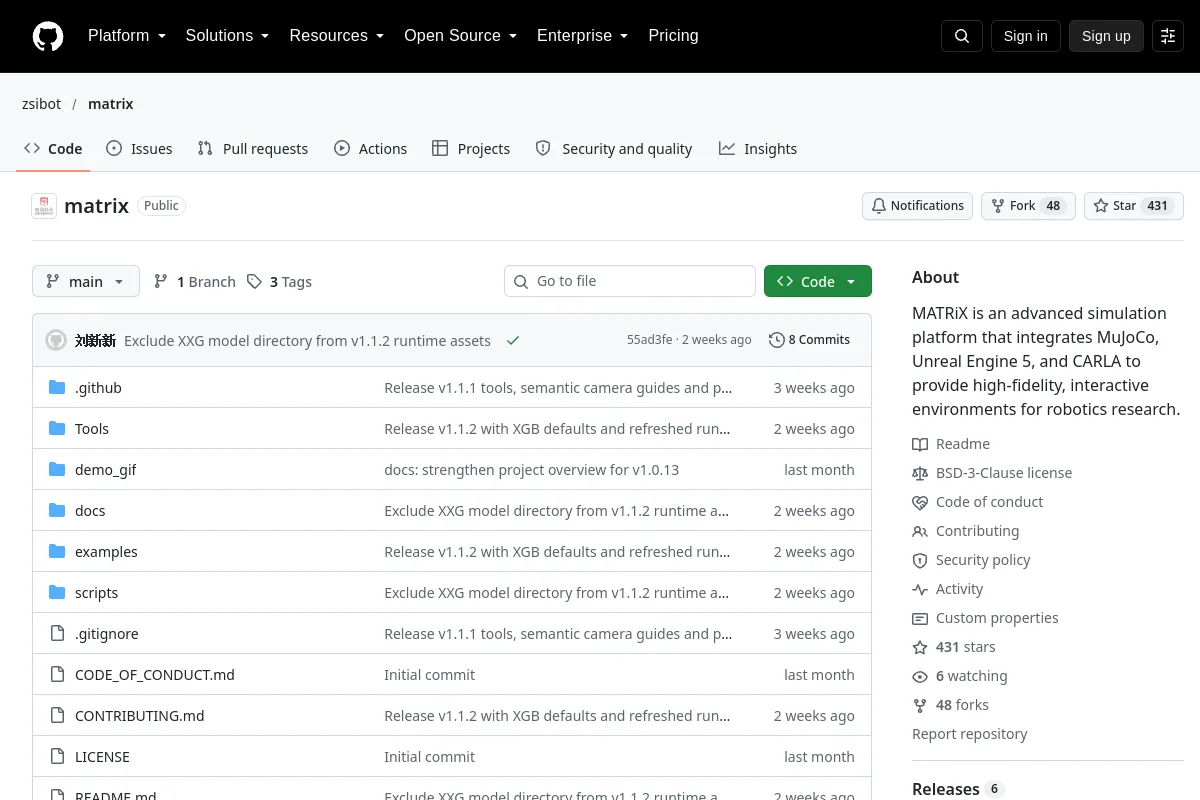 Repository
 Open source
MATRiX is an advanced simulation platform that integrates MuJoCo, Unreal Engine 5, and CARLA to provide high-fidelity, interactive environments for robotics research.
Simulation & physics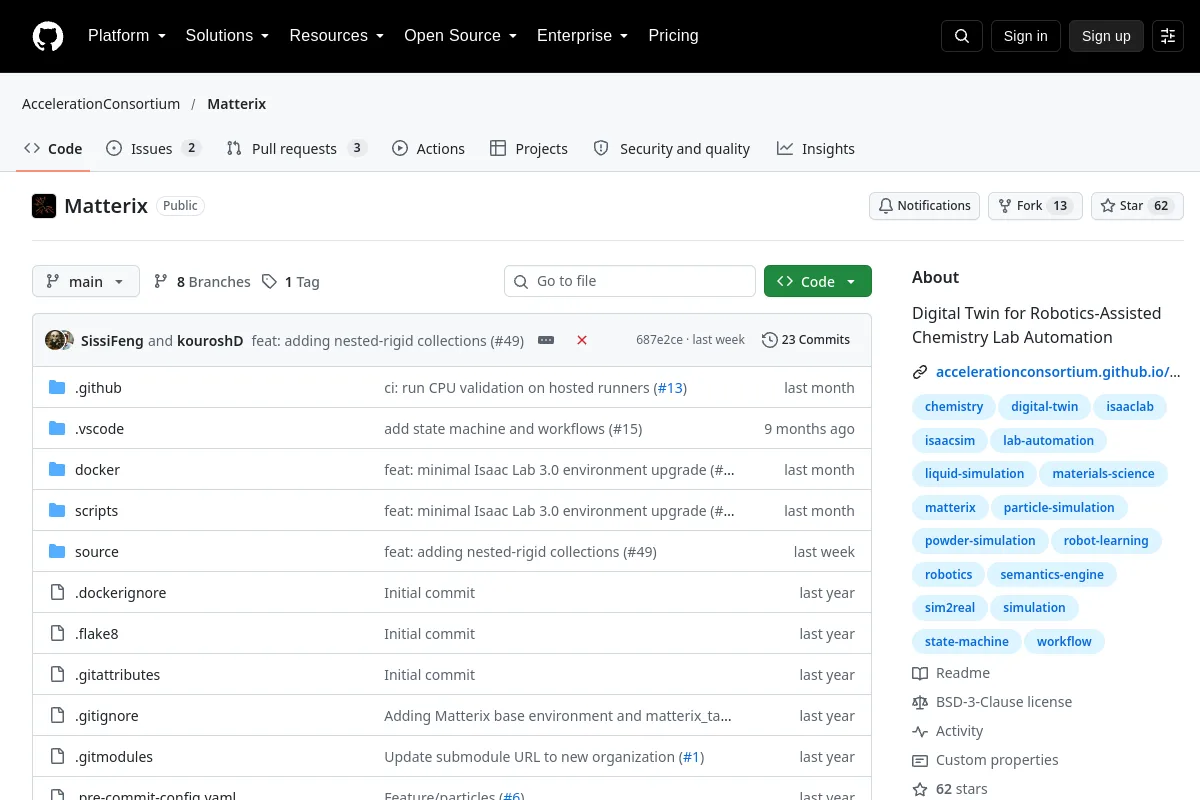 Repository
 Open source
A digital twin for robotics-assisted chemistry laboratory automation.
Simulation & physics Repository
 Open source
Driving simulator for autonomous-driving research and multi-agent experiments.
Simulation & physics Repository
 Repository
 Open source
ROS packages and Arduino scripts that can be used to control the BCN3D Moveo robotic arm in simulation and real-life.
Simulation & physics Repository
 Open source
ROS2 control package for Mujoco simulation physics simulator, including plugins for various sensors, RGB-D cameras, and lidar.
Simulation & physicsSELECTION NOTES
Choose around contact fidelity, sensor rendering, robot assets and compute requirements. Confirm supported versions and licenses before comparing simulation speed or transferring policies to hardware.
Know a resource that belongs here?