 Repository
THE EMBODIED AI DIRECTORY
Middleware & communication
Explore messaging and dataflow infrastructure for distributed robotic systems.
Repository
 Repository
 Open source
robot-control-stack · RobotControlStack
A lean, ROS-free sim-to-real framework for training and deploying Vision-Language-Action (VLA) models and RL agents. Native MuJoCo Gymnasium wrappers with synchronous execution for Franka, UR5e…
Middleware & communication Repository
 Research
robot-harness · xiao-yang25
A harness for embodied intelligence — connecting agents, robot skills and the physical world through execution, feedback and recovery.
Middleware & communication Repository
 Open source
ros2-for-unity · RobotecAI
High-performance ROS2 solution for Unity3D
Middleware & communication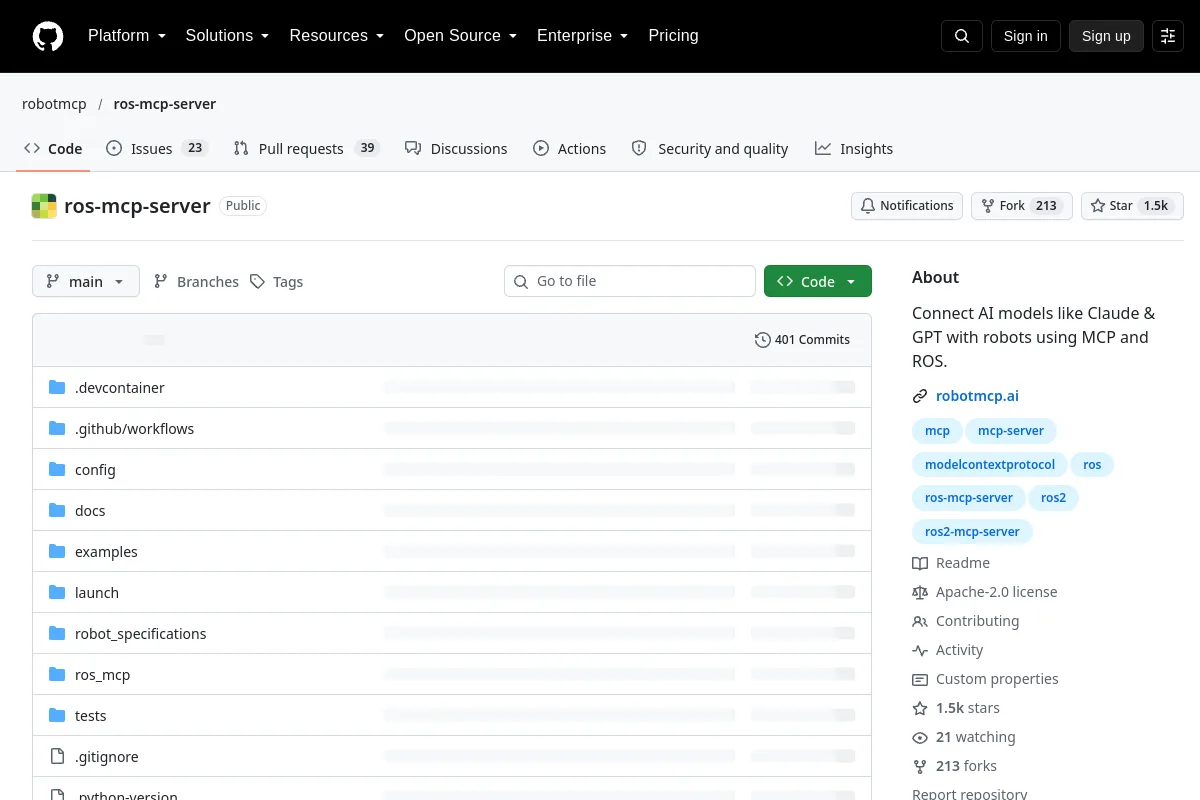 Repository
 Open source
ros-mcp-server · robotmcp
Connect AI models like Claude & GPT with robots using MCP and ROS.
Middleware & communication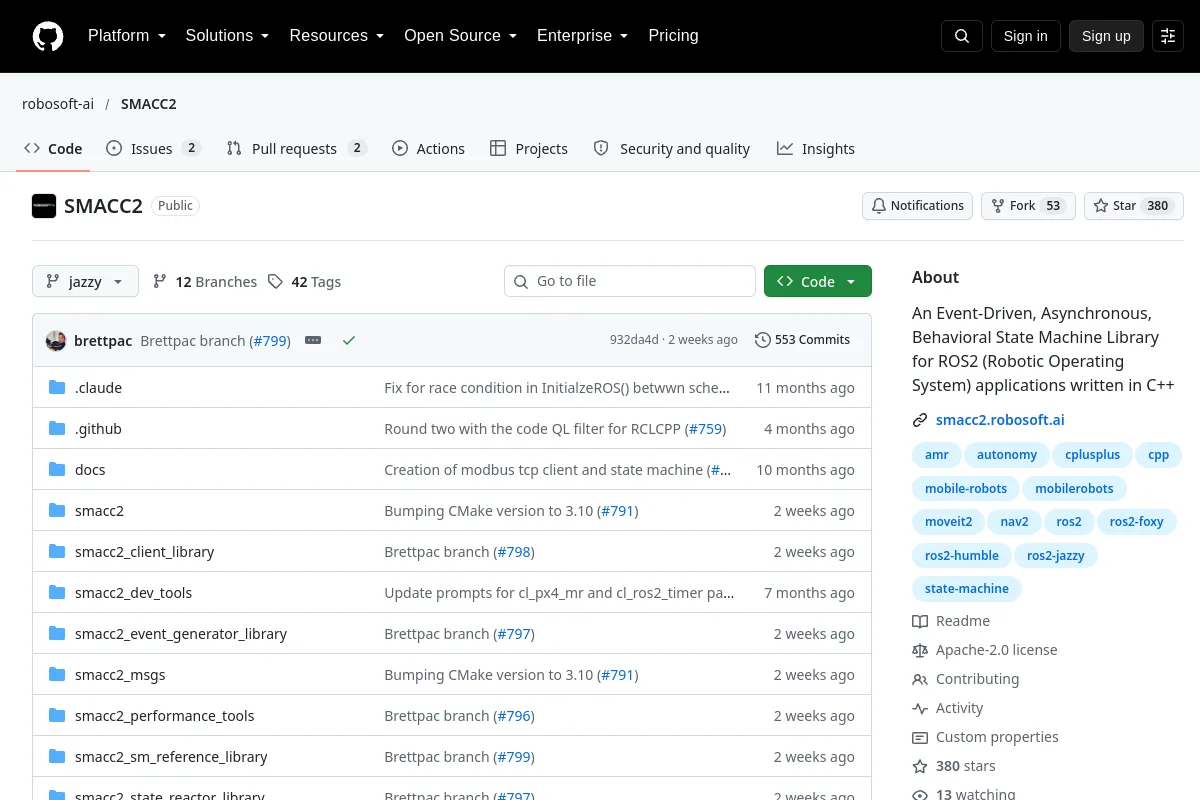 Repository
 Open source
SMACC2 · robosoft-ai
An Event-Driven, Asynchronous, Behavioral State Machine Library for ROS2 (Robotic Operating System) applications written in C++
Middleware & communication Repository
 Open source
UltraBot · LeapLabTHU
Towards Expert-level Autonomous Carotid Ultrasonography with Large-scale Learning-based Robotic System
Middleware & communication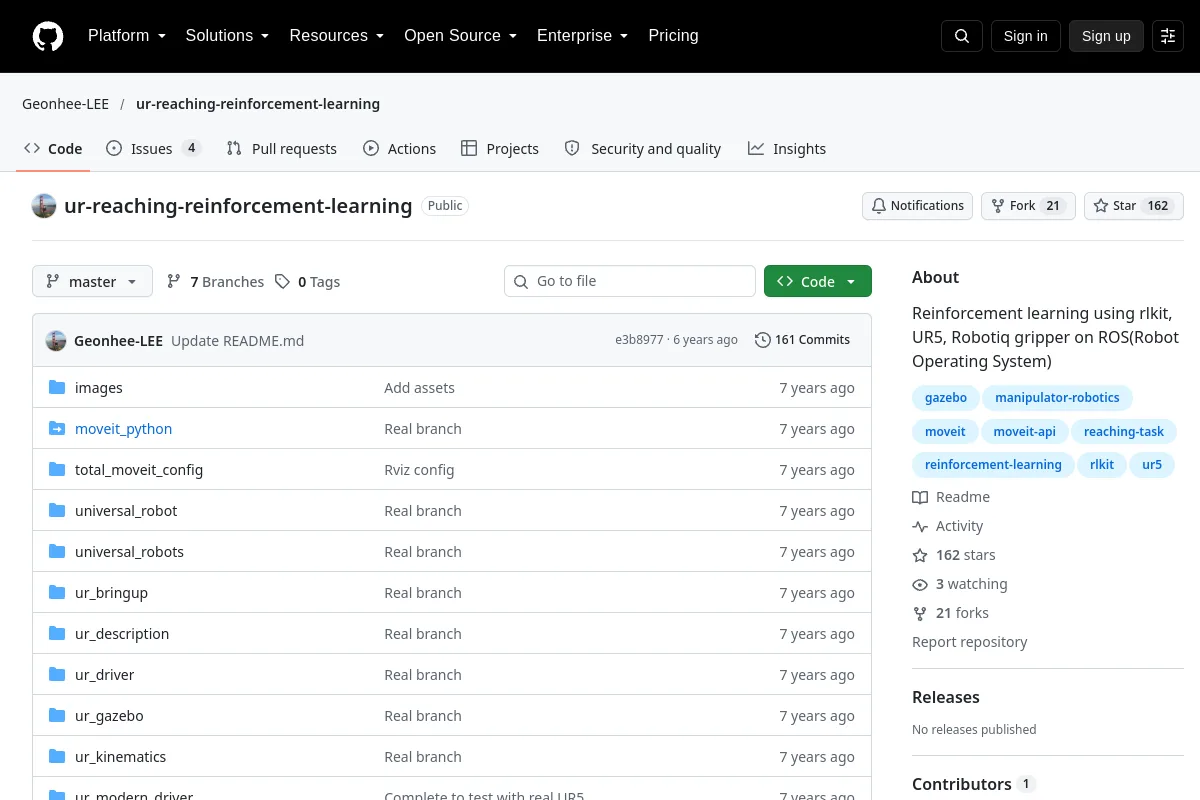 Repository
 Research
ur-reaching-reinforcement-learning · Geonhee-LEE
Reinforcement learning using rlkit, UR5, Robotiq gripper on ROS(Robot Operating System)
Middleware & communication Repository
 Open source
vlink · thun-res
VLink is a high-performance C++ communication middleware for autonomous driving and embodied intelligence, positioned as a full-scenario alternative to ROS 2.
Middleware & communication Repository
 Research
wrapyfi · modular-ml
Robotics MOM and RPC middleware wrapper with deep-learning framework integration
Middleware & communication Repository
 Research
yarp · robotology
Middleware and tools for distributed robot systems.
Middleware & communication Repository
 Open source
Dora
A dataflow runtime for robotic perception and control pipelines.
Middleware & communication Website

SELECTION NOTES
Choosing middleware & communication
Compare delivery semantics, timing, transport security and integration requirements. Verify compatibility with the selected ROS distribution or runtime instead of assuming drop-in replacement.
A PLACE FOR YOUR NEXT DISCOVERY
Suggest a resource ↗The ecosystem keeps growing.
Know a resource that belongs here?