 Repository
 Research
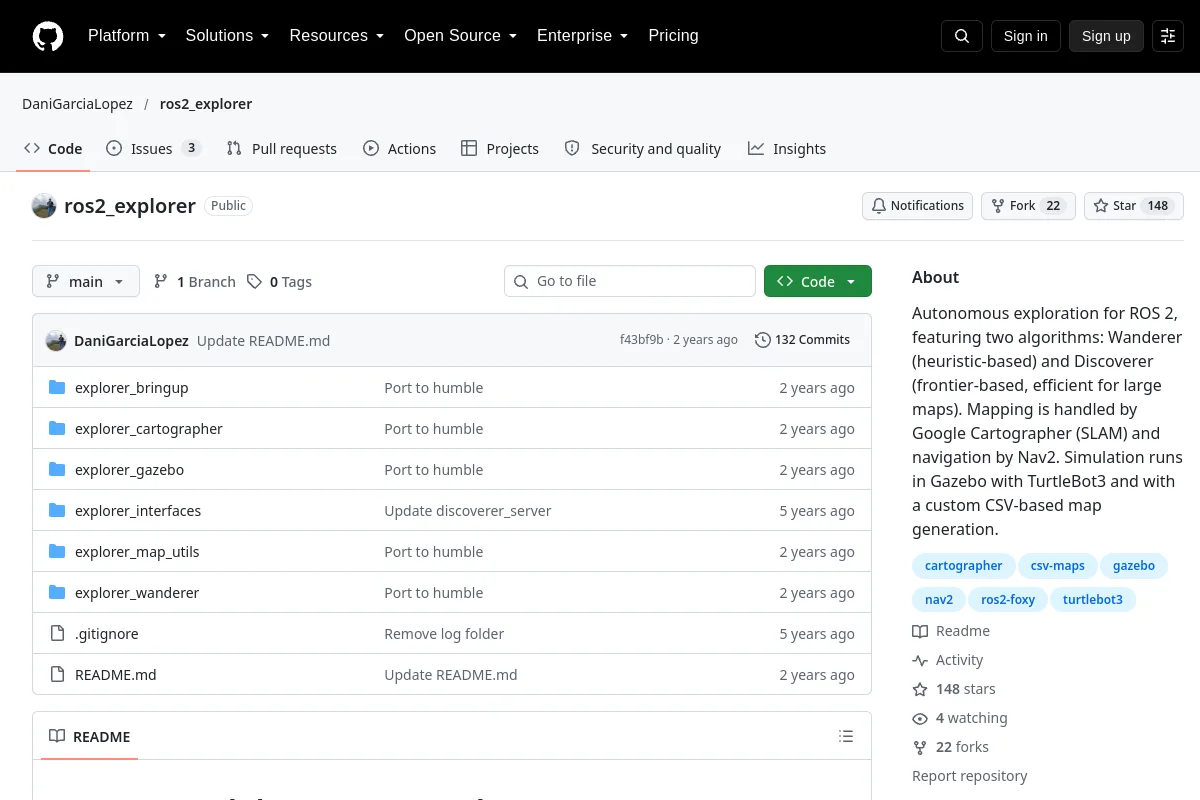
ros2_explorer · DaniGarciaLopez
Autonomous exploration for ROS 2, featuring two algorithms: Wanderer (heuristic-based) and Discoverer (frontier-based, efficient for large maps). Mapping is handled by Google Cartographer (SLAM)…
Navigation & SLAM