 Repository
 Open source
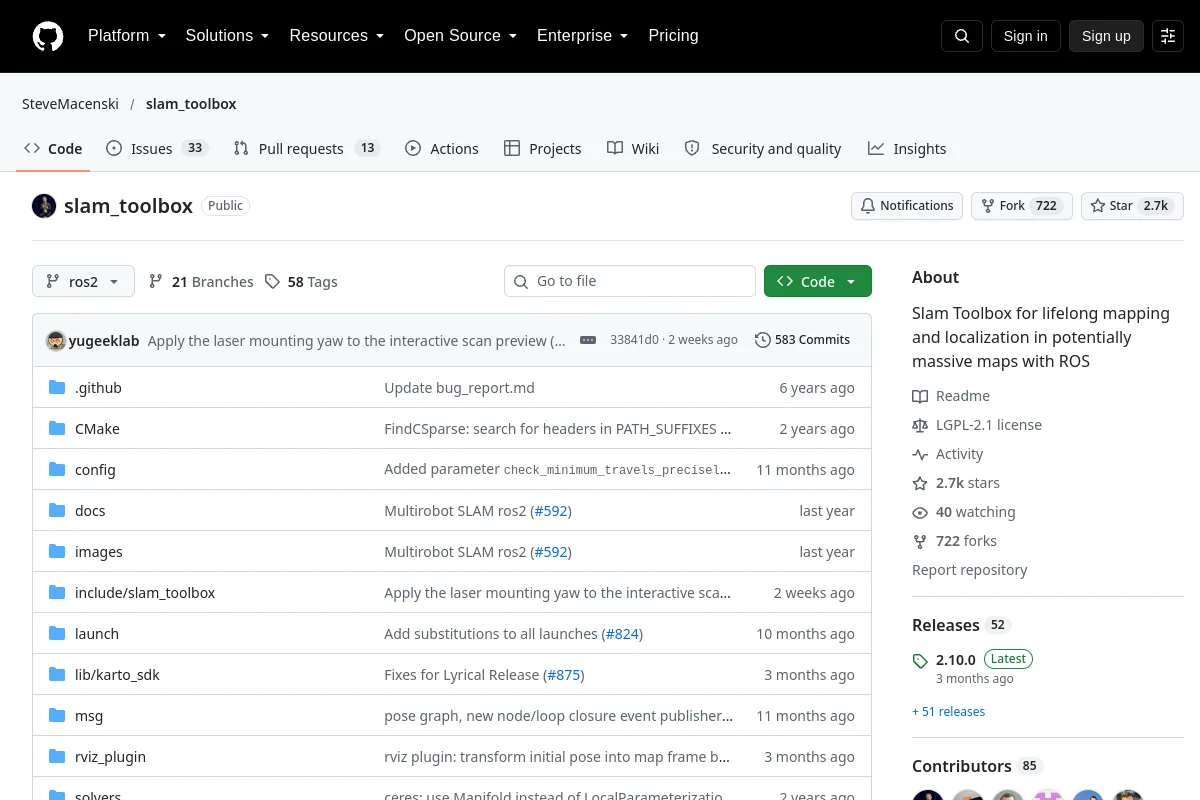
slam_toolbox
Mapping and localization tools for ROS 2 navigation workflows.
Navigation & SLAMTHE EMBODIED AI DIRECTORY
Find ROS 2 navigation and planning resources for autonomous robots.
Repository
Open source
Mapping and localization tools for ROS 2 navigation workflows.
Navigation & SLAM Repository
 Open source
Deep Reinforcement Learning for mobile robot navigation in ROS2 Gazebo simulator. Using DRL (SAC, TD3) neural networks, a robot learns to navigate to a random goal point in a simulated environment…
Navigation & SLAM Repository
 Open source
Edge deployment guide for InternNav-based perception and navigation on Unitree Go2 / Go2W / B2 robots (ROS 2, RealSense, Python).
Navigation & SLAM Repository
 Open source
KISS-Matcher: Fast, Robust, and Scalable Registration + ROS2 SLAM examples
Navigation & SLAM Repository
 Open source
ROS 2 packages for connecting robots and controllers to Webots.
Navigation & SLAM Repository
 Open source
A sensor-equipped mobile-robot model for multiple simulation platforms.
Navigation & SLAM Repository
 Open source
C++ Monte Carlo localization library with ROS packages.
Navigation & SLAM Repository
 Repository
 Open source
ROS 2 localization for outdoor robots: IMU, wheel encoders and GPS fused in a 23-state UKF at 100 Hz. When the estimate goes wrong it reports which sensor and why, instead of drifting silently.…
Navigation & SLAM Repository
 Open source
ROS 2 implementation of a Teleoperated robot with live video feed using webrtc and SLAM using realsense's stereocameras. Running on a Jetson Nano
Navigation & SLAM Repository
 Open source
A differential drive robot is controlled using ROS2 Jazzy running on a Raspberry Pi 4 (running Ubuntu Server 24.04). The vehicle is equipped with a Raspberry Pi camera for visual feedback and an…
Navigation & SLAM Repository
 Open source
3D LIDAR Localization using pointcloud map in ROS 2 (Not SLAM)
Navigation & SLAM Repository
 Open source
A ROS 2 navigation workspace combining LiDAR-inertial odometry, relocalization and Nav2.
Navigation & SLAM Repository
 Open source
ROS 2 package of tightly-coupled lidar inertial ndt/gicp slam
Navigation & SLAM Repository
 Open source
ROS 2 nodes wrapping core MRPT functionality: localization, autonomous navigation, rawlogs, etc. SLAM is in other packages.
Navigation & SLAM Repository
 Open source
MCP server that provides tools and resources to control and monitor robots using Nav2.
Navigation & SLAM Repository
 Open source
ROS 2 Jazzy software for the OpenAMRobot mobile base: simulation, Nav2, SLAM, docking, control, drivers, and bringup.
Navigation & SLAM Repository
 Open source
Agent skill for production-grade ROS 2 development. Progressive-disclosure SKILL.md covering workspace, nodes, executors, QoS, ros2_control, Nav2, MoveIt 2, real-time, and deployment. Works with…
Navigation & SLAM Repository
 Open source
A ROS2 Humble package that natively implementing ORB-SLAM3 V1.0 VSLAM framework
Navigation & SLAM Repository
 Open source
ROS2 node for DJI Tello and Visual SLAM for mapping of indoor environments.
Navigation & SLAM Repository
 Open source
Mapping, localization and using the navigation stack with ROS2 Jazzy
Navigation & SLAM Website
 Website
 Website
SELECTION NOTES
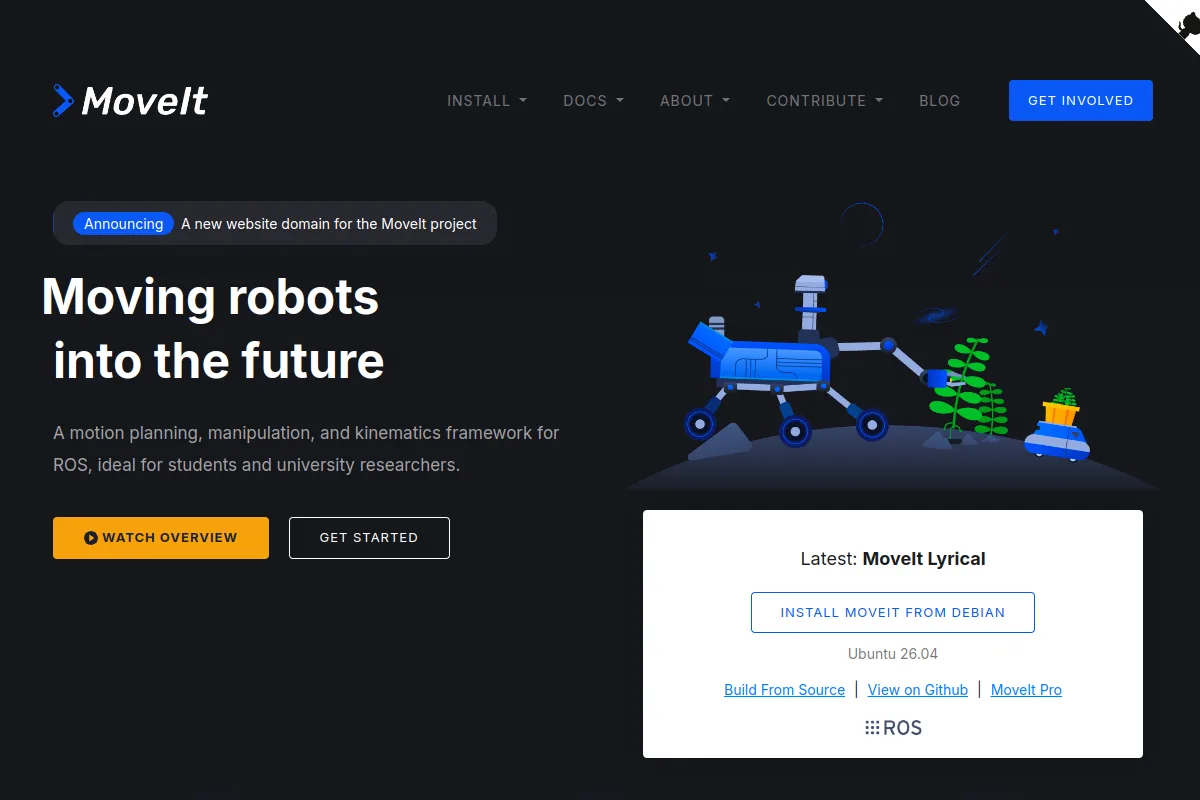
Start with compatible ROS 2 distributions, robot transforms, localization, sensors and motor drivers. Nav2 addresses mobile navigation; MoveIt addresses manipulation planning. Confirm distribution and driver compatibility in the official documentation.
Know a resource that belongs here?