 Repository
 Research
turtlebot3 drlnav · tomasvr
Unmaintained ROS 2 framework for TurtleBot3 navigation with deep reinforcement learning.
Navigation & SLAMTHE EMBODIED AI DIRECTORY
Find ROS 2 navigation and planning resources for autonomous robots.
Repository
Research
Unmaintained ROS 2 framework for TurtleBot3 navigation with deep reinforcement learning.
Navigation & SLAM Repository
 Research
ROS 2 framework for autonomous robot navigation.
Navigation & SLAM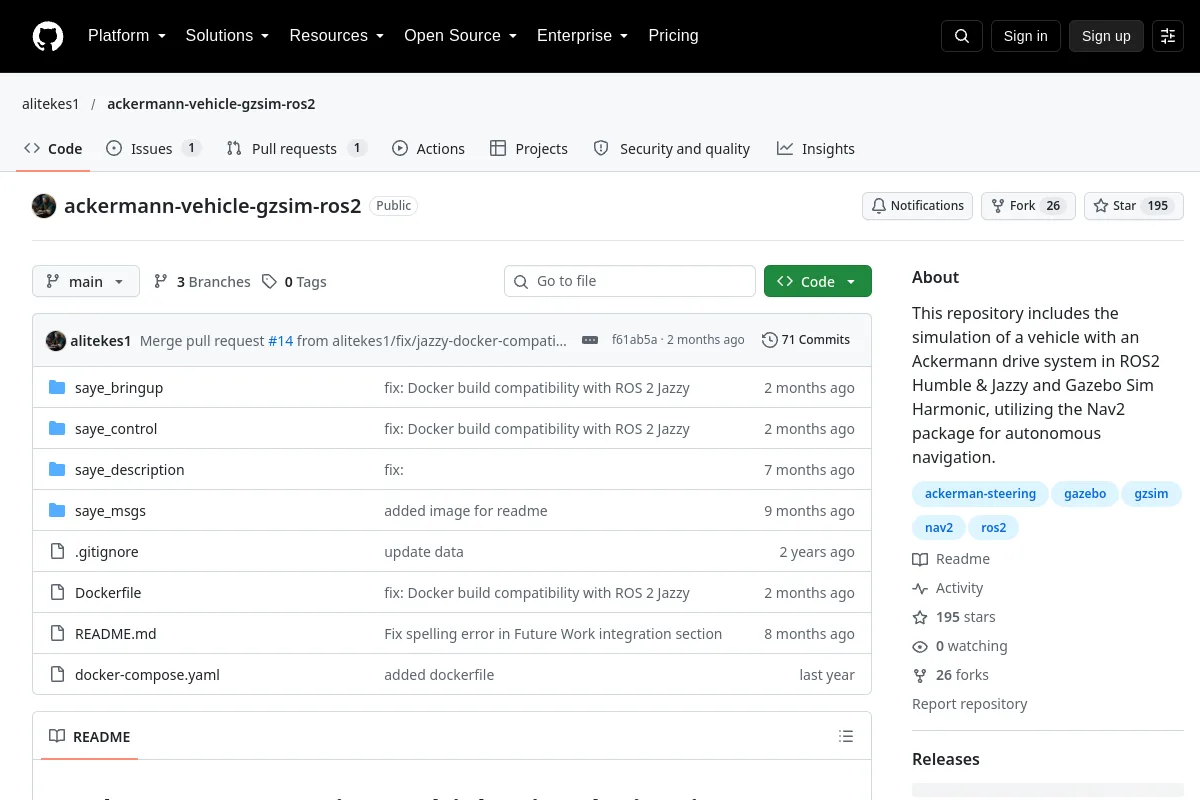 Repository
 Research
This repository includes the simulation of a vehicle with an Ackermann drive system in ROS2 Humble & Jazzy and Gazebo Sim Harmonic, utilizing the Nav2 package for autonomous navigation.
Navigation & SLAM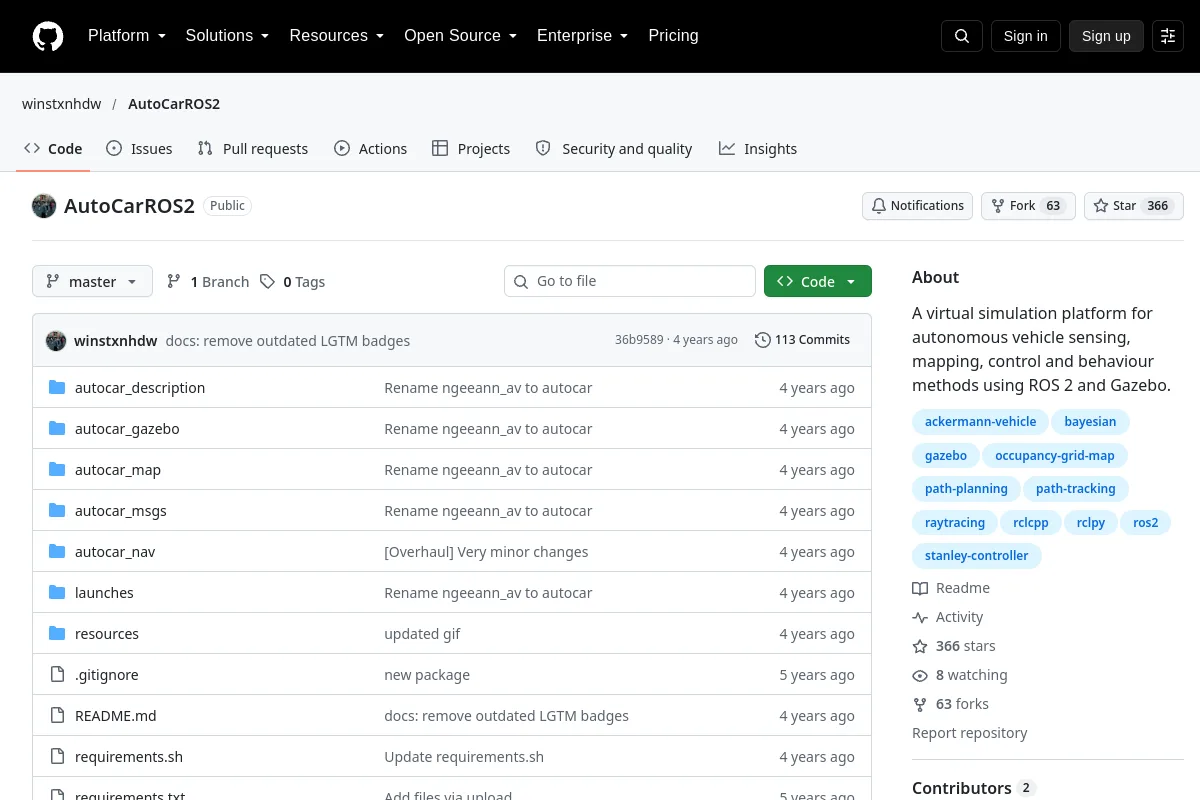 Repository
 Research
A virtual simulation platform for autonomous vehicle sensing, mapping, control and behaviour methods using ROS 2 and Gazebo.
Navigation & SLAM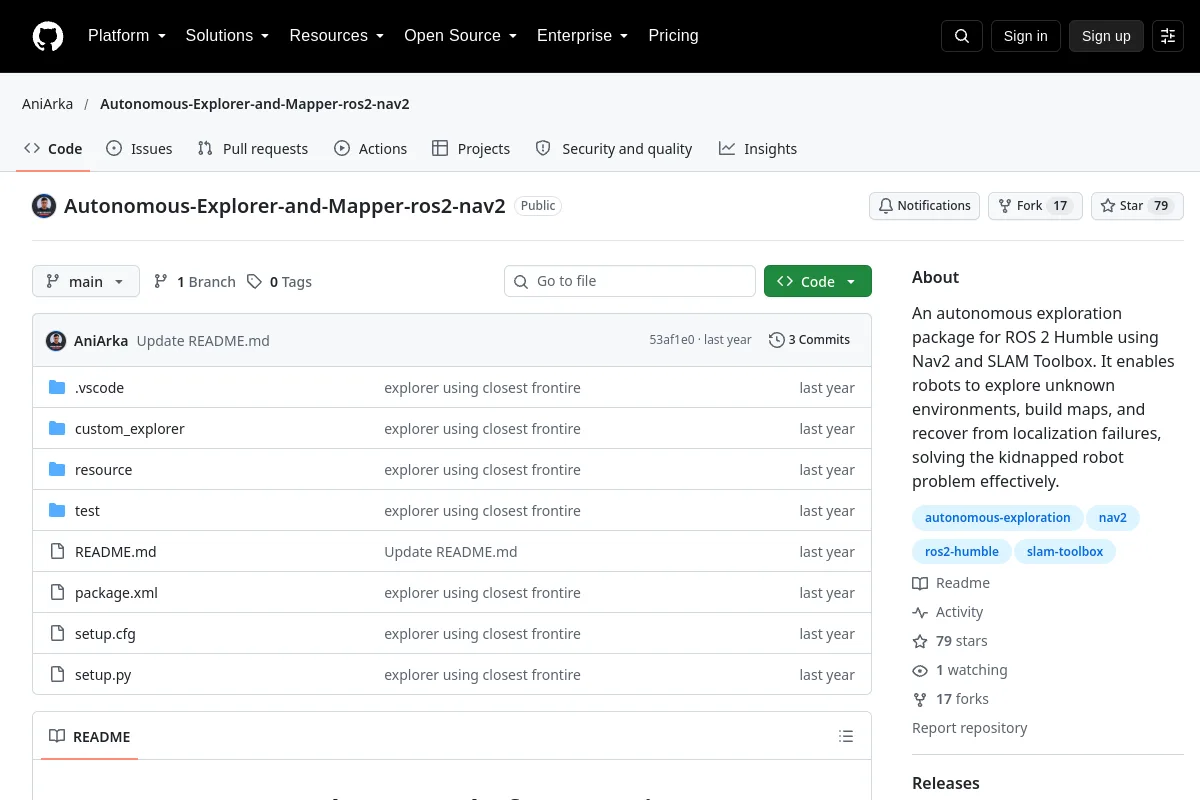 Repository
 Research
An autonomous exploration package for ROS 2 Humble using Nav2 and SLAM Toolbox. It enables robots to explore unknown environments, build maps, and recover from localization failures, solving the…
Navigation & SLAM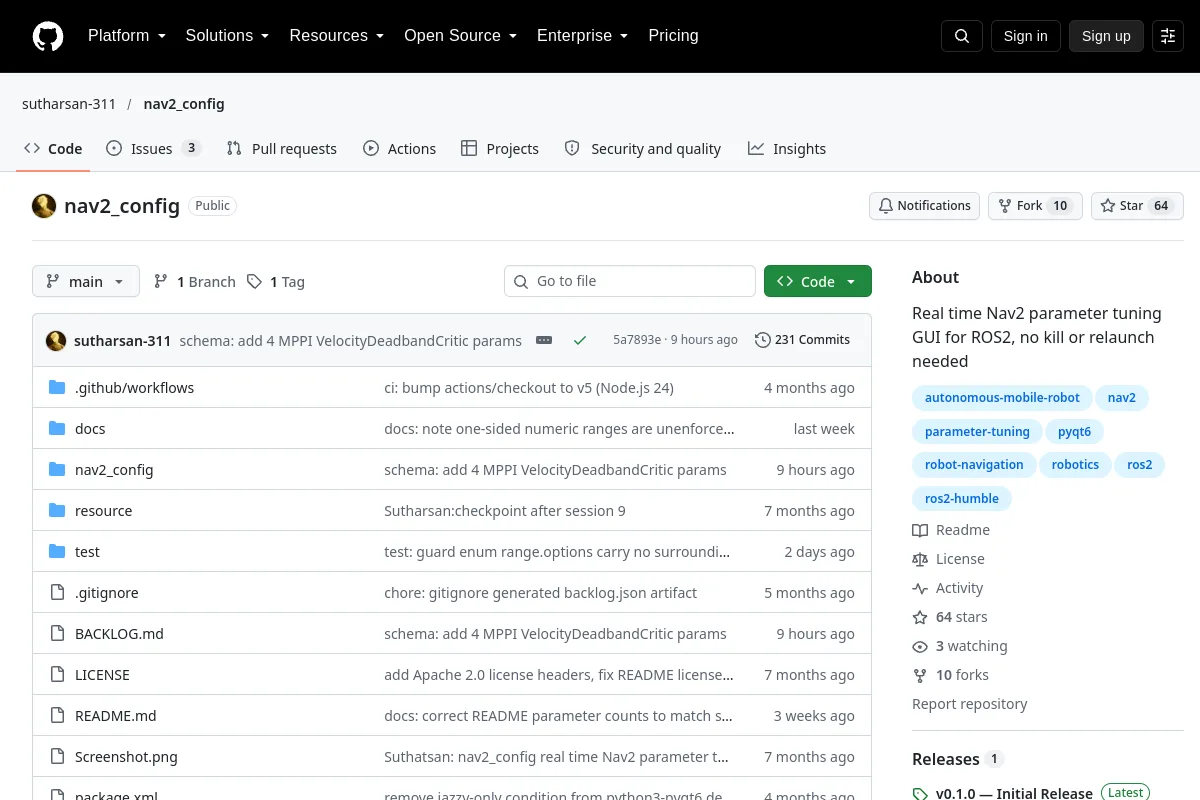 Repository
 Research
Real time Nav2 parameter tuning GUI for ROS2, no kill or relaunch needed
Navigation & SLAM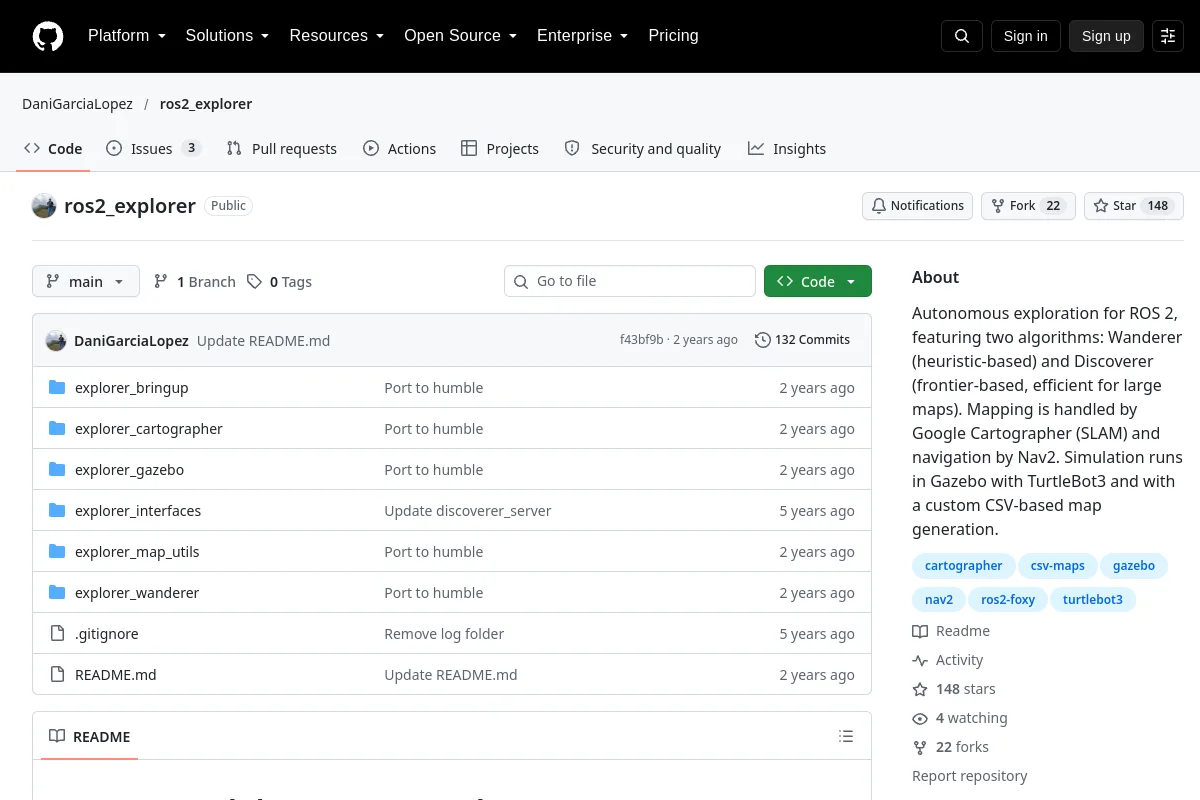 Repository
 Research
Autonomous exploration for ROS 2, featuring two algorithms: Wanderer (heuristic-based) and Discoverer (frontier-based, efficient for large maps). Mapping is handled by Google Cartographer (SLAM)…
Navigation & SLAM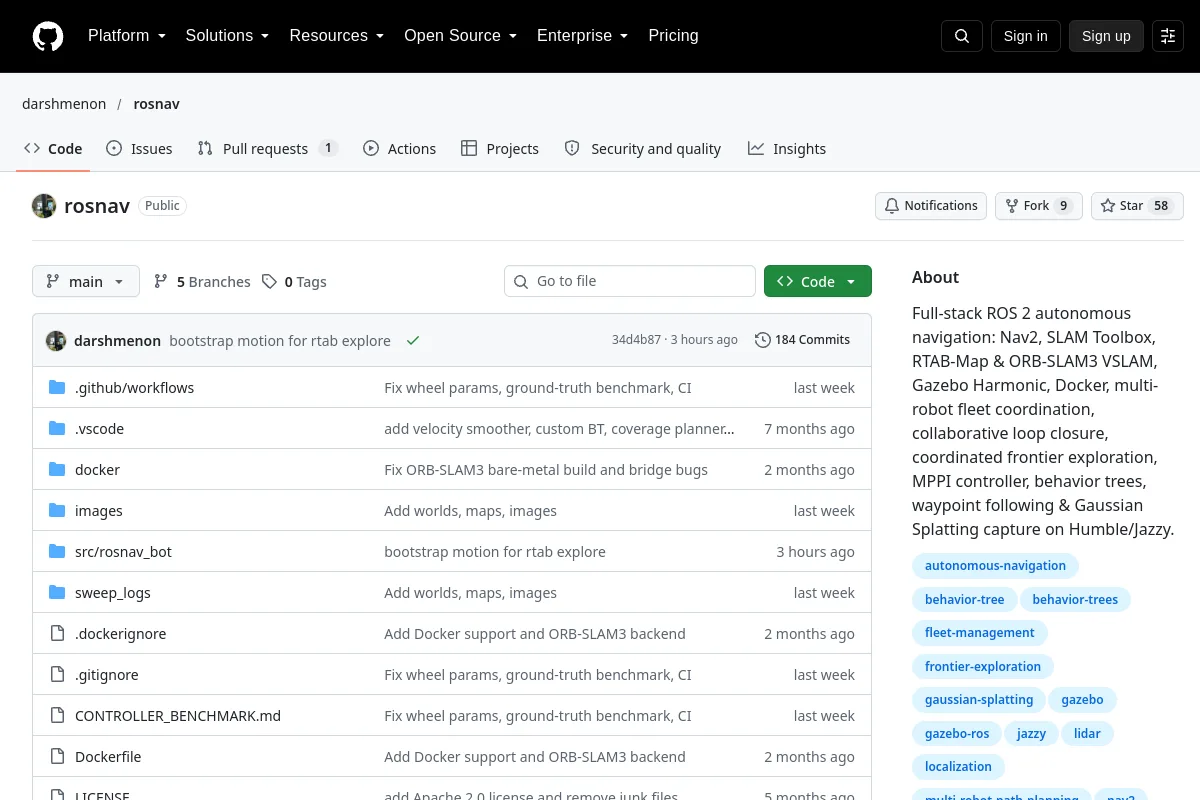 Repository
 Research
Full-stack ROS 2 autonomous navigation: Nav2, SLAM Toolbox, RTAB-Map & ORB-SLAM3 VSLAM, Gazebo Harmonic, Docker, multi-robot fleet coordination, collaborative loop closure, coordinated frontier…
Navigation & SLAM Repository
SELECTION NOTES
Start with compatible ROS 2 distributions, robot transforms, localization, sensors and motor drivers. Nav2 addresses mobile navigation; MoveIt addresses manipulation planning. Confirm distribution and driver compatibility in the official documentation.
Know a resource that belongs here?