 Repository
 Open source
minisam · dongjing3309
Factor-graph framework for nonlinear least-squares optimization.
Navigation & SLAMTHE EMBODIED AI DIRECTORY
Explore mapping, localization, odometry and navigation software for autonomous robots.
Repository
Open source
Factor-graph framework for nonlinear least-squares optimization.
Navigation & SLAM Repository
 Open source
Robot path planning, mapping and exploration algorithms
Navigation & SLAM Repository
 Open source
ROS 2 nodes wrapping core MRPT functionality: localization, autonomous navigation, rawlogs, etc. SLAM is in other packages.
Navigation & SLAM Repository
 Open source
A modularized multi-robot SLAM system with elevation mapping and a costmap converter for easy navigation. Different odometry and loop closure algorithms can be easily integrated into the system.
Navigation & SLAM Repository
 Open source
CVPR 2026 - MSGNav: Unleashing the Power of Multi-modal 3D Scene Graph for Zero-Shot Embodied Navigation
Navigation & SLAM Repository
 Open source
"Multi-robot Coordination with Agent-Server Architecture for Autonomous Navigation in Partially Unknown Environments", IROS 2020
Navigation & SLAM Repository
 Open source
MCP server that provides tools and resources to control and monitor robots using Nav2.
Navigation & SLAM Repository
 Open source
NeRF-SLAM: Real-Time Dense Monocular SLAM with Neural Radiance Fields. https://arxiv.org/abs/2210.13641 + Sigma-Fusion: Probabilistic Volumetric Fusion for Dense Monocular SLAM…
Navigation & SLAM Repository
 Open source
Object-goal navigation using semantic exploration.
Navigation & SLAM Repository
 Open source
ROS 2 Jazzy software for the OpenAMRobot mobile base: simulation, Nav2, SLAM, docking, control, drivers, and bringup.
Navigation & SLAM Repository
 Open source
OpenBot leverages smartphones as brains for low-cost robots. We have designed a small electric vehicle that costs about $50 and serves as a robot body. Our software stack for Android smartphones…
Navigation & SLAM Repository
 Open source
Implementation and annotation of Free Space Carving algorithm (CARV) using ORB-SLAM map points and camera poses.
Navigation & SLAM Repository
 Open source
PaddleRobotics is an open-source algorithm library for robots based on Paddle, including open-source parts such as human-robot interaction, complex motion control, environment perception, SLAM…
Navigation & SLAM Repository
 Repository
 Repository
 Open source
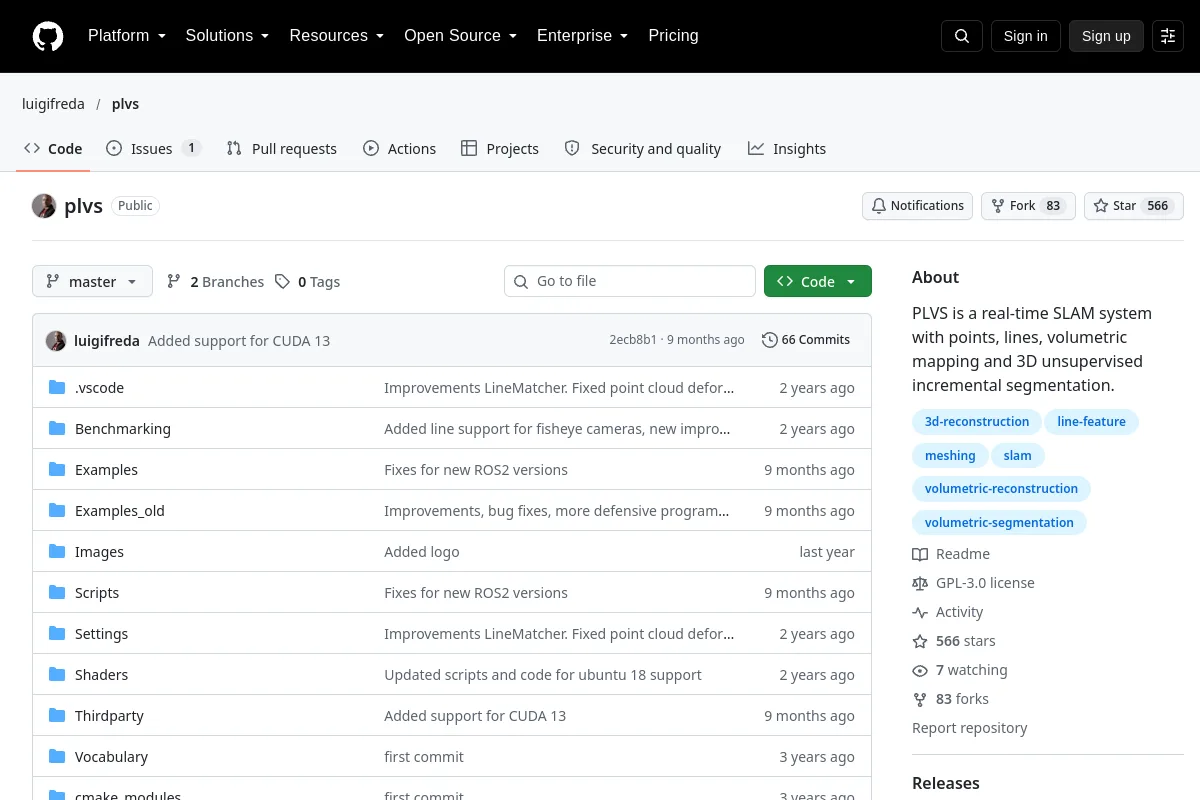
PLVS is a real-time SLAM system with points, lines, volumetric mapping and 3D unsupervised incremental segmentation.
Navigation & SLAM Repository
 Open source
Coverage path planning for polygons with holes.
Navigation & SLAM Repository
 Repository
 Repository
 Open source
RoomTour3D - Geometry-aware, cheap and automatic data from web videos for embodied navigation
Navigation & SLAM Repository
 Open source
Agent skill for production-grade ROS 2 development. Progressive-disclosure SKILL.md covering workspace, nodes, executors, QoS, ros2_control, Nav2, MoveIt 2, real-time, and deployment. Works with…
Navigation & SLAM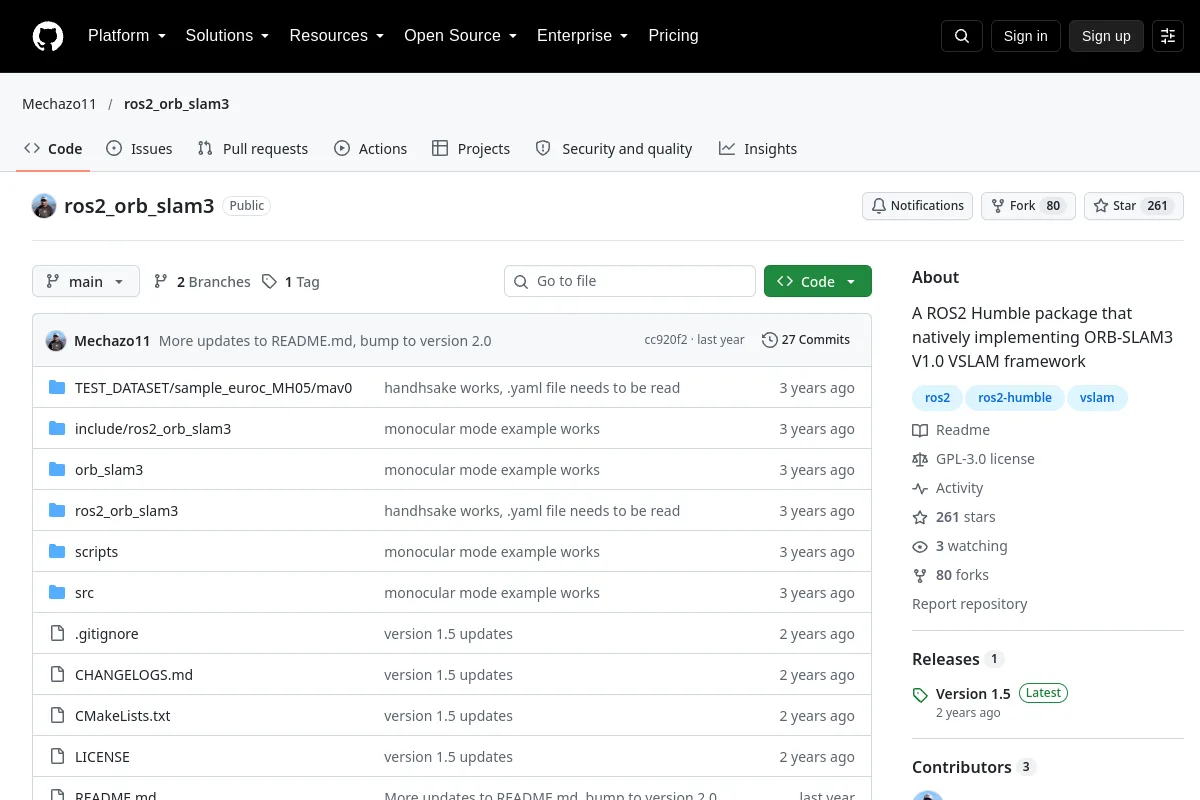 Repository
 Open source
A ROS2 Humble package that natively implementing ORB-SLAM3 V1.0 VSLAM framework
Navigation & SLAM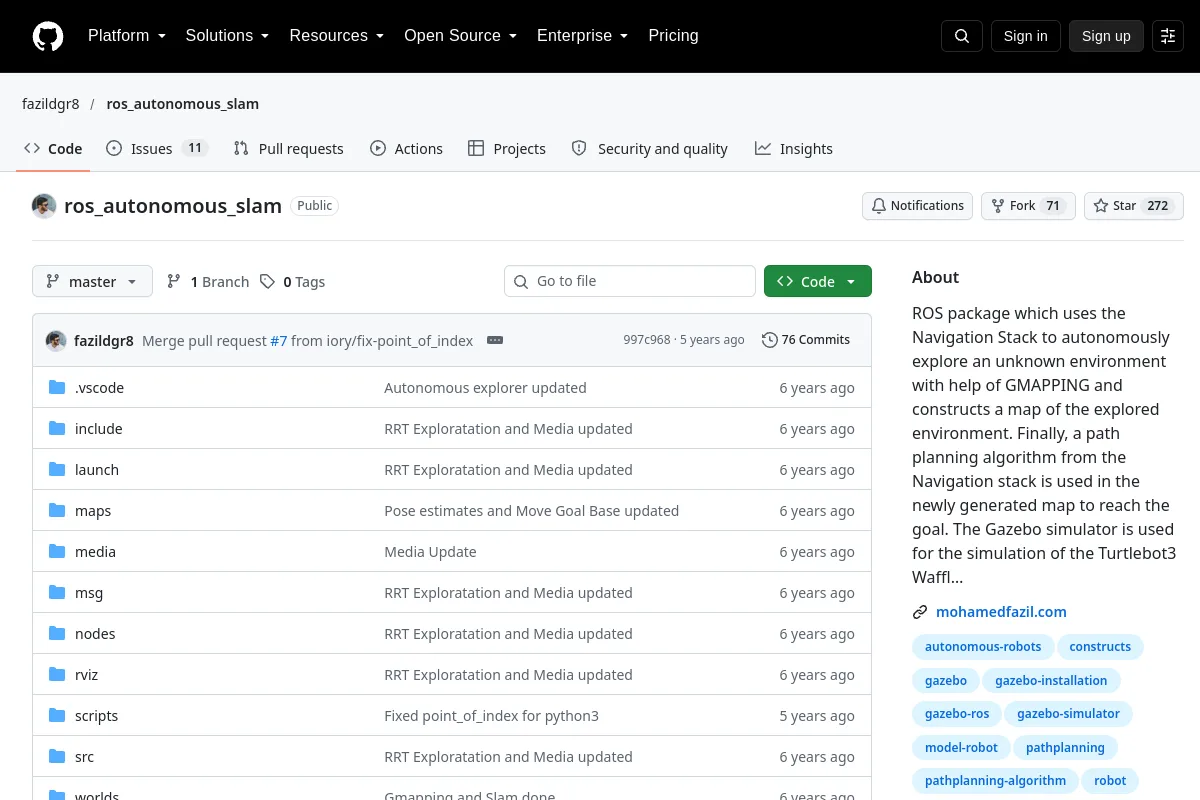 Repository
 Open source
ROS package which uses the Navigation Stack to autonomously explore an unknown environment with help of GMAPPING and constructs a map of the explored environment. Finally, a path planning…
Navigation & SLAM Repository
 Open source
SchurVINS: Schur Complement-Based Lightweight Visual Inertial Navigation System
Navigation & SLAMSELECTION NOTES
Match sensors, coordinate frames and localization assumptions to the deployment environment. Mapping, pose estimation, path planning and obstacle avoidance serve different parts of the navigation stack.
Know a resource that belongs here?