 Repository
Software / Open source
NeRF-SLAM · ToniRV
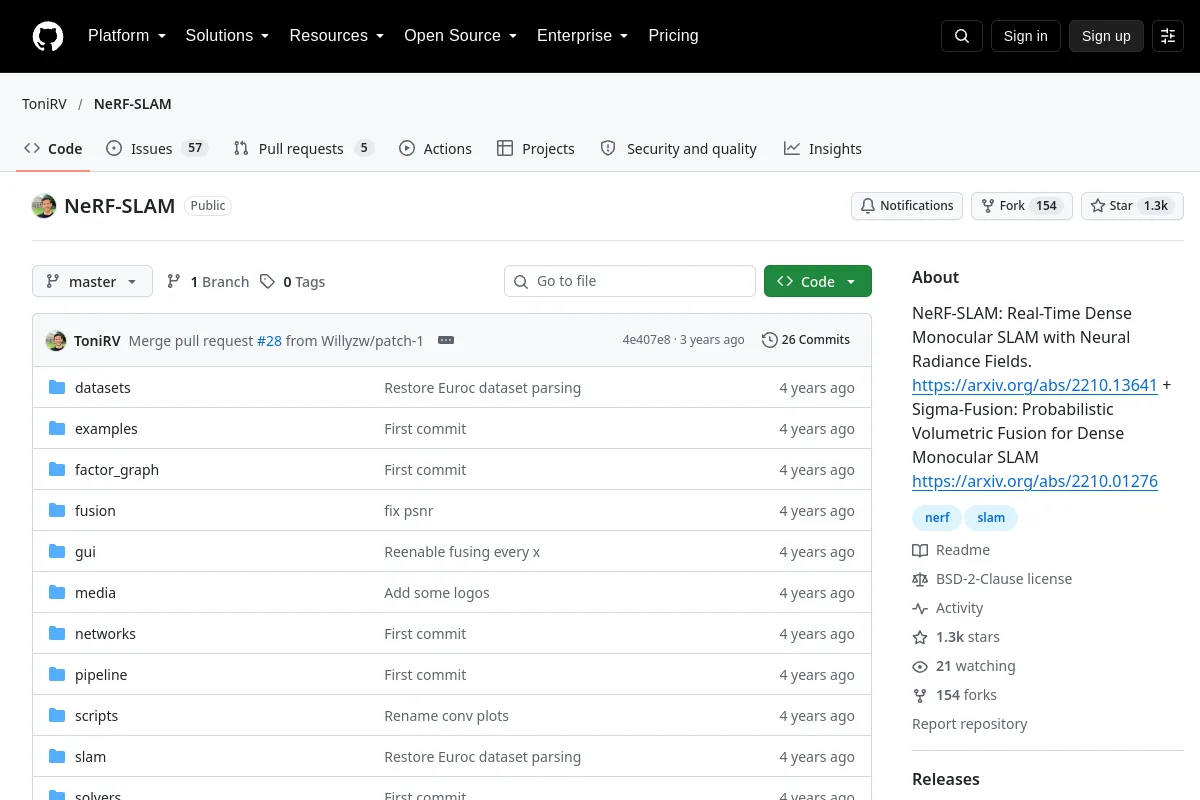
NeRF-SLAM: Real-Time Dense Monocular SLAM with Neural Radiance Fields. https://arxiv.org/abs/2210.13641 + Sigma-Fusion: Probabilistic Volumetric Fusion for Dense Monocular SLAM…
Overview
NeRF-SLAM: Real-Time Dense Monocular SLAM with Neural Radiance Fields. https://arxiv.org/abs/2210.13641 + Sigma-Fusion: Probabilistic Volumetric Fusion for Dense Monocular SLAM…
Publisher purpose: NeRF-SLAM: Real-Time Dense Monocular SLAM with Neural Radiance Fields. https://arxiv.org/abs/2210.13641 + Sigma-Fusion: Probabilistic Volumetric Fusion for Dense Monocular SLAM https://arxiv.org/abs/2210.01276
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Project information
- Maintainer
- ToniRV
- Primary language
- Python
- Repository code license
- BSD-2-Clause
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2024-03-19
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- Install
- CUDA 11.3
- Download Sample Data
- Run
- FAQ
- GPU Memory
Browse this resource’s categories
Explore related collections
Browse Software →More in Software
Repository
 Repository