 Repository
 Research
chalet · lil-lab
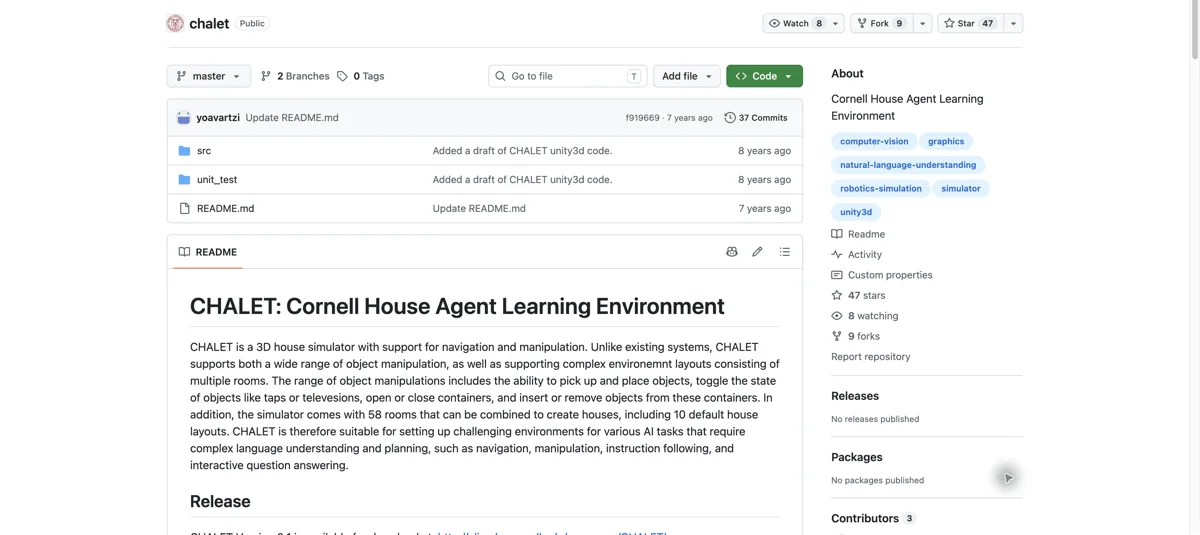
Cornell House Agent Learning Environment and associated resources.
Perception & geometryTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Research
Cornell House Agent Learning Environment and associated resources.
Perception & geometry Repository
 Research
CloudPeek provides a lightweight C++ point-cloud viewer for visual data inspection.
Visualization & data tools Repository
 Research
A GPU-Parallel analytical physics engine with mujoco API compatibility
Simulation & physics Repository
 Research
State-of-the-art method for model-based dexterous manipulation
Motion planning & control Repository
 Research
Constraint-aware imitation-learning research for autonomous racing.
Perception & geometry Website
 Research
A robot simulator with scene modeling and remote control interfaces.
Simulation & physics Repository
 Repository
 Research
JavaScript framework for robotics, drones, and the Internet of Things (IoT)
Middleware & communication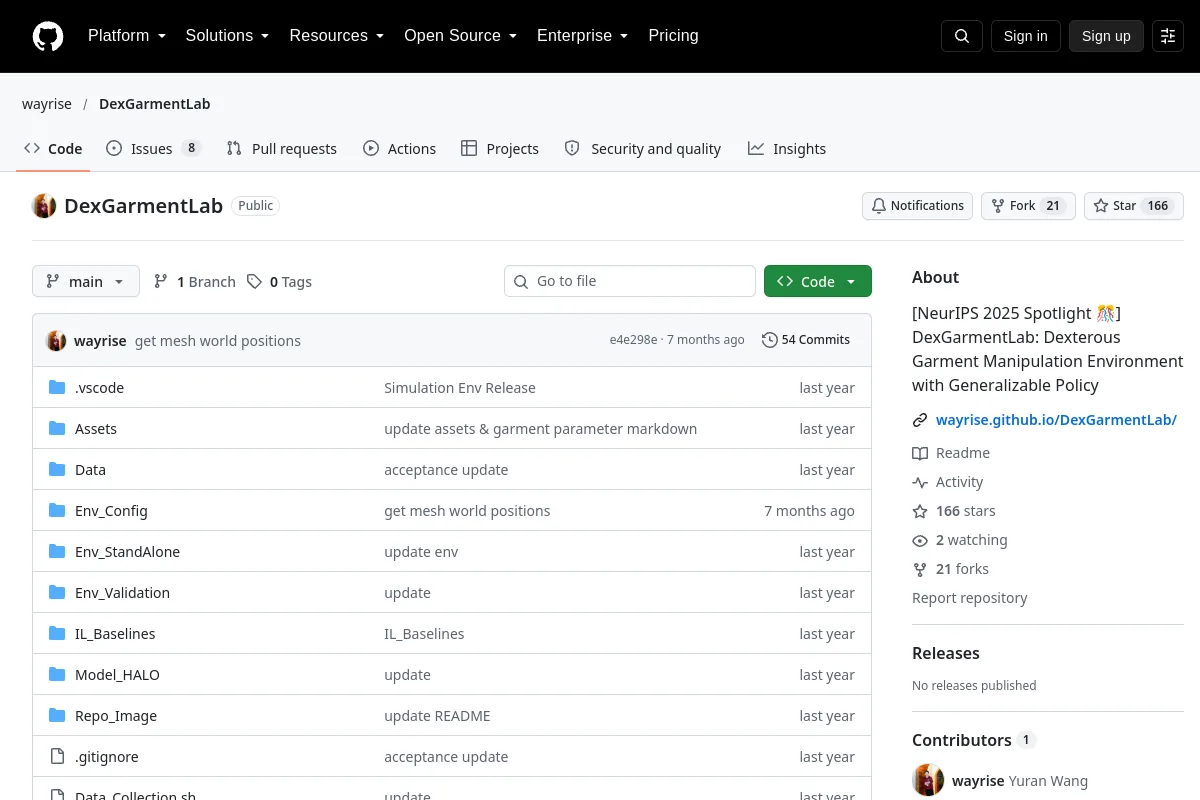 Repository
 Research
DexGarmentLab: Dexterous Garment Manipulation Environment with Generalizable Policy
Simulation & physics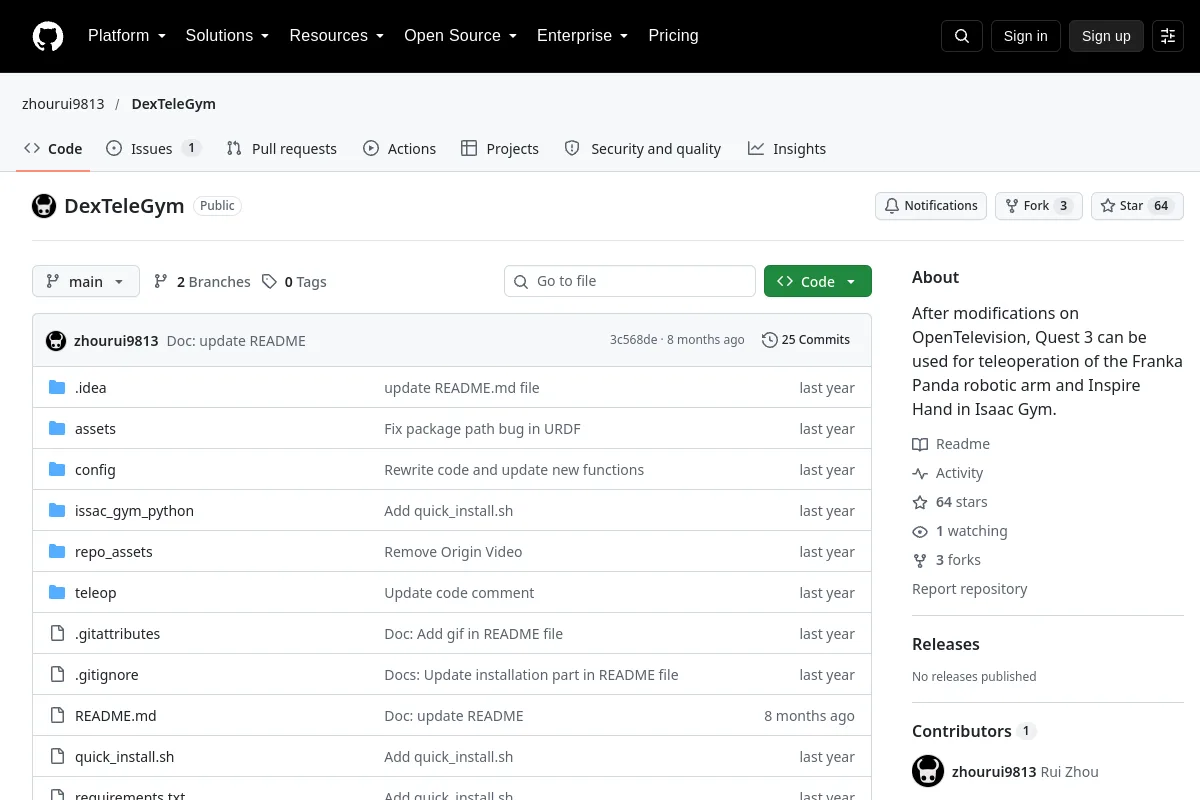 Repository
 Research
After modifications on OpenTelevision, Quest 3 can be used for teleoperation of the Franka Panda robotic arm and Inspire Hand in Isaac Gym.
Teleoperation software Repository
 Research
VR-based Teleoperation for Dexterous Manipulation - Control xArm + Inspire Hands with Vive Trackers and Quest Hand Tracking
Teleoperation software Repository
 Research
🍀 DexTrack: Towards Generalizable Neural Tracking Control for Dexterous Manipulation from Human References
Perception & geometry Repository
 Research
This project consists of research on a 6 degree of freedom robot. A 3D model of the robot has been made on Unity to demonstrate Forward and Inverse Kinematics. Important concepts in robotics like…
Motion planning & control Repository
 Research
 implementation of divide-and-conquer reinforcement learning.
Robot learning frameworks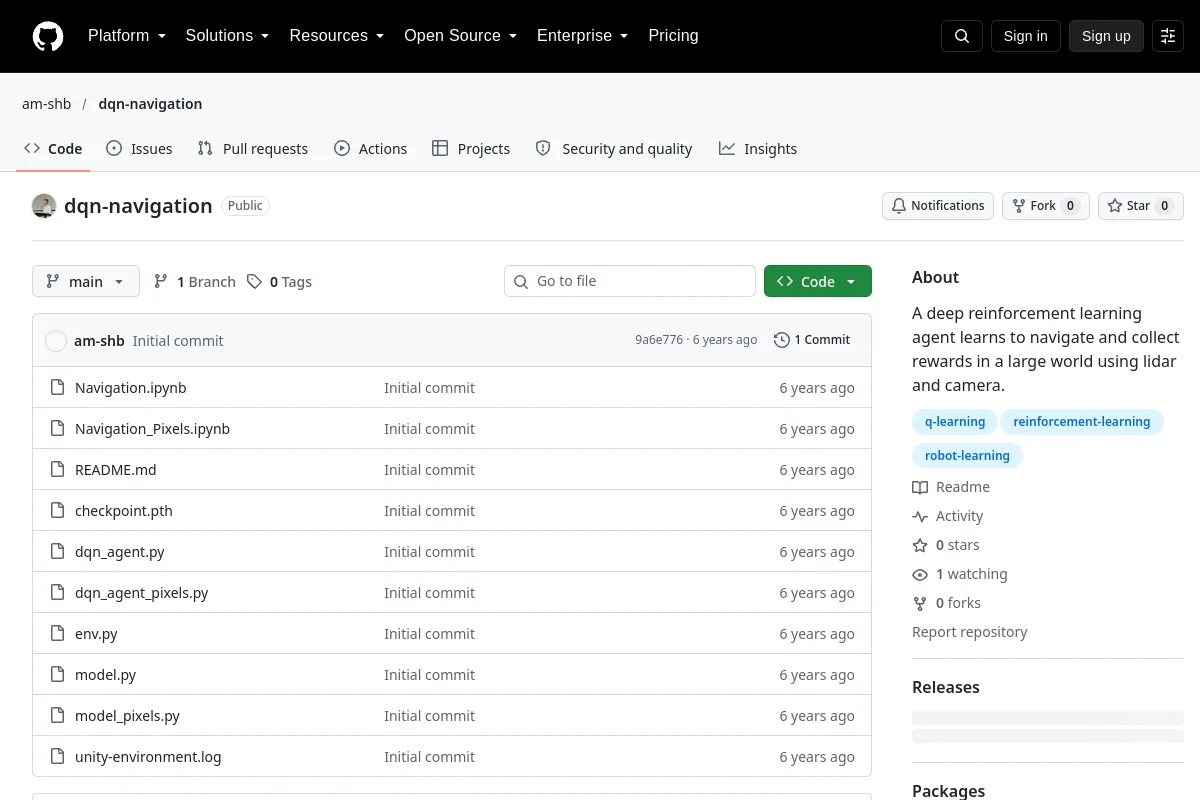 Repository
 Research
A reinforcement-learning navigation agent using lidar and camera observations.
Navigation & SLAM Website
 Repository
 Research
Domain-randomization experiments for closed-loop soft-robot control.
Motion planning & control Repository
 Repository
 Research
EAO-SLAM: Monocular Semi-Dense Object SLAM Based on Ensemble Data Association
Navigation & SLAM Repository
 Research
SO-ARM101 dual-view ACT experiments with documented runtime safeguards.
Robot learning frameworks Repository
 Research
Embodied Eval Automation provides workflows for collecting robot-benchmark and simulator episodes.
Visualization & data tools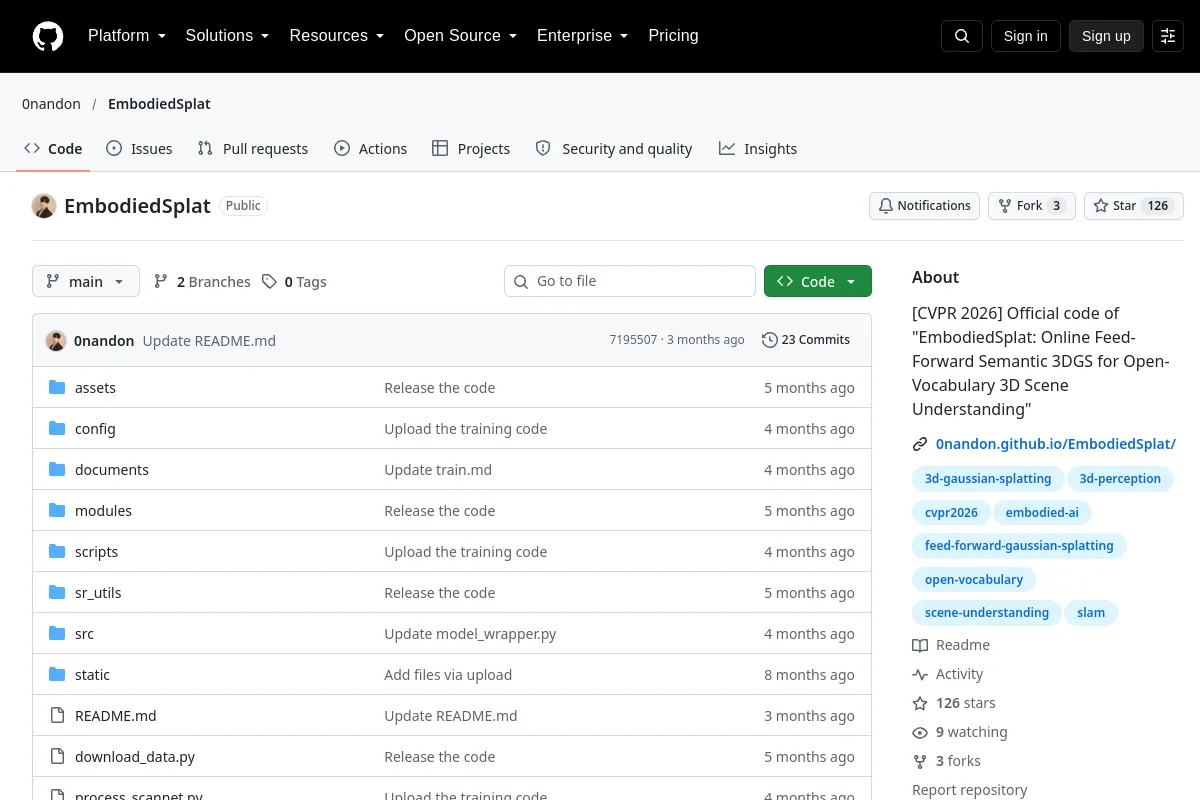 Repository
 Research
Official code of "EmbodiedSplat: Online Feed-Forward Semantic 3DGS for Open-Vocabulary 3D Scene Understanding"
Perception & geometry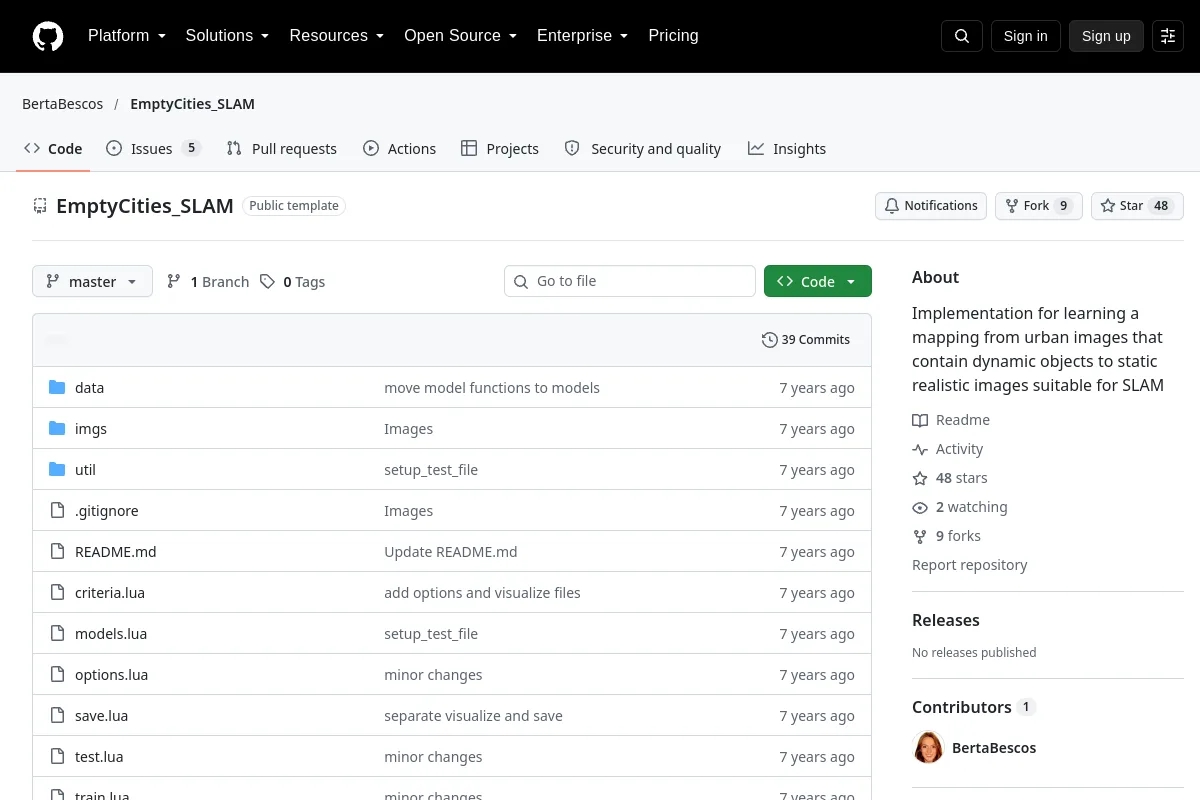 Repository
 Research
Implementation for learning a mapping from urban images that contain dynamic objects to static realistic images suitable for SLAM
Navigation & SLAM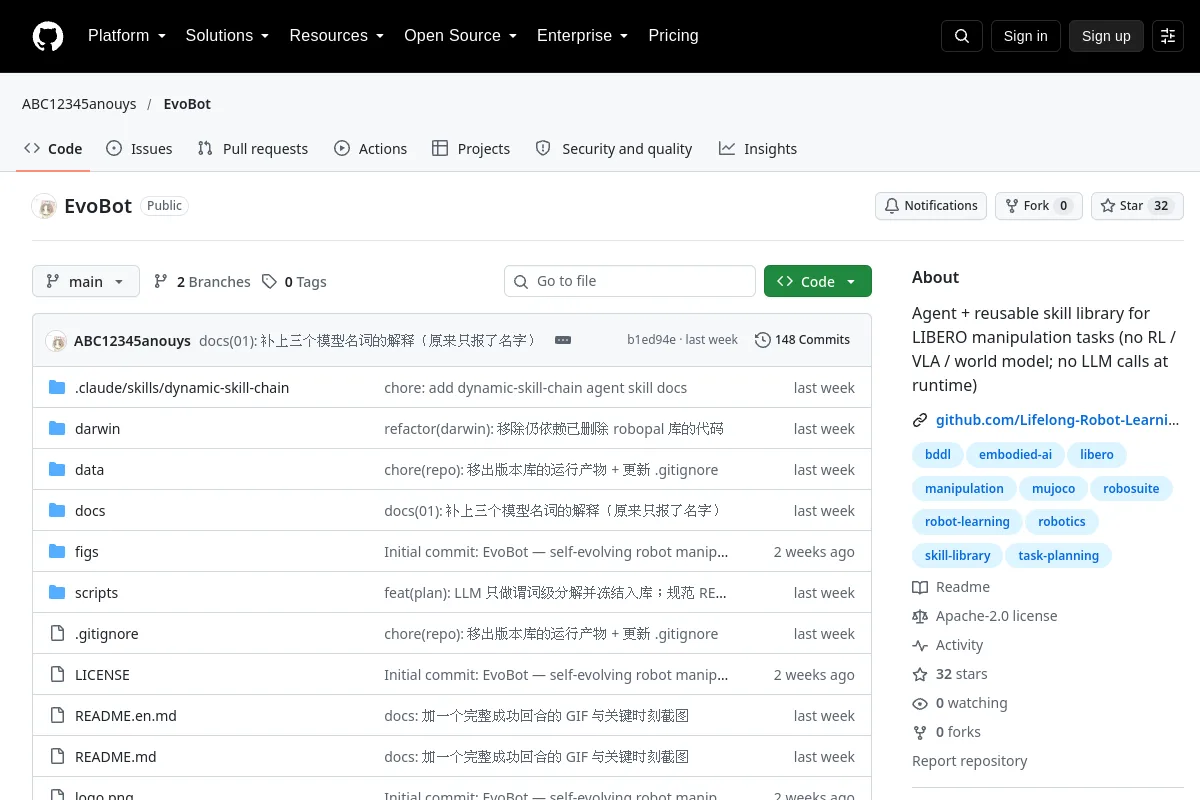 Repository
 Research
EvoBot provides an agent and reusable skill library for LIBERO manipulation tasks.
Motion planning & controlKnow a resource that belongs here?