 Repository
 Research
easy handeye · IFL-CAMP
ROS tools for automated hand-eye calibration.
Perception & geometryTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Research
ROS tools for automated hand-eye calibration.
Perception & geometry Repository
 Research
RoboHive provides a framework and task suites for robot learning.
Robot learning frameworks Repository
 Repository
 Research
ROS 2 driver for the Kinova Gen3 robot arm.
Robot learning frameworks Repository
 Research
Robot model collection for OpenRAVE.
Robot learning frameworks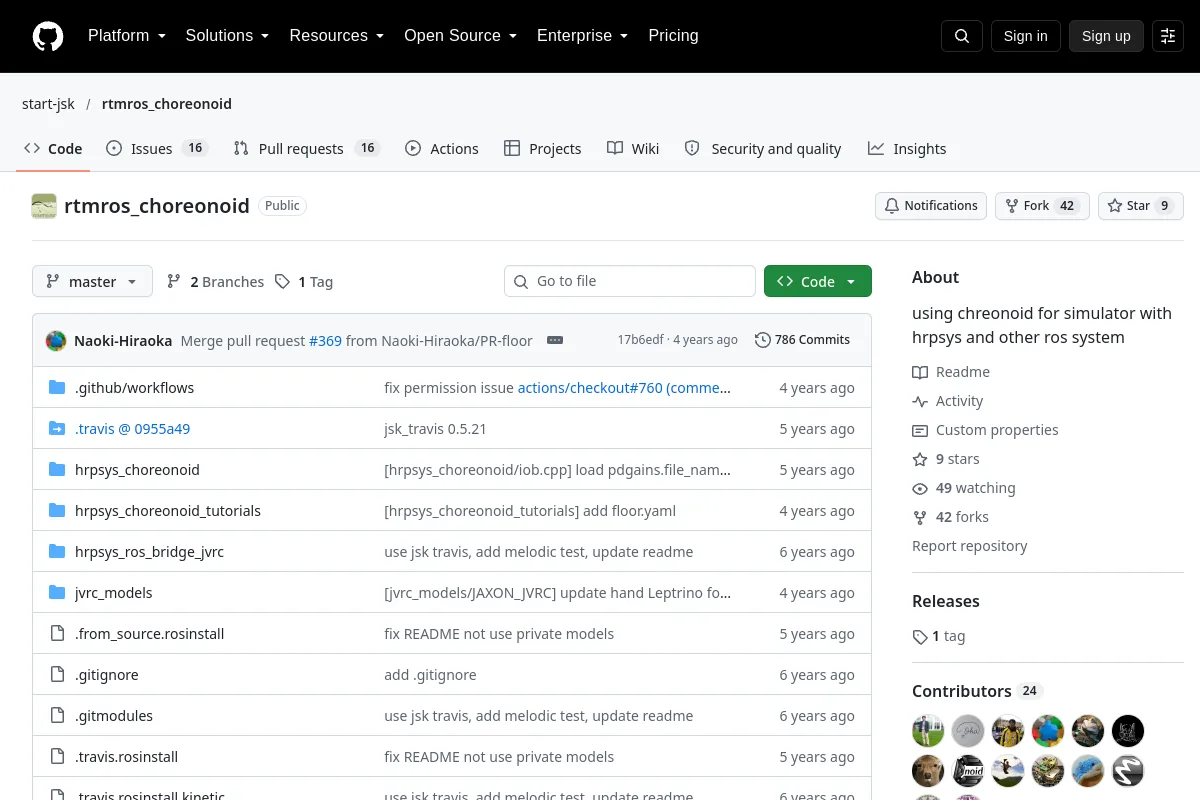 Repository
 Research
Choreonoid simulation integration with ROS and hrpsys tooling.
Simulation & physics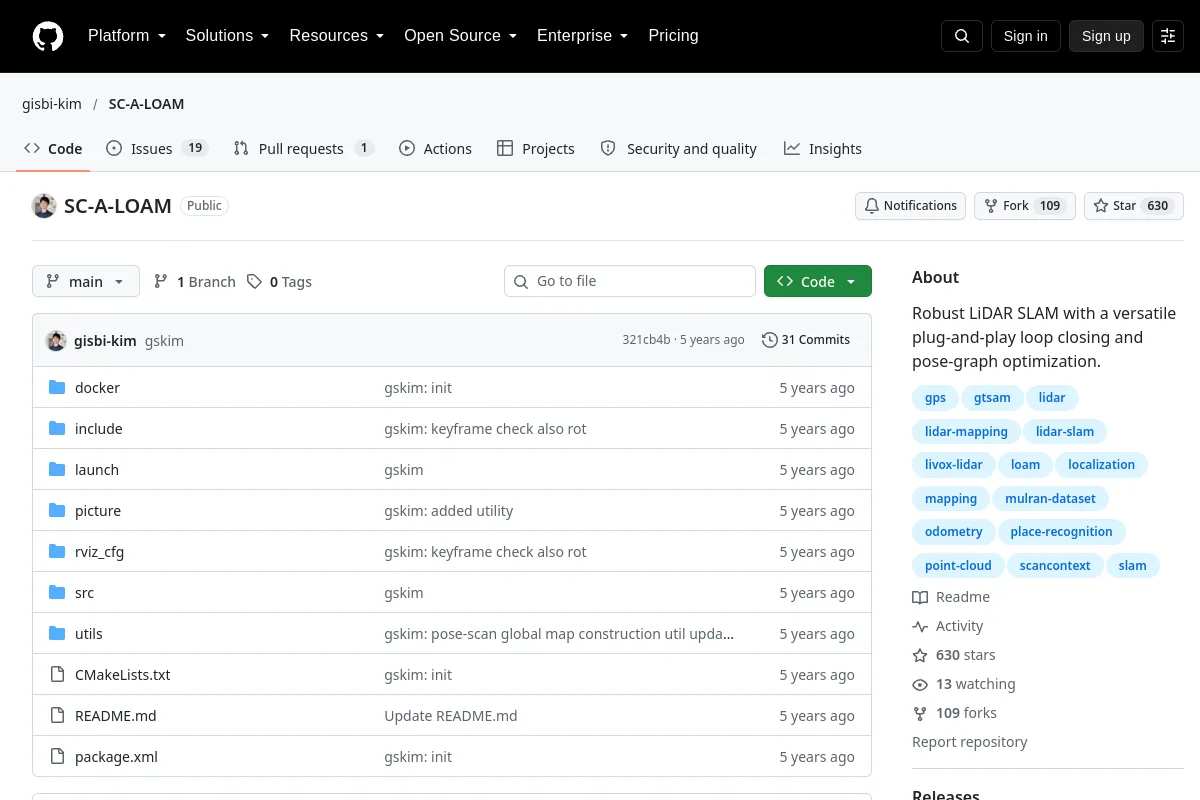 Repository
 Research
Robust LiDAR SLAM with a versatile plug-and-play loop closing and pose-graph optimization.
Navigation & SLAM Repository
 Research
URDF and SDF models of the iCub humanoid robot.
Simulation & physics Repository
 Research
 code for mapping multimodal instructions to robotic actions.
Navigation & SLAM Repository
 Research
A visual fiducial system for robotics research.
Robot learning frameworks Repository
 Repository
 Research
This repository contains code for training and evaluating FlingBot in both simulation and real-world settings on a dual-UR5 robot arm setup for Ubuntu 18.04
Simulation & physics Repository
 Research
Golang framework for robotics, drones, and the Internet of Things (IoT)
Middleware & communication Repository
 Research
GraspIt! simulator for robotic grasping research.
Simulation & physics Repository
 Research
Main software repository for the iCub humanoid robot.
Robot learning frameworks Repository
 Research
Isaac Sim application for developing, simulating and testing AI-driven robots.
Simulation & physics Repository
 Research
Intensity Scan Context based full SLAM implementation for autonomous driving. ICRA 2020
Navigation & SLAM Repository
 Research
Environment for developing and testing robot motion-planning algorithms.
Motion planning & control Repository
 Research
Examples for deploying ROS and ROS 2 workloads on Kubernetes and KubeEdge.
Robot learning frameworks Repository
 Repository
 Research
 code for injecting robotic affordances into multimodal language models.
Robot learning frameworks Repository
 Repository
 Research
A URDF model of the Robotiq 2-Finger Adaptive Gripper 85.
Robot learning frameworks Repository
 Research
A unified, agentic system for general-purpose robots, enabling multi-modal perception, mapping and localization, and autonomous mobility and manipulation, with intelligent interaction with users.
Navigation & SLAMKnow a resource that belongs here?