 Repository
 Research
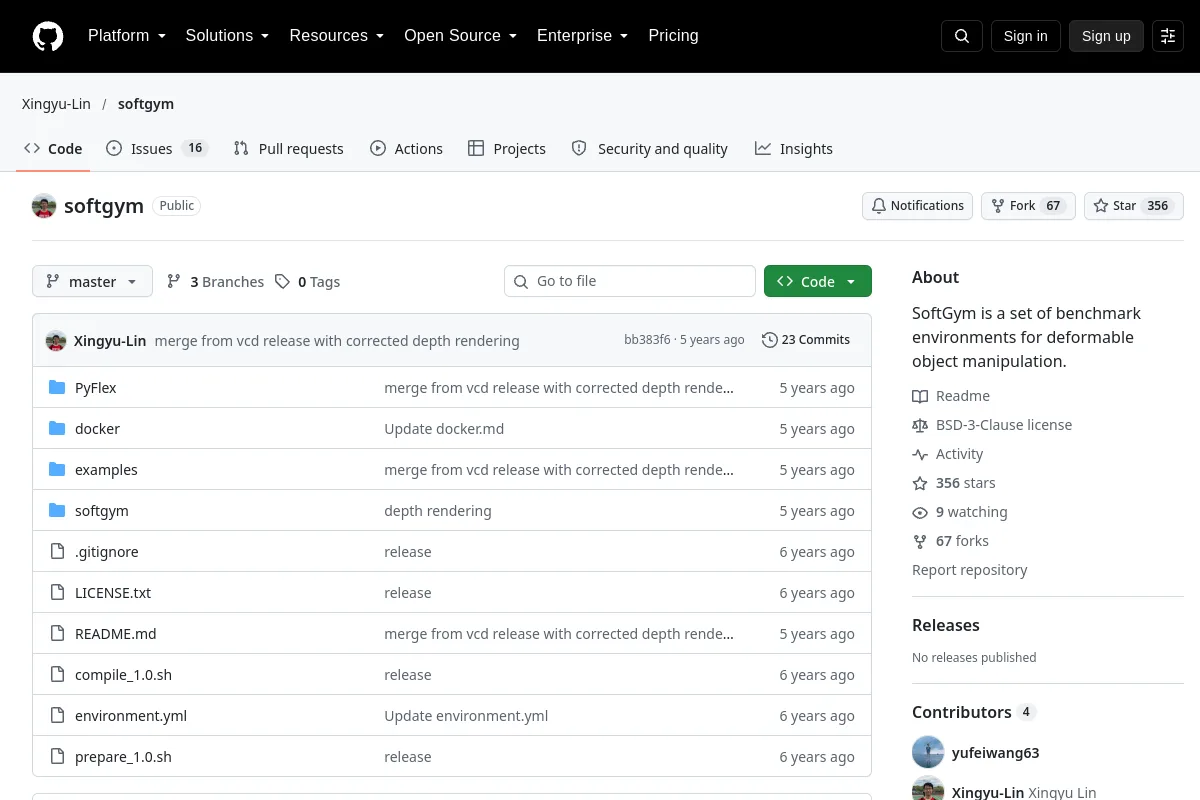
softgym · Xingyu-Lin
SoftGym provides benchmark environments for deformable-object manipulation.
Manipulation
Software / Research
This repository contains code for training and evaluating FlingBot in both simulation and real-world settings on a dual-UR5 robot arm setup for Ubuntu 18.04
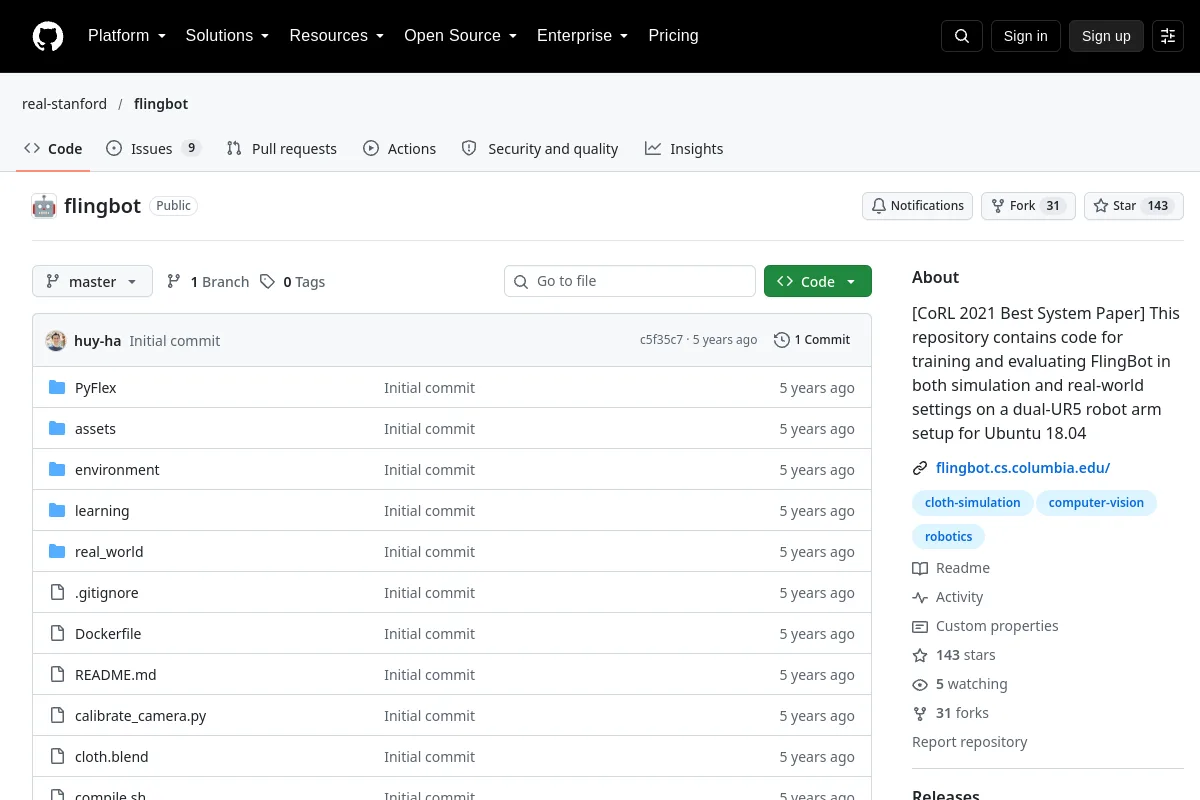
This repository contains code for training and evaluating FlingBot in both simulation and real-world settings on a dual-UR5 robot arm setup for Ubuntu 18.04
Publisher purpose: [CoRL 2021 Best System Paper] This repository contains code for training and evaluating FlingBot in both simulation and real-world settings on a dual-UR5 robot arm setup for Ubuntu 18.04
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
SoftGym provides benchmark environments for deformable-object manipulation.
Manipulation