 Repository
 Open source
franka ros2 · frankarobotics
ROS 2 integration packages for Franka research robots.
Robot learning frameworksTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Open source
ROS 2 integration packages for Franka research robots.
Robot learning frameworks Repository
 Open source
ROS integration packages for Franka research robots.
Robot learning frameworks Repository
 Open source
ACDC4Robot: Automated Conversion of Description Conventions for Robots from Design to Learning
Robot learning frameworks Repository
 Open source
ROS 2 localization for outdoor robots: IMU, wheel encoders and GPS fused in a 23-state UKF at 100 Hz. When the estimate goes wrong it reports which sensor and why, instead of drifting silently.…
Navigation & SLAM Repository
 Open source
Gaussian-SLAM: Photo-realistic Dense SLAM with Gaussian Splatting
Navigation & SLAM Repository
 Open source
A simple tool to generate gazebo terrain using satellite images and DEM data.
Simulation & physics Repository
 Open source
Motion Planning around Obstacles with Convex Optimization by Marcucci et al, 2023
Motion planning & control Repository
 Open source
Research code for learning general motion flows as robot affordances.
Robot learning frameworks Repository
 Open source
A lightweight robotics RL framework built on Genesis with IsaacLab-aligned APIs, enabling fast task development and easy migration from existing IsaacLab environments.
Simulation & physics Repository
 Open source
Generating Robotic Simulation Tasks via Large Language Models
Simulation & physics Repository
 Open source
Modern C++20 GNSS toolkit — RTK/PPP/CLAS/IMU fusion.
Navigation & SLAM Repository
 Open source
A convex MPC locomotion controller implemented in MuJoCo with Unitree Go2 quadruped
Motion planning & control Repository
 Open source
"Good Robot! Now Watch This!": Repurposing Reinforcement Learning for Task-to-Task Transfer; and “Good Robot!”: Efficient Reinforcement Learning for Multi-Step Visual Tasks with Sim to Real Transfer
Robot learning frameworks Repository
 Open source
Gradient-Informed Path Smoothing for Wheeled Mobile Robots (GRIPS)
Motion planning & control Repository
 Open source
Example connecting an Isaac GR00T policy to a simulated Franka Panda in MuJoCo.
Perception & geometry Repository
 Open source
LiDAR ground segmentation and terrain estimation implementation.
Fleet & autonomy systems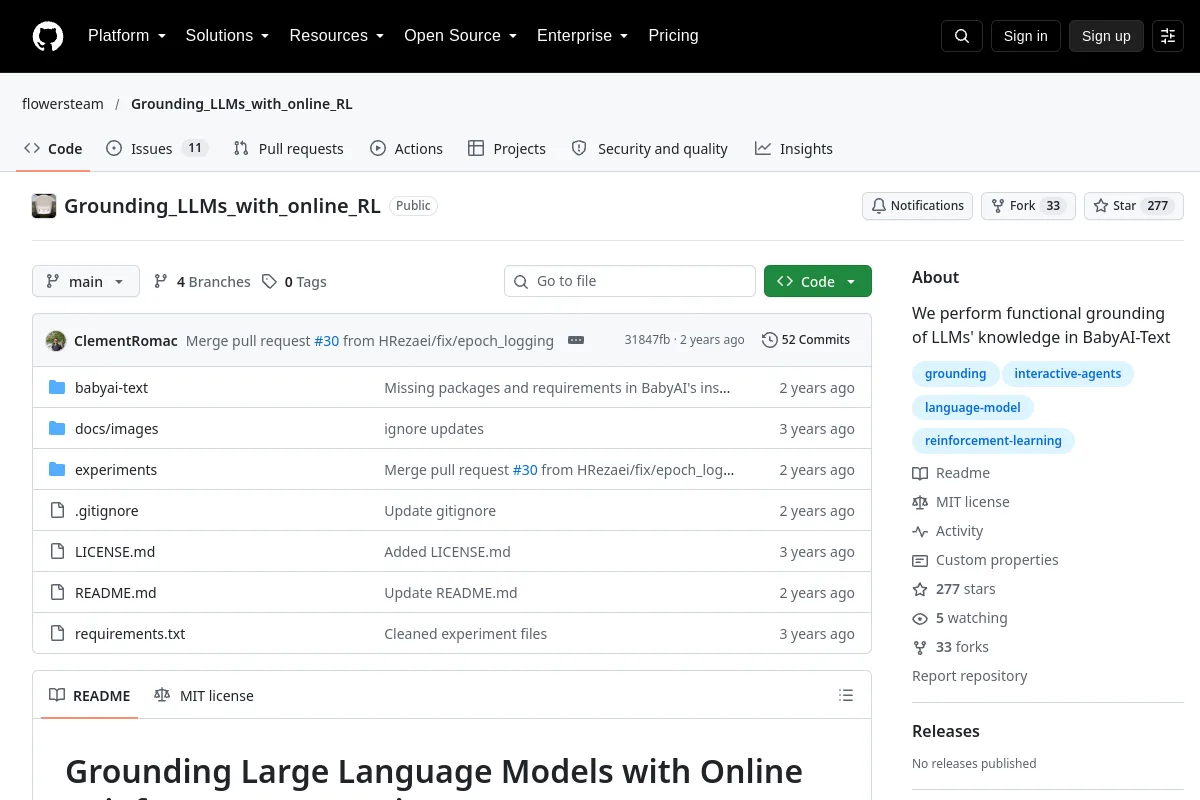 Repository
 Open source
Online reinforcement learning experiments grounding language models in BabyAI-Text.
Robot learning frameworks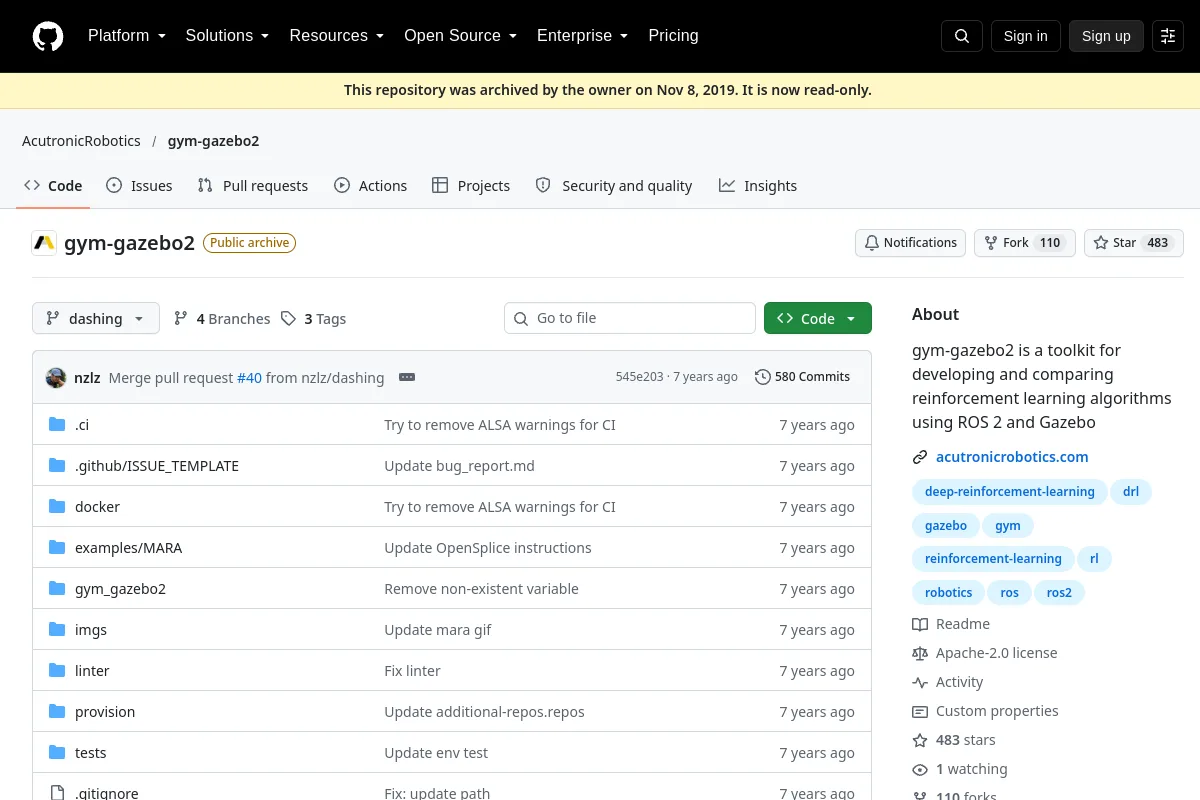 Repository
 Open source
An archived toolkit for RL experiments with ROS 2 and Gazebo.
Simulation & physics Repository
 Open source
Framework for developing OpenAI Gym robotics environments simulated with Ignition Gazebo
Simulation & physics Repository
 Open source
PyBullet Gymnasium environments for quadcopter control learning.
Motion planning & control Repository
 Open source
Reproducible reinforcement-learning experiments in Gazebo.
Simulation & physics Repository
 Open source
NVIDIA Halos Outside-In Safety Blueprint extends robot perception beyond on-board sensors by using external infrastructure cameras and AI agents to dynamically control robot behavior and perform…
Perception & geometry Repository
 Open source
HapticWAM research code for distilling touch into a world-action model.
Robot learning frameworks Repository
 Open source
Hector Quadrotor with MoveIt! Motion Planning Framework
Motion planning & controlKnow a resource that belongs here?