 Repository
 Research
lidar_slam_ros2 · rsasaki0109
ROS 2 LiDAR SLAM for pointcloud-map authoring, benchmarking, and Autoware-compatible map workflows.
Navigation & embodied interactionTHE EMBODIED AI DIRECTORY
Find evaluation tasks for navigation and interaction in embodied environments.
Repository
Research
ROS 2 LiDAR SLAM for pointcloud-map authoring, benchmarking, and Autoware-compatible map workflows.
Navigation & embodied interaction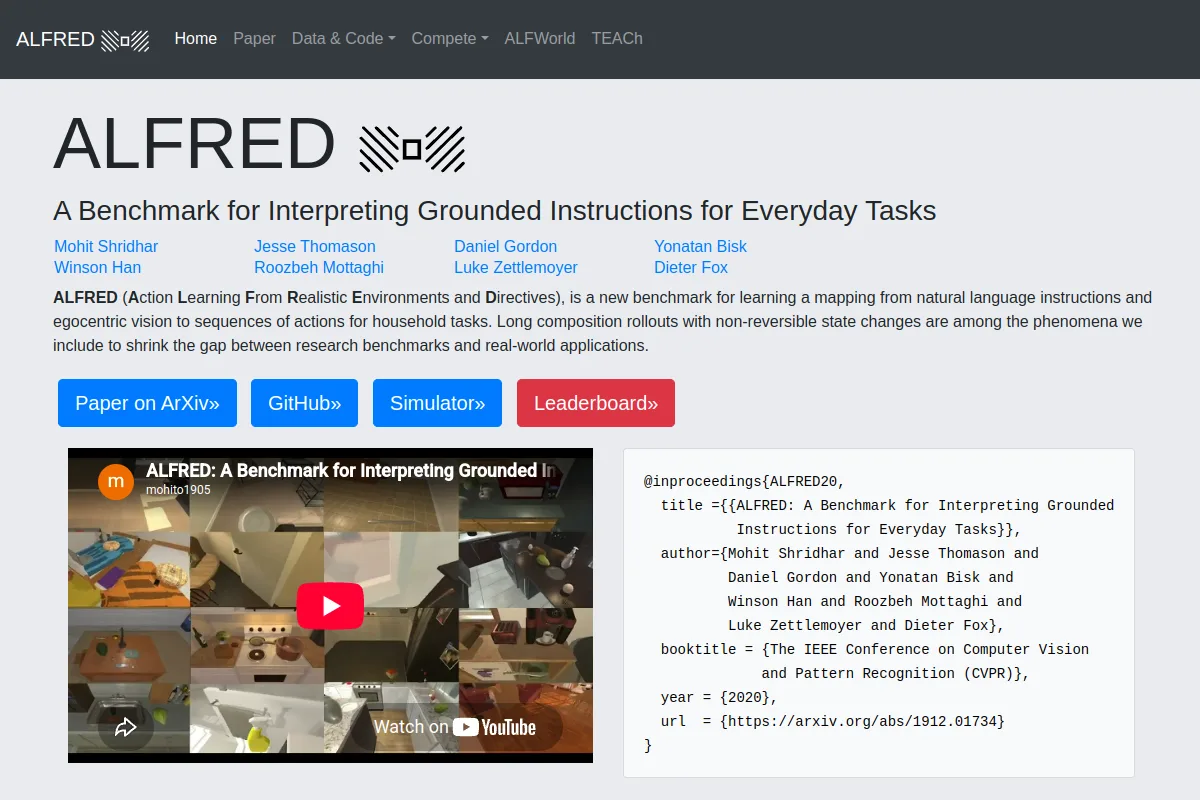 Website
 Research
A benchmark for following language instructions in interactive environments.
Navigation & embodied interaction Repository
 Research
BARK provides simulation and benchmarking tools for autonomous-driving behavior planning.
Navigation & embodied interaction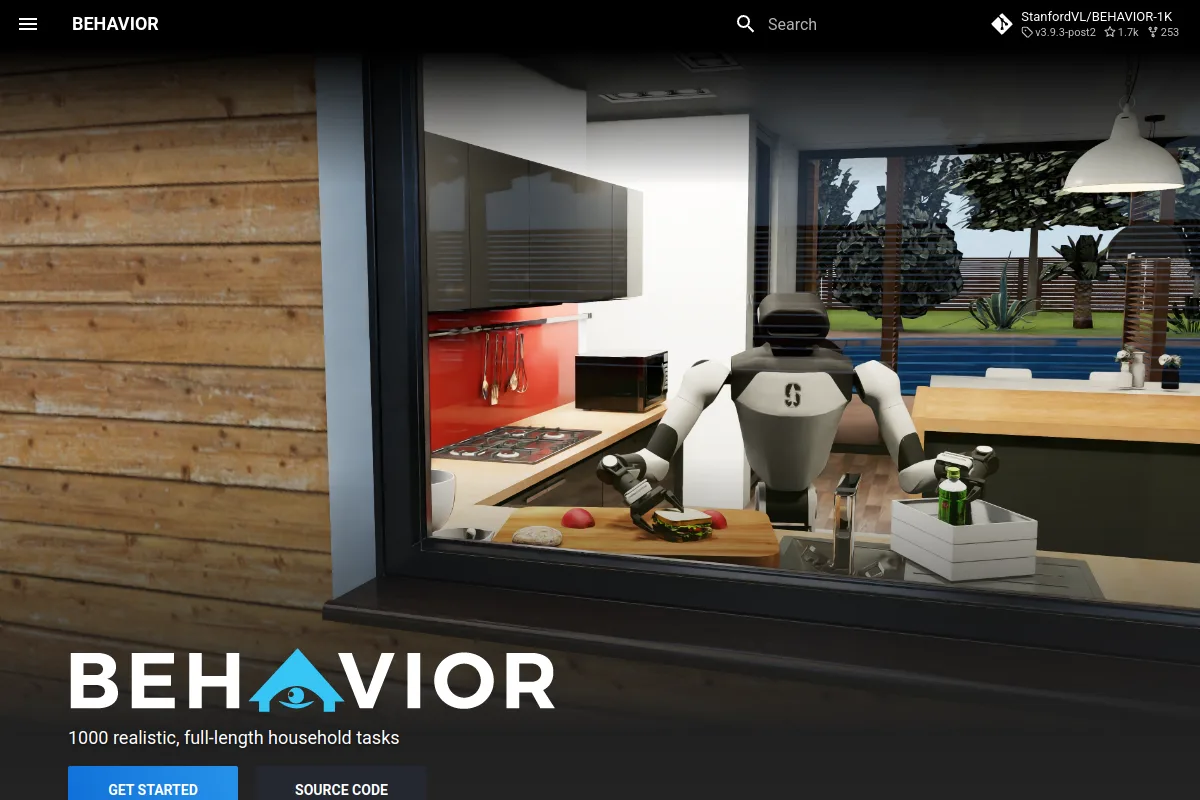 Website
 Research
Household activity benchmarks for embodied AI and robotic behavior.
Navigation & embodied interaction Repository
 Research
MapEval: Towards Unified, Robust and Efficient SLAM Map Evaluation Framework.
Navigation & embodied interaction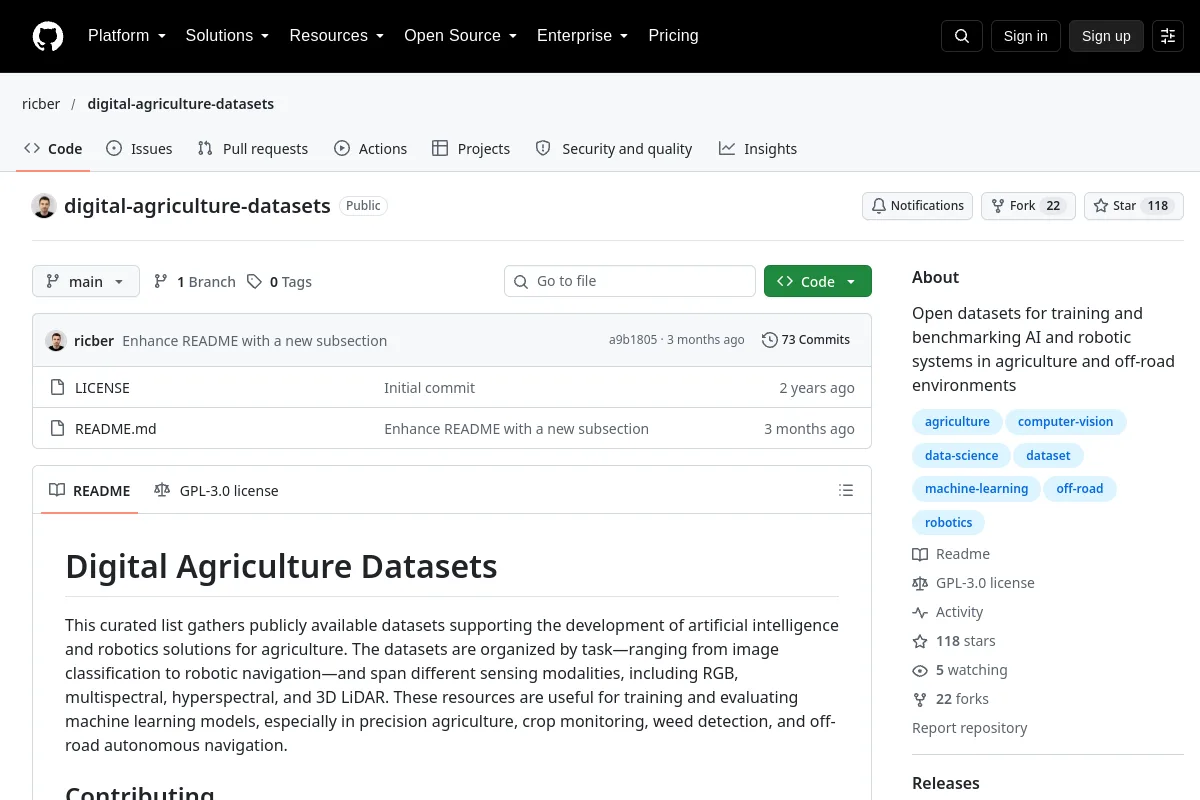 Repository
 Research
Open datasets for training and benchmarking AI and robotic systems in agriculture and off-road environments
Navigation & embodied interaction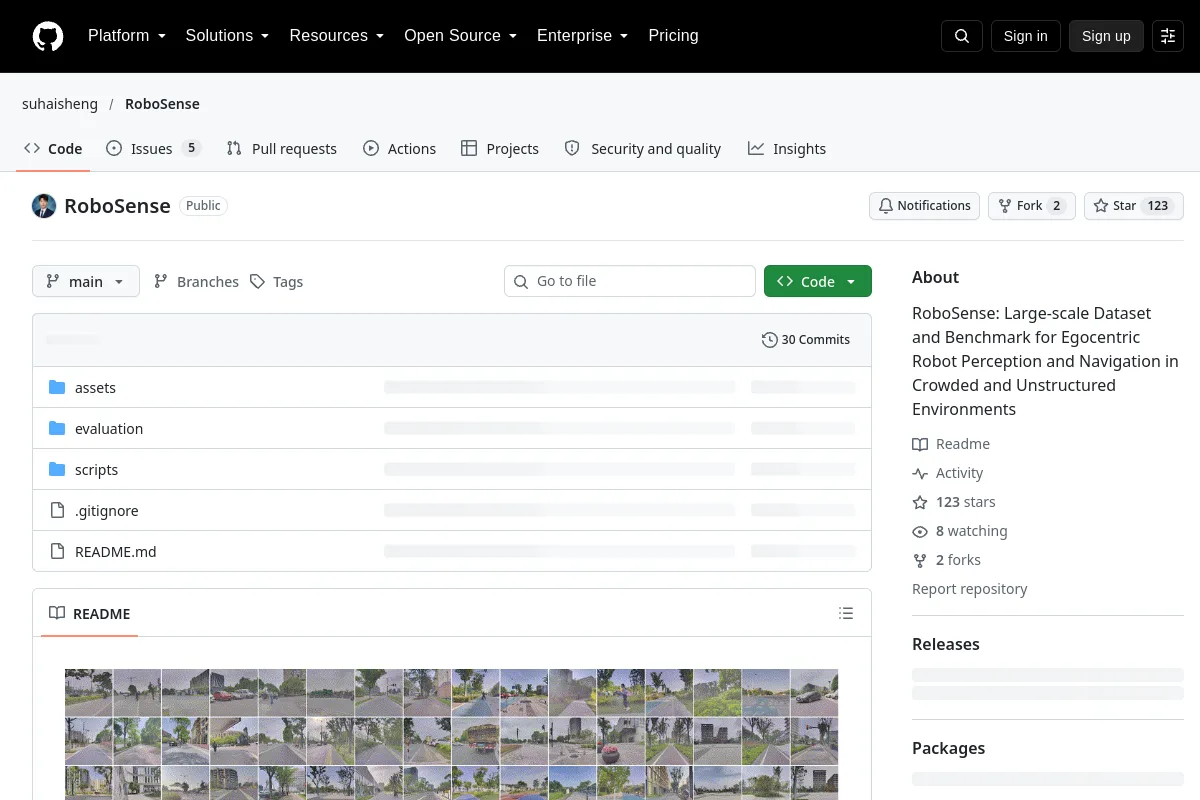 Repository
 Research
RoboSense: Large-scale Dataset and Benchmark for Egocentric Robot Perception and Navigation in Crowded and Unstructured Environments
Navigation & embodied interaction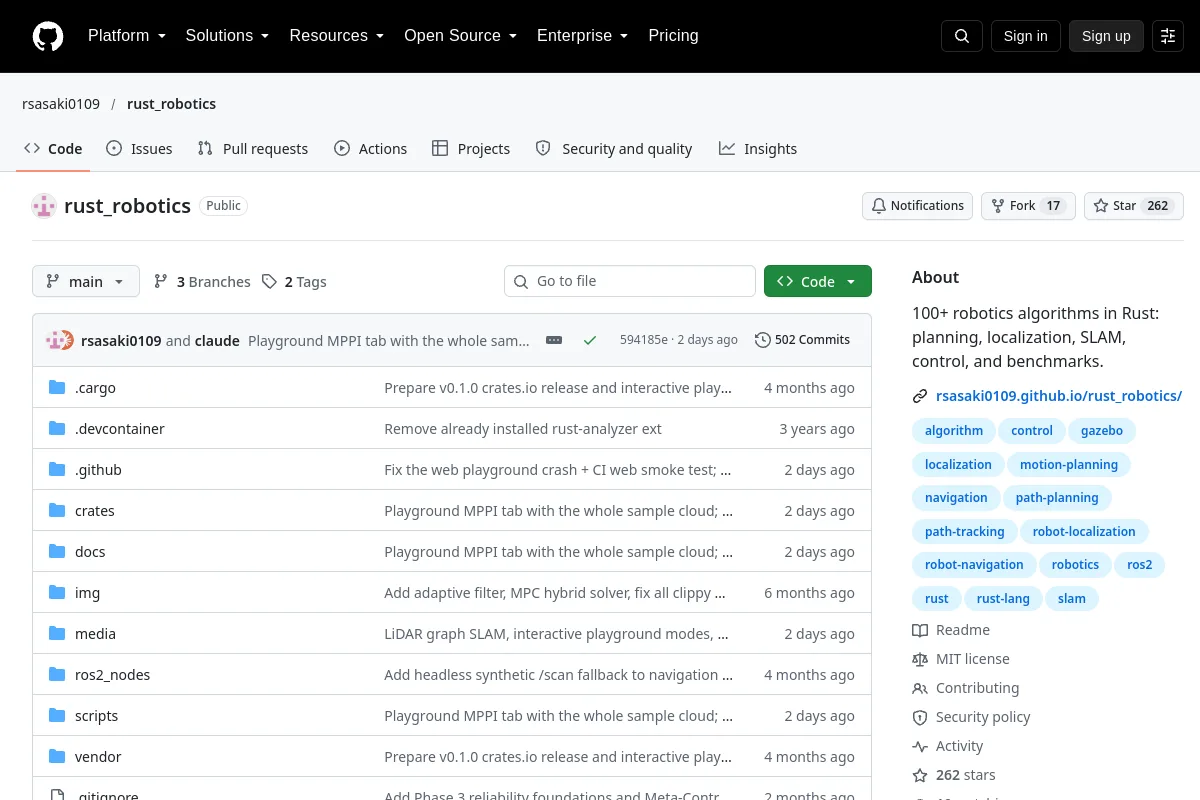 Repository
 Research
100+ robotics algorithms in Rust: planning, localization, SLAM, control, and benchmarks.
Navigation & embodied interaction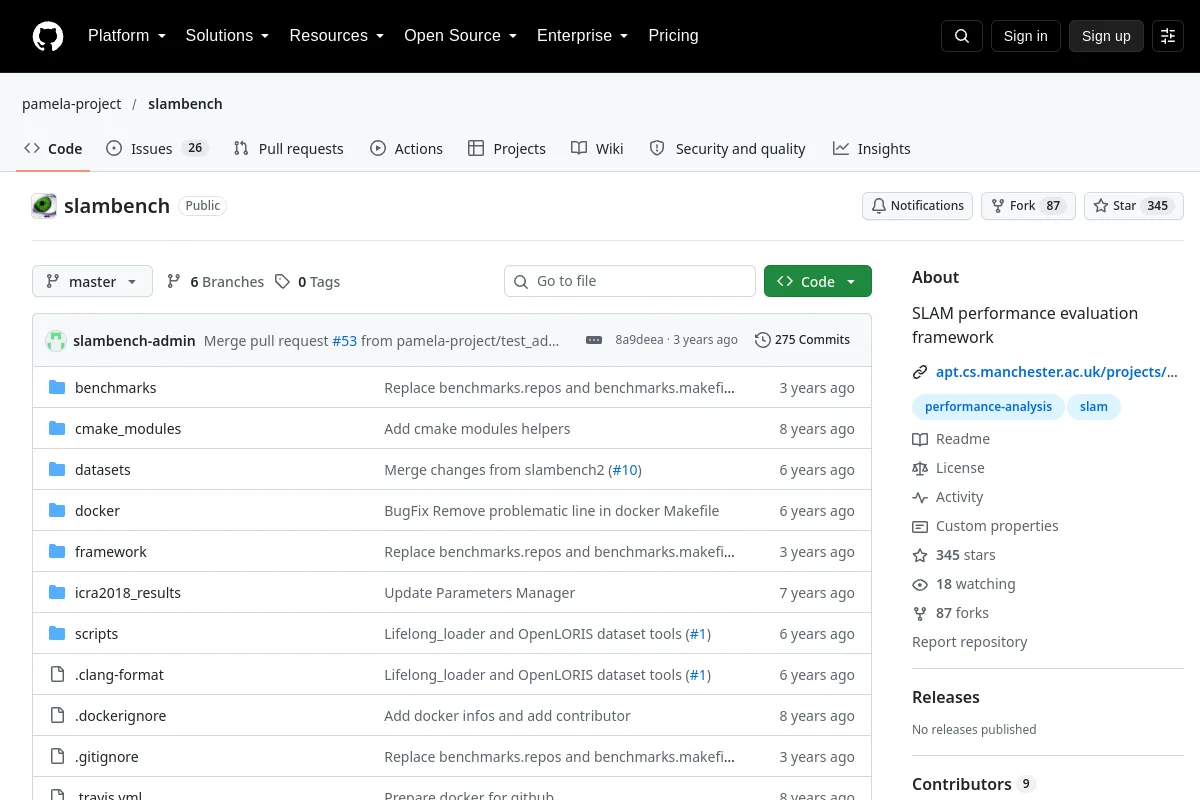 Repository
 Research
SLAM performance evaluation framework
Navigation & embodied interaction Repository
 Research
OpenXRLab Visual-inertial SLAM Toolbox and Benchmark
Navigation & embodied interactionSELECTION NOTES
Inspect observations, maps, instructions and permitted agent actions. Check how task success and path efficiency are measured and whether test environments overlap with training data.
Know a resource that belongs here?