 Repository
 Open source
wanderland · ai4ce
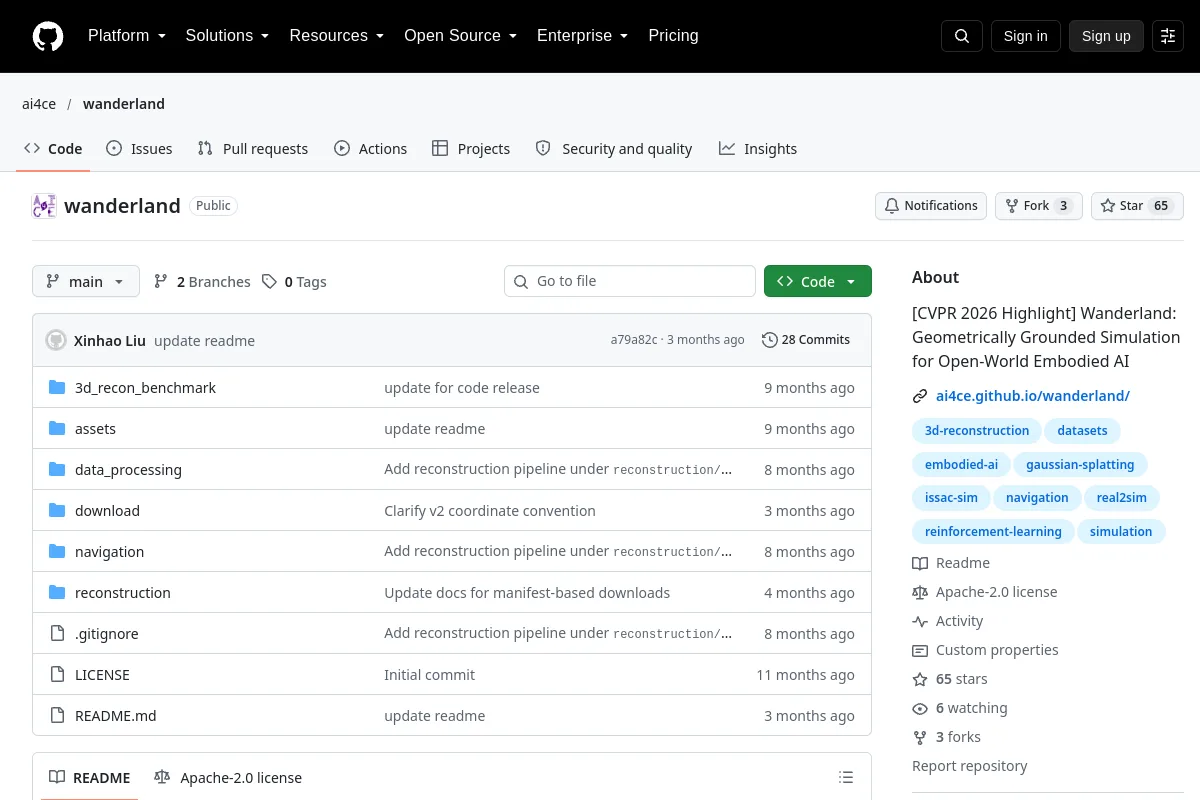
Wanderland: Geometrically Grounded Simulation for Open-World Embodied AI
Simulation & physicsTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Open source
Wanderland: Geometrically Grounded Simulation for Open-World Embodied AI
Simulation & physics Repository
 Open source
Multi-resolution 3D occupancy mapping from multiple sensors.
Navigation & SLAM Repository
 Open source
Whole-Body Nonlinear MPC for Realtime Humanoid Loco-Manipulation Planning and Control
Motion planning & control Repository
 Open source
Mapping, localization and using the navigation stack with ROS2 Jazzy
Navigation & SLAM Repository
 Repository
 Open source
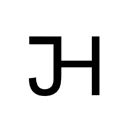
Force controlled assembly process. In real and simulated environment. Using Universal Robots UR5, ROS, Gazebo.
Simulation & physics Repository
 Open source
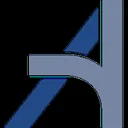
A protocol for real-time transfer and visualization of autonomy data.
Visualization & data tools Repository
 Open source
ROS 2 integration for Ultralytics YOLO perception models.
Robot learning frameworks Repository
 Repository
 Open source
Spatial-perception SDK for ZED cameras and robotics applications.
Robot SDKs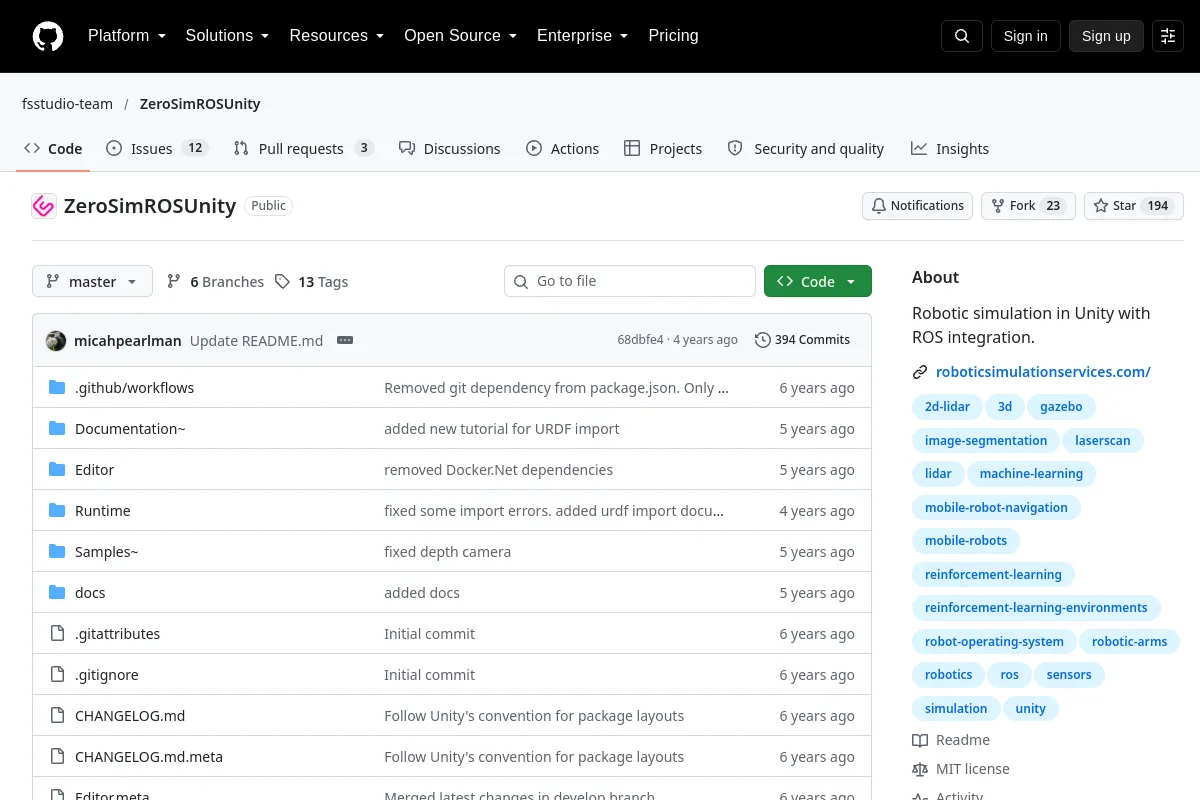 Repository
 Open source
Unity robotic simulation tools with ROS integration.
Navigation & SLAM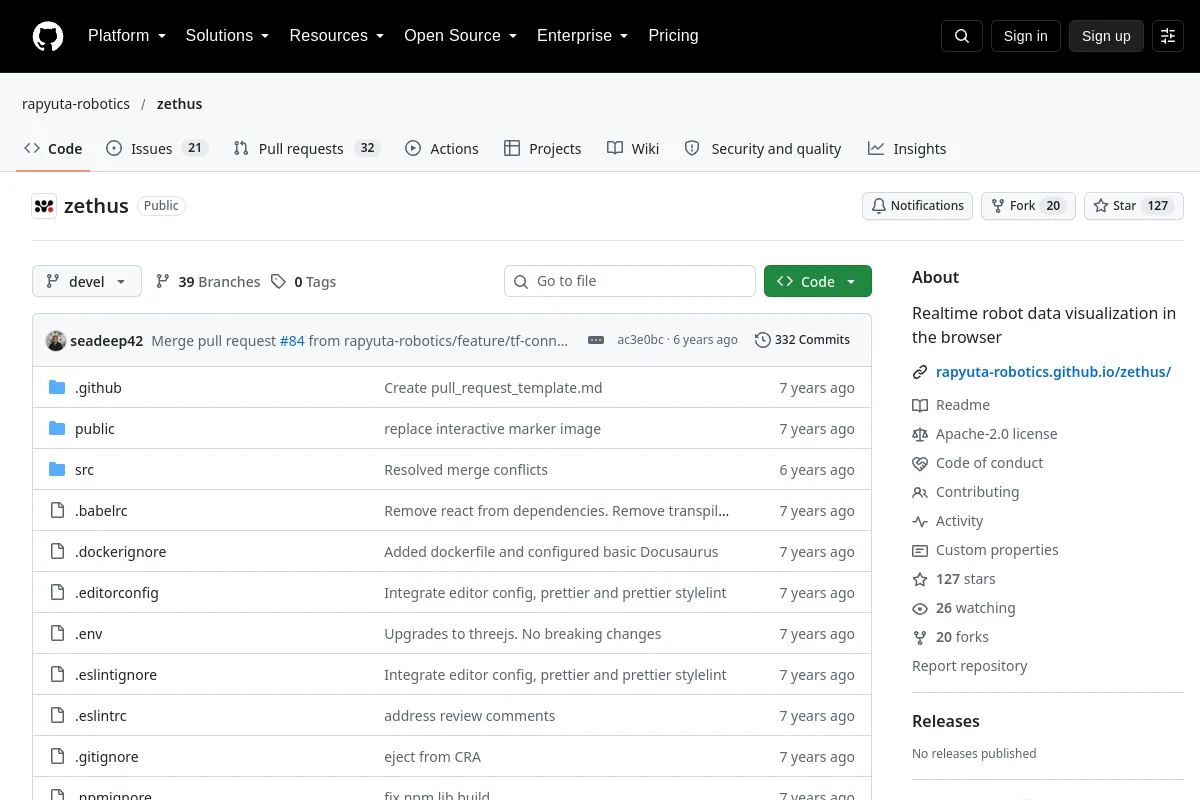 Repository
 Open source
Browser-based visualization of live robot data.
Visualization & data tools Repository
 Open source
Import URDF robot descriptions into Unity for robot visualisation and simulation.
Visualization & data tools Repository
 Open source
A dataflow runtime for robotic perception and control pipelines.
Middleware & communication Website
 Website
 Open source
An open-source Python toolkit for real-world robot learning.
Robot learning frameworks Website
 Website
 Website
 Website
Know a resource that belongs here?