 Repository
 Research
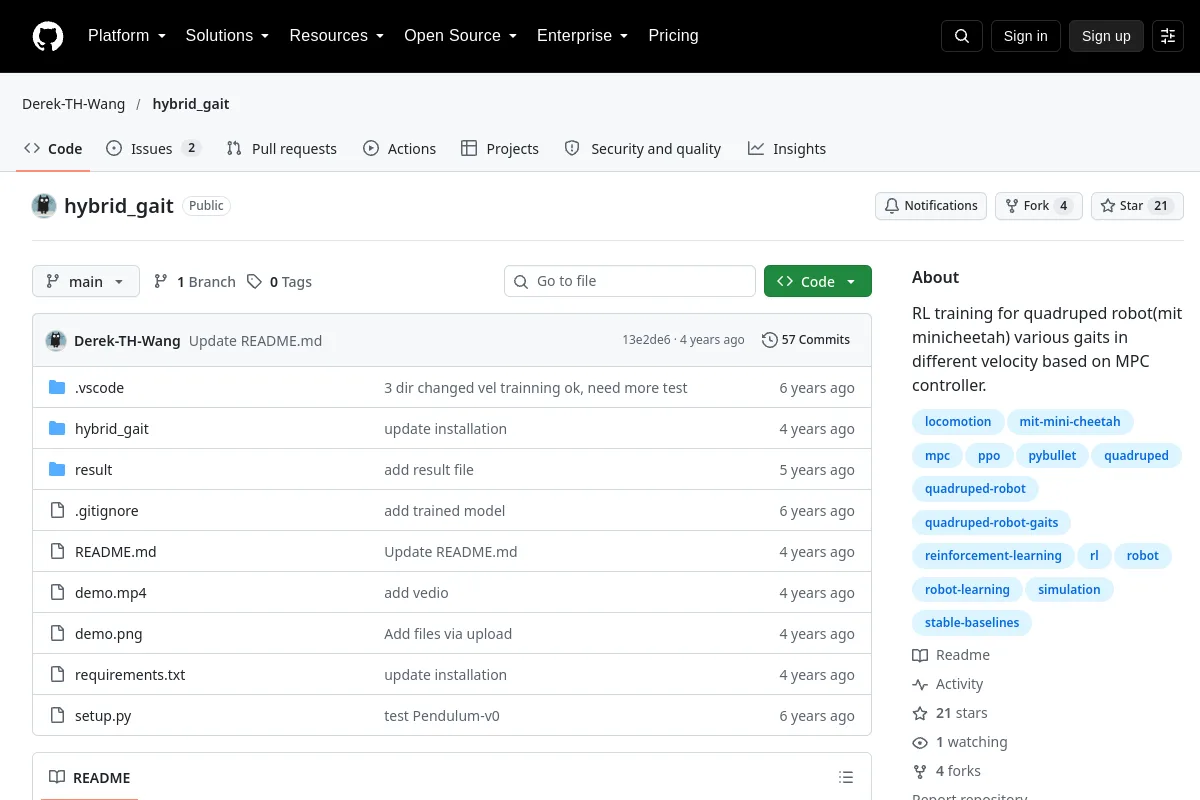
hybrid gait · Derek-TH-Wang
Quadruped gait learning combining reinforcement learning and model predictive control.
Motion planning & controlTHE EMBODIED AI DIRECTORY
Find kinematics, dynamics, trajectory-generation and motion-planning tools.
Repository
Research
Quadruped gait learning combining reinforcement learning and model predictive control.
Motion planning & control Repository
 Research
CPG and reinforcement-learning control for a swimming eel robot.
Motion planning & control Repository
 Research
Python package for symbolic robot-arm inverse kinematics.
Motion planning & control Repository
 Research
A Python wrapper for IKFast inverse kinematics on the UR5 arm.
Motion planning & control Repository
 Research
Manipulator and mobile robot models for trajectory planning and actuator analysis.
Motion planning & control Repository
 Research
NVIDIA-accelerated packages for arm motion planning and control
Motion planning & control Repository
 Research
LangGraph VLA Agent orchestrates SmolVLA and LeRobot policies for multi-step manipulation.
Motion planning & control Repository
 Research
MAVLink-to-ROS gateway for vehicle communication and ground-control integration.
Motion planning & control Repository
 Repository
 Repository
 Research
Welcome to an in-depth visual guide on Motion Planning in Robotics — the brain behind how robots decide where and how to move!
Motion planning & control Repository
 Research
Motion-Planning-for-for-Mobile-Robotse-Robotics
Motion planning & control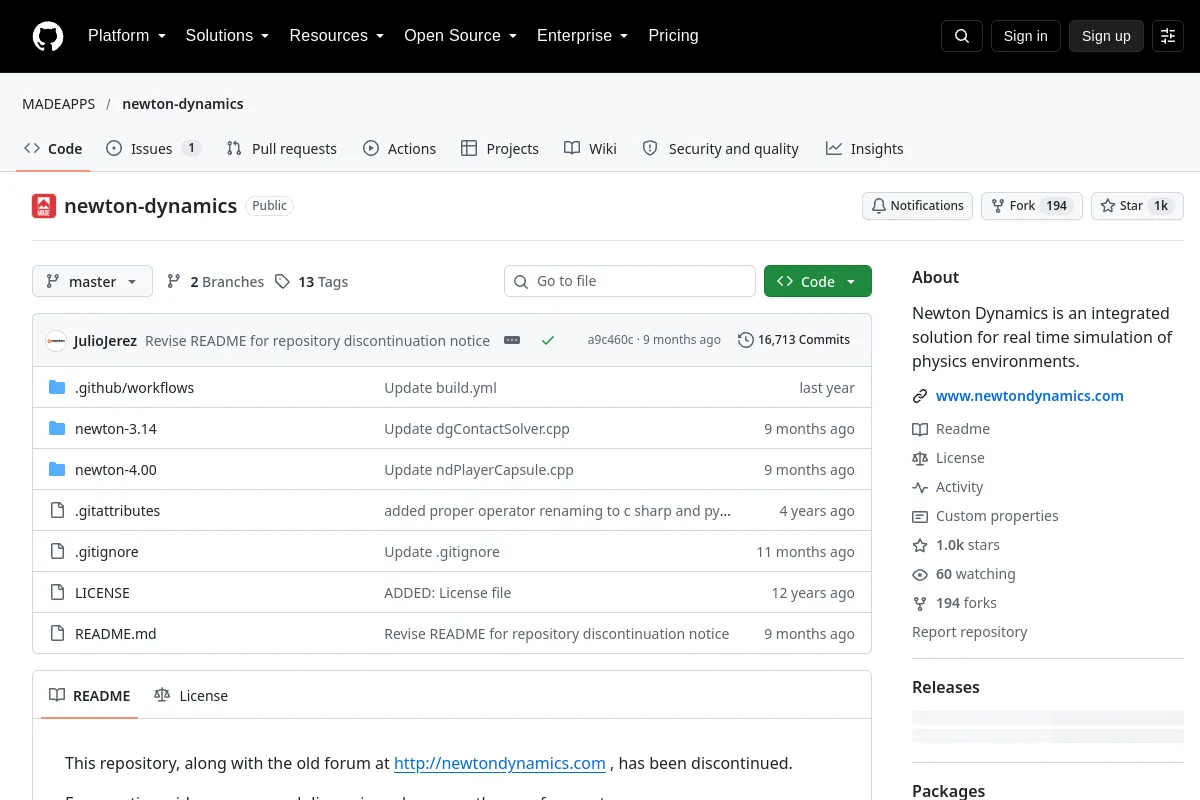 Repository
 Research
Newton Dynamics engine for real-time physics simulation.
Motion planning & control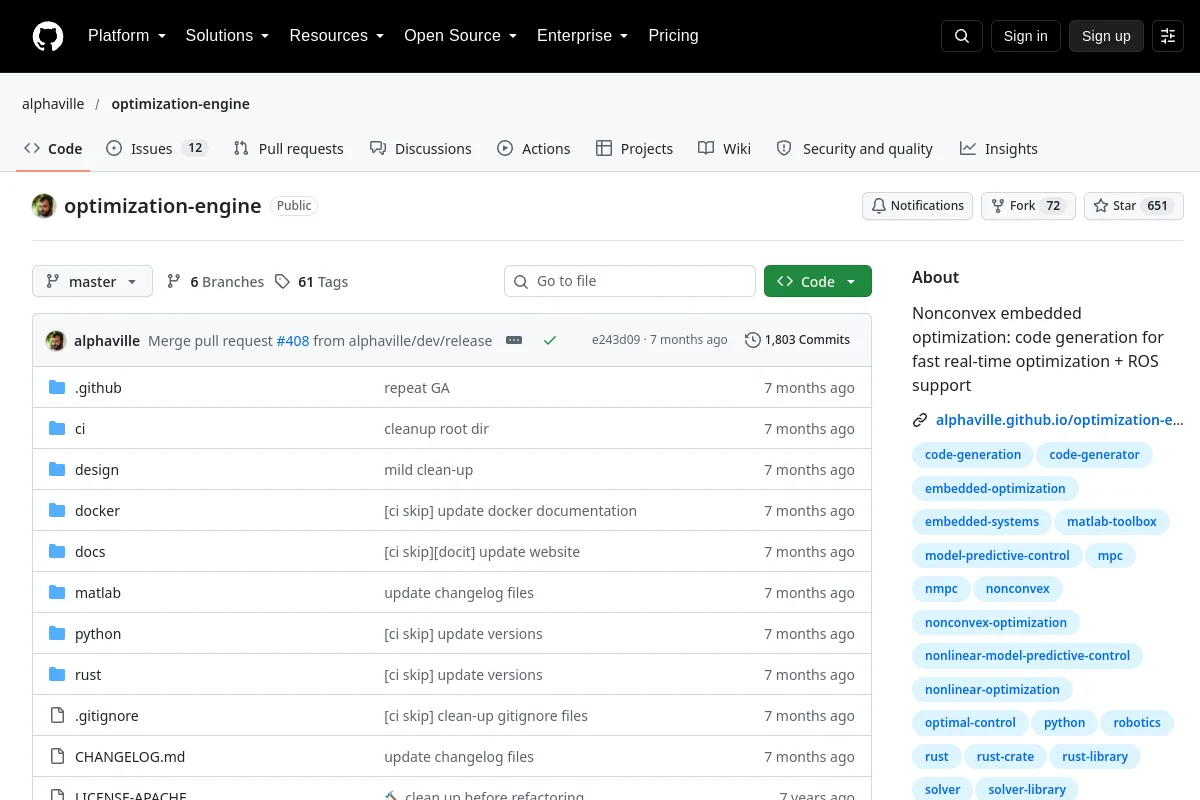 Repository
 Research
Code generation for nonconvex embedded optimization with ROS support.
Motion planning & control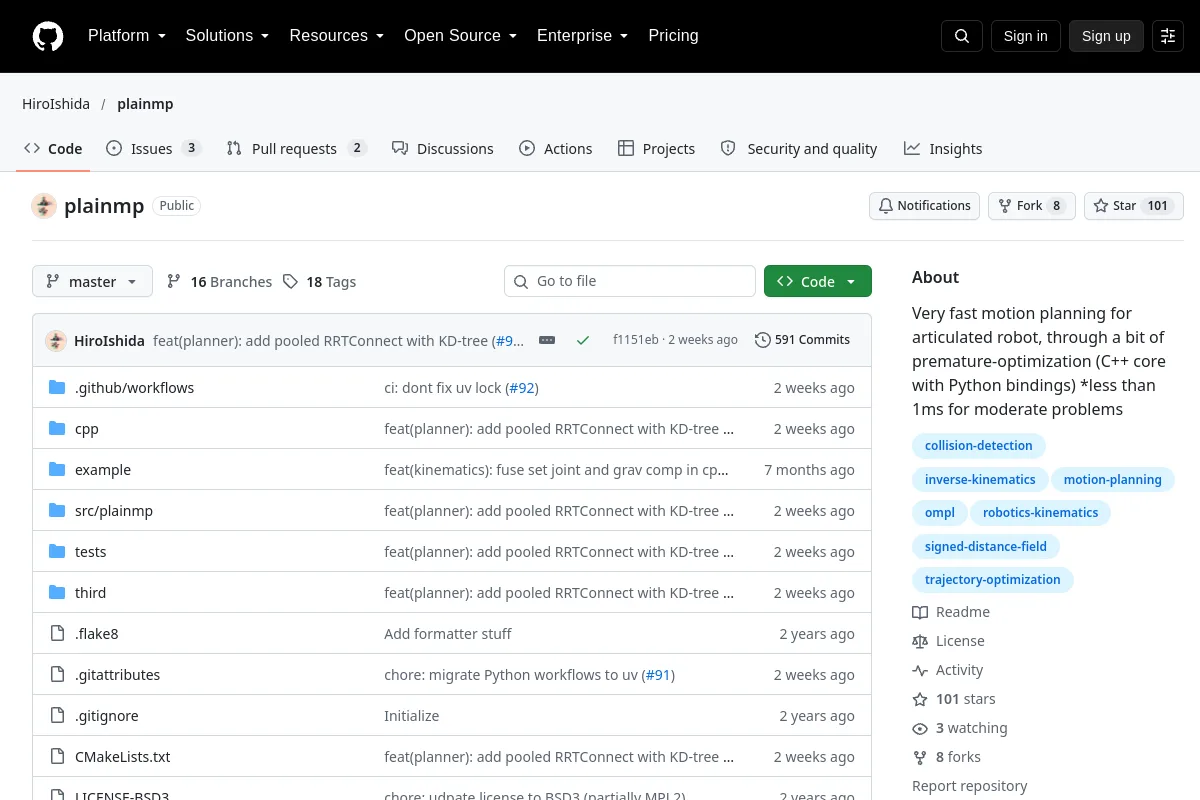 Repository
 Research
Very fast motion planning for articulated robot, through a bit of premature-optimization (C++ core with Python bindings) *less than 1ms for moderate problems
Motion planning & control Repository
 Repository
 Research
RAISIM physics simulation resources for robotics and AI research.
Motion planning & control Repository
 Research
C++ reinforcement-learning library for prediction and control.
Motion planning & control Repository
 Research
Examples and material on robot kinematics, dynamics, control and learning.
Motion planning & control Repository
 Research
A Kinova Gen3 ball-balancing project using SAC in MATLAB and Simulink.
Motion planning & control Repository
 Research
Quadrotor control framework developed by the Robotics and Perception Group
Motion planning & control Repository
 Research
ROS and OpenRTM controller software for the Nextage dual-arm robot.
Motion planning & control Repository
 Research
C++ framework for evolutionary computation, including evolutionary-robotics research.
Motion planning & control Repository
 Research
Motion-planning infrastructure for industrial robot applications.
Motion planning & controlSELECTION NOTES
Check robot models, collision representations, timing and control interfaces. A feasible geometric path still needs dynamic and hardware-level validation before execution.
Know a resource that belongs here?