 Repository
 Research
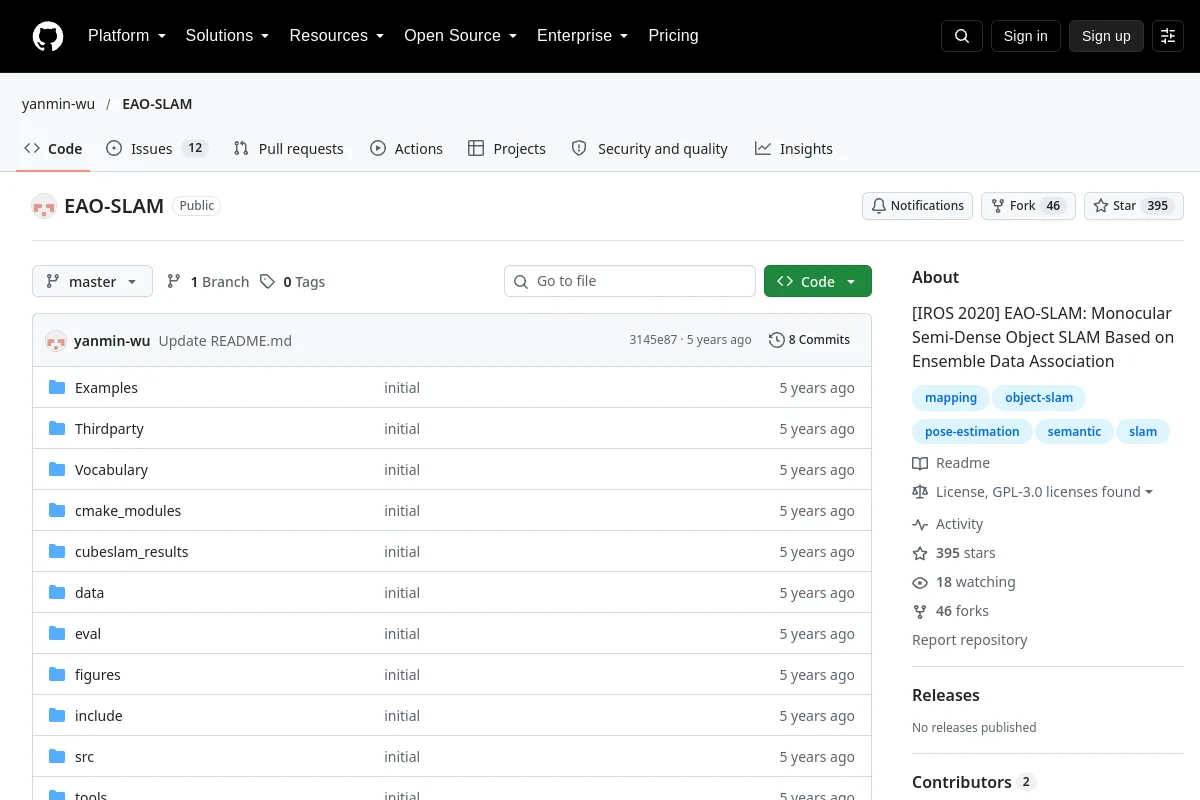
EAO-SLAM · yanmin-wu
EAO-SLAM: Monocular Semi-Dense Object SLAM Based on Ensemble Data Association
Navigation & SLAMTHE EMBODIED AI DIRECTORY
Explore mapping, localization, odometry and navigation software for autonomous robots.
Repository
Research
EAO-SLAM: Monocular Semi-Dense Object SLAM Based on Ensemble Data Association
Navigation & SLAM Repository
 Research
Implementation for learning a mapping from urban images that contain dynamic objects to static realistic images suitable for SLAM
Navigation & SLAM Repository
 Research
Sensor fusion architecture for robot state estimation, localization and mapping.
Navigation & SLAM Repository
 Research
This is the official implementation of the voxel-based humanoid locomotion in "Gallant: Voxel Grid-based Humanoid Locomotion and Local-navigation across 3D Constrained Terrains"
Navigation & SLAM Repository
 Research
Geometry-Aware Learning of Maps for Camera Localization (CVPR2018)
Navigation & SLAM Repository
 Research
Habitat-GS: A High-Fidelity Navigation Simulator with Dynamic Gaussian Splatting
Navigation & SLAM Repository
 Research
AUTONOMOUS ROBOT NAVIGATION USING ROS Clearpath Husky A200 robot with Gazebo and RViz simulations using different SLAM and Path Planning algorithms. 360 degrees laser scan with two SICK LMS511…
Navigation & SLAM Repository
 Research
Code for LGX (Language Guided Exploration). We use LLMs to perform embodied robot navigation in a zero-shot manner.
Navigation & SLAM Repository
 Repository
 Repository
 Research
Learning World Transition Model for Socially Aware Robot Navigation
Navigation & SLAM Repository
 Research
A Modular Optimization framework for Localization and mApping (MOLA)
Navigation & SLAM Repository
 Research
EMKG: multimodal memory and retrieval for open-world object-goal navigation in dynamic environments.
Navigation & SLAM Repository
 Research
Educational Python implementation of pose-graph optimization.
Navigation & SLAM Repository
 Research
Real time Nav2 parameter tuning GUI for ROS2, no kill or relaunch needed
Navigation & SLAM Repository
 Research
Nav-R1: Reasoning and Navigation in Embodied Scenes
Navigation & SLAM Repository
 Research
Official implementation of "NavRAG: Generating User Demand Instructions for Embodied Navigation through Retrieval-Augmented LLM" (ACL'25 Findings)
Navigation & SLAM Repository
 Research
ROS global and local motion planning for mobile robots.
Navigation & SLAM Repository
 Repository
 Research
A ROS integration of ORB-SLAM2.
Navigation & SLAM Repository
 Research
A semantic visual SLAM implementation combining object detection, motion analysis and OctoMap mapping.
Navigation & SLAM Repository
 Research
Pop-up SLAM: Semantic Monocular Plane SLAM for Low-texture Environments
Navigation & SLAM Repository
 Research
Sampling based rewiring approaches to solve motion planning problems for a robot with dynamic obstacles
Navigation & SLAM Repository
 Research
A historical collection of SLAM research references, maintained through its 2021 edition.
Navigation & SLAMSELECTION NOTES
Match sensors, coordinate frames and localization assumptions to the deployment environment. Mapping, pose estimation, path planning and obstacle avoidance serve different parts of the navigation stack.
Know a resource that belongs here?