 Repository
 Research
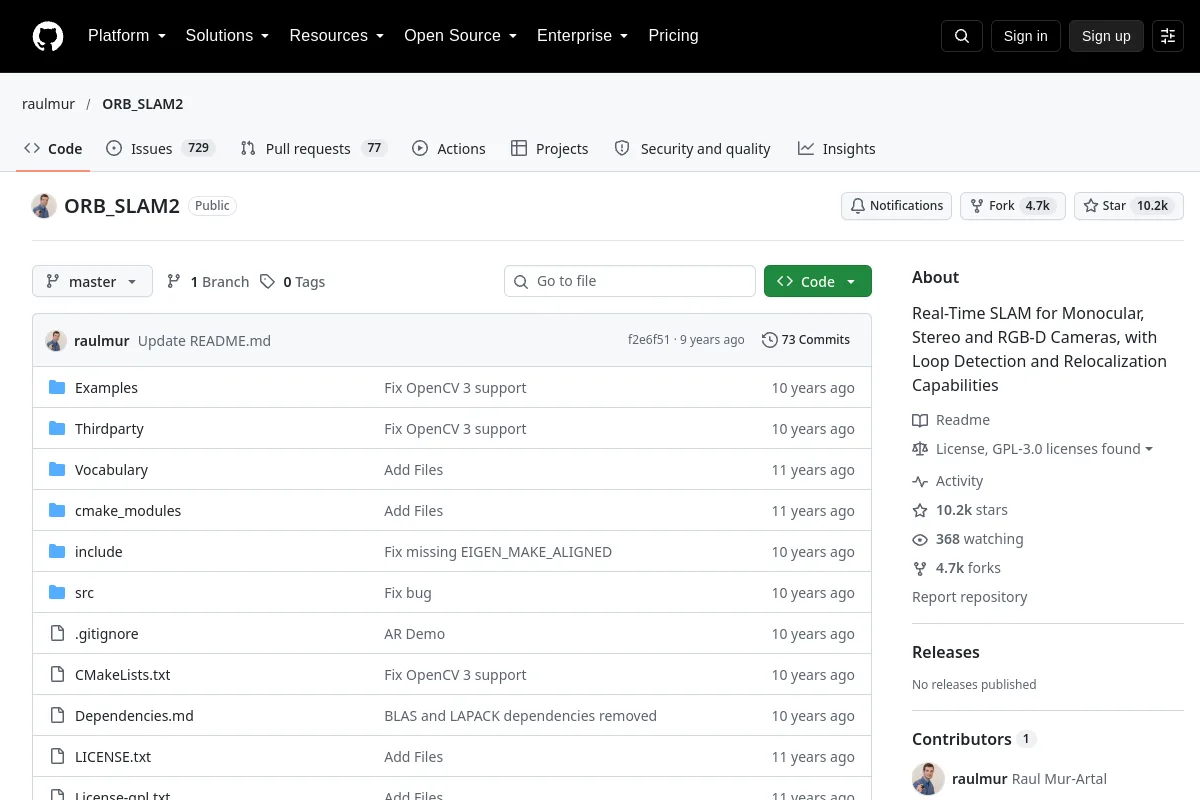
ORB SLAM2 · raulmur
Visual SLAM for monocular, stereo, and RGB-D cameras.
Navigation & SLAM
Software / Research
A semantic visual SLAM implementation combining object detection, motion analysis and OctoMap mapping.
A semantic visual SLAM implementation combining object detection, motion analysis and OctoMap mapping.
Publisher purpose: 动态语义SLAM 目标检测+VSLAM+光流/多视角几何动态物体检测+octomap地图+目标数据库
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
Visual SLAM for monocular, stereo, and RGB-D cameras.
Navigation & SLAM Repository
 Repository
 Research
Collection of robot vision, SLAM and autonomous driving learning resources.
Courses & documentation