 Repository
 Open source
Search TTA RL VLN · marmotlab
Search-TTA research on multimodal test-time adaptation for visual search.
Navigation & SLAMTHE EMBODIED AI DIRECTORY
Explore mapping, localization, odometry and navigation software for autonomous robots.
Repository
Open source
Search-TTA research on multimodal test-time adaptation for visual search.
Navigation & SLAM Repository
 Open source
SG-Nav: Online 3D Scene Graph Prompting for LLM-based Zero-shot Object Navigation
Navigation & SLAM Repository
 Open source
SimpleNav: A simple, unified, reproducible, and extensible framework for navigation VLA research.
Navigation & SLAM Repository
 Open source
Official implementation for "SocialNav: Training Human-Inspired Foundation Model for Socially-Aware Embodied Navigation"
Navigation & SLAM Repository
 Open source
SplaTAM: Splat, Track & Map 3D Gaussians for Dense RGB-D SLAM (CVPR 2024)
Navigation & SLAM Repository
 Open source
The official Implementation of "Structure PLP-SLAM: Efficient Sparse Mapping and Localization using Point, Line and Plane for Monocular, RGB-D and Stereo Cameras"
Navigation & SLAM Repository
 Open source
📖[IEEE Sensors Journal (JSEN) ] SuperVINS: A Real-Time Visual-Inertial SLAM Framework for Challenging Imaging Conditions (integrated deep learning features)
Navigation & SLAM Repository
 Open source
Multi-robot control simulation environmrnt build on top on Mobile Robotics Simulation Toolbox, implemented 1)some algorithm for formation control 2)mapping, localization and SLAM based on Kalman…
Navigation & SLAM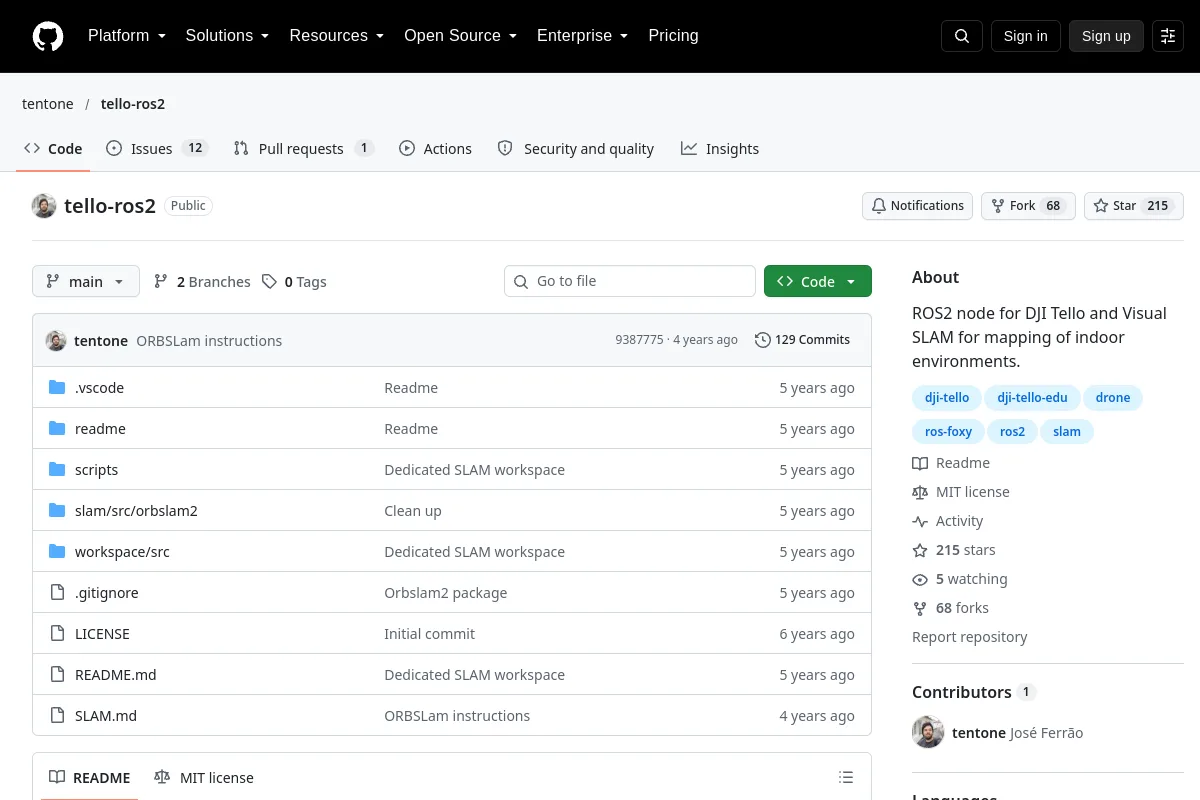 Repository
 Open source
ROS2 node for DJI Tello and Visual SLAM for mapping of indoor environments.
Navigation & SLAM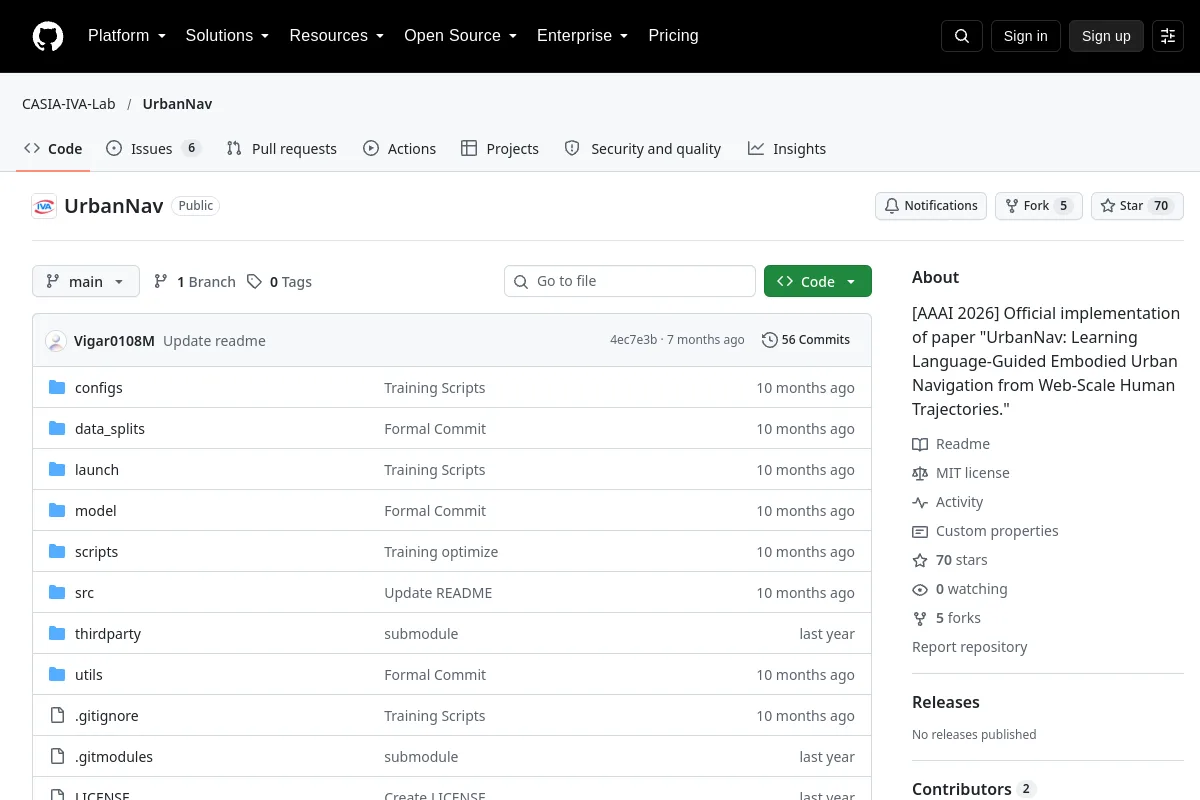 Repository
 Open source
Official implementation of paper "UrbanNav: Learning Language-Guided Embodied Urban Navigation from Web-Scale Human Trajectories."
Navigation & SLAM Repository
 Open source
VINS-Fusion, VINS-Fisheye, OpenVINS, EnVIO, ROVIO, S-MSCKF, ORB-SLAM2, NVIDIA Elbrus application of different sets of cameras and imu on different board including desktop and Jetson boards
Navigation & SLAM Repository
 Open source
Voxel mapping library for truncated and Euclidean signed distance fields.
Navigation & SLAM Repository
 Open source
A navigation system for outdoor robotics in rough uneven terrains.
Navigation & SLAM Repository
 Open source
Multi-resolution 3D occupancy mapping from multiple sensors.
Navigation & SLAM Repository
 Open source
Mapping, localization and using the navigation stack with ROS2 Jazzy
Navigation & SLAM Repository
 Open source
Unity robotic simulation tools with ROS integration.
Navigation & SLAM Website
SELECTION NOTES
Match sensors, coordinate frames and localization assumptions to the deployment environment. Mapping, pose estimation, path planning and obstacle avoidance serve different parts of the navigation stack.
Know a resource that belongs here?