 Repository
THE EMBODIED AI DIRECTORY
Courses & documentation
Explore robotics learning materials and publisher-maintained documentation.
Repository
 Repository
 Repository
 Open source
slambook-en · gaoxiang12
The English version of 14 lectures on visual SLAM.
Courses & documentation Repository
 Open source
slambook · gaoxiang12
Examples and learning materials accompanying lectures on visual SLAM.
Courses & documentation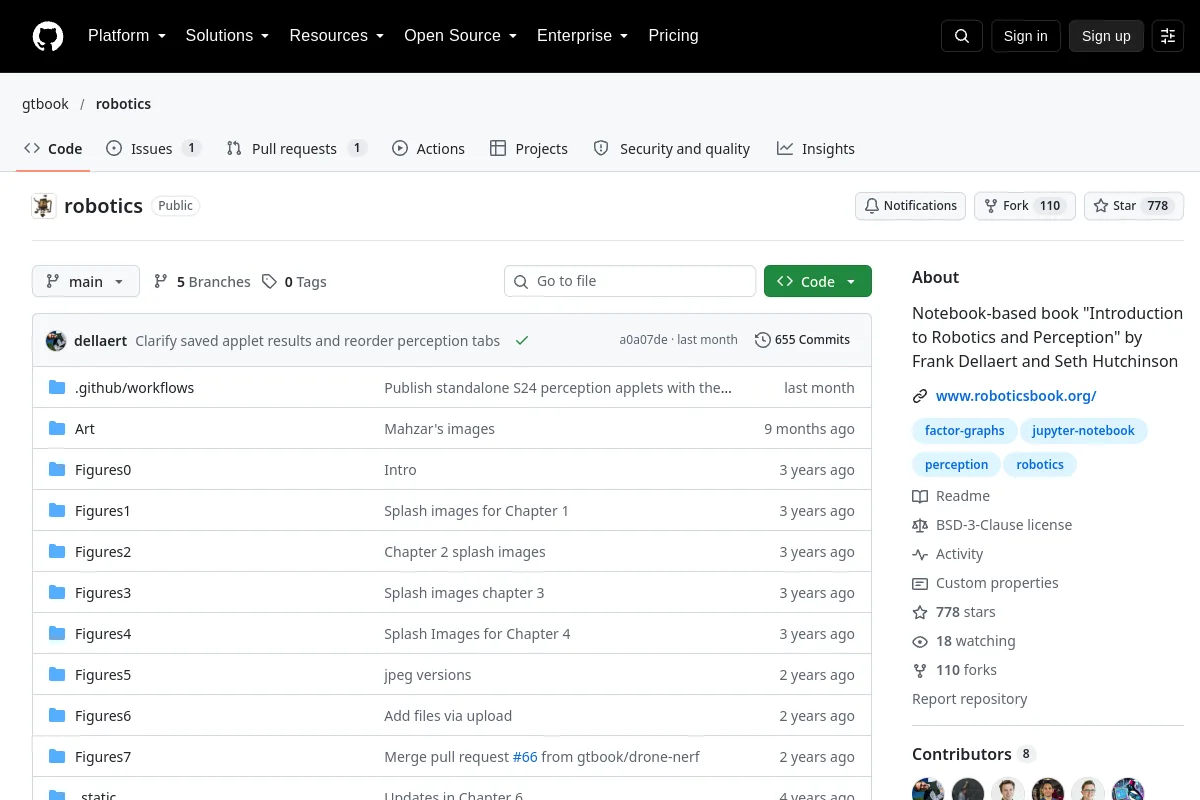 Repository
 Open source
robotics · gtbook
Notebook-based book "Introduction to Robotics and Perception" by Frank Dellaert and Seth Hutchinson
Courses & documentation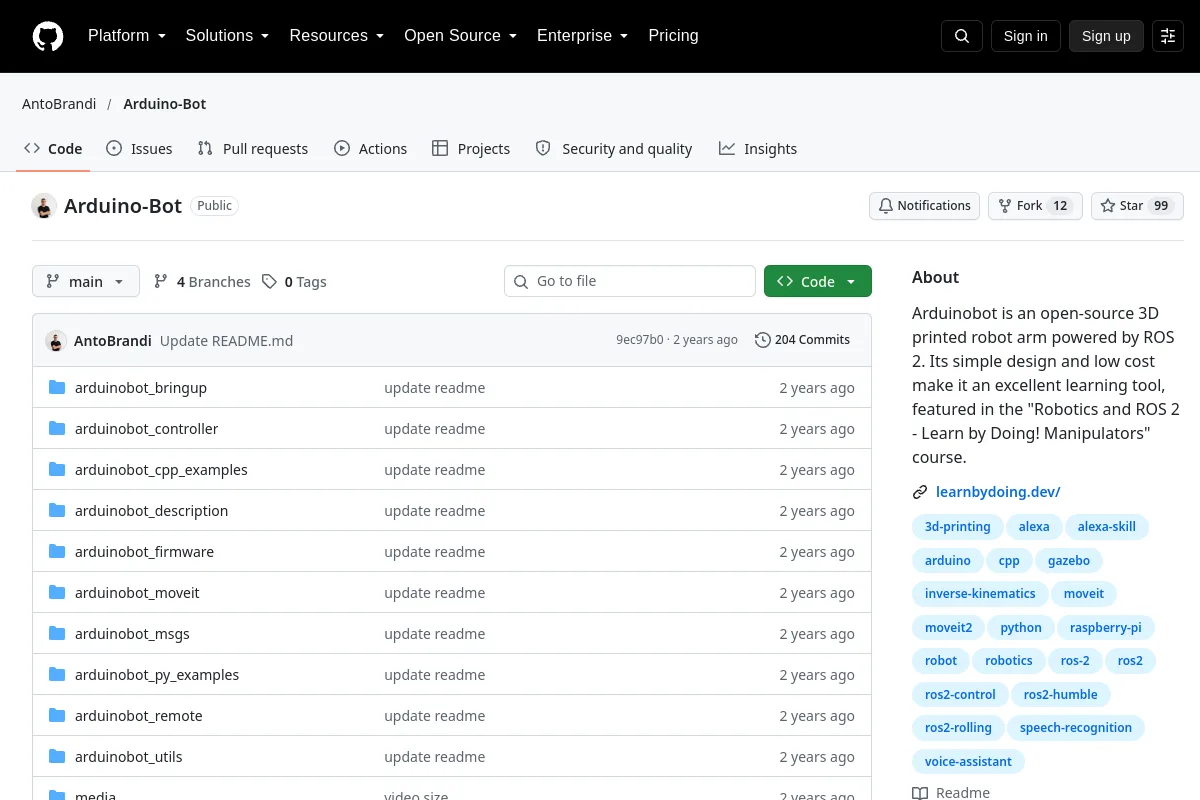 Repository
 Open source
Arduino-Bot · AntoBrandi
Arduinobot is an open-source 3D printed robot arm powered by ROS 2. Its simple design and low cost make it an excellent learning tool, featured in the "Robotics and ROS 2 - Learn by Doing!…
Courses & documentation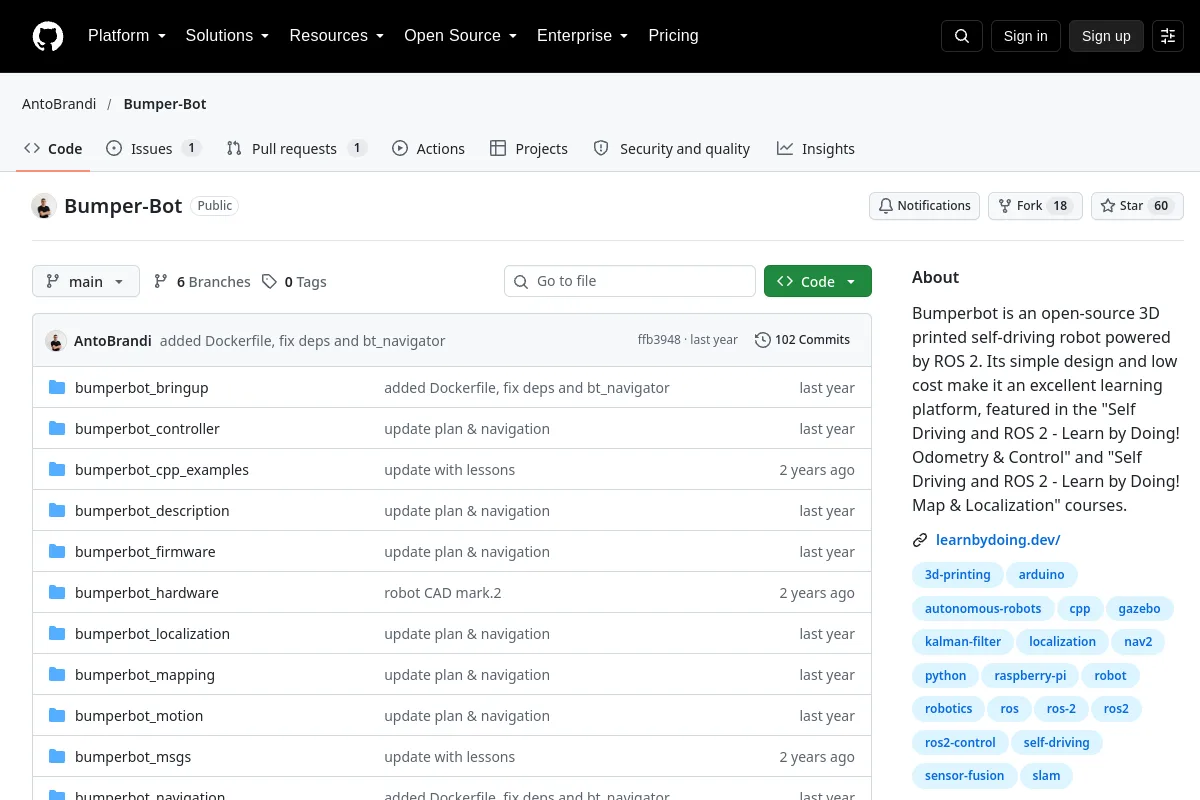 Repository
 Open source
Bumper-Bot · AntoBrandi
Bumperbot is an open-source 3D printed self-driving robot powered by ROS 2. Its simple design and low cost make it an excellent learning platform, featured in the "Self Driving and ROS 2 - Learn…
Courses & documentation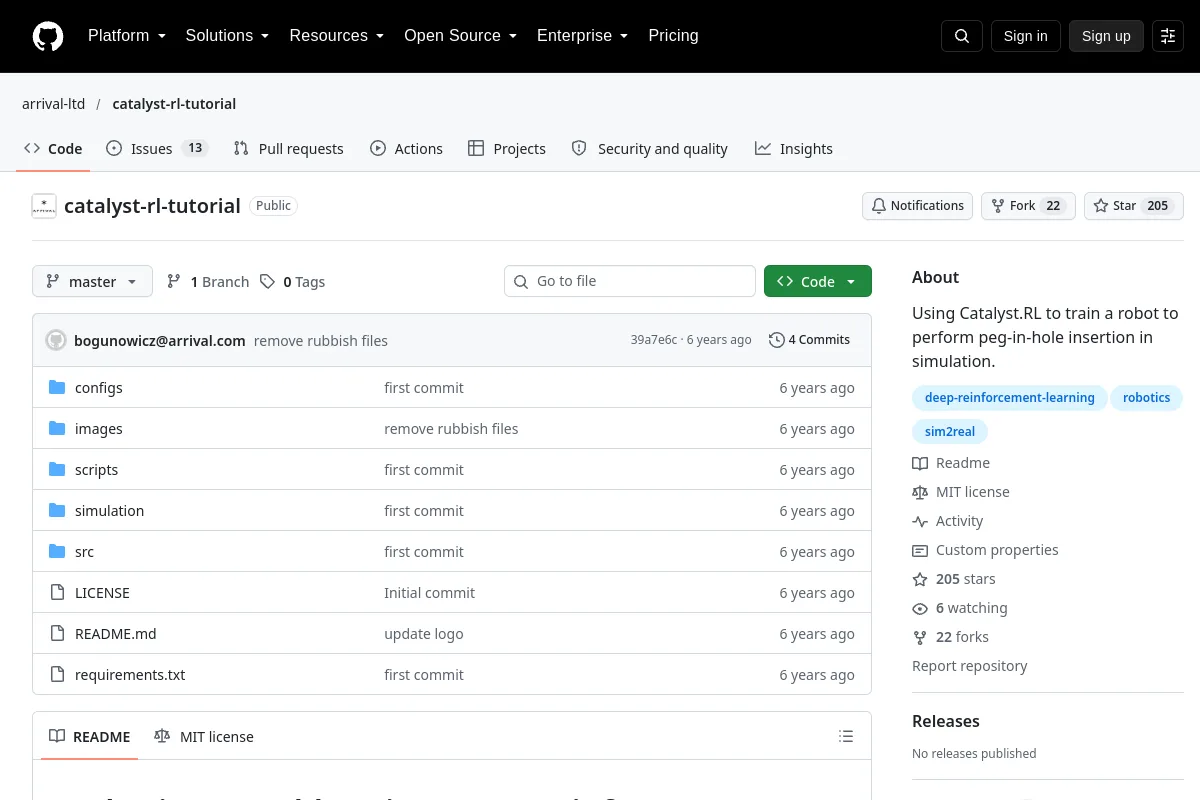 Repository
 Open source
catalyst-rl-tutorial · arrival-ltd
Using Catalyst.RL to train a robot to perform peg-in-hole insertion in simulation.
Courses & documentation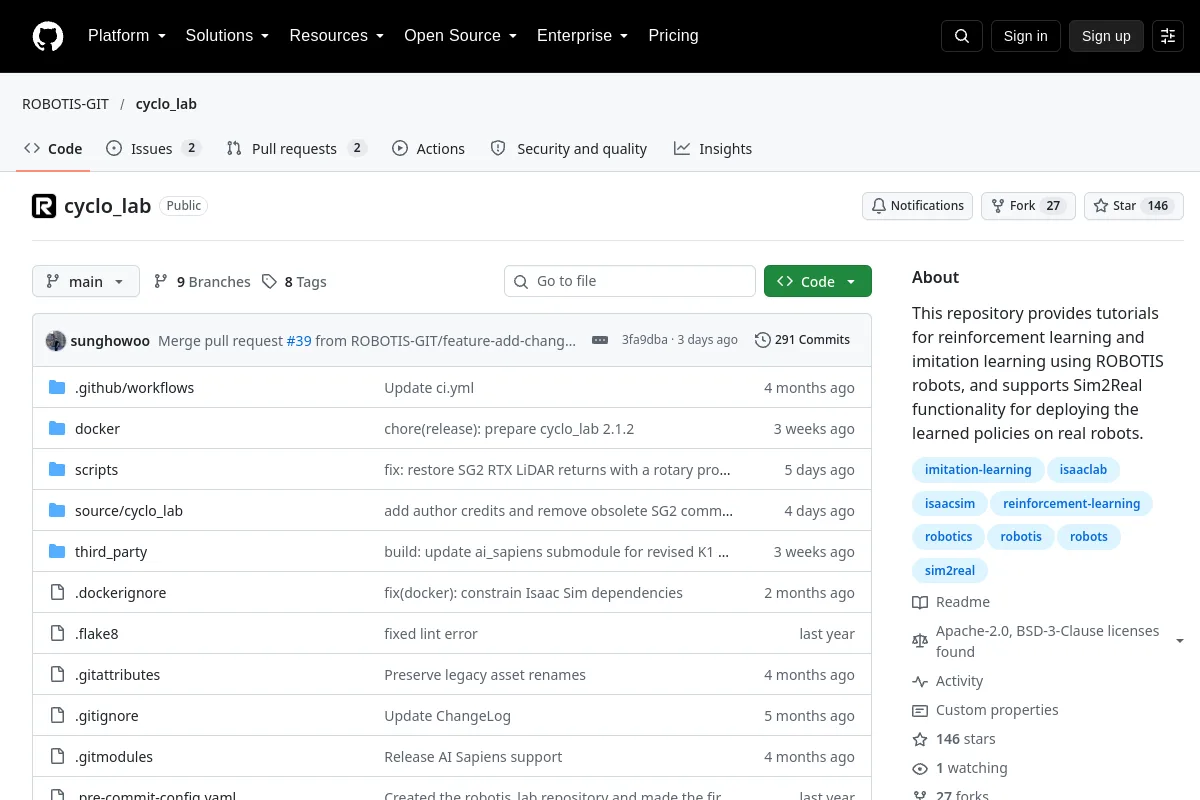 Repository
 Open source
cyclo_lab · ROBOTIS-GIT
This repository provides tutorials for reinforcement learning and imitation learning using ROBOTIS robots, and supports Sim2Real functionality for deploying the learned policies on real robots.
Courses & documentation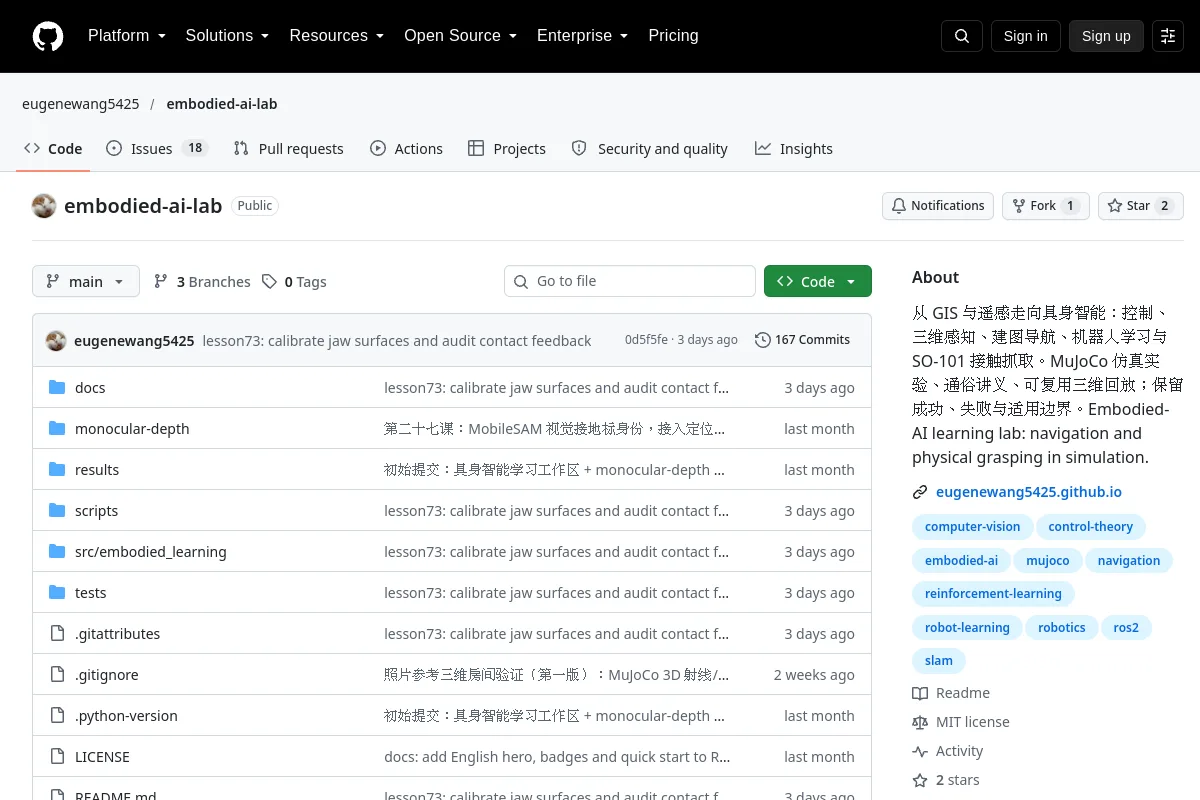 Repository
 Open source
embodied ai lab · eugenewang5425
Learning lab covering control, 3D perception, navigation and simulated grasping.
Courses & documentation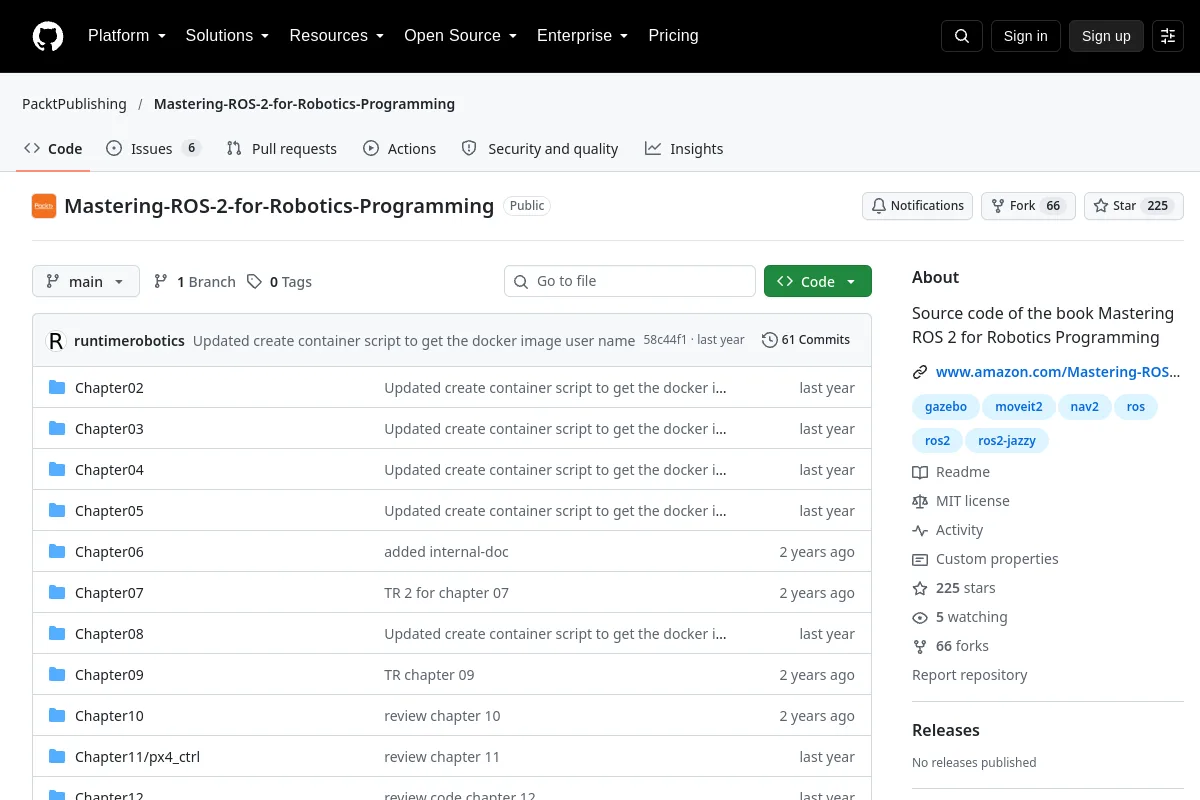 Repository
 Open source
Mastering-ROS-2-for-Robotics-Programming · PacktPublishing
Source code of the book Mastering ROS 2 for Robotics Programming
Courses & documentation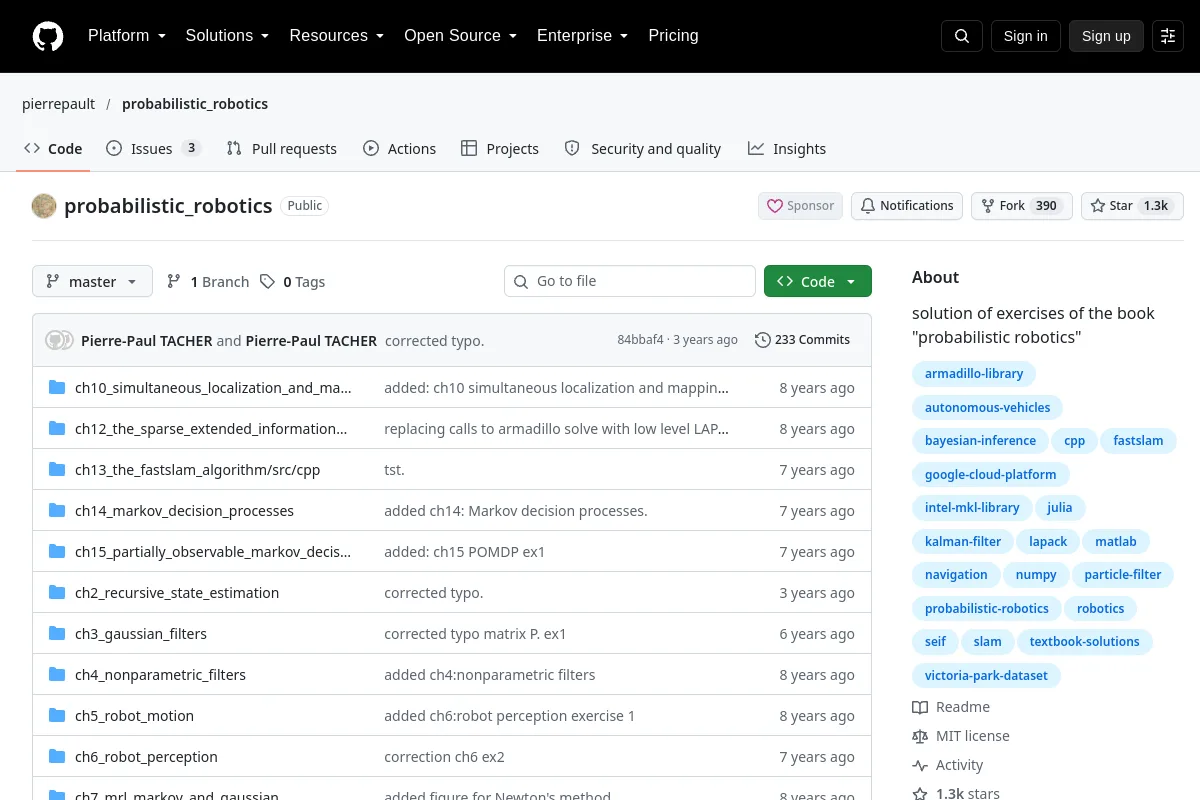 Repository
 Open source
probabilistic_robotics · pierrepault
solution of exercises of the book "probabilistic robotics"
Courses & documentation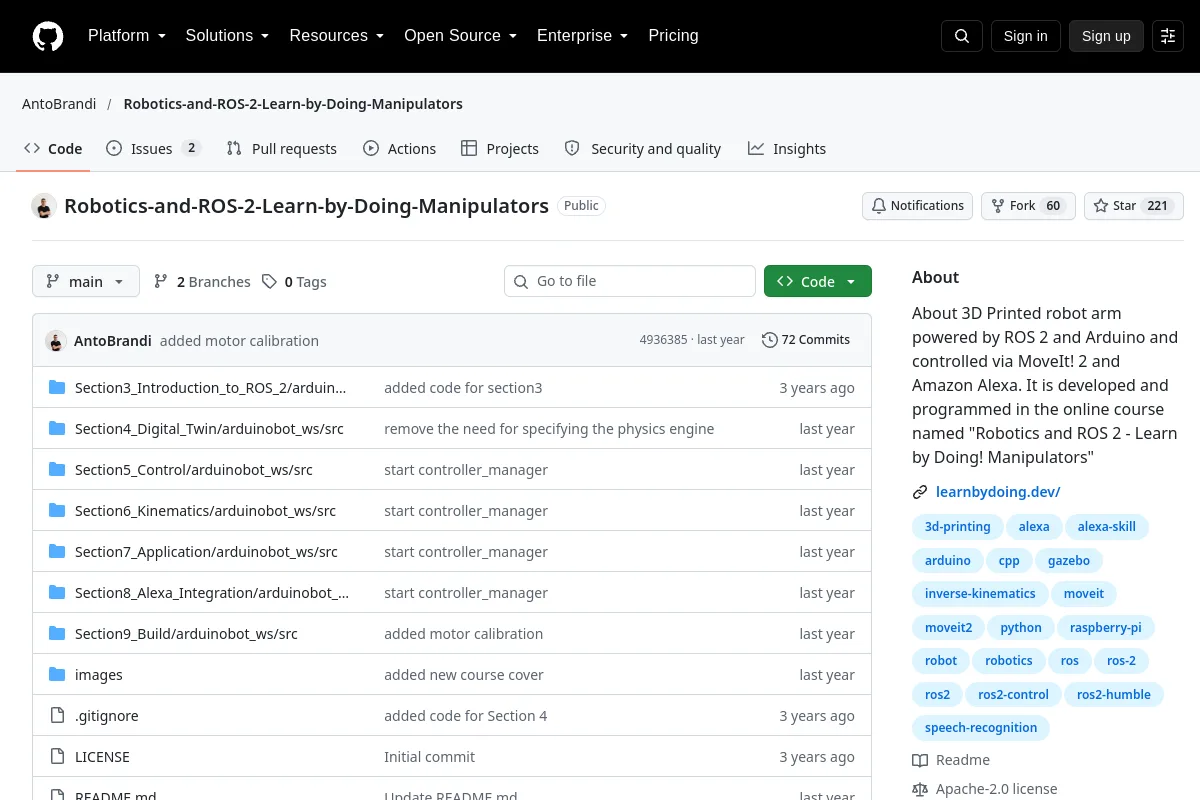 Repository
 Open source
Robotics-and-ROS-2-Learn-by-Doing-Manipulators · AntoBrandi
About 3D Printed robot arm powered by ROS 2 and Arduino and controlled via MoveIt! 2 and Amazon Alexa. It is developed and programmed in the online course named "Robotics and ROS 2 - Learn by…
Courses & documentation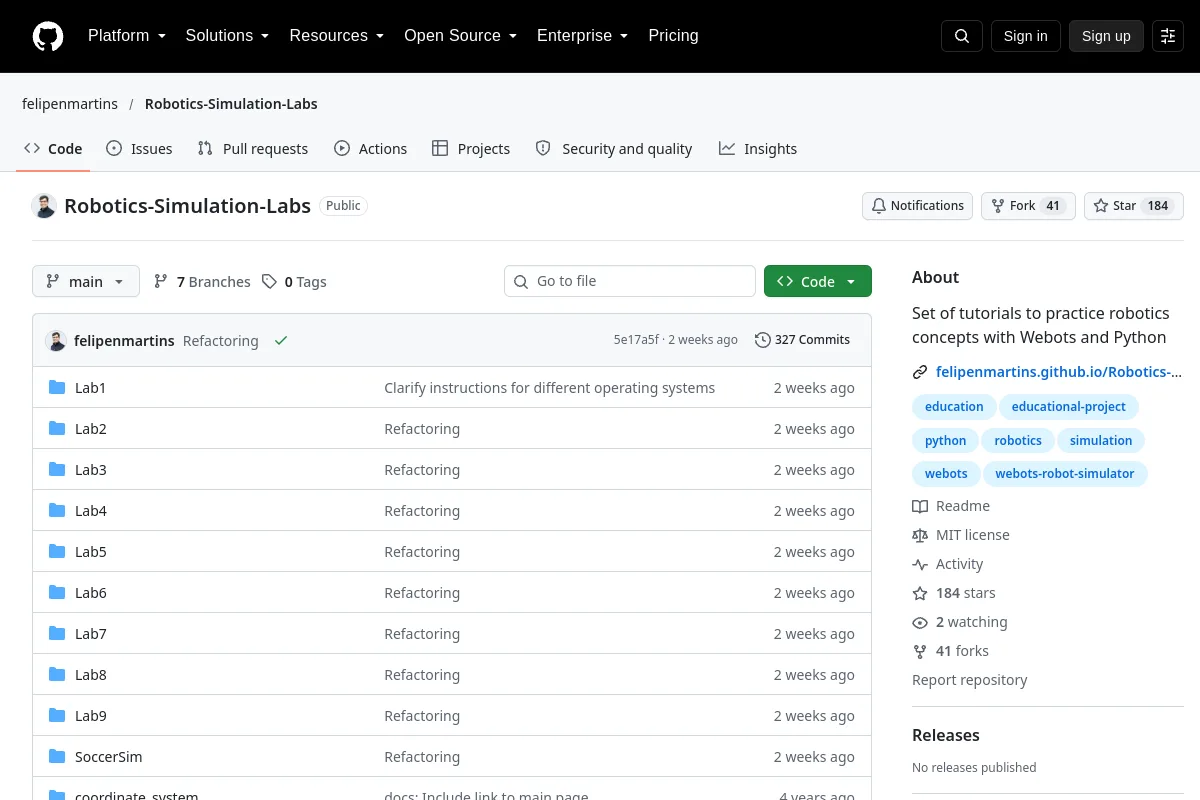 Repository
 Open source
Robotics-Simulation-Labs · felipenmartins
Set of tutorials to practice robotics concepts with Webots and Python
Courses & documentation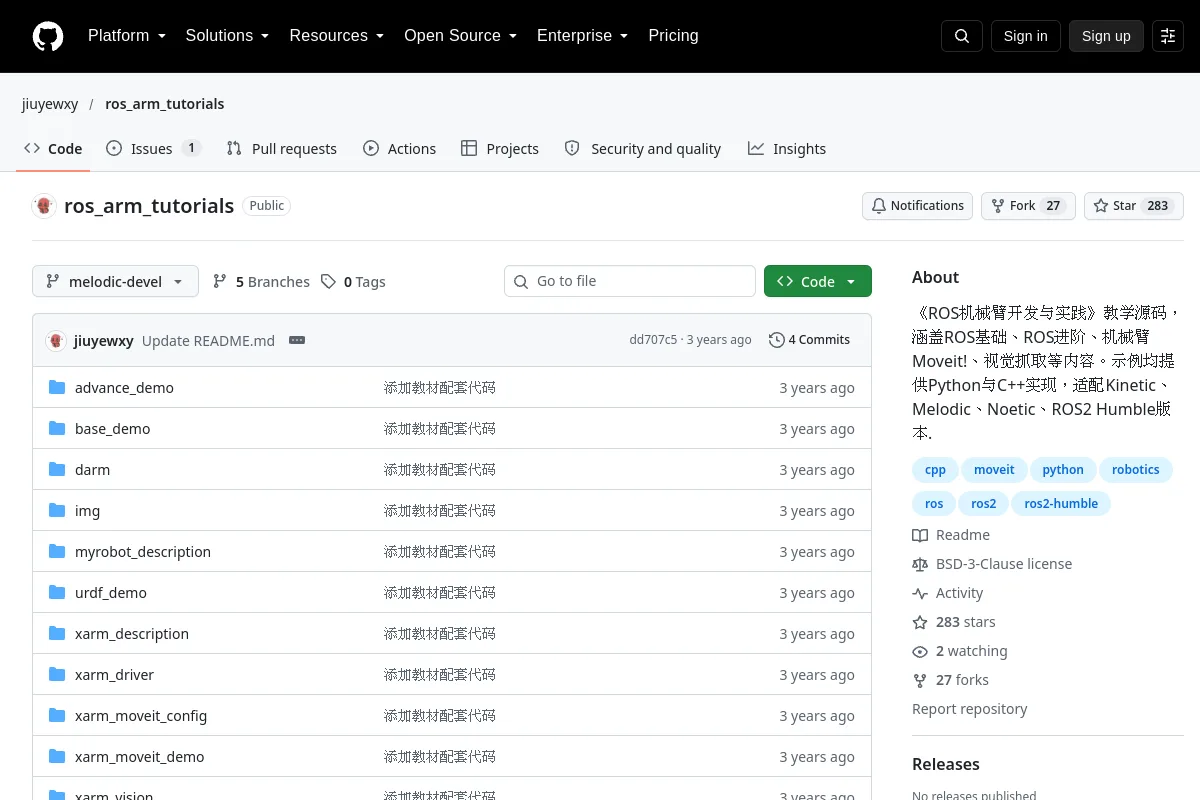 Repository
 Open source
ros_arm_tutorials · jiuyewxy
Python and C++ examples for ROS robot-arm development, MoveIt and visual grasping.
Courses & documentation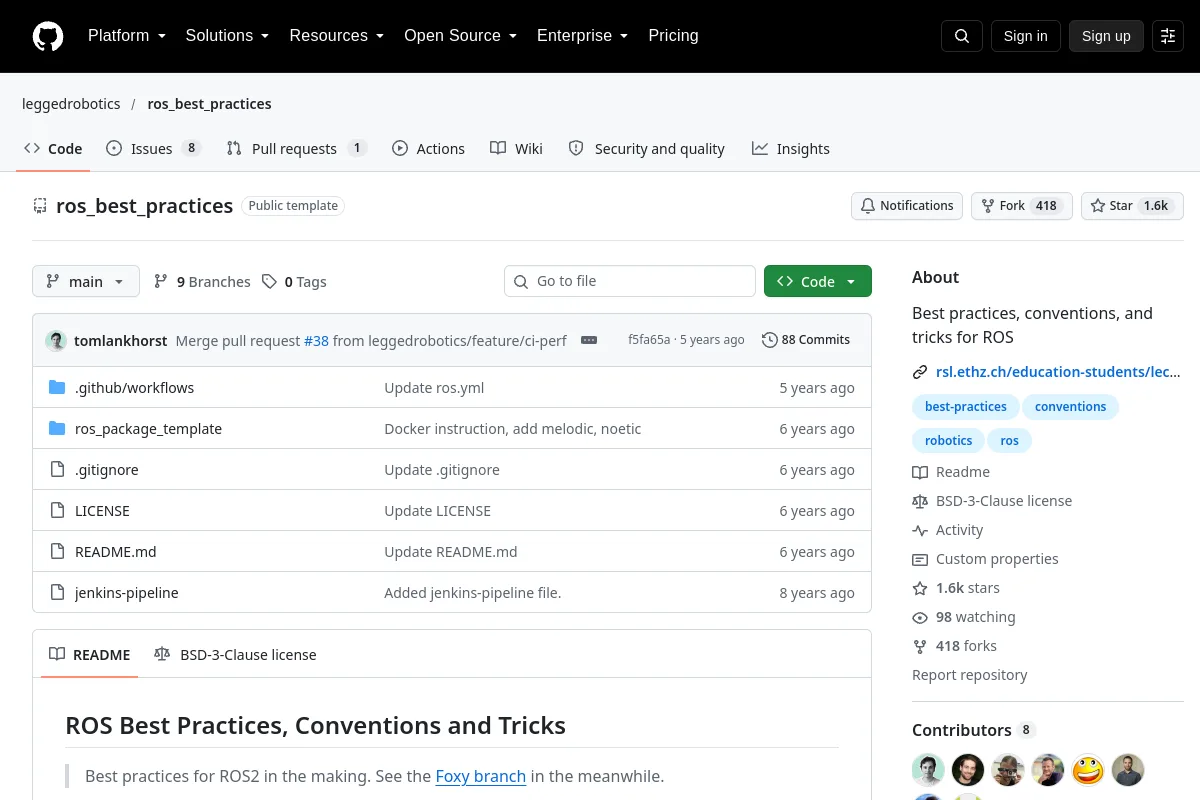 Repository
 Open source
ros_best_practices · leggedrobotics
Best practices, conventions, and tricks for ROS
Courses & documentation Repository
 Open source
ROS · HuangCongQing
Learning notes and C++ examples for the Robot Operating System.
Courses & documentation Repository
 Open source
Self-Driving-and-ROS-2-Learn-by-Doing-Map-Localization · AntoBrandi
Autonomous Mobile Robot developed and programmed in the online course named "Self-Driving and ROS 2 - Learn By Doing! Map & Localization"
Courses & documentation Repository
 Open source
Self-Driving-and-ROS-2-Learn-by-Doing-Odometry-Control · AntoBrandi
Autonomous Mobile Robot developed and programmed in the online course named "Self-Driving and ROS 2 - Learn By Doing! Odometry & Control"
Courses & documentation Repository
 Open source
Self-Driving-and-ROS-2-Learn-by-Doing-Plan-Navigation · AntoBrandi
Autonomous Mobile Robot developed and programmed in the online course named "Self-Driving and ROS 2 - Learn By Doing! Plan & Navigation"
Courses & documentation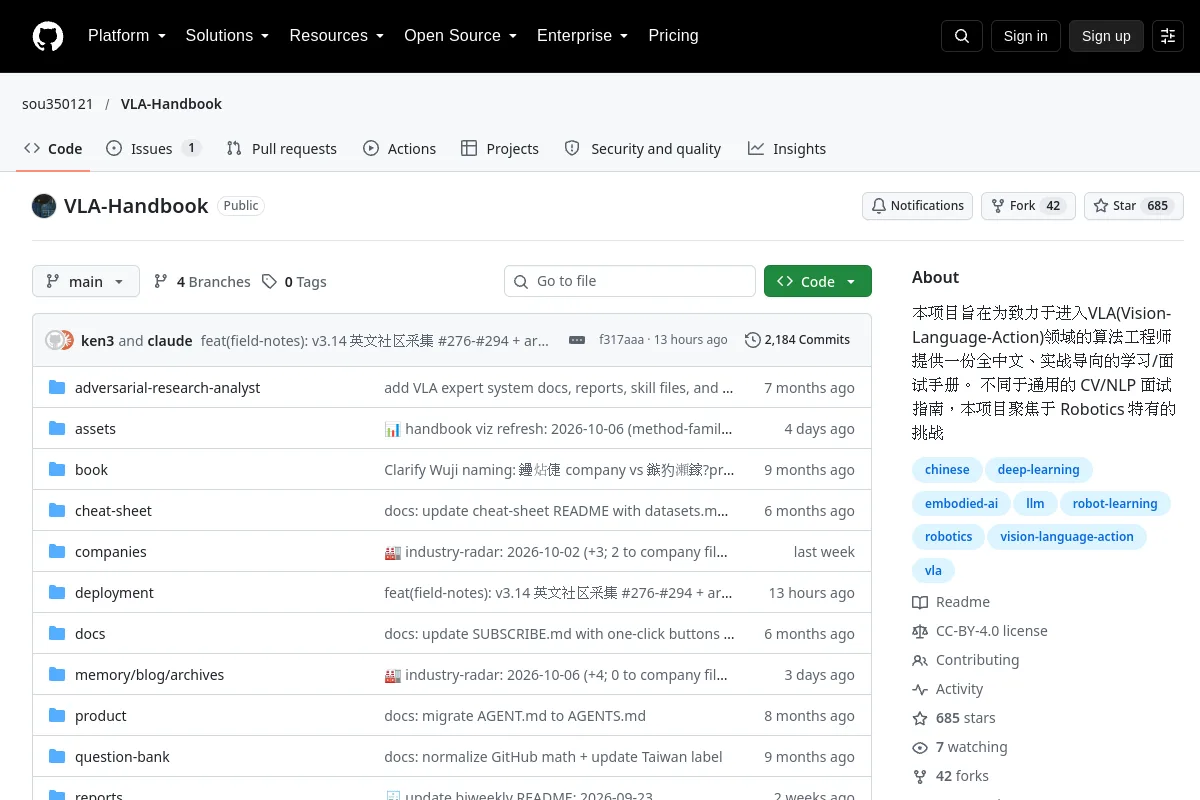 Repository
 Open source
VLA-Handbook · sou350121
A Chinese-language practical handbook focused on vision-language-action models and robotics engineering.
Courses & documentation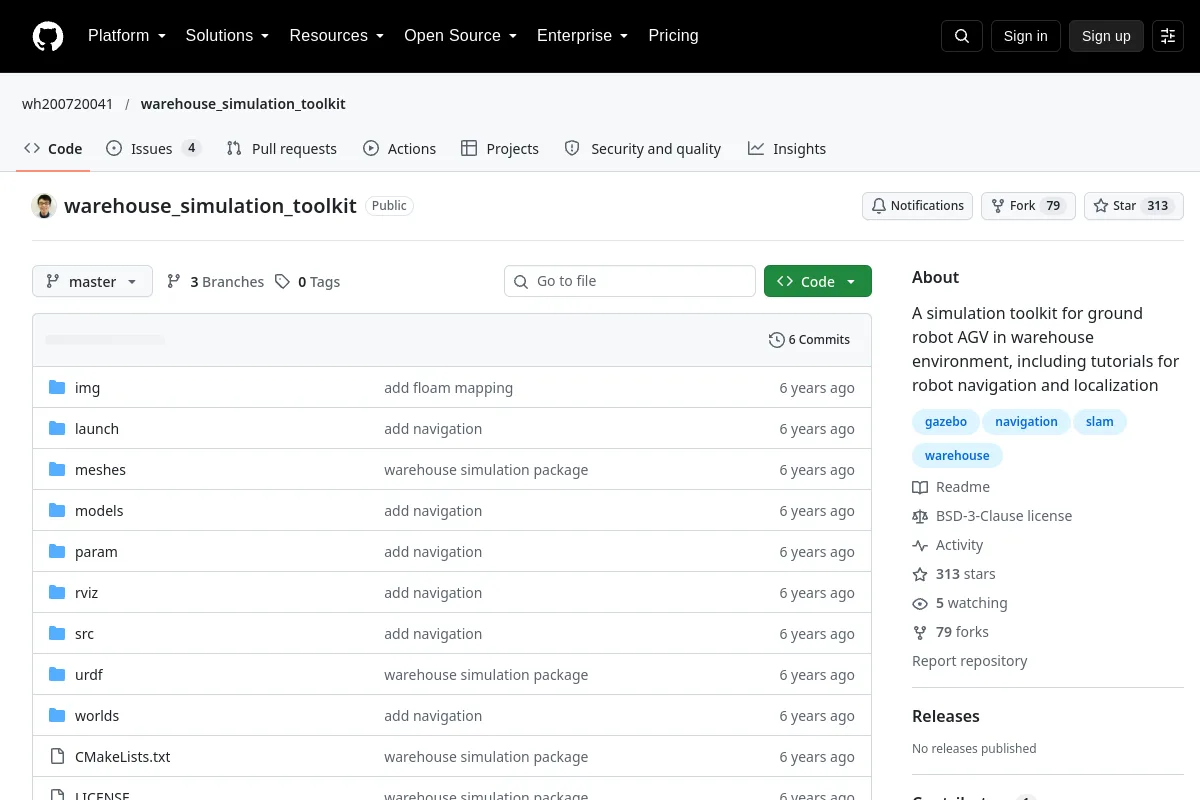 Repository
 Open source
warehouse_simulation_toolkit · wh200720041
A simulation toolkit for ground robot AGV in warehouse environment, including tutorials for robot navigation and localization
Courses & documentationSELECTION NOTES
Choosing courses & documentation
Check prerequisites, supported versions and whether material is conceptual or platform-specific. Use official release documentation when implementing a hardware workflow.
A PLACE FOR YOUR NEXT DISCOVERY
Suggest a resource ↗The ecosystem keeps growing.
Know a resource that belongs here?