 Repository
 Research
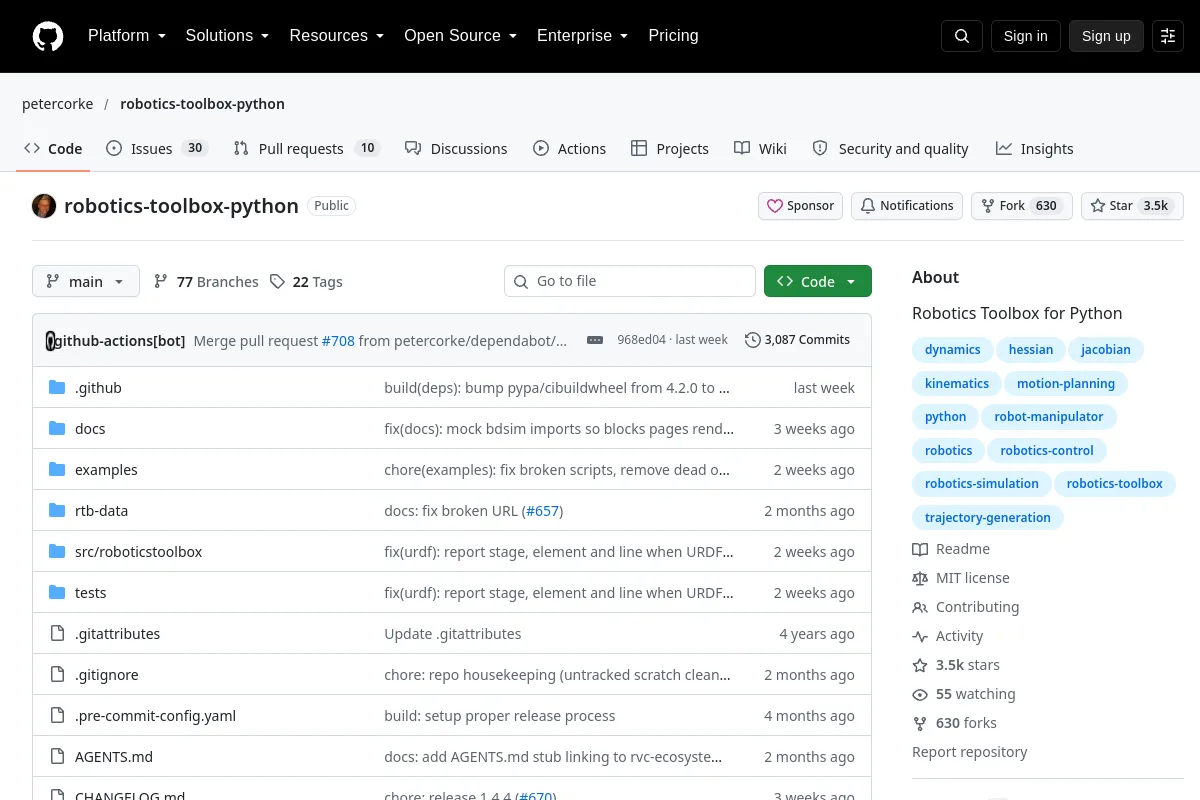
Robotics Toolbox for Python
Python tools and examples for robotics education and algorithm exploration.
Courses & documentation
Research & learning / Open source
Learning lab covering control, 3D perception, navigation and simulated grasping.
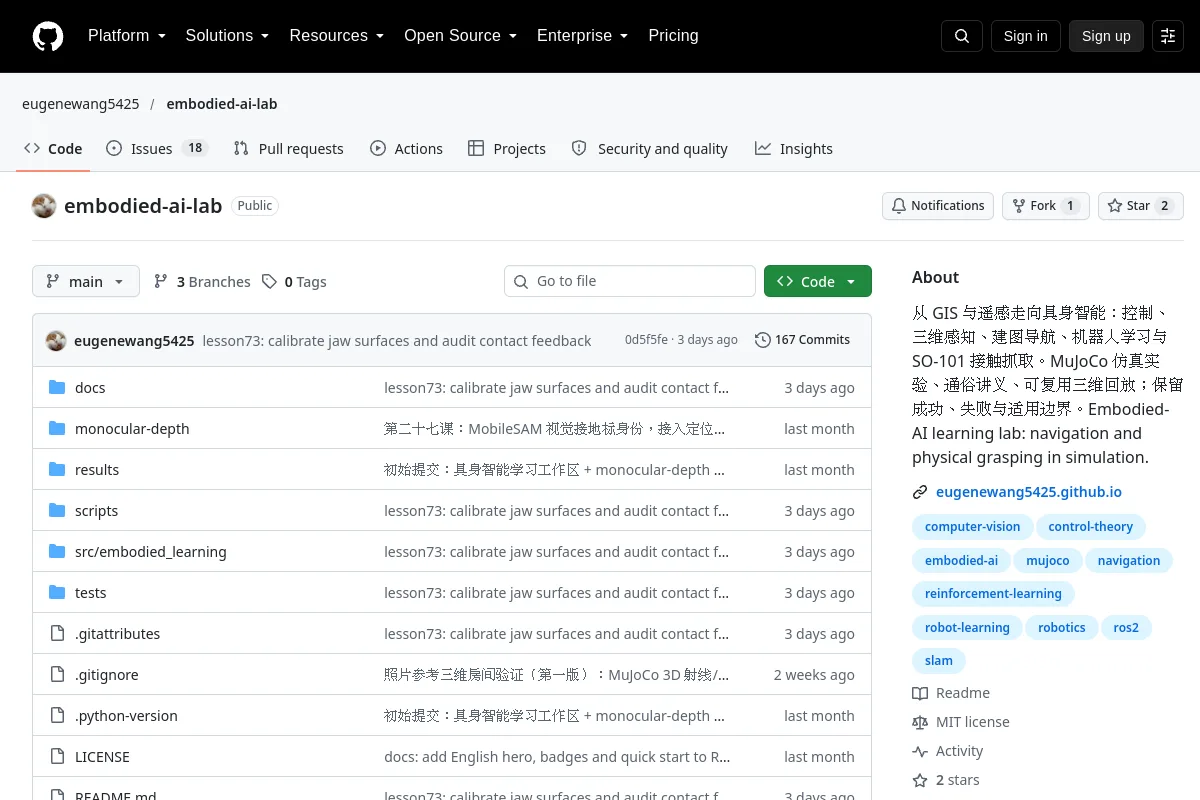
Learning lab covering control, 3D perception, navigation and simulated grasping.
Publisher summary: “从 GIS 与遥感走向具身智能:控制、三维感知、建图导航、机器人学习与 SO-101 接触抓取。MuJoCo 仿真实验、通俗讲义、可复用三维回放;保留成功、失败与适用边界。Embodied-AI learning lab: navigation and physical grasping in simulation.”
Use its repository to inspect the implementation, documentation and supported workflows. This directory record identifies the maintainer, code license and related resources; it does not claim that the project has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
Python tools and examples for robotics education and algorithm exploration.
Courses & documentation Repository
 Repository
 Repository
 Open source
The English version of 14 lectures on visual SLAM.
Courses & documentation Repository
 Research
zenoh-plugin-ros2dds provides a Zenoh plugin and bridge for ROS 2 communication over DDS.
Standards & reference collections Repository
 Research
Embodied AI Lab is a research hub covering VLA, data infrastructure and robotics evaluation.
Standards & reference collections