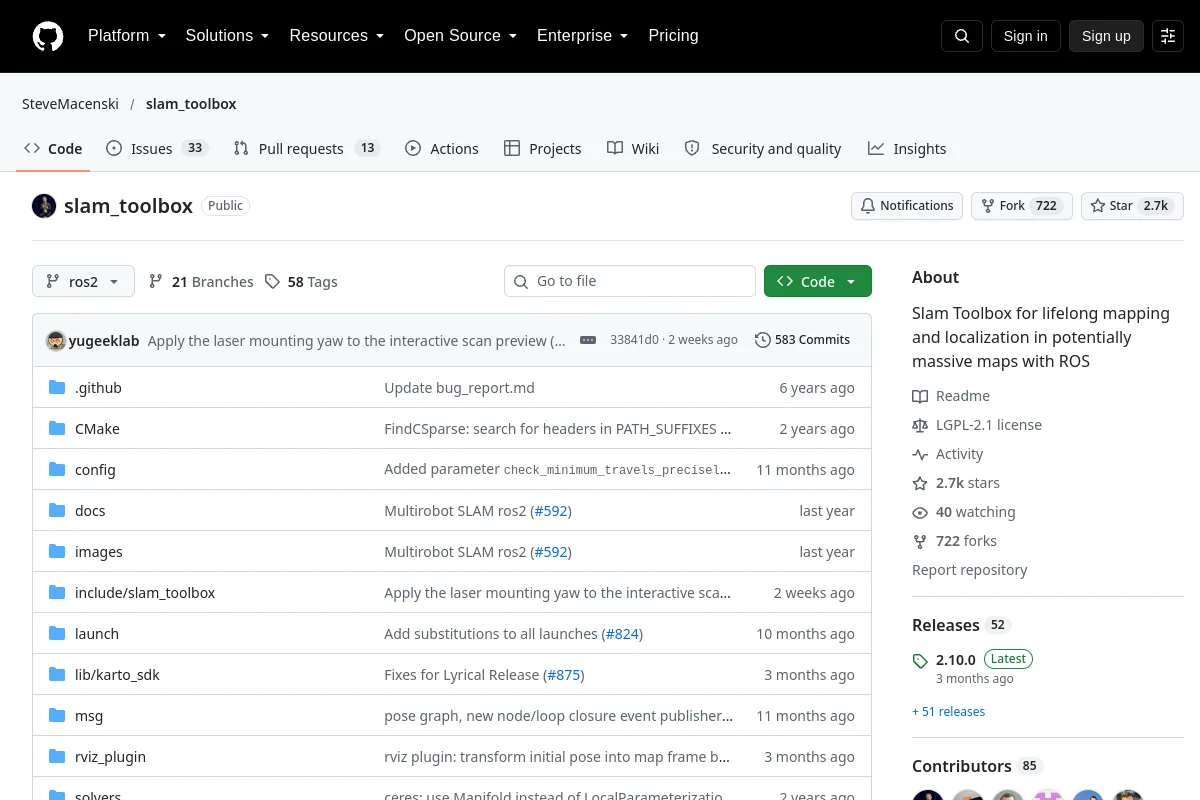
 Repository
 Open source
slam_toolbox
Mapping and localization tools for ROS 2 navigation workflows.
Navigation & SLAM
Research & learning / Open source
Bumperbot is an open-source 3D printed self-driving robot powered by ROS 2. Its simple design and low cost make it an excellent learning platform, featured in the "Self Driving and ROS 2 - Learn…
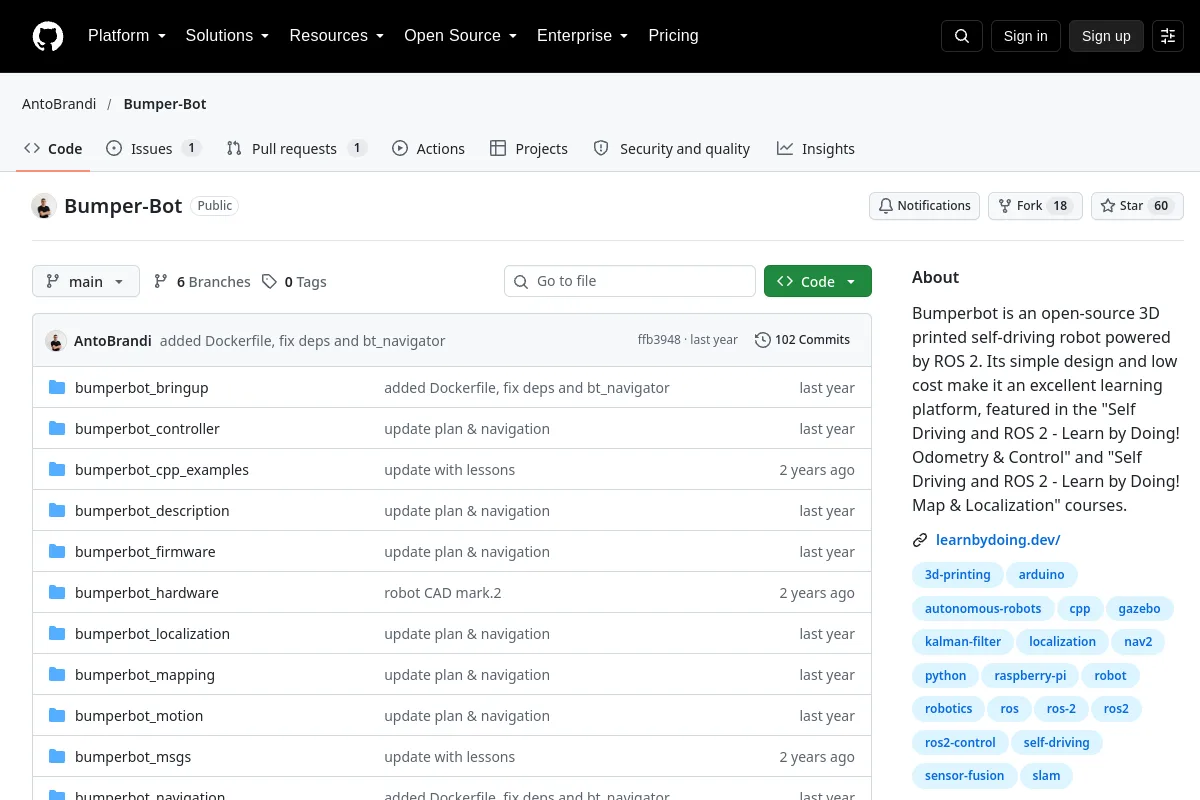
Bumperbot is an open-source 3D printed self-driving robot powered by ROS 2. Its simple design and low cost make it an excellent learning platform, featured in the "Self Driving and ROS 2 - Learn…
Publisher purpose: Bumperbot is an open-source 3D printed self-driving robot powered by ROS 2. Its simple design and low cost make it an excellent learning platform, featured in the "Self Driving and ROS 2 - Learn by Doing! Odometry & Control" and "Self Driving and ROS 2 - Learn by Doing! Map & Localization" courses.
Use the source to explore robotics concepts, examples and references. Source material may be historical; check the applicable version and context.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
Mapping and localization tools for ROS 2 navigation workflows.
Navigation & SLAM