 Repository
 Research
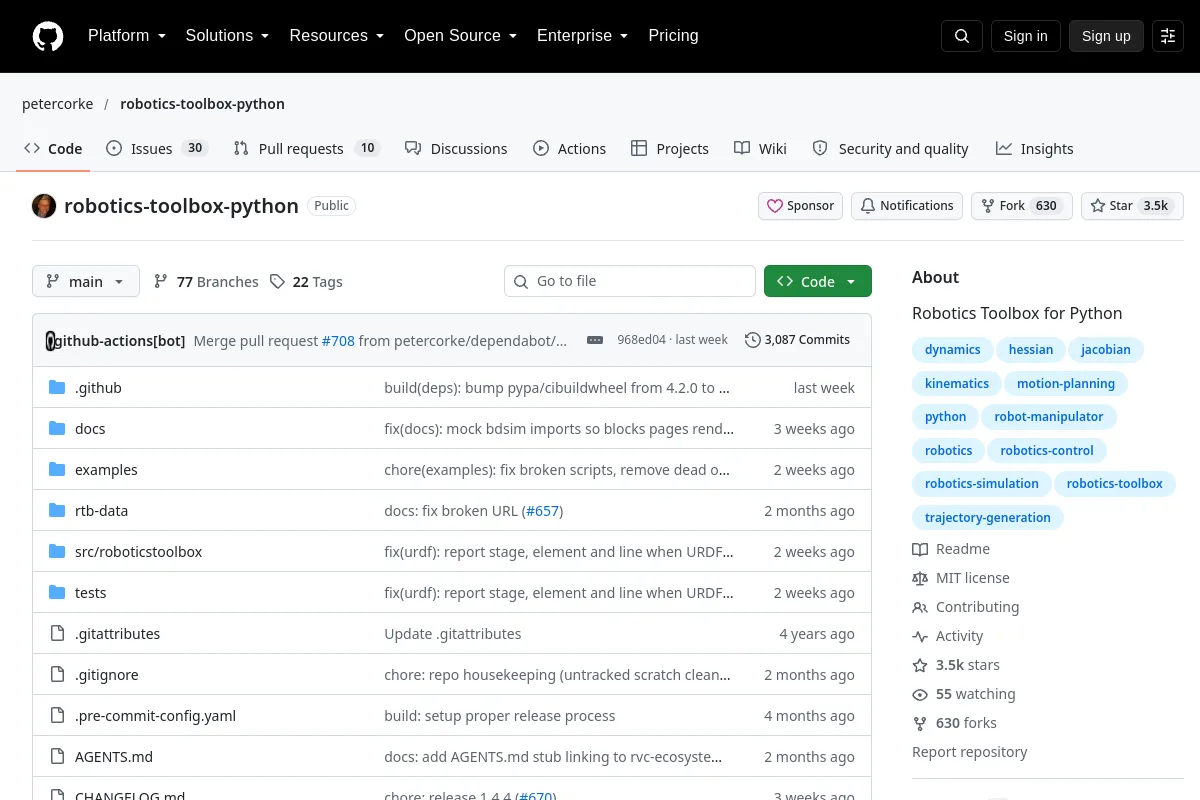
Robotics Toolbox for Python
Python tools and examples for robotics education and algorithm exploration.
Courses & documentation
Research & learning / Open source
Arduinobot is an open-source 3D printed robot arm powered by ROS 2. Its simple design and low cost make it an excellent learning tool, featured in the "Robotics and ROS 2 - Learn by Doing!…
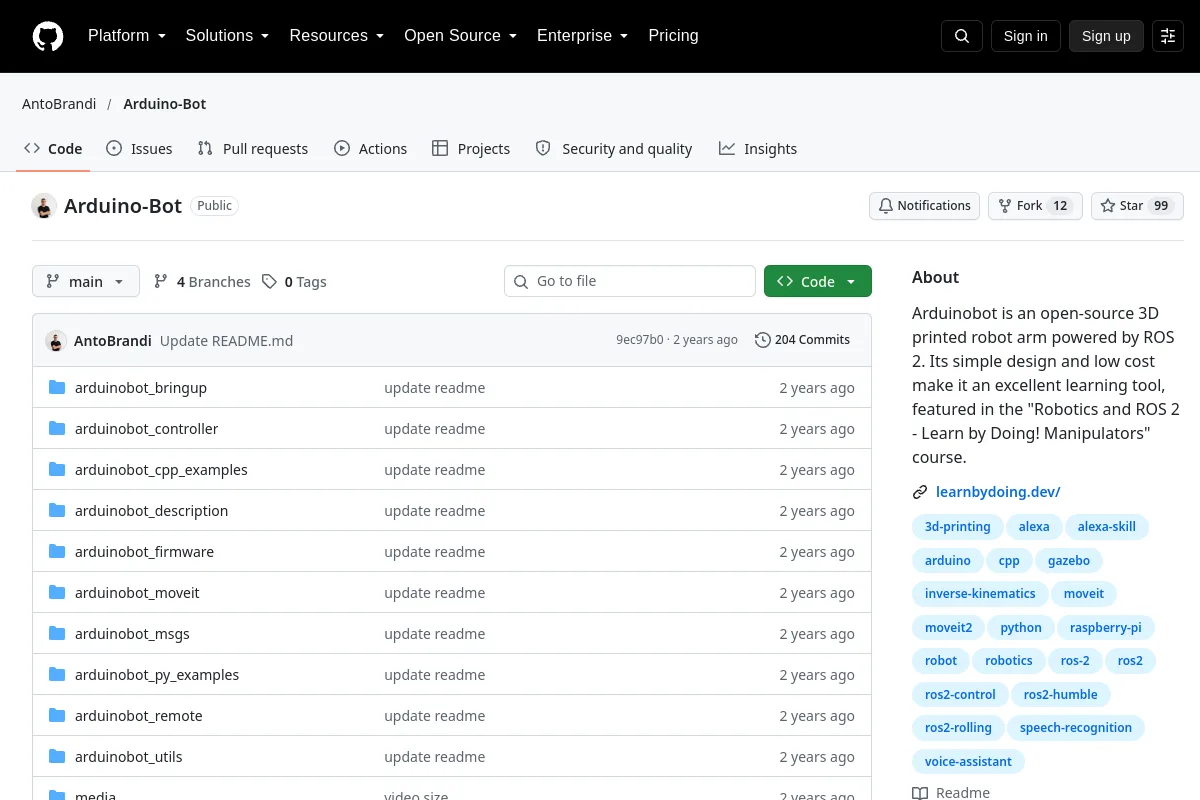
Arduinobot is an open-source 3D printed robot arm powered by ROS 2. Its simple design and low cost make it an excellent learning tool, featured in the "Robotics and ROS 2 - Learn by Doing!…
Publisher purpose: Arduinobot is an open-source 3D printed robot arm powered by ROS 2. Its simple design and low cost make it an excellent learning tool, featured in the "Robotics and ROS 2 - Learn by Doing! Manipulators" course.
Use the source to explore robotics concepts, examples and references. Source material may be historical; check the applicable version and context.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
Python tools and examples for robotics education and algorithm exploration.
Courses & documentation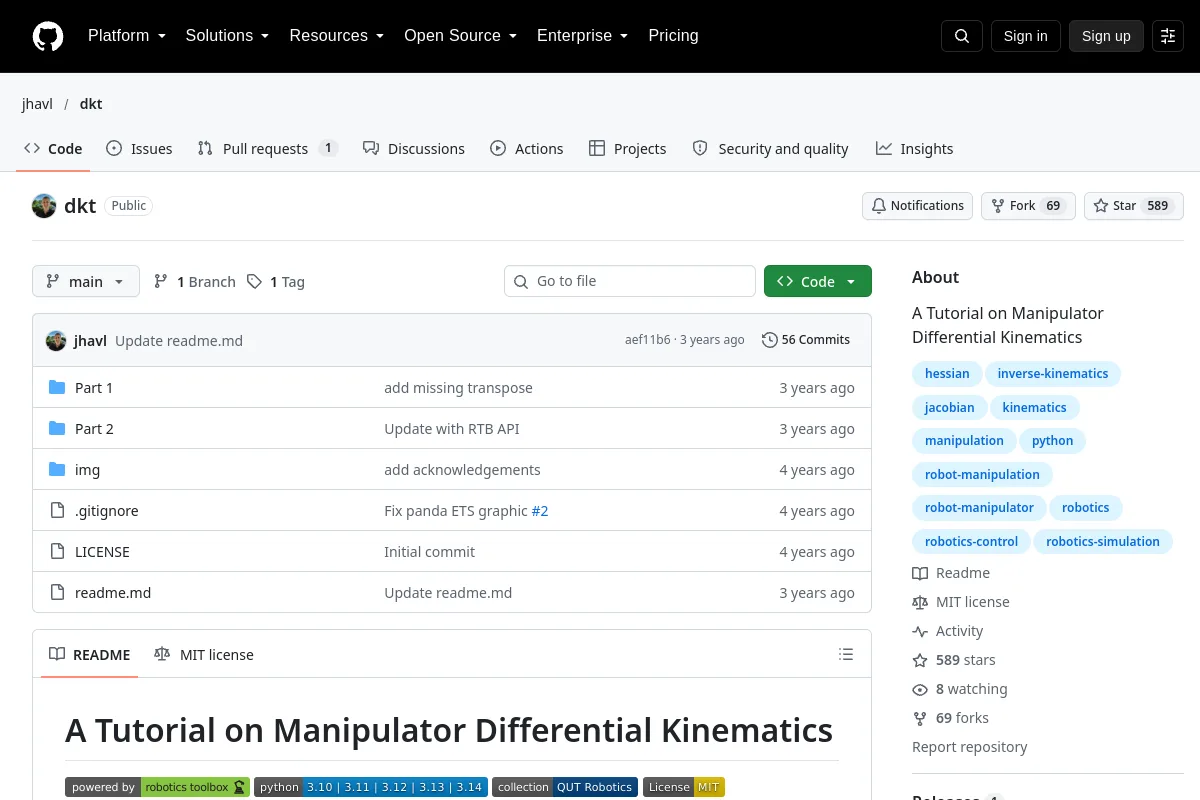 Repository
 Repository
 Repository
 Open source
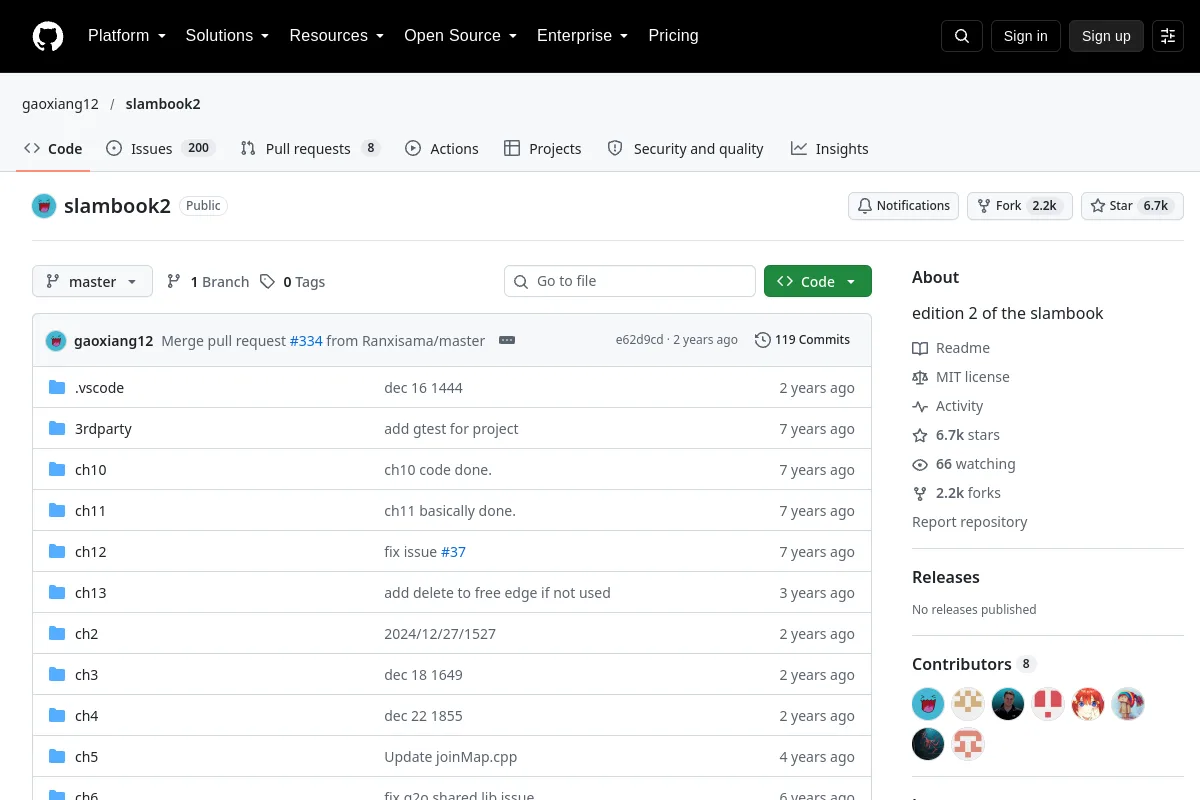
The English version of 14 lectures on visual SLAM.
Courses & documentation Repository
 Research
zenoh-plugin-ros2dds provides a Zenoh plugin and bridge for ROS 2 communication over DDS.
Standards & reference collections Repository
 Research
Embodied AI Lab is a research hub covering VLA, data infrastructure and robotics evaluation.
Standards & reference collections