 Repository
Research & learning / Open source
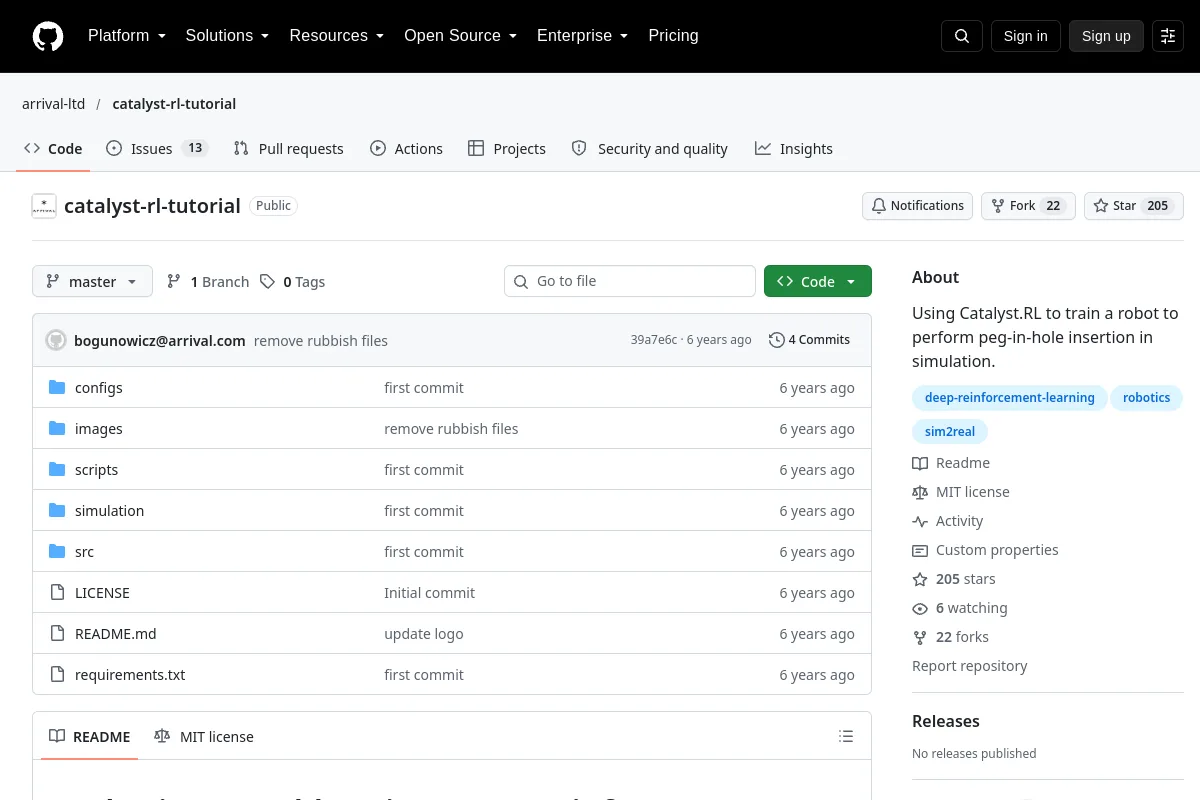
catalyst-rl-tutorial · arrival-ltd
Using Catalyst.RL to train a robot to perform peg-in-hole insertion in simulation.
Overview
Using Catalyst.RL to train a robot to perform peg-in-hole insertion in simulation.
Use the source to explore robotics concepts, examples and references. Source material may be historical; check the applicable version and context.
Project information
- Maintainer
- arrival-ltd
- Primary language
- Python
- Repository code license
- MIT
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2020-09-23
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- Robotic Assembly using Deep Reinforcement Learning
- Introduction
- Setup
- -------------- all methods above are required for any Gym environment, everything below is env-specific --------------
- A brief summary of the `CoppeliaSimEnvWrapper` in `src/env.py`
- Defining the RL algorithm
Browse this resource’s categories
Explore related collections
Browse Research & learning →More in Research & learning
Repository