 Repository
Research & learning / Open source
Self-Driving-and-ROS-2-Learn-by-Doing-Odometry-Control · AntoBrandi
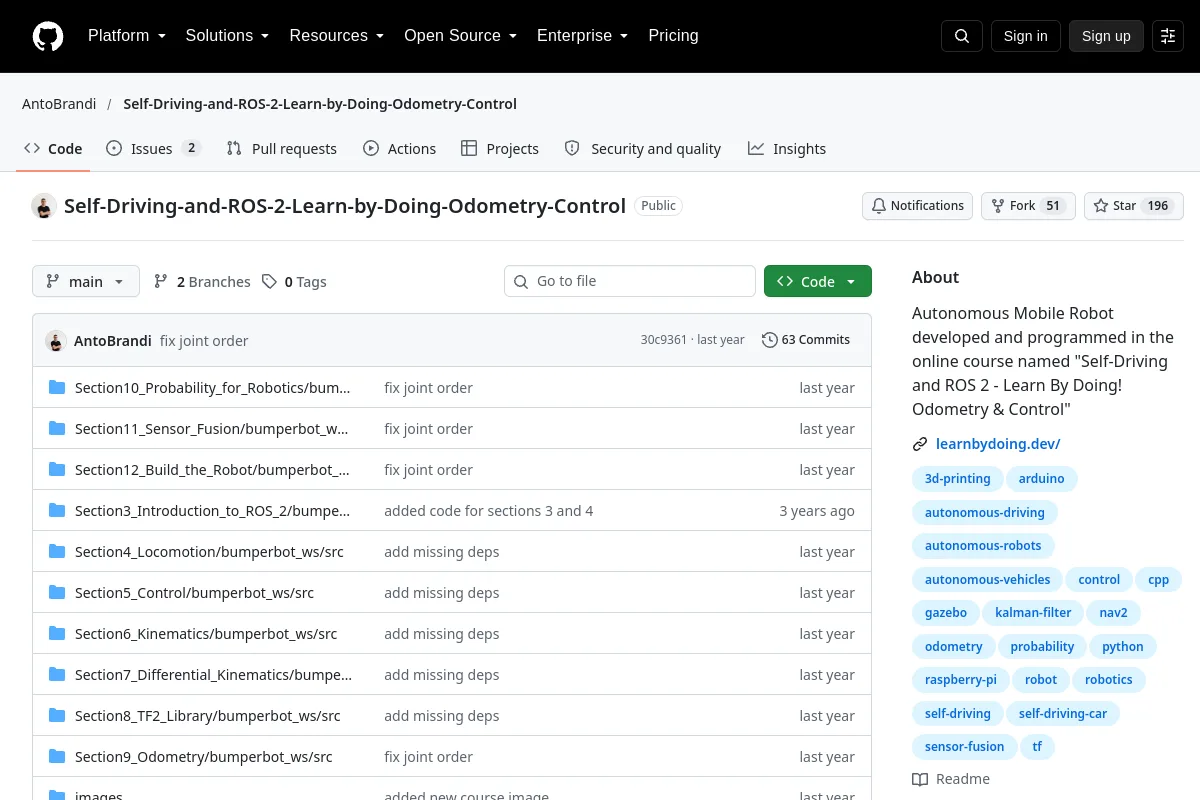
Autonomous Mobile Robot developed and programmed in the online course named "Self-Driving and ROS 2 - Learn By Doing! Odometry & Control"
Overview
Autonomous Mobile Robot developed and programmed in the online course named "Self-Driving and ROS 2 - Learn By Doing! Odometry & Control"
Use the source to explore robotics concepts, examples and references. Source material may be historical; check the applicable version and context.
Project information
- Maintainer
- AntoBrandi
- Primary language
- Python
- Repository code license
- Apache-2.0
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2025-09-30
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- Self-Driving and ROS 2 - Learn by Doing! Odometry & Control
- Table of Contents
- About the Course
- Other Courses
- Self Driving and ROS 2 - Learn by Doing! Plan & Navigation
- Self Driving and ROS 2 - Learn by Doing! Map & Localization
Browse this resource’s categories
Explore related collections
Browse Research & learning →More in Research & learning
Repository