 代码仓库
科研与学习 / 开源
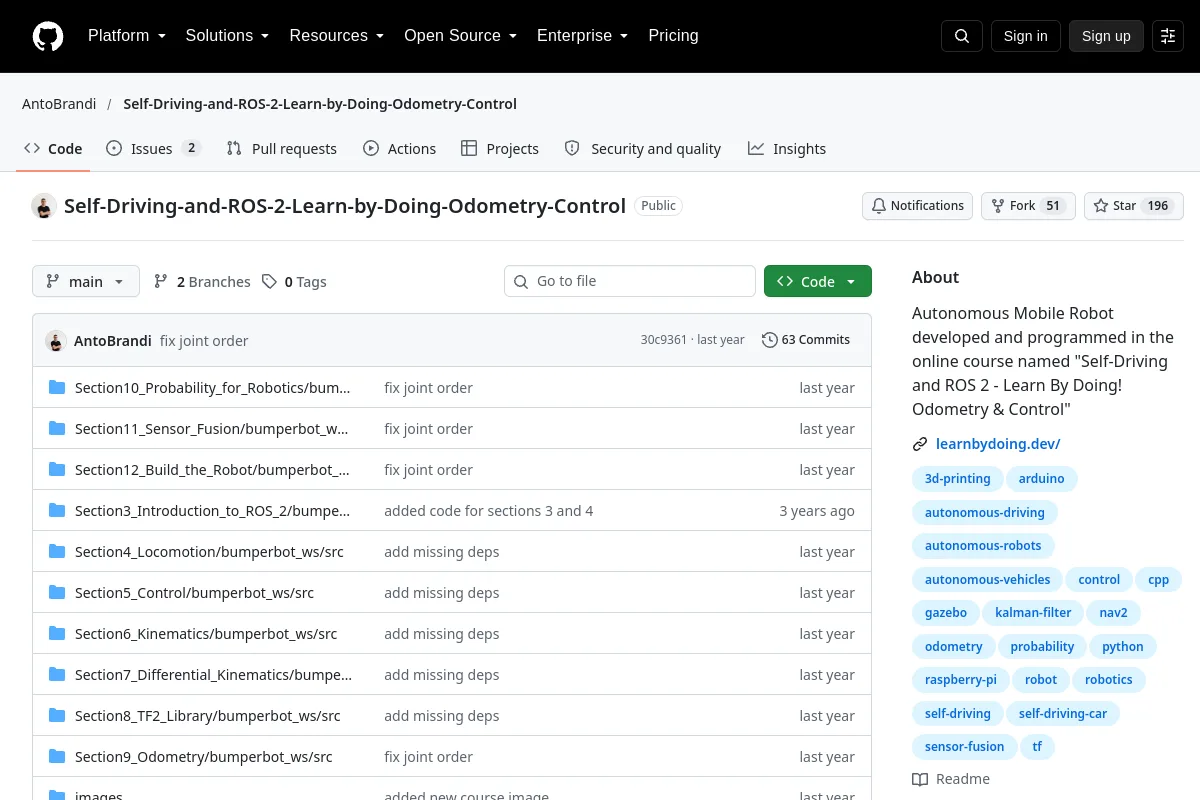
Self-Driving-and-ROS-2-Learn-by-Doing-Odometry-Control · AntoBrandi
在名为“自驾驶和ROS 2-边做边学!里程计和控制”的在线课程中开发和编程的自主移动机器人
概述
Autonomous Mobile Robot developed and programmed in the online course named "Self-Driving and ROS 2 - Learn By Doing! Odometry & Control"
Use the source to explore robotics concepts, examples and references. Source material may be historical; check the applicable version and context.
项目信息
- 维护者
- AntoBrandi
- 主要语言
- Python
- 存储库代码许可证
- Apache-2.0
- 模型重量许可证
- 未记录
- 数据集许可
- 未记录
- 硬件设计许可证
- 未记录
- 维护
- 未存档在最后记录的元数据中
- 最后观察到的存储库推送
- 2025-09-30
代码许可不会自动涵盖模型权重、数据集或硬件设计。未记录的许可证详细信息需要与发布者确认。
文档部分
- Self-Driving and ROS 2 - Learn by Doing! Odometry & Control
- Table of Contents
- About the Course
- Other Courses
- Self Driving and ROS 2 - Learn by Doing! Plan & Navigation
- Self Driving and ROS 2 - Learn by Doing! Map & Localization
浏览该资源的类别
探索相关集合
浏览 科研与学习 →更多内容见 科研与学习
代码仓库
