 Repository
 Research
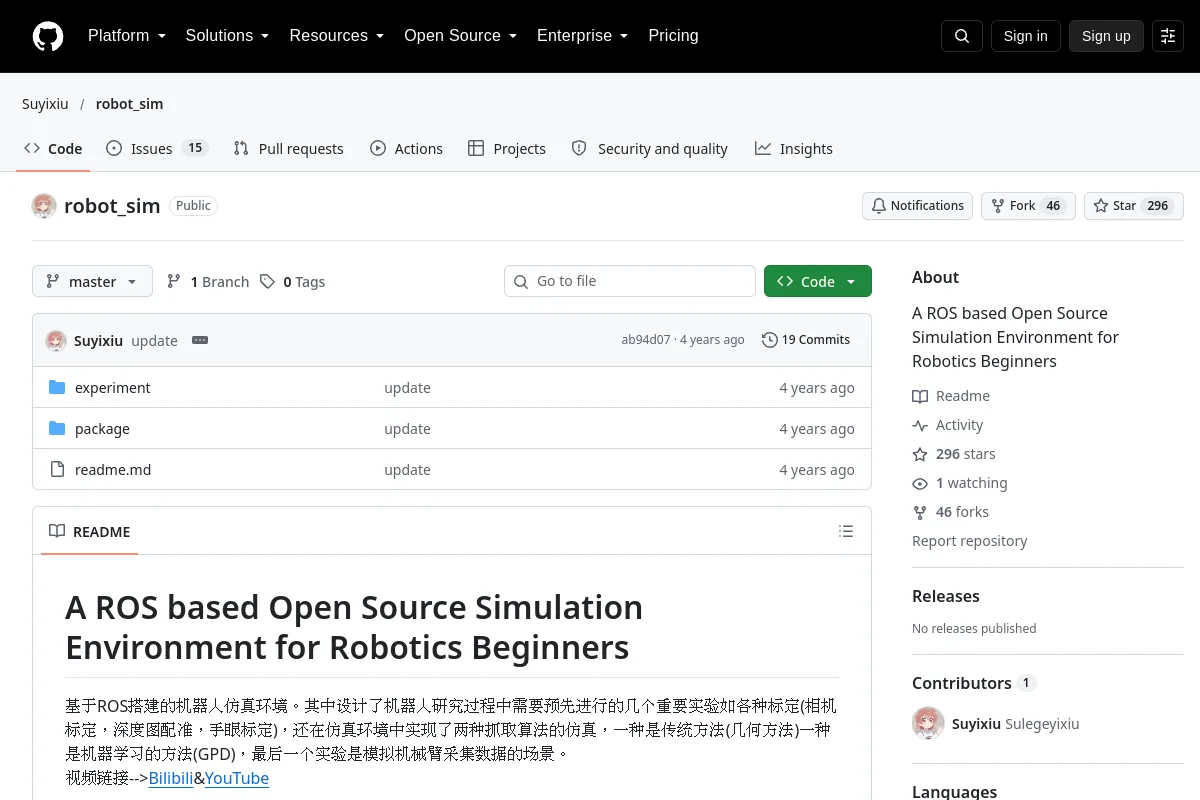
robot_sim · Suyixiu
A ROS based Open Source Simulation Environment for Robotics Beginners
Simulation & physicsTHE EMBODIED AI DIRECTORY
Explore robot simulation software for physics, control and robot learning.
Repository
Research
A ROS based Open Source Simulation Environment for Robotics Beginners
Simulation & physics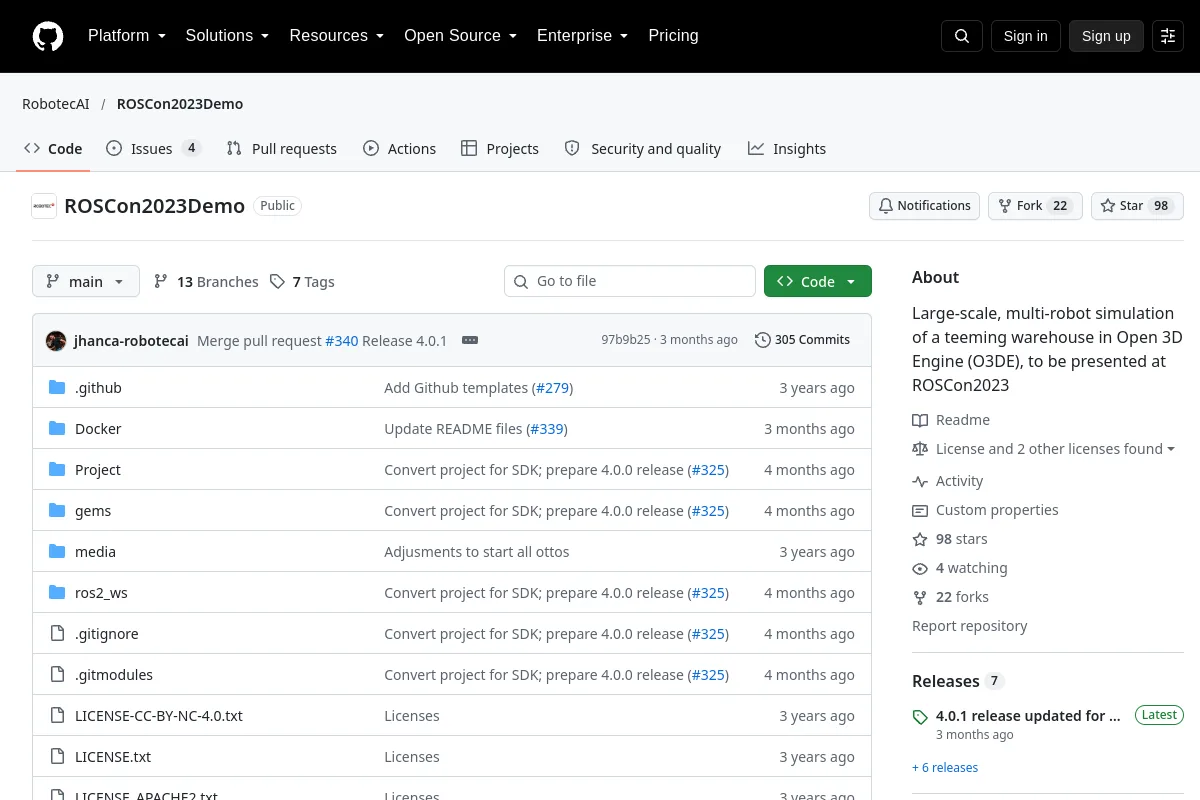 Repository
 Research
Large-scale, multi-robot simulation of a teeming warehouse in Open 3D Engine (O3DE), to be presented at ROSCon2023
Simulation & physics Repository
 Repository
 Research
SO-101 behavior-cloning and PPO reproduction notes and evaluation workflows.
Simulation & physics Repository
 Research
SoRoSim: A MATLAB Toolbox for Hybrid Soft-Rigid Robots
Simulation & physics Repository
 Research
Simulate a simple Ackermann steering vehicle in Gazebo using ros_control.
Simulation & physics Repository
 Research
Interactive Robot Assisted Suturing Simulation
Simulation & physics Repository
 Research
Collection of MuJoCo robotics environments equipped with both vision and tactile sensing
Simulation & physics Repository
 Research
Isaac Lab workflows for TienKung legged-robot research.
Simulation & physics Repository
 Research
A high-performance CUDA-based physics simulation sandbox for soft robotics and reinforcement learning.
Simulation & physics Repository
 Research
Visually Realistic Underwater Robotics Simulator UNav-Sim
Simulation & physics Repository
 Research
Universal Robot (UR5) Pick and Place Simulation in ROS-Gazebo with a USB Cam and Vacuum Grippers
Simulation & physics Repository
 Research
MuJoCo reinforcement learning environments for UR5e reaching and manipulation.
Simulation & physics Repository
 Research
Vitruvio is a framework for rapid leg design analysis and optimization for legged robots. The purpose of the simulation framework is to guide the early stages of legged robot design. The end…
Simulation & physics Repository
 Research
Learning Robotics by Playing with V-REP
Simulation & physics Website
 Research
A robot simulation environment with sensor models and controller interfaces.
Simulation & physicsSELECTION NOTES
Compare physics fidelity, rendering, robot asset support and Python interfaces. MuJoCo suits physics and control experiments; Gazebo connects simulation with the ROS ecosystem; Isaac Sim supports robotics simulation and synthetic data. Check current GPU and license requirements before choosing.
Know a resource that belongs here?