 Repository
 Open source
isaac_ros_pose_estimation · NVIDIA-ISAAC-ROS
Deep learned, NVIDIA-accelerated 3D object pose estimation
Perception & geometryTHE EMBODIED AI DIRECTORY
Find point-cloud processing, calibration and geometric estimation libraries.
Repository
Open source
Deep learned, NVIDIA-accelerated 3D object pose estimation
Perception & geometry Repository
 Open source
AdaptiGraph research code for material-adaptive robotic manipulation dynamics.
Perception & geometry Repository
 Open source
Tools for robot kinematics, dynamics, and optimization.
Perception & geometry Repository
 Open source
Autonomous Perception
Perception & geometry Repository
 Open source
BiFold research code for language-guided bimanual cloth folding.
Perception & geometry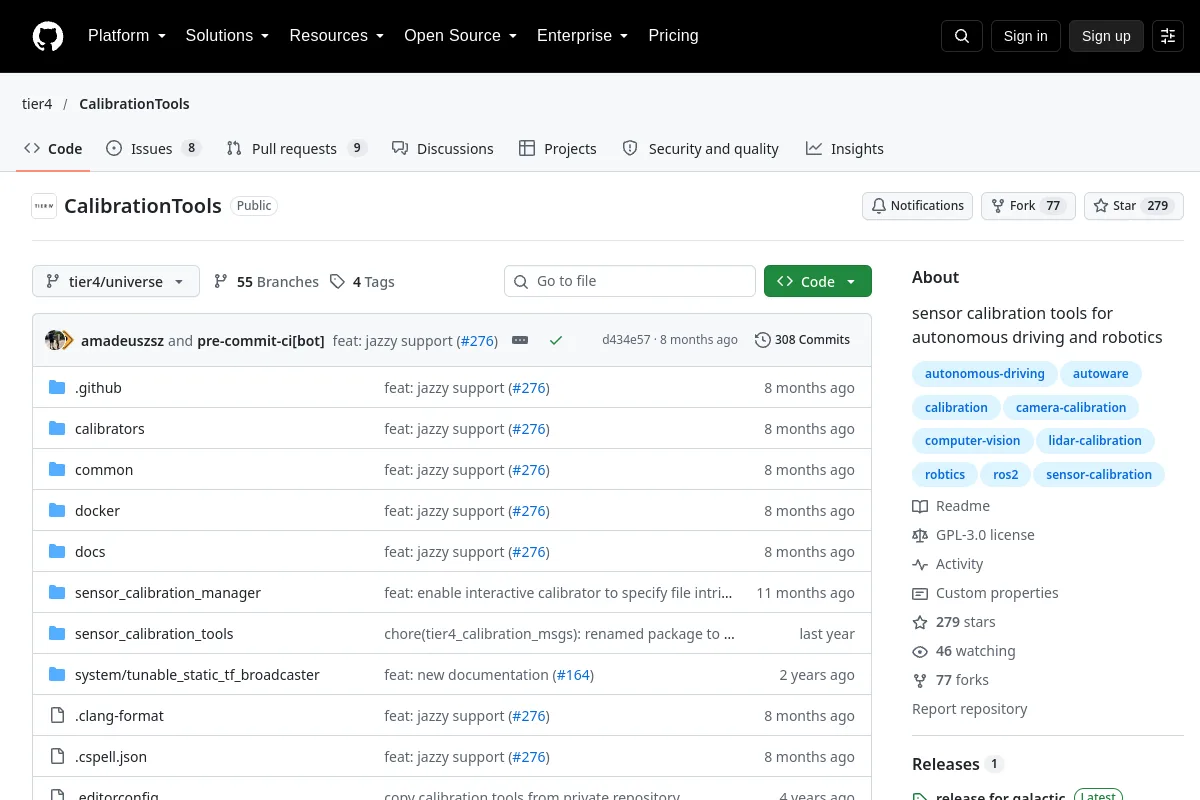 Repository
 Open source
sensor calibration tools for autonomous driving and robotics
Perception & geometry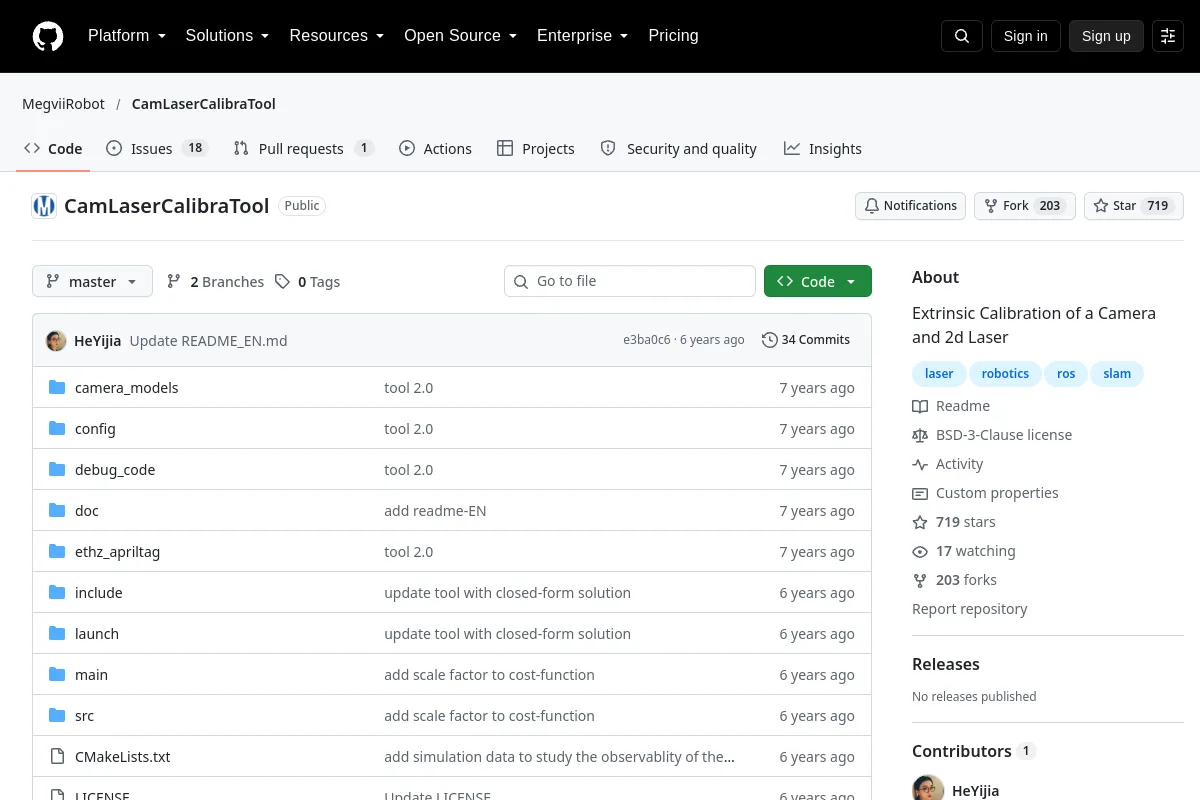 Repository
 Open source
Extrinsic Calibration of a Camera and 2d Laser
Perception & geometry Repository
 Open source
ROS tools and Raspberry Pi images for PX4-powered drones.
Perception & geometry Repository
 Repository
 Open source
Example connecting an Isaac GR00T policy to a simulated Franka Panda in MuJoCo.
Perception & geometry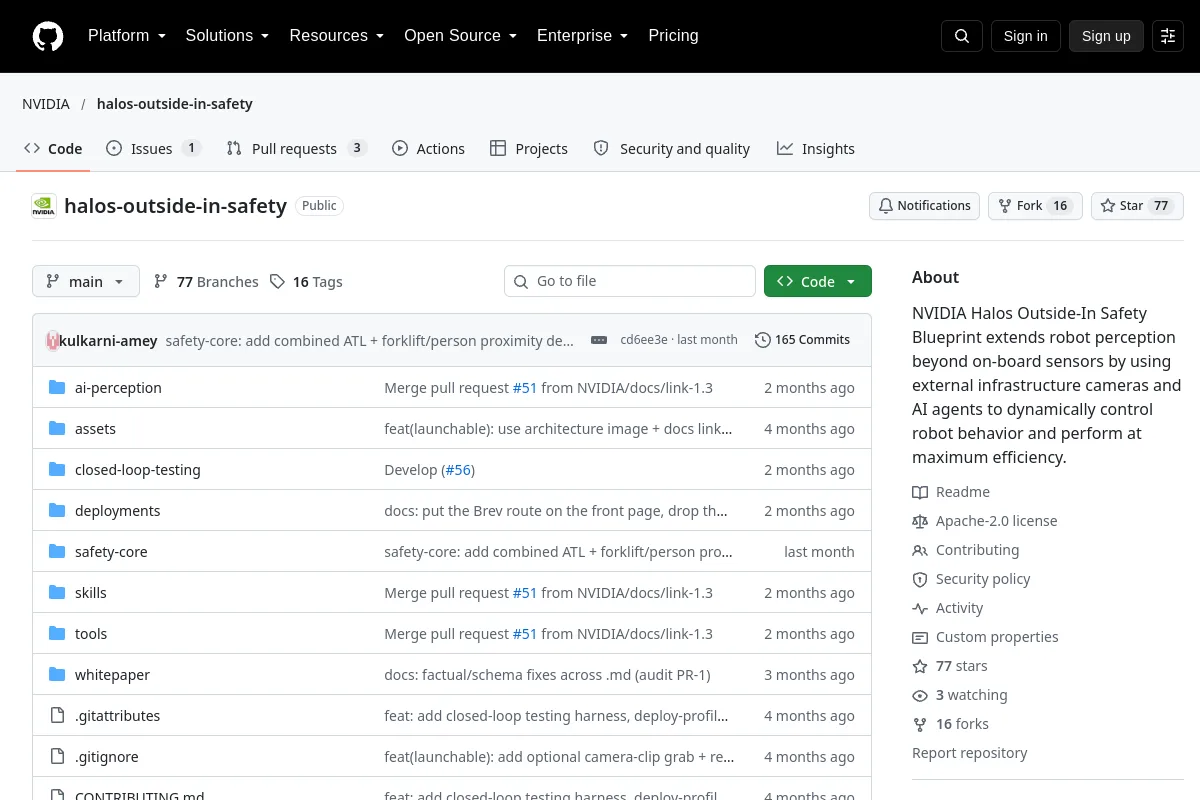 Repository
 Open source
NVIDIA Halos Outside-In Safety Blueprint extends robot perception beyond on-board sensors by using external infrastructure cameras and AI agents to dynamically control robot behavior and perform…
Perception & geometry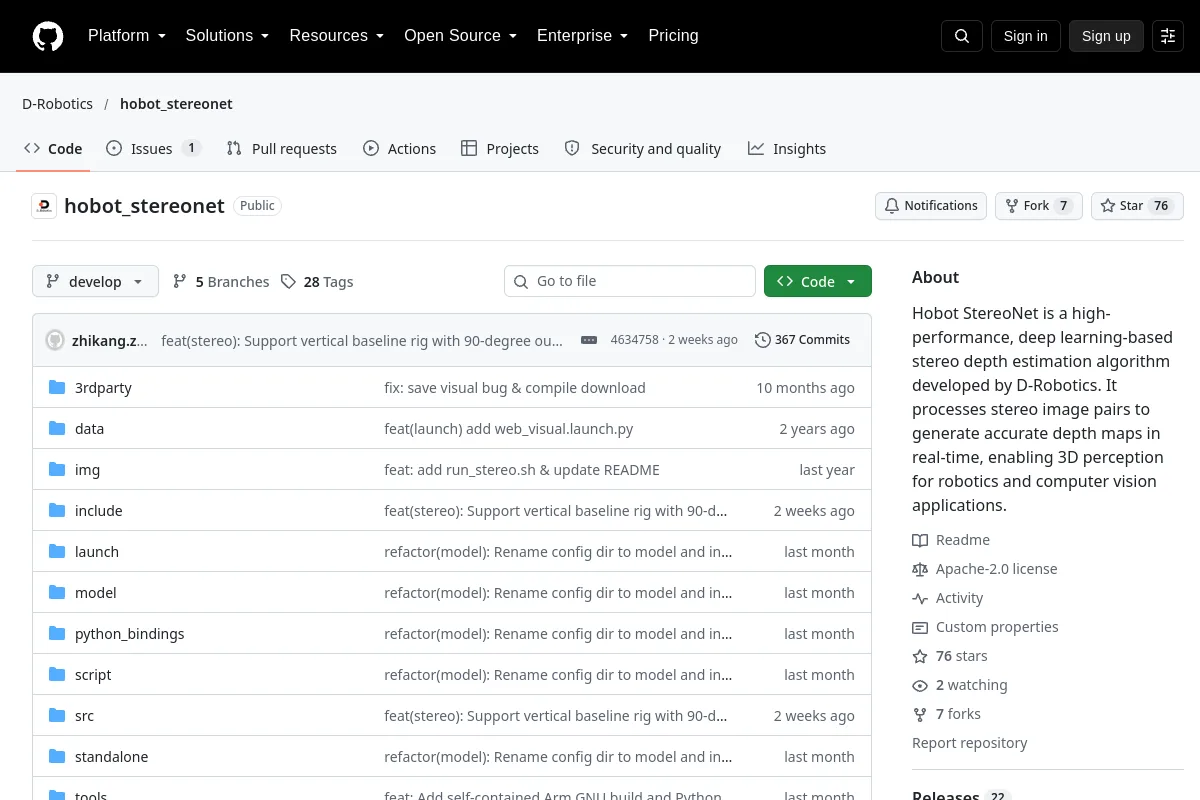 Repository
 Open source
Hobot StereoNet is a high-performance, deep learning-based stereo depth estimation algorithm developed by D-Robotics. It processes stereo image pairs to generate accurate depth maps in real-time…
Perception & geometry Repository
 Open source
A simulation environment for reinforcement learning and robotics research.
Perception & geometry Repository
 Open source
NVIDIA-accelerated Apriltag detection and pose estimation.
Perception & geometry Repository
 Repository
 Open source
Guides and code for deep-learning inference on NVIDIA Jetson with TensorRT.
Perception & geometry Repository
 Open source
A Fully Open-source and Compact Aerial Robot with Omnidirectional Visual Perception
Perception & geometry Repository
 Open source
OpenEyes is an open-source robot vision framework for edge devices
Perception & geometry Repository
 Open source
Research code for open-vocabulary affordance detection in 3D point clouds.
Perception & geometry Repository
 Open source
A specification for permissioned egocentric teaching of personal robots.
Perception & geometry Repository
 Open source
Learning robotic spray-painting paths from 3D point clouds.
Perception & geometry Repository
 Open source
Perception and AI components for autonomous mobile robotics.
Perception & geometry Repository
 Open source
A ROS 2 vision framework for RoboMaster robots.
Perception & geometry Repository
 Open source
Library for differentiable nonlinear optimization.
Perception & geometrySELECTION NOTES
Choose tools around sensor modality, calibration assumptions and required geometric outputs. Check numerical precision, runtime requirements and data conventions before connecting pipelines.
Know a resource that belongs here?