 Repository
 Open source
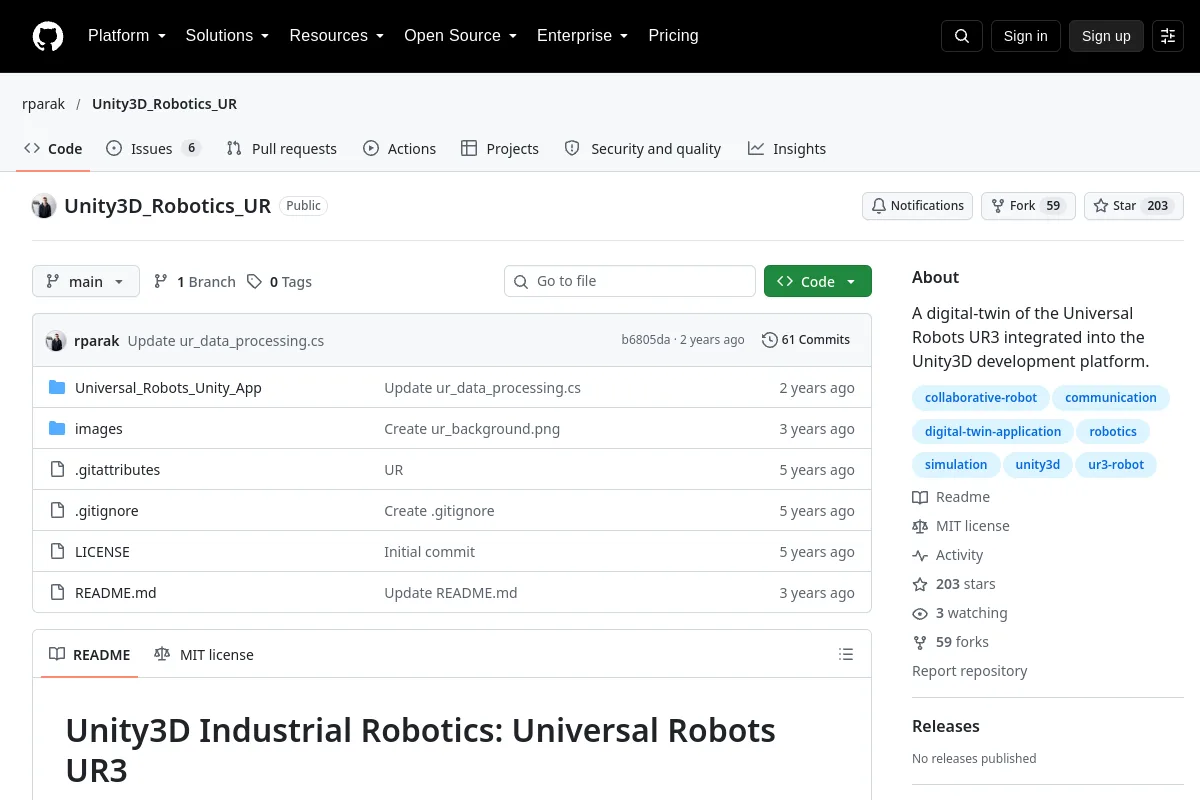
Unity3D_Robotics_UR · rparak
A digital-twin of the Universal Robots UR3 integrated into the Unity3D development platform.
Simulation & physicsTHE EMBODIED AI DIRECTORY
Explore robot simulation software for physics, control and robot learning.
Repository
Open source
A digital-twin of the Universal Robots UR3 integrated into the Unity3D development platform.
Simulation & physics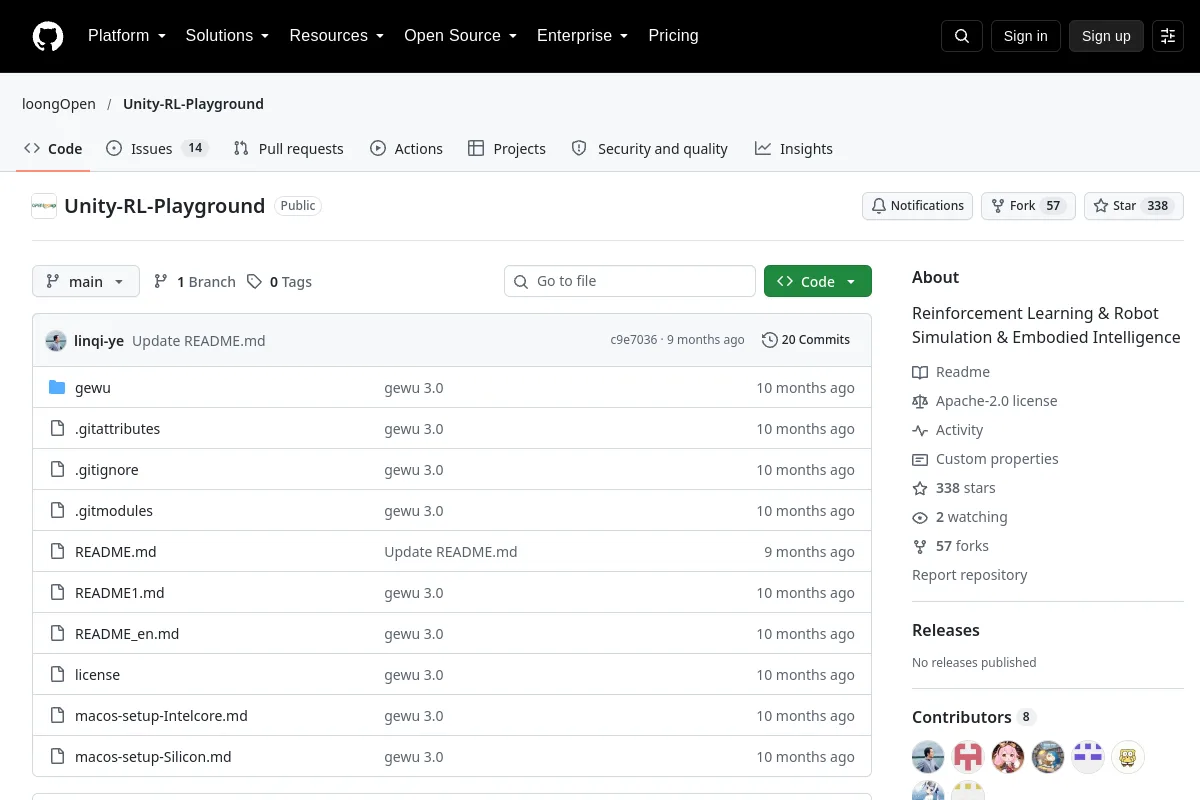 Repository
 Open source
Reinforcement Learning & Robot Simulation & Embodied Intelligence
Simulation & physics Repository
 Open source
Using the repository
Simulation & physics Repository
 Open source
ROS-based Universal Robots (e.g., UR3/e UR5/5, ...) with simulation in Gazebo.
Simulation & physics Repository
 Open source
UR3 robotic arm pick-and-place stack for ROS2 Humble: MoveIt 2 + MoveIt Task Constructor, Gazebo Harmonic simulation, Robotiq/OnRobot grippers, dual-arm support, BehaviorTree.CPP task planning…
Simulation & physics Repository
 Open source
This project simulates a UR5 robotic arm with a Robotiq 85 gripper, performing autonomous object grasping and placement tasks in the PyBullet environment.
Simulation & physics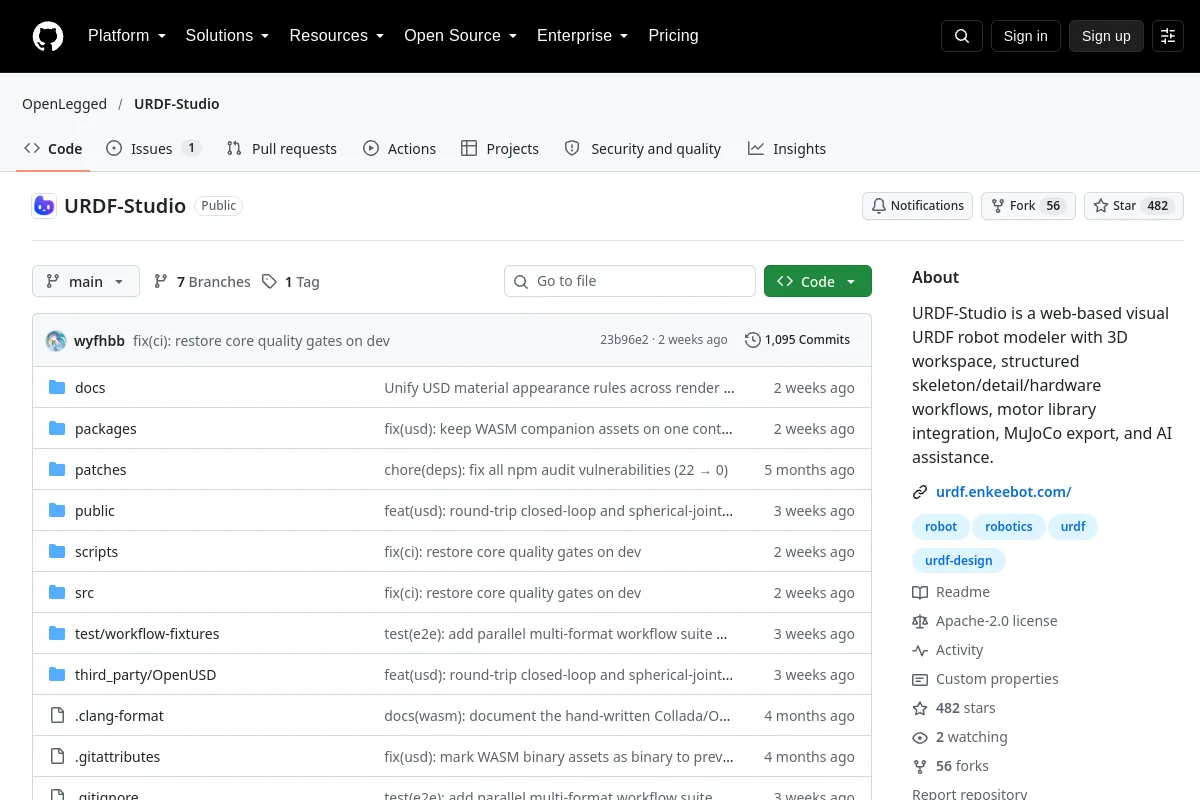 Repository
 Open source
Web-based URDF robot-model editor with 3D visualization and export workflows.
Simulation & physics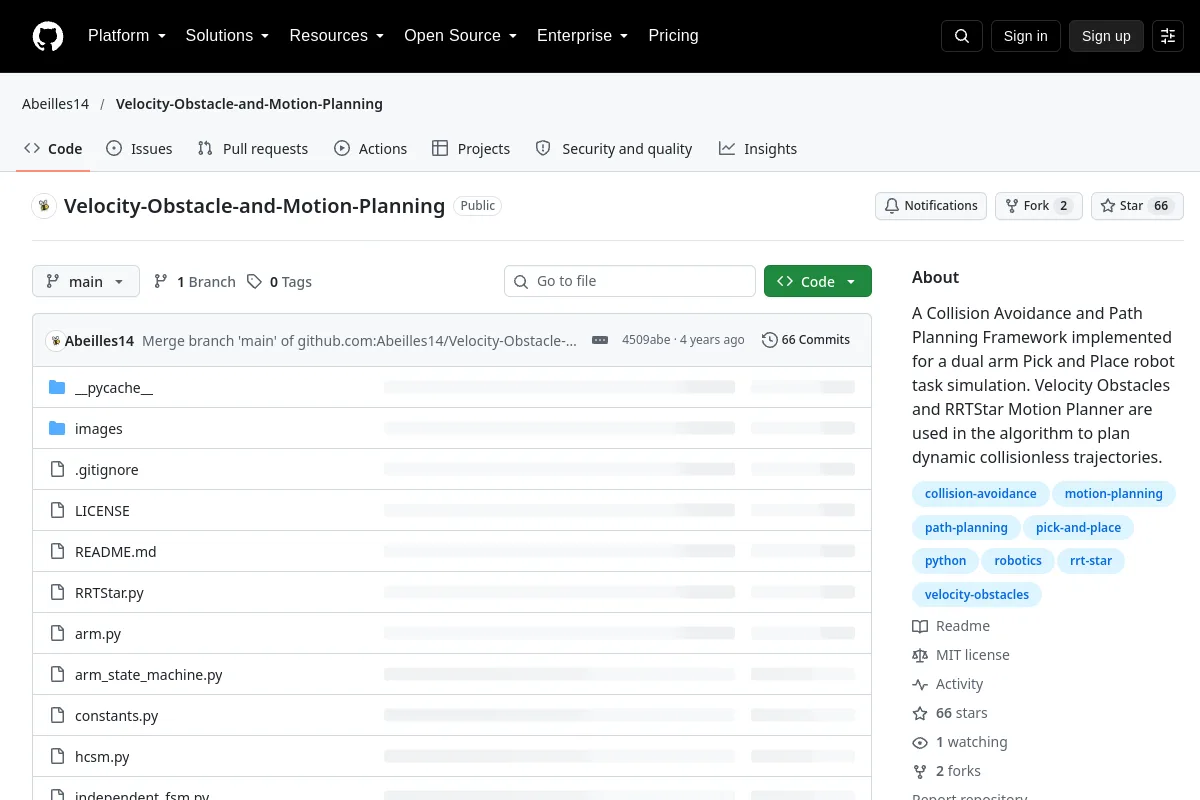 Repository
 Open source
A Collision Avoidance and Path Planning Framework implemented for a dual arm Pick and Place robot task simulation. Velocity Obstacles and RRTStar Motion Planner are used in the algorithm to plan…
Simulation & physics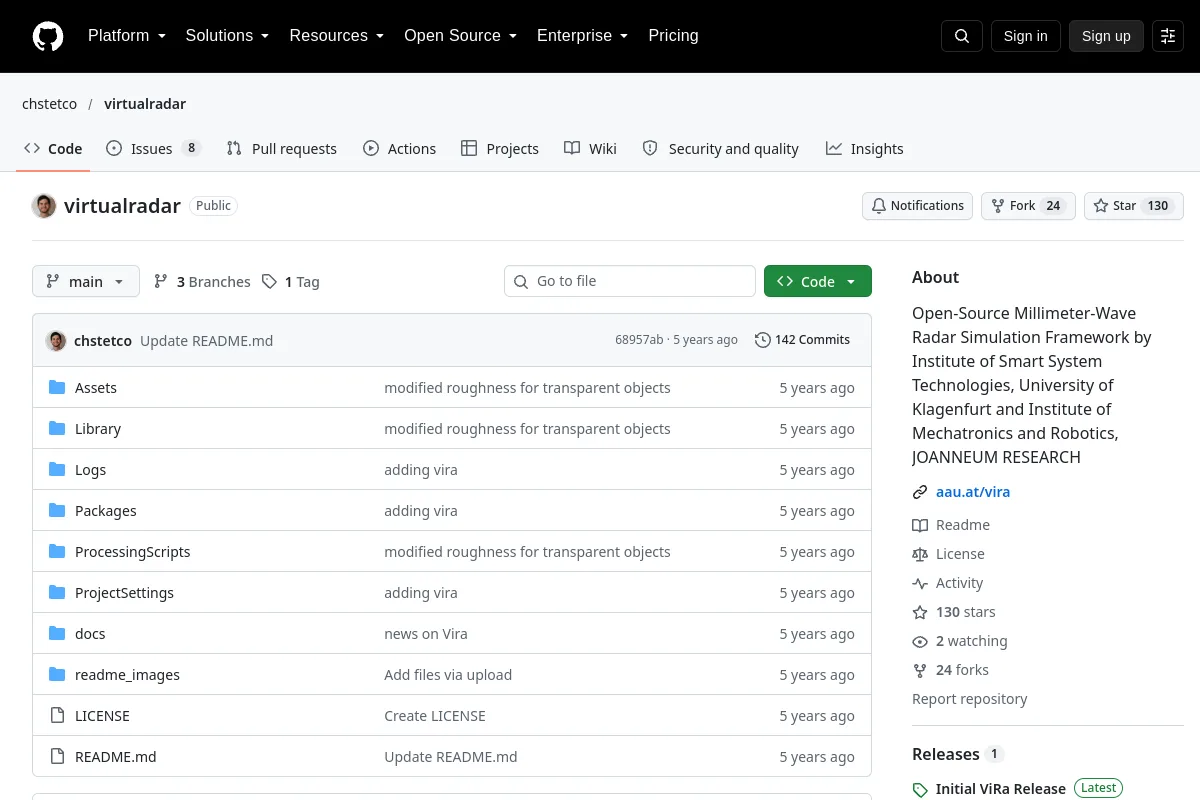 Repository
 Open source
Open-Source Millimeter-Wave Radar Simulation Framework by Institute of Smart System Technologies, University of Klagenfurt and Institute of Mechatronics and Robotics, JOANNEUM RESEARCH
Simulation & physics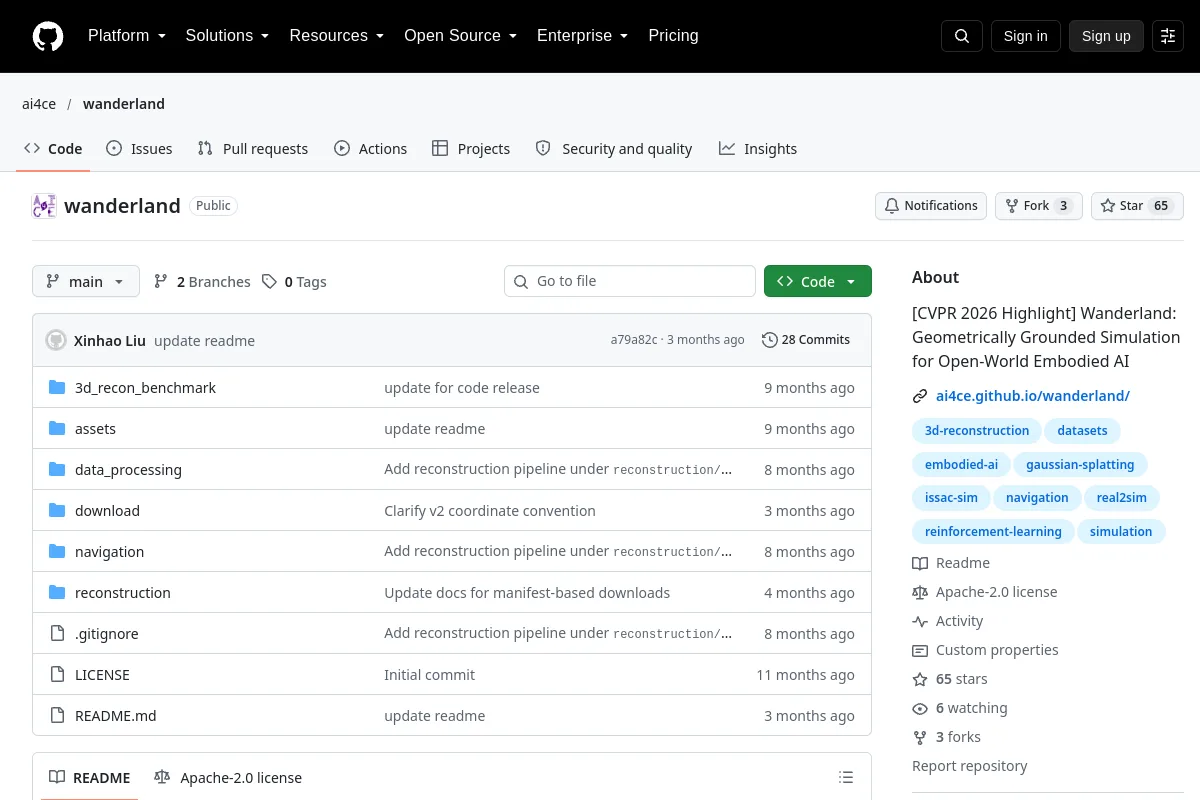 Repository
 Open source
Wanderland: Geometrically Grounded Simulation for Open-World Embodied AI
Simulation & physics Repository
 Repository
 Open source
Force controlled assembly process. In real and simulated environment. Using Universal Robots UR5, ROS, Gazebo.
Simulation & physics Website
 Website
SELECTION NOTES
Compare physics fidelity, rendering, robot asset support and Python interfaces. MuJoCo suits physics and control experiments; Gazebo connects simulation with the ROS ecosystem; Isaac Sim supports robotics simulation and synthetic data. Check current GPU and license requirements before choosing.
Know a resource that belongs here?