 Repository
 Open source
pymanoid · stephane-caron
OpenRAVE-based environment for humanoid robotics prototyping.
Motion planning & controlTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Open source
OpenRAVE-based environment for humanoid robotics prototyping.
Motion planning & control Repository
 Repository
 Open source
A library for differentiable robotics on manifolds.
Motion planning & control Repository
 Open source
Library to control Robotiq company grippers from python
Robot SDKs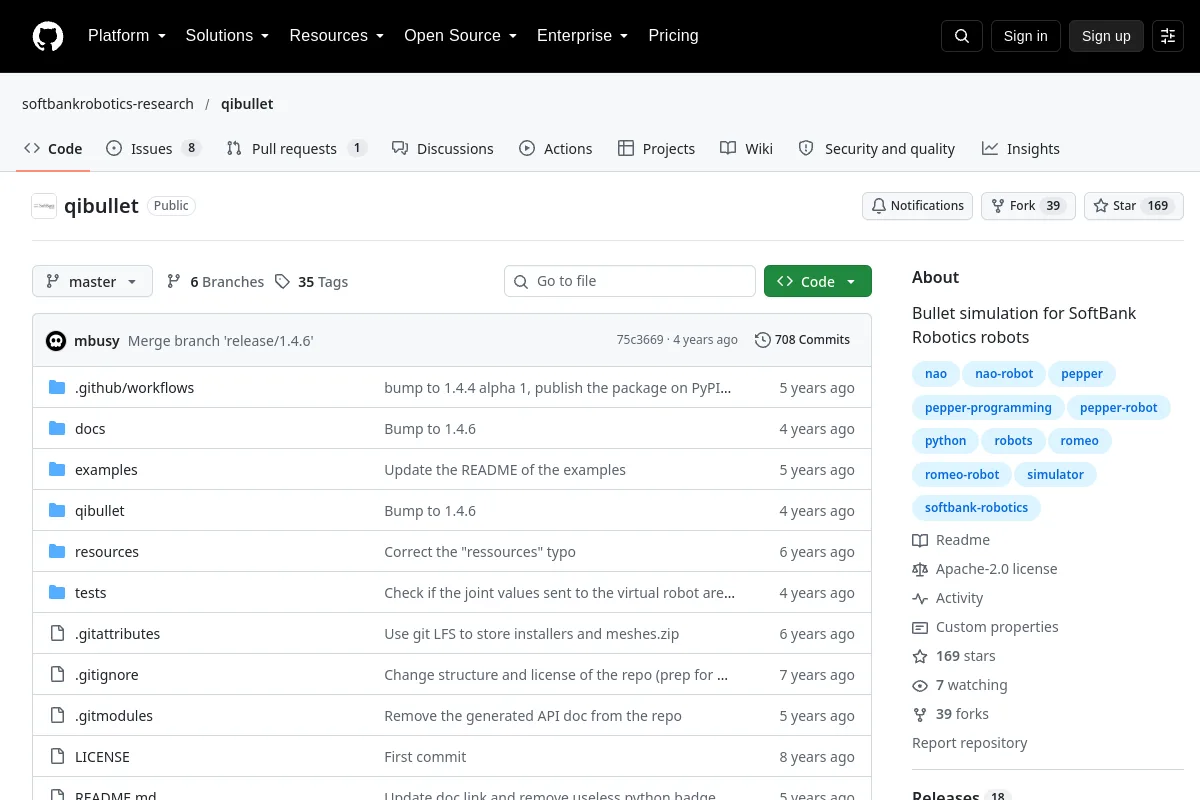 Repository
 Open source
Bullet simulation for SoftBank Robotics robots
Simulation & physics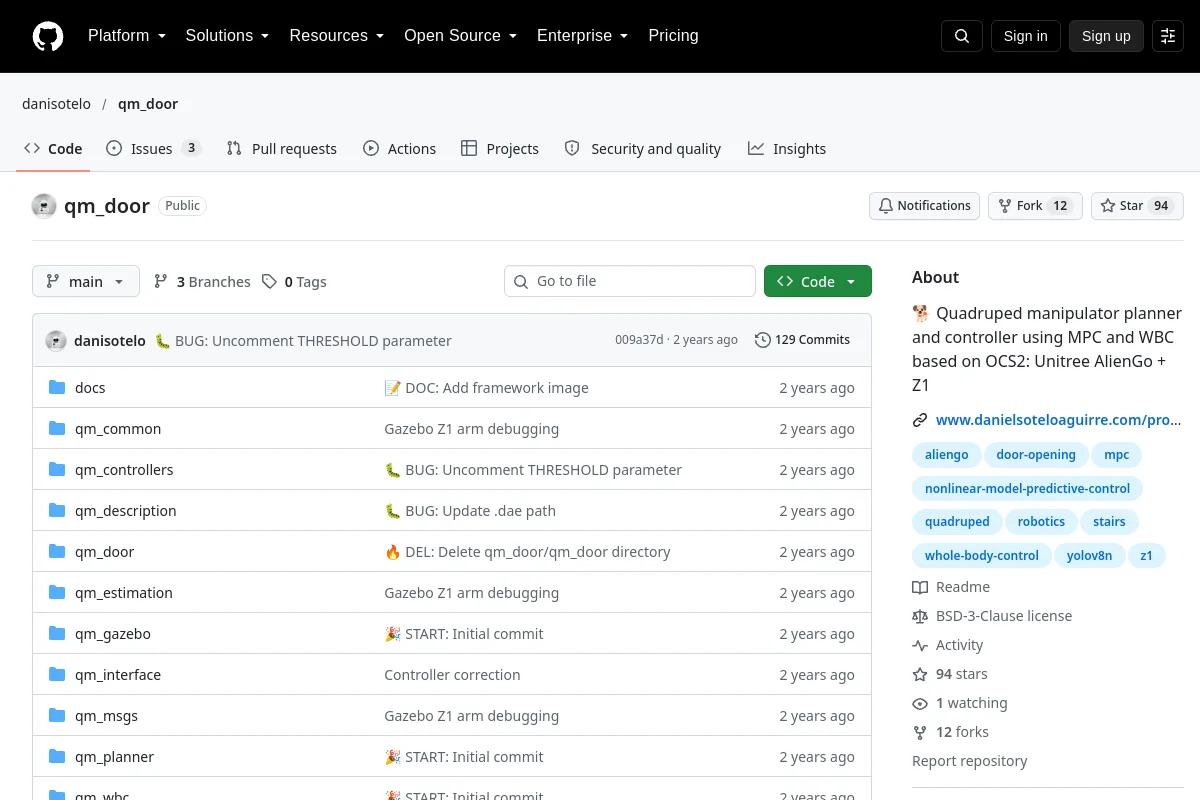 Repository
 Open source
:dog2: Quadruped manipulator planner and controller using MPC and WBC based on OCS2: Unitree AlienGo + Z1
Motion planning & control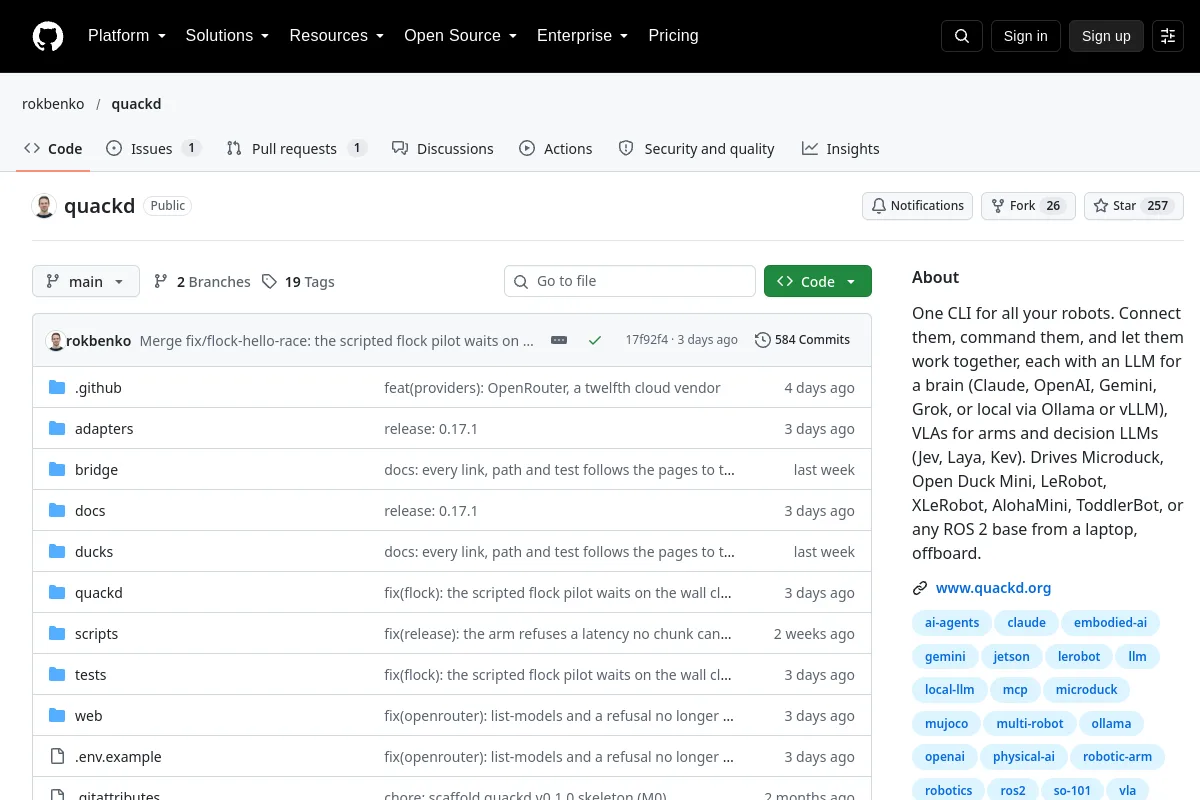 Repository
 Open source
One CLI for all your robots. Connect them, command them, and let them work together, each with an LLM for a brain (Claude, OpenAI, Gemini, Grok, or local via Ollama or vLLM), VLAs for arms and…
Middleware & communication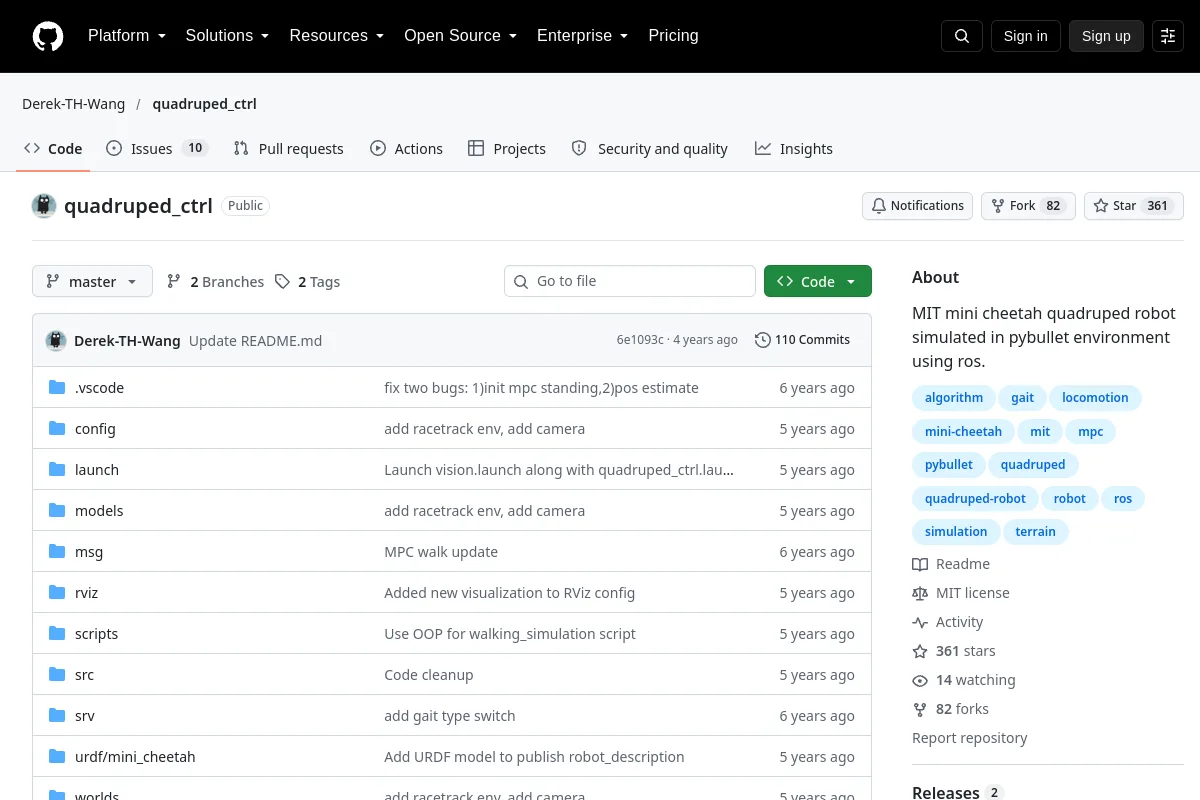 Repository
 Open source
MIT mini cheetah quadruped robot simulated in pybullet environment using ros.
Simulation & physics Repository
 Open source
A model predictive controller for quadruped robots based on the single rigid body model and written in python. Gradient-based (acados) or Sampling-based (jax)
Motion planning & control Repository
 Open source
A guide and workflows for quadruped locomotion with reinforcement learning.
Simulation & physics Repository
 Open source
Implementation of Radiance Fields for Robotic Teleoperation
Teleoperation software Repository
 Open source
Robot-arm manipulation demonstration using the RAI framework.
Robot learning frameworks Repository
 Open source
Rank-Then-Act research code for control from frame-order progress.
Motion planning & control Repository
 Open source
A simulation framework for Robotic Mobile Fulfillment Systems
Simulation & physics Repository
 Open source
Robot-description assets for the RBY1 mobile manipulator.
Robot learning frameworks Repository
 Open source
RCareWorld simulation environment for caregiving robots
Simulation & physics Repository
 Open source
URDF descriptions for the Reachy robot.
Robot learning frameworks Repository
 Open source
Real2Render2Real: Scaling Robot Data Without Dynamics Simulation or Robot Hardware
Simulation & physics Repository
 Open source
Open-source code of the paper: Real-to-Sim Robot Policy Evaluation with Gaussian Splatting Simulation of Soft-Body Interactions.
Simulation & physics Repository
 Open source
Perception and AI components for autonomous mobile robotics.
Perception & geometry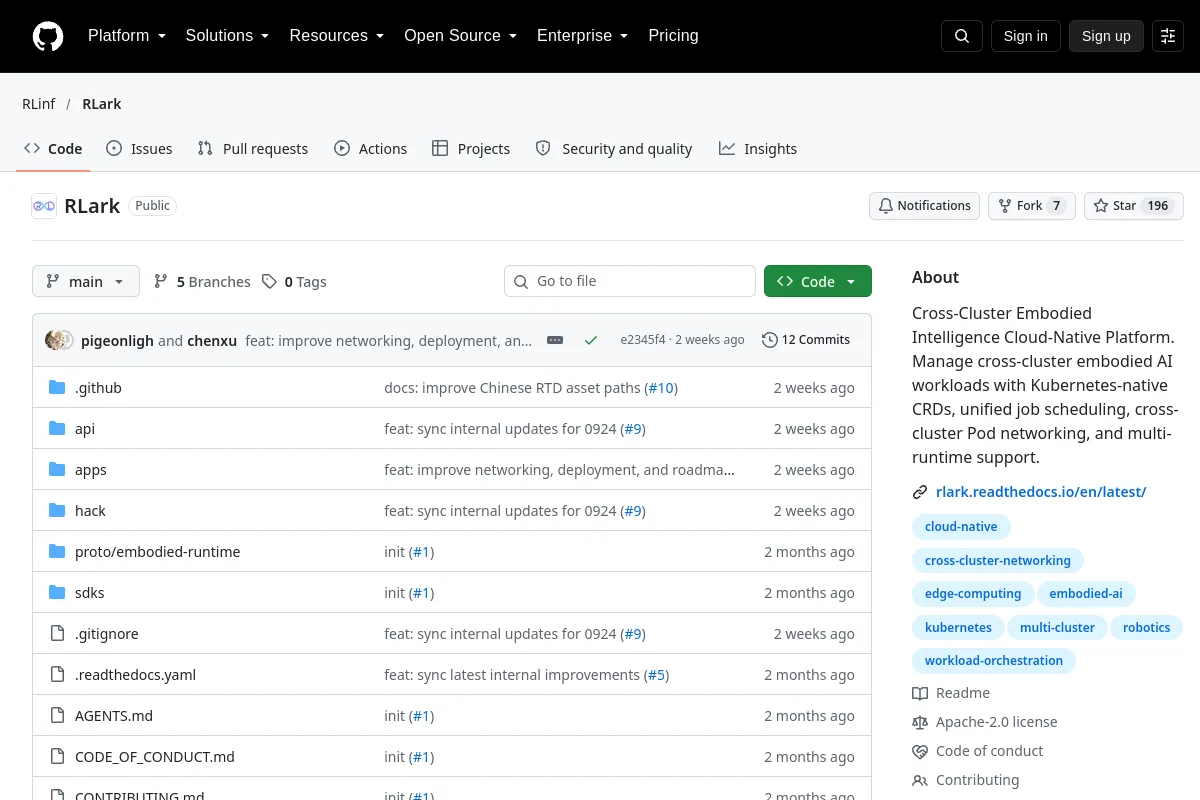 Repository
 Open source
Cross-Cluster Embodied Intelligence Cloud-Native Platform. Manage cross-cluster embodied AI workloads with Kubernetes-native CRDs, unified job scheduling, cross-cluster Pod networking, and…
Middleware & communication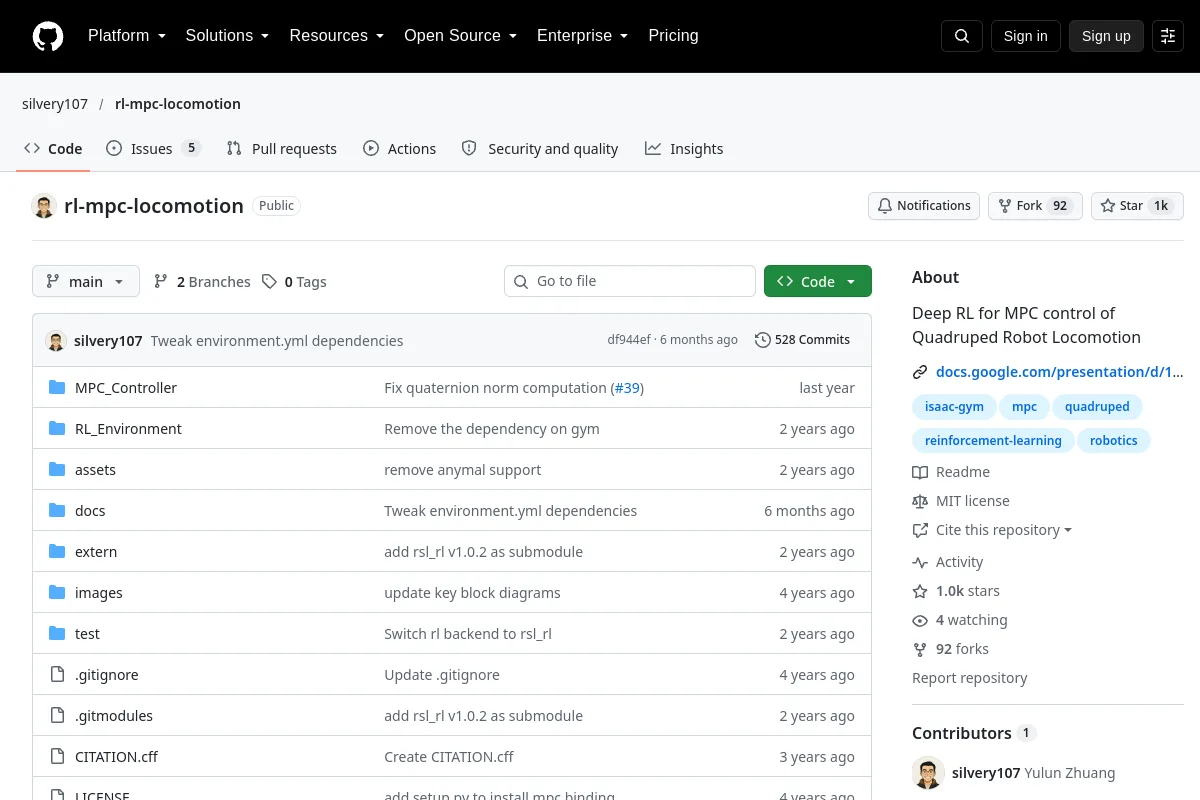 Repository
 Open source
Deep RL for MPC control of Quadruped Robot Locomotion
Motion planning & control Repository
 Open source
A modular, primitive-first, python-first PyTorch library for Reinforcement Learning.
Robot learning frameworks Repository
 Open source
C++ robotics library for kinematics, dynamics, motion planning, and control.
Visualization & data toolsKnow a resource that belongs here?