 Repository
 Open source
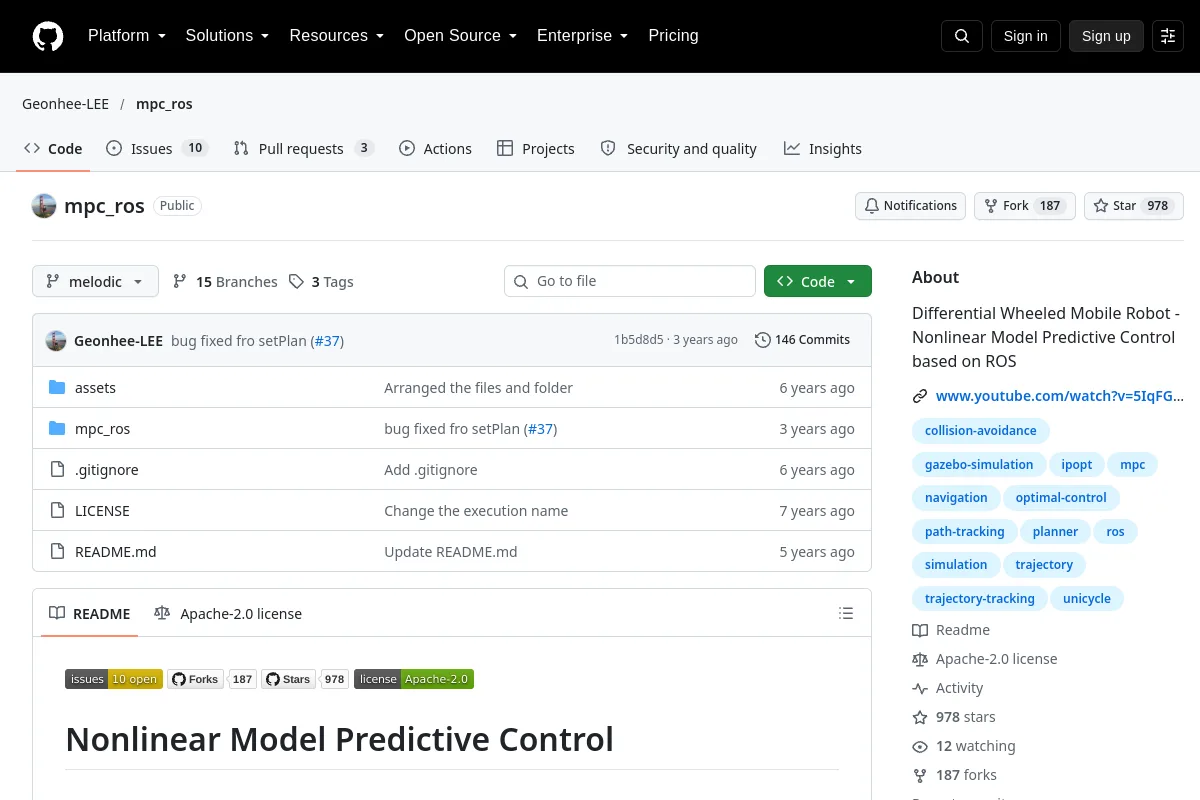
mpc_ros · Geonhee-LEE
Differential Wheeled Mobile Robot - Nonlinear Model Predictive Control based on ROS
Motion planning & controlTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Open source
Differential Wheeled Mobile Robot - Nonlinear Model Predictive Control based on ROS
Motion planning & control Repository
 Open source
This repository implements Motion Planning Diffusion (MPD) - a method for learning and planning robot motions with diffusion models.
Motion planning & control Repository
 Open source
A C++/CUDA implementation of Model Predictive Path Integral control.
Motion planning & control Repository
 Open source
Motion Planning Templates creates fast, parallel, robot-specific motion planners.
Motion planning & control Repository
 Open source
ROS 2 nodes wrapping core MRPT functionality: localization, autonomous navigation, rawlogs, etc. SLAM is in other packages.
Navigation & SLAM Repository
 Open source
A modularized multi-robot SLAM system with elevation mapping and a costmap converter for easy navigation. Different odometry and loop closure algorithms can be easily integrated into the system.
Navigation & SLAM Repository
 Open source
CVPR 2026 - MSGNav: Unleashing the Power of Multi-modal 3D Scene Graph for Zero-Shot Embodied Navigation
Navigation & SLAM Repository
 Repository
 Open source
MuJoCo locomotion RL experiments with PPO and domain randomization.
Motion planning & control Repository
 Open source
ROS2 control package for Mujoco simulation physics simulator, including plugins for various sensors, RGB-D cameras, and lidar.
Simulation & physics Repository
 Open source
Interactive browser scene editor for MuJoCo robot and mesh scenes.
Simulation & physics Repository
 Open source
Performance-guided data-collection research for on-robot learning.
Robot learning frameworks Repository
 Open source
Python multi-panel viewer for MuJoCo simulation.
Simulation & physics Repository
 Open source
"Multi-robot Coordination with Agent-Server Architecture for Autonomous Navigation in Partially Unknown Environments", IROS 2020
Navigation & SLAM Repository
 Open source
The autonomous exploration army project consists of 1 aerial vehicle and 2 ground vehicles, utilizing ROS 2 and the Gazebo simulation environment.
Simulation & physics Repository
 Open source
Hybrid motion planner related to "Trajectory Planning for Quadrotor Swarms" and "Trajectory Planning for Heterogeneous Robot Teams" papers
Motion planning & control Repository
 Open source
A drone swarm simulator based on ROS (Robot Operating System).
Simulation & physics Repository
 Repository
 Open source
Open project for biped robot with c++. Cross OS, cross simulation platform or even real robot.
Simulation & physics Repository
 Open source
🦕 nanosaur is a little robot, powered by ROS 2. Made for NVIDIA Jetson
Middleware & communication Repository
 Open source
MCP server that provides tools and resources to control and monitor robots using Nav2.
Navigation & SLAM Repository
 Open source
Arduino UNO-compatible robotic simulation of the C. elegans nematode
Simulation & physics Repository
 Open source
NeRF-SLAM: Real-Time Dense Monocular SLAM with Neural Radiance Fields. https://arxiv.org/abs/2210.13641 + Sigma-Fusion: Probabilistic Volumetric Fusion for Dense Monocular SLAM…
Navigation & SLAM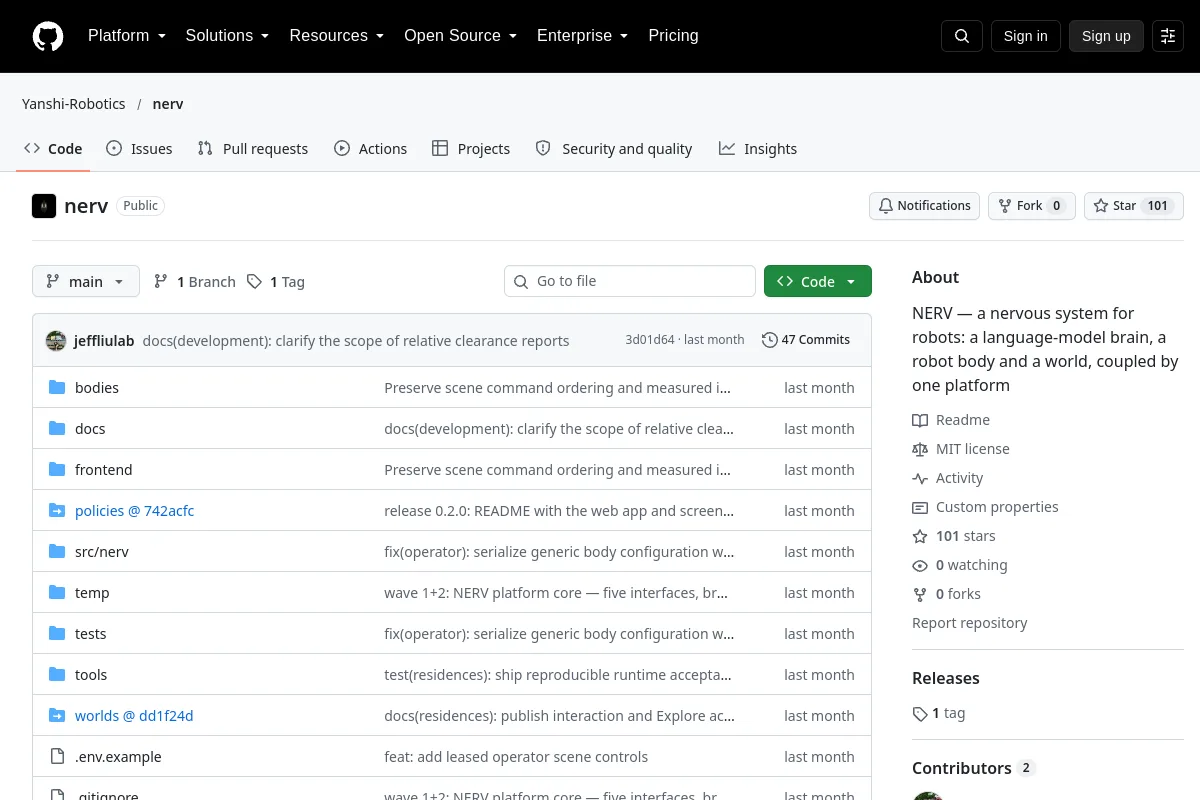 Repository
 Open source
NERV — a nervous system for robots: a language-model brain, a robot body and a world, coupled by one platform
Middleware & communicationKnow a resource that belongs here?