 Repository
THE EMBODIED AI DIRECTORY
Middleware & communication
Explore messaging and dataflow infrastructure for distributed robotic systems.
Repository
 Repository
 Repository
 Open source
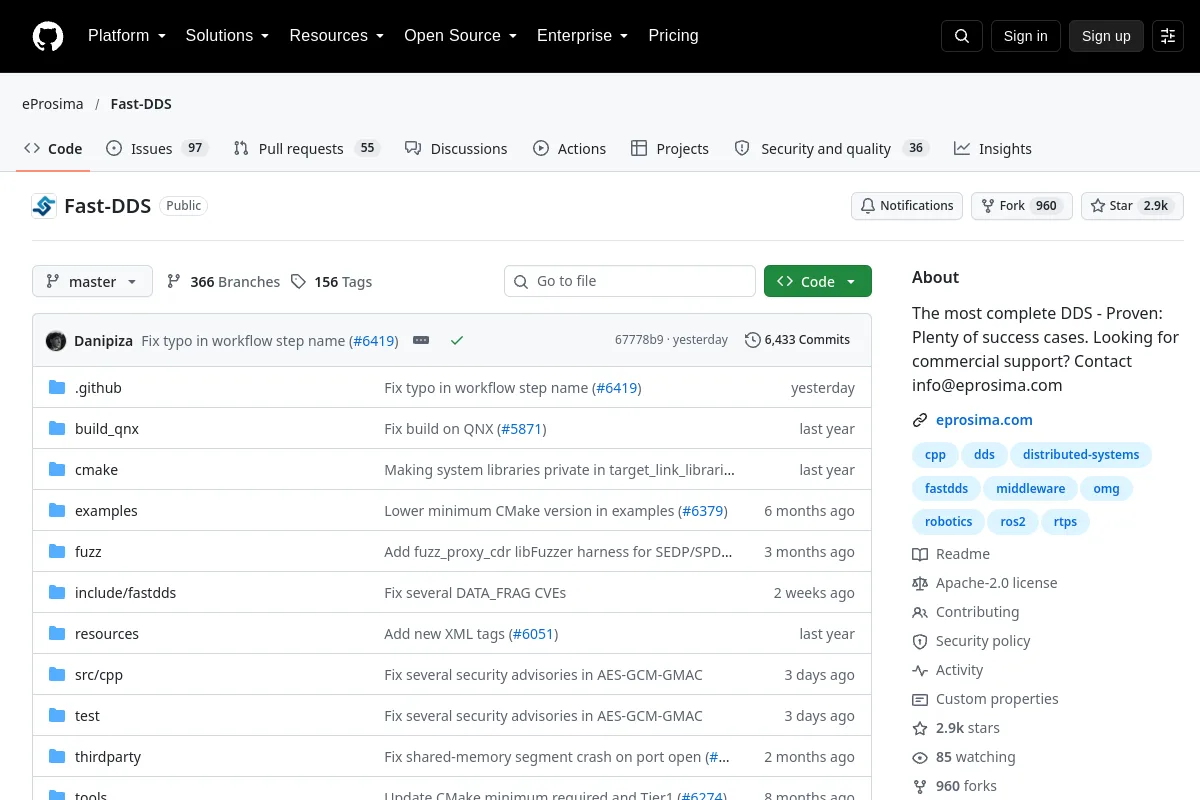
Fast DDS · eProsima
DDS communication middleware with implementation and documentation resources.
Middleware & communication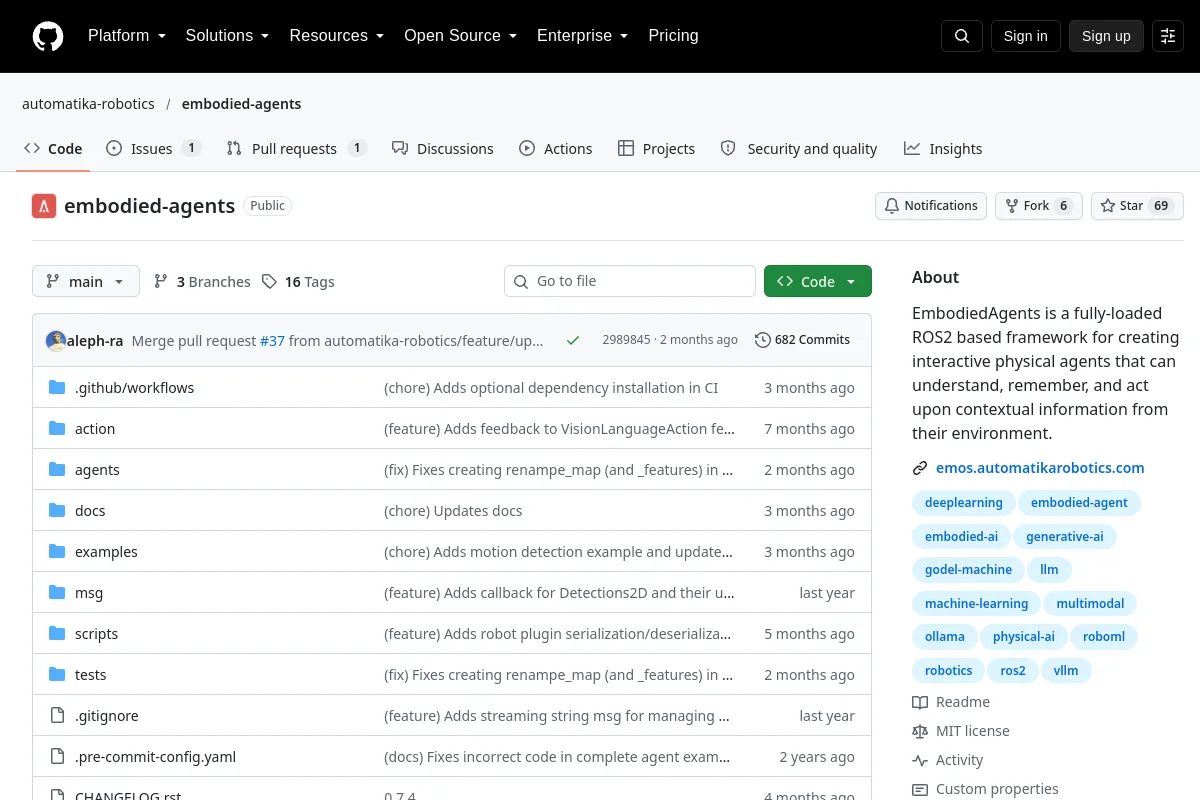 Repository
 Open source
embodied-agents · automatika-robotics
EmbodiedAgents is a fully-loaded ROS2 based framework for creating interactive physical agents that can understand, remember, and act upon contextual information from their environment.
Middleware & communication Repository
 Open source
generate_parameter_library · PickNikRobotics
Declarative ROS 2 Parameters
Middleware & communication Repository
 Open source
rmw fastrtps · ros2
ROS 2 middleware implementation using eProsima Fast DDS.
Middleware & communication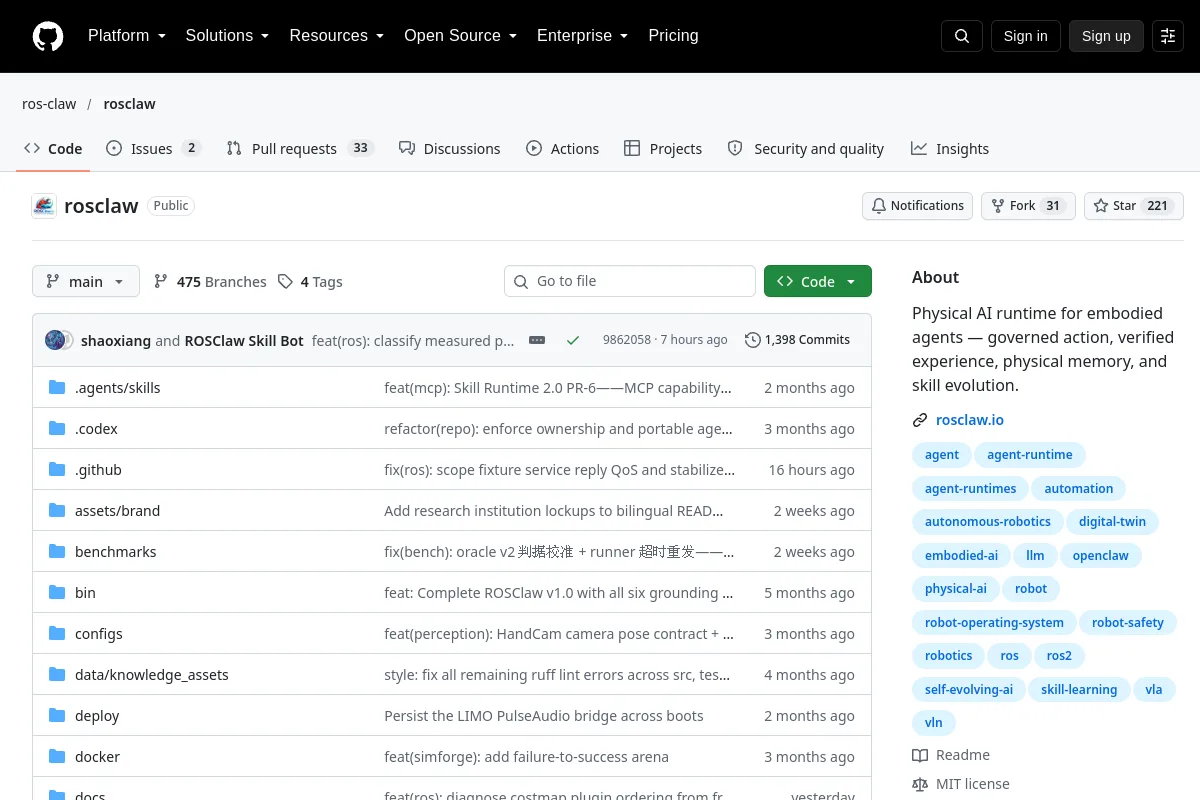 Repository
 Open source
rosclaw · ros-claw
Physical AI runtime for embodied agents — governed action, verified experience, physical memory, and skill evolution.
Middleware & communication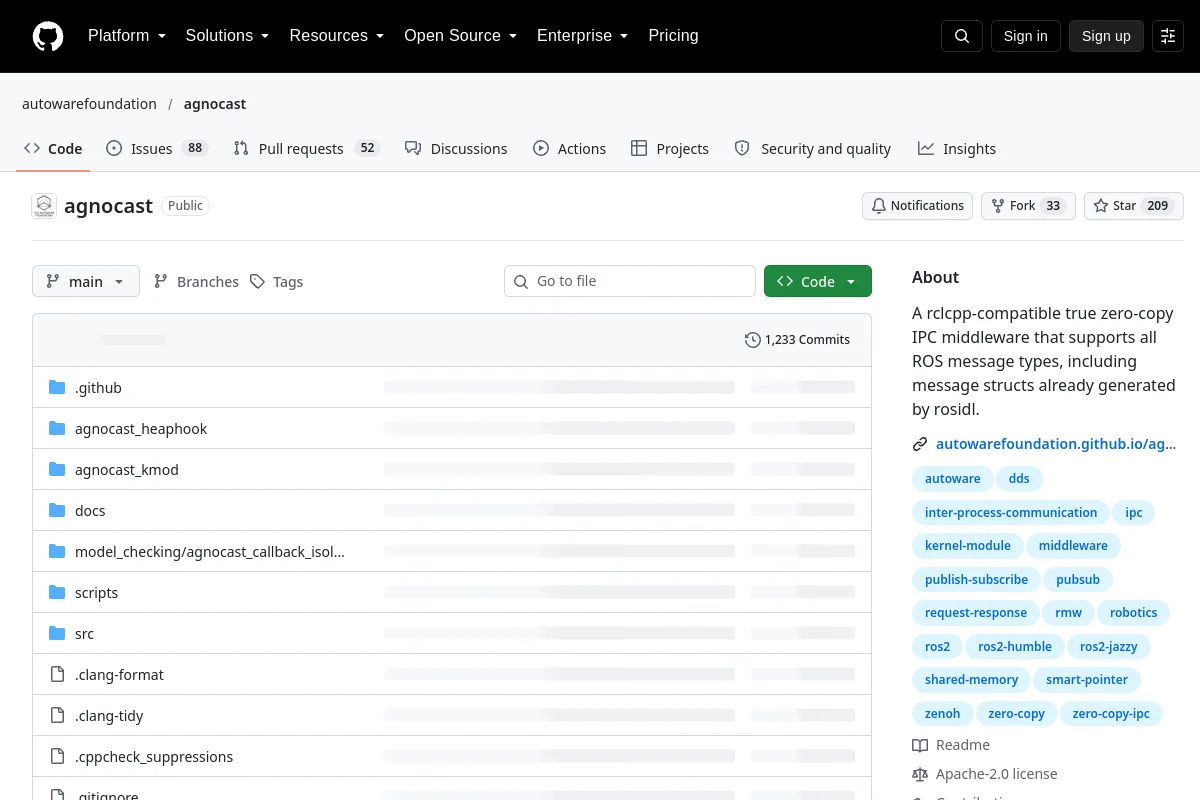 Repository
 Open source
agnocast · autowarefoundation
A rclcpp-compatible true zero-copy IPC middleware that supports all ROS message types, including message structs already generated by rosidl.
Middleware & communication Repository
 Open source
cerulion · cerulion-inc
The open-source robot runtime that records a run, re-executes it against new code, and returns an exit code.
Middleware & communication Repository
 Open source
horus · softmata
Fastest Robotics Runtime System. If phones have Android, robots deserve HORUS.
Middleware & communication Repository
 Open source
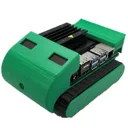
nanosaur · rnanosaur
🦕 nanosaur is a little robot, powered by ROS 2. Made for NVIDIA Jetson
Middleware & communication Repository
 Open source
nerv · Yanshi-Robotics
NERV — a nervous system for robots: a language-model brain, a robot body and a world, coupled by one platform
Middleware & communication Repository
 Open source
ogma · nasa
Generator of runtime monitors for flight and robotics applications.
Middleware & communication Repository
 Open source
OM1 · OpenMind
Modular hardware-abstraction framework for robot AI systems.
Middleware & communication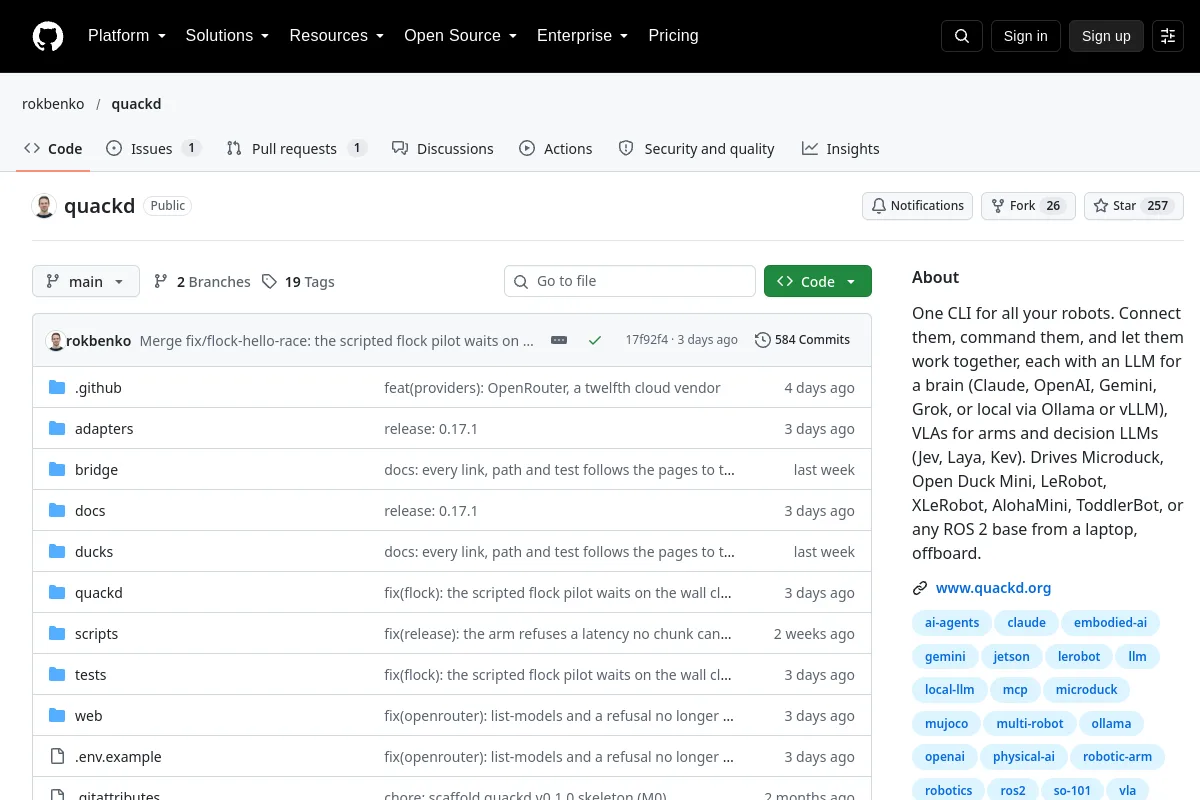 Repository
 Open source
quackd · rokbenko
One CLI for all your robots. Connect them, command them, and let them work together, each with an LLM for a brain (Claude, OpenAI, Gemini, Grok, or local via Ollama or vLLM), VLAs for arms and…
Middleware & communication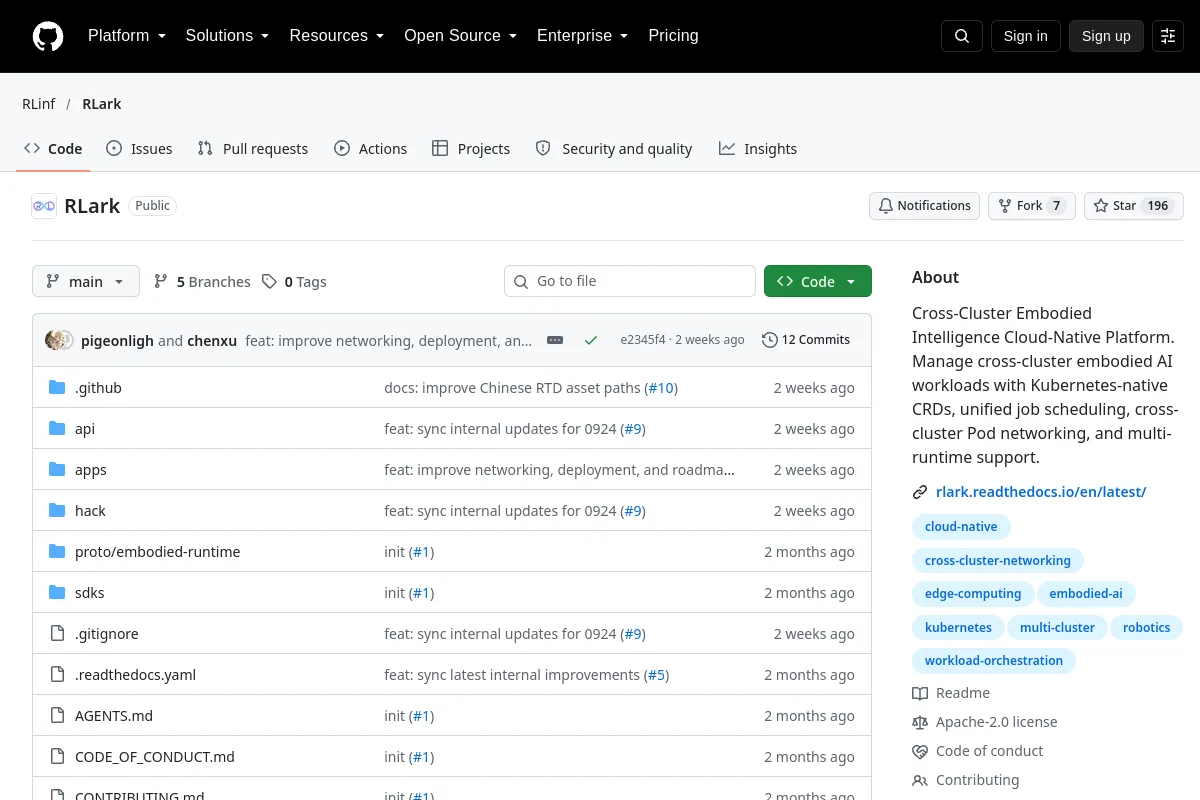 Repository
 Open source
RLark · RLinf
Cross-Cluster Embodied Intelligence Cloud-Native Platform. Manage cross-cluster embodied AI workloads with Kubernetes-native CRDs, unified job scheduling, cross-cluster Pod networking, and…
Middleware & communication Repository
 Repository
 Open source
RoboCrew · Grigorij-Dudnik
🦾Make your robot autonomous with LLM agent. Set it up with the same ease as normal agents in CrewAI or Autogen
Middleware & communication Repository
 Repository
 Open source
robot-control-stack · RobotControlStack
A lean, ROS-free sim-to-real framework for training and deploying Vision-Language-Action (VLA) models and RL agents. Native MuJoCo Gymnasium wrappers with synchronous execution for Franka, UR5e…
Middleware & communication Repository
 Open source
ros2-for-unity · RobotecAI
High-performance ROS2 solution for Unity3D
Middleware & communication Repository
 Open source
ros-mcp-server · robotmcp
Connect AI models like Claude & GPT with robots using MCP and ROS.
Middleware & communication Repository
 Open source
SMACC2 · robosoft-ai
An Event-Driven, Asynchronous, Behavioral State Machine Library for ROS2 (Robotic Operating System) applications written in C++
Middleware & communication Repository
 Open source
UltraBot · LeapLabTHU
Towards Expert-level Autonomous Carotid Ultrasonography with Large-scale Learning-based Robotic System
Middleware & communicationSELECTION NOTES
Choosing middleware & communication
Compare delivery semantics, timing, transport security and integration requirements. Verify compatibility with the selected ROS distribution or runtime instead of assuming drop-in replacement.
A PLACE FOR YOUR NEXT DISCOVERY
Suggest a resource ↗The ecosystem keeps growing.
Know a resource that belongs here?