 Repository
 Open source
PPI · InternRobotics
Gripper Keypose and Object Pointflow as Interfaces for Bimanual Robotic Manipulation
Robot policiesTHE EMBODIED AI DIRECTORY
Explore vision-language-action models and robotics foundation models for perception, manipulation and control.
Repository
Open source
Gripper Keypose and Object Pointflow as Interfaces for Bimanual Robotic Manipulation
Robot policies Repository
 Open source
Official implementation of "Learning Diverse Natural Behaviors for Enhancing the Agility of Quadrupedal Robots"
Robot policies Repository
 Open source
End-to-end robot control based on generative diffusion model
Robot policies Repository
 Open source
"Sequential Dexterity: Chaining Dexterous Policies for Long-Horizon Manipulation" code repository
Robot policies Repository
 Open source
Official codebase for Sirius: Robot Learning on the Job
Robot policies Repository
 Open source
ViTacFormer: Learning Cross-Modal Representation for Visuo-Tactile Dexterous Manipulation
Robot policies Website
 Open source
An open vision-language-action model for robot manipulation.
Vision-language-action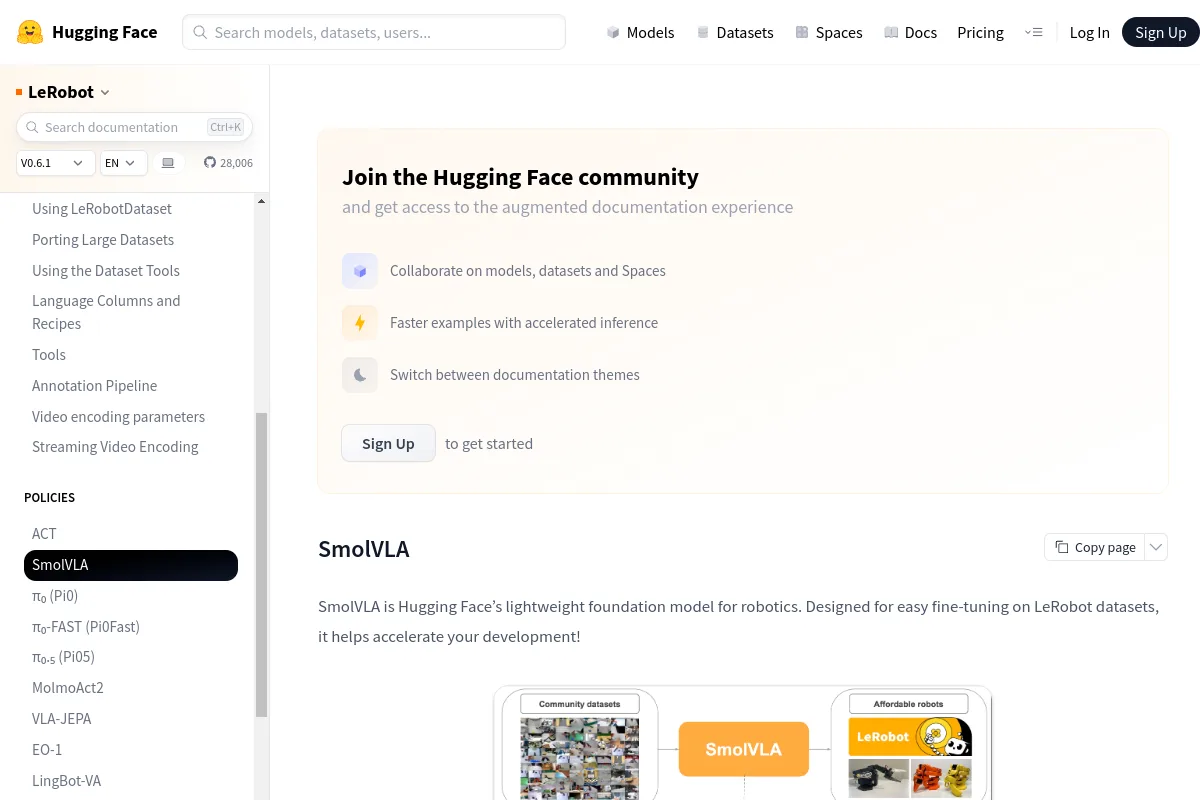 Website
 Open source
A compact vision-language-action model in the LeRobot ecosystem.
Vision-language-actionKnow a resource that belongs here?