 Repository
 Open source
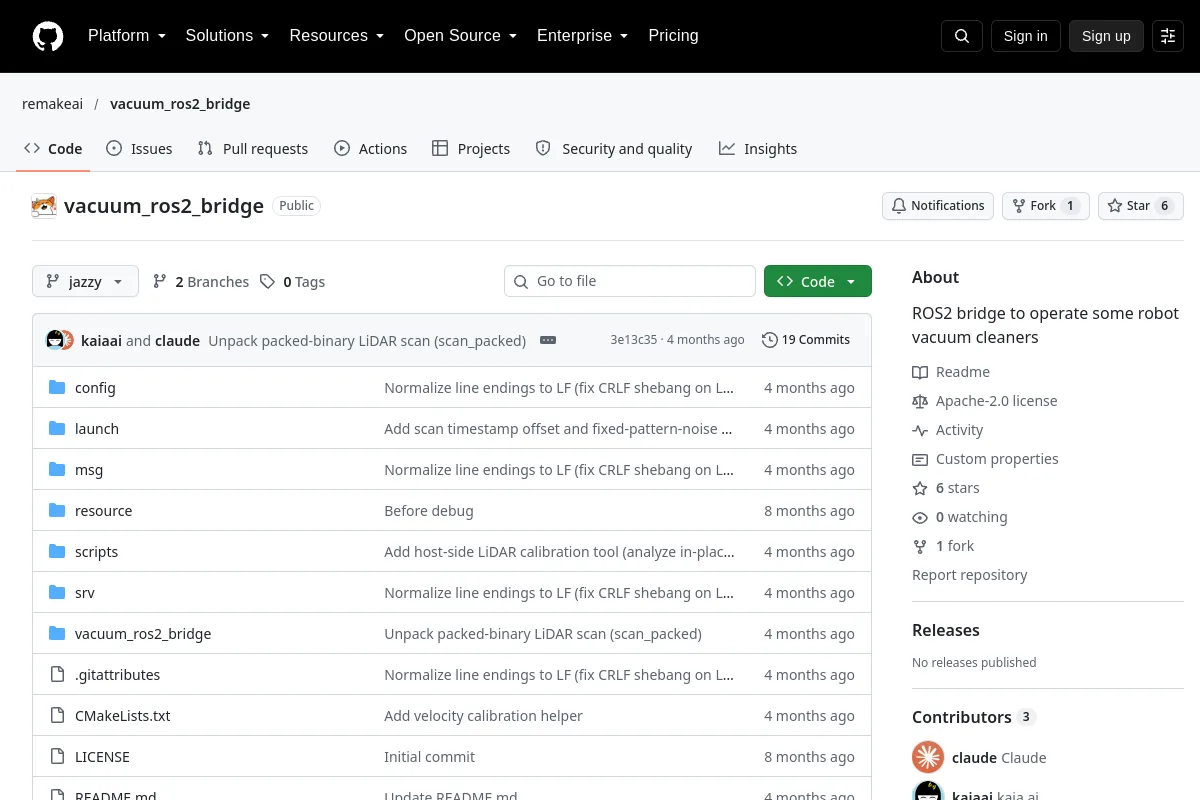
vacuum_ros2_bridge · remakeai
ROS2 bridge to operate some robot vacuum cleaners
Robot SDKsTHE EMBODIED AI DIRECTORY
Explore manufacturer and project SDKs for communicating with robotic hardware.
Repository
Open source
ROS2 bridge to operate some robot vacuum cleaners
Robot SDKs Repository
 Open source
Universal Robots ROS2 driver supporting CB3 and e-Series
Robot SDKs Repository
 Repository
 Repository
 Open source
Experimental packages for ABB manipulators within ROS-Industrial (http://wiki.ros.org/abb_experimental)
Robot SDKs Repository
 Repository
 Repository
 Open source
The ctrlX AUTOMATION software development kit for ROS 2.
Robot SDKs Repository
 Repository
 Repository
 Open source
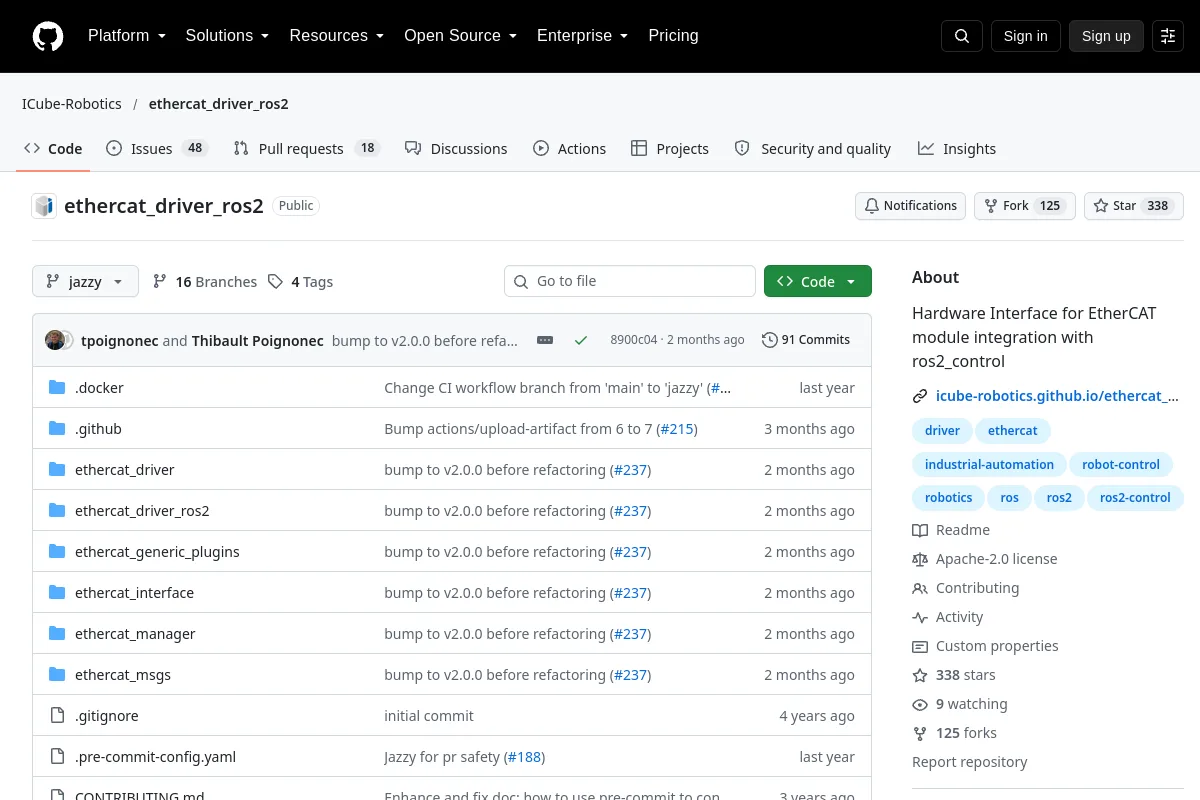
Hardware Interface for EtherCAT module integration with ros2_control
Robot SDKs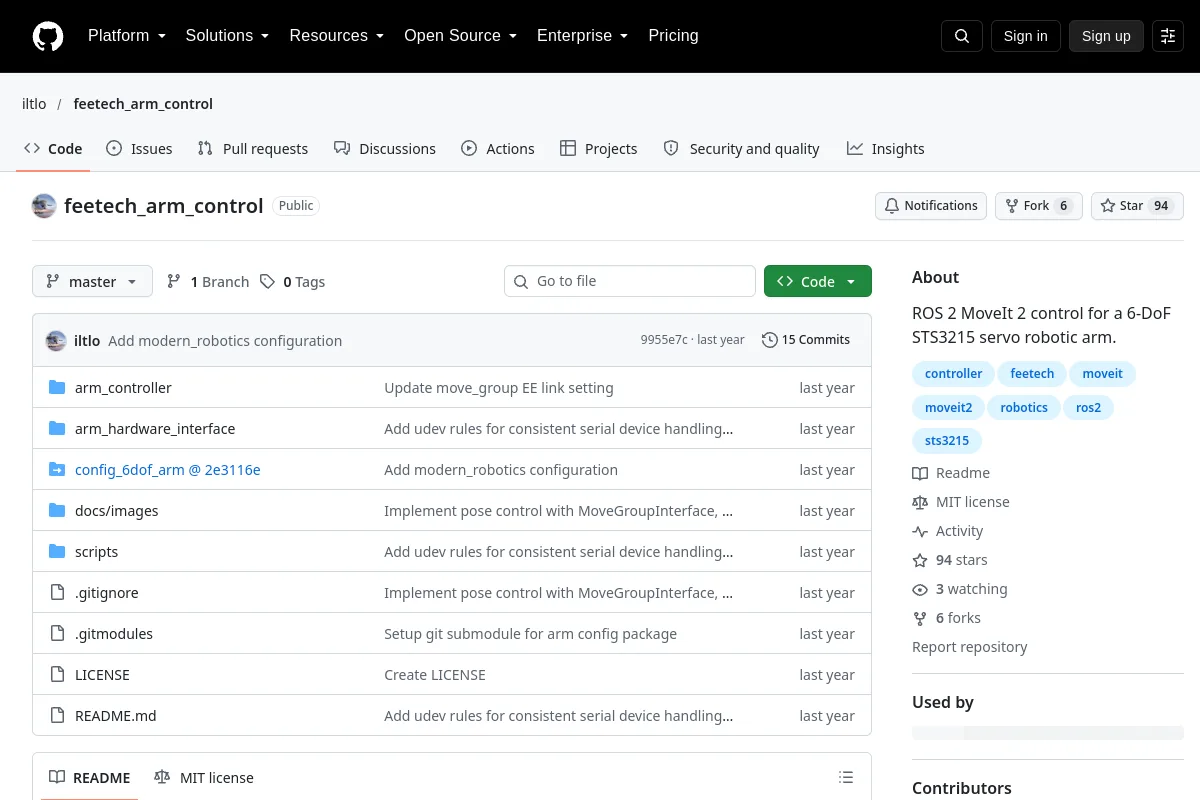 Repository
 Open source
ROS 2 MoveIt 2 control for a 6-DoF STS3215 servo robotic arm.
Robot SDKs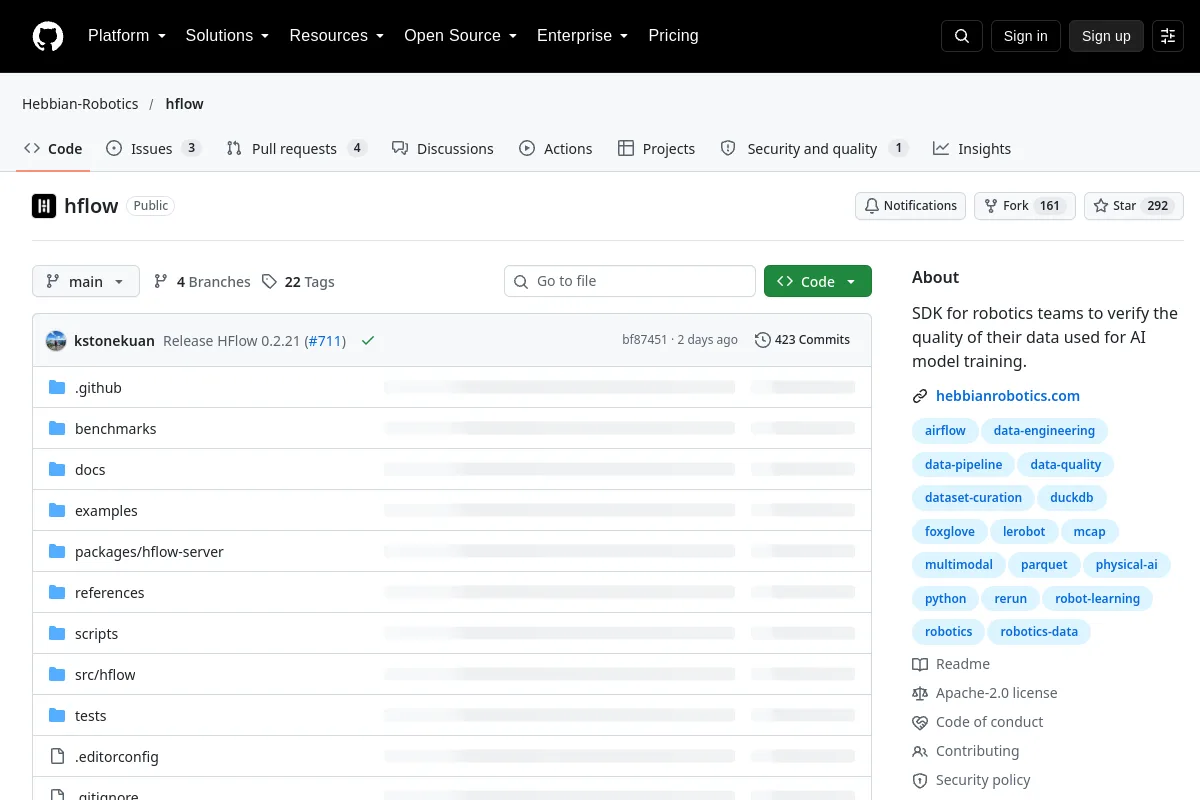 Repository
 Open source
SDK for robotics teams to verify the quality of their data used for AI model training.
Robot SDKs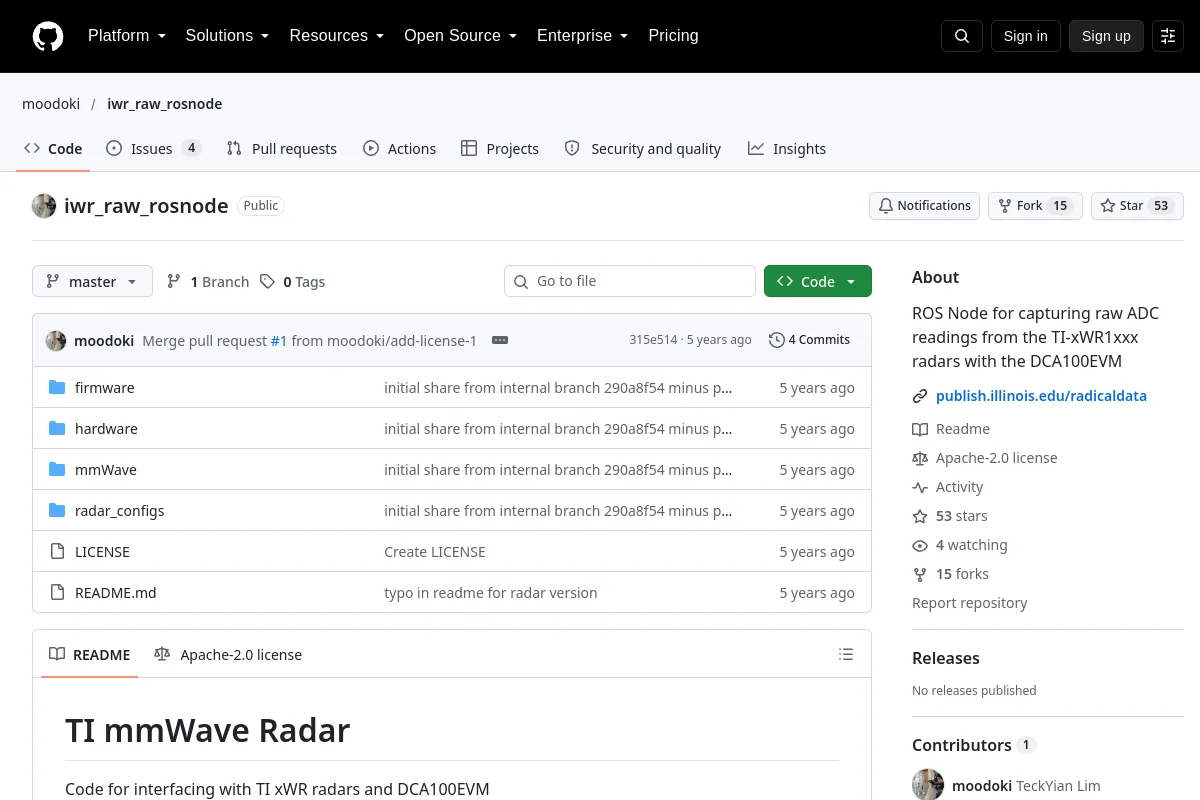 Repository
 Open source
ROS Node for capturing raw ADC readings from the TI-xWR1xxx radars with the DCA100EVM
Robot SDKs Repository
 Open source
Experimental packages for KUKA manipulators within ROS-Industrial (http://wiki.ros.org/kuka_experimental)
Robot SDKs Repository
 Repository
 Repository
 Open source
OnRobot packages (https://wiki.ros.org/onrobot)
Robot SDKs Repository
 Repository
 Repository
 Open source
Python communication library and alternative SDK for the Cozmo robot.
Robot SDKs Repository
 Open source
Library to control Robotiq company grippers from python
Robot SDKs Repository
 Repository
 Open source
ROS package of helper functions related to bringing up roslaunch on system startup.
Robot SDKsSELECTION NOTES
Confirm model, firmware and transport compatibility in the publisher’s documentation. An SDK may expose commands without providing a complete safety or autonomy stack.
Know a resource that belongs here?