 Repository
THE EMBODIED AI DIRECTORY
Software
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
 Repository
 Open source
sim2real-robot-identification · iit-DLSLab
A joints calibration routine for quadrupeds and manipulators to facilitate sim-to-real transfer from isaaclab and mujoco to real robots
Simulation & physics Repository
 Open source
Universal_Robots_ROS2_Gazebo_Simulation · UniversalRobots
Using the repository
Simulation & physics Repository
 Open source
LeRobot-Anything-U-Arm · MINT-SJTU
U-Arm: Lerobot-Everything-Cross-Embodiment-Teleoperation
Teleoperation software Repository
 Open source
score lerobot episodes · RoboticsData
Toolkit for quantitatively scoring LeRobot data episodes.
Perception & geometry Repository
 Open source
openMVG · openMVG
Multiple-view geometry and structure-from-motion library.
Perception & geometry Repository
 Open source
NvEM · MarSaKi
Official repo of "Neighbor-view Enhanced Model for Vision and Language Navigation"
Navigation & SLAM Repository
 Open source
PointNav-VO · Xiaoming-Zhao
Official implementation of "The Surprising Effectiveness of Visual Odometry Techniques for Embodied PointGoal Navigation"
Navigation & SLAM Repository
 Open source
TopologicalSemanticGraphMemory · rllab-snu
Topological Semantic Graph Memory for Image Goal Navigation (CoRL 2022 oral)
Navigation & SLAM Repository
 Open source
cuRobo
Accelerated motion-generation tools for robot manipulation.
Motion planning & control Repository
 Open source
PIN_SLAM · PRBonn
📍PIN-SLAM: LiDAR SLAM Using a Point-Based Implicit Neural Representation for Achieving Global Map Consistency [TRO 24]
Navigation & SLAM Repository
 Open source
Swarm-SLAM · MISTLab
Sparse Decentralized Collaborative Simultaneous Localization and Mapping Framework for Multi-Robot Systems
Navigation & SLAM Repository
 Open source
Voyager · MineDojo
Research implementation of an open-ended language-model agent in Minecraft.
Robot learning frameworks Repository
 Open source
arnold · arnold-benchmark
A benchmark for language-grounded robot manipulation in realistic 3D scenes.
Robot learning frameworks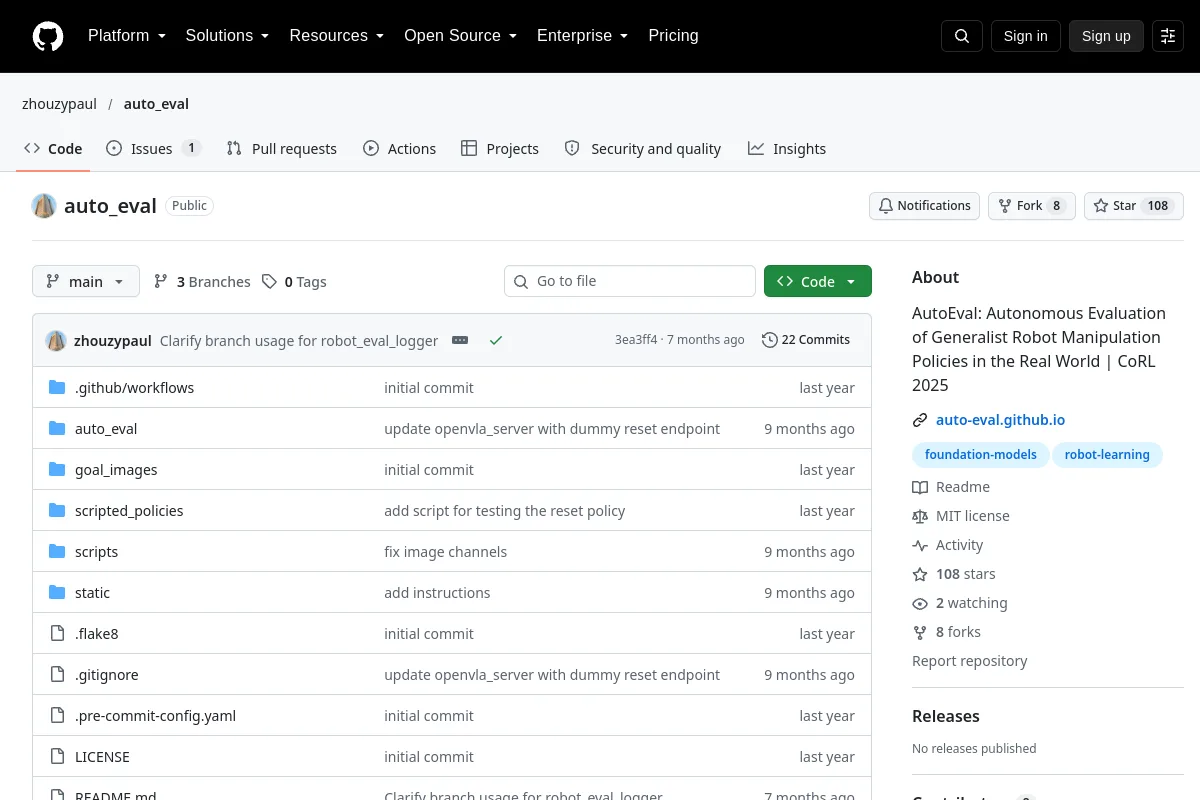 Repository
 Open source
auto_eval · zhouzypaul
AutoEval: Autonomous Evaluation of Generalist Robot Manipulation Policies in the Real World | CoRL 2025
Robot learning frameworks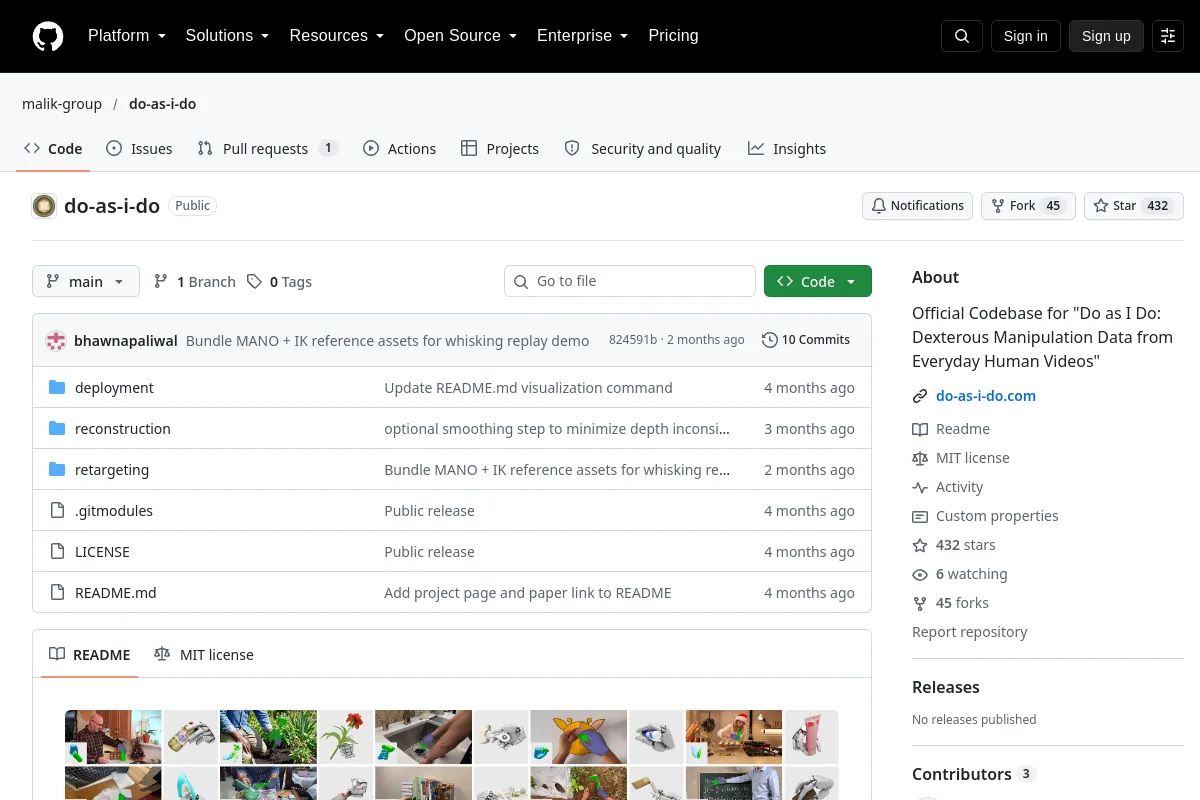 Repository
 Open source
do-as-i-do · malik-group
Official Codebase for "Do as I Do: Dexterous Manipulation Data from Everyday Human Videos"
Robot learning frameworks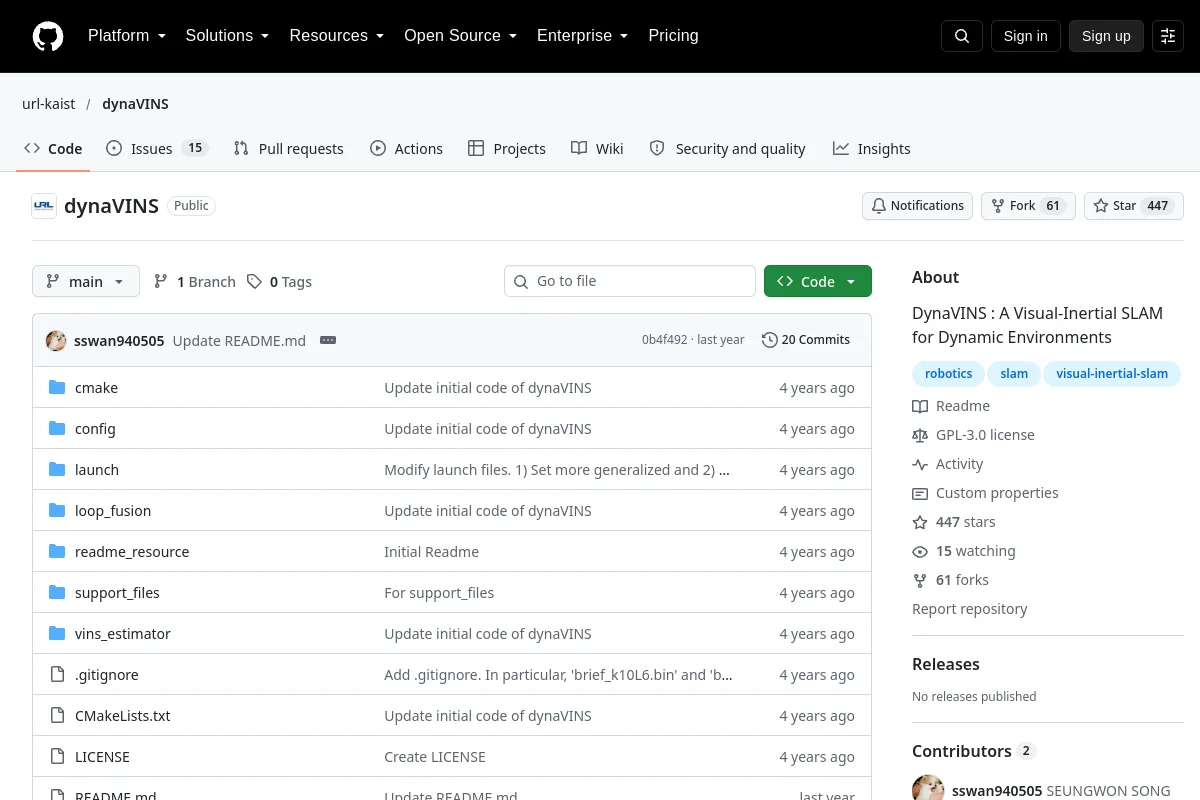 Repository
 Open source
dynaVINS · url-kaist
DynaVINS : A Visual-Inertial SLAM for Dynamic Environments
Navigation & SLAM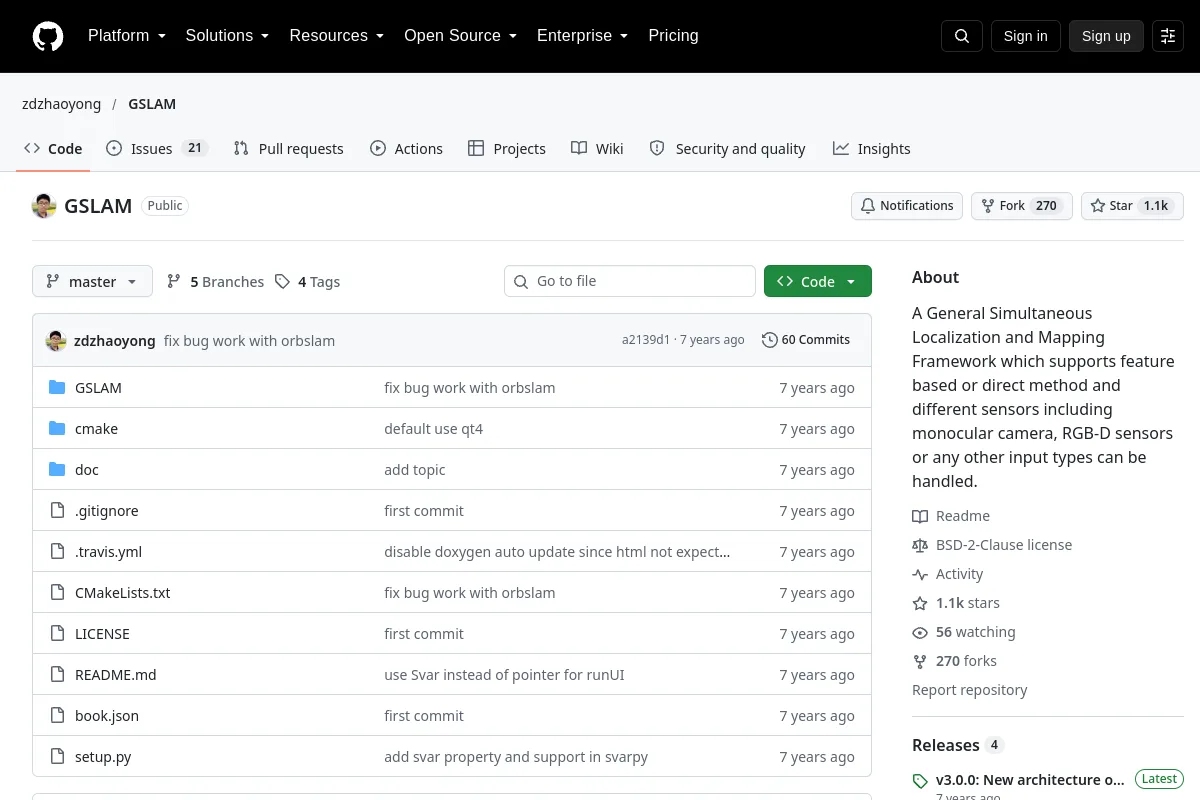 Repository
 Open source
GSLAM · zdzhaoyong
A General Simultaneous Localization and Mapping Framework which supports feature based or direct method and different sensors including monocular camera, RGB-D sensors or any other input types can…
Navigation & SLAM Repository
 Open source
Open-Teach · aadhithya14
A Versatile Teleoperation framework for Robotic Manipulation using Meta Quest3
Teleoperation software Repository
 Open source
vision-in-action · haoyu-x
An open-source, full-stack robotic neck for active perception
Perception & geometry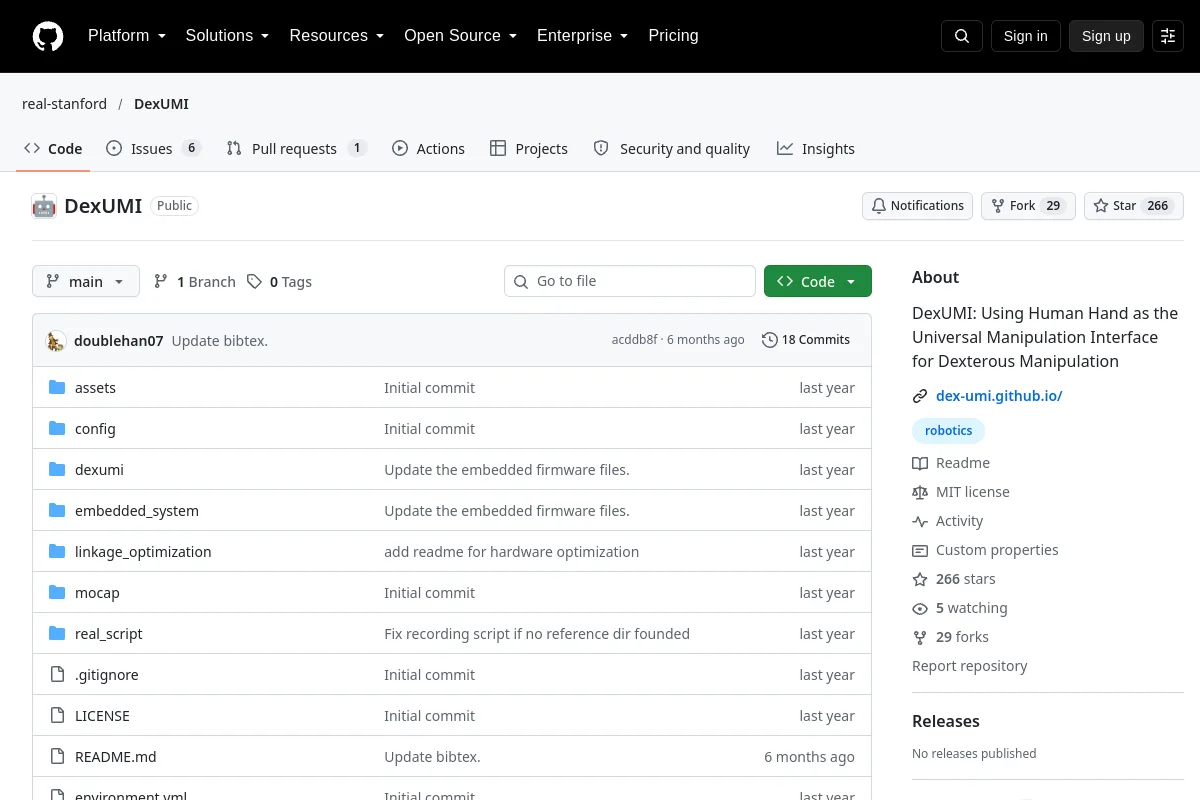 Repository
 Open source
DexUMI · real-stanford
DexUMI: Using Human Hand as the Universal Manipulation Interface for Dexterous Manipulation
Teleoperation software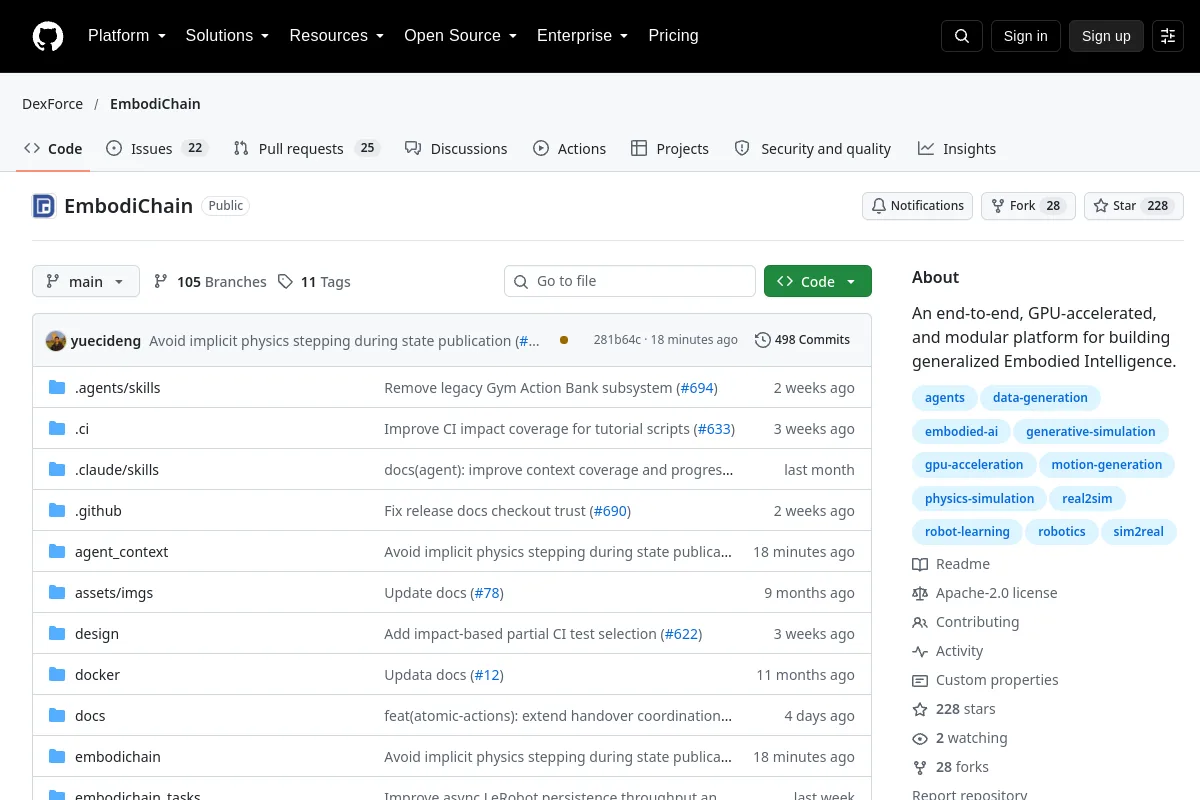 Repository
 Open source
EmbodiChain · DexForce
Modular platform for embodied intelligence simulation and learning workflows.
Simulation & physics Repository
 Open source
mimic-video · mimic-video
Video-Action Models for Generalizable Robot Control Beyond VLAs
Robot learning frameworks Repository
 Open source
log-polar-descriptors · cvlab-epfl
Public implementation of "Beyond Cartesian Representations for Local Descriptors", ICCV 2019
Perception & geometryA PLACE FOR YOUR NEXT DISCOVERY
Suggest a resource ↗The ecosystem keeps growing.
Know a resource that belongs here?