 Repository
 Open source
wanderland · ai4ce
Wanderland: Geometrically Grounded Simulation for Open-World Embodied AI
Simulation & physicsTHE EMBODIED AI DIRECTORY
Explore robot simulation software for physics, control and robot learning.
Repository
Open source
Wanderland: Geometrically Grounded Simulation for Open-World Embodied AI
Simulation & physics Website
 Research
A robot simulation environment with sensor models and controller interfaces.
Simulation & physics Repository
 Repository
 Open source
Force controlled assembly process. In real and simulated environment. Using Universal Robots UR5, ROS, Gazebo.
Simulation & physics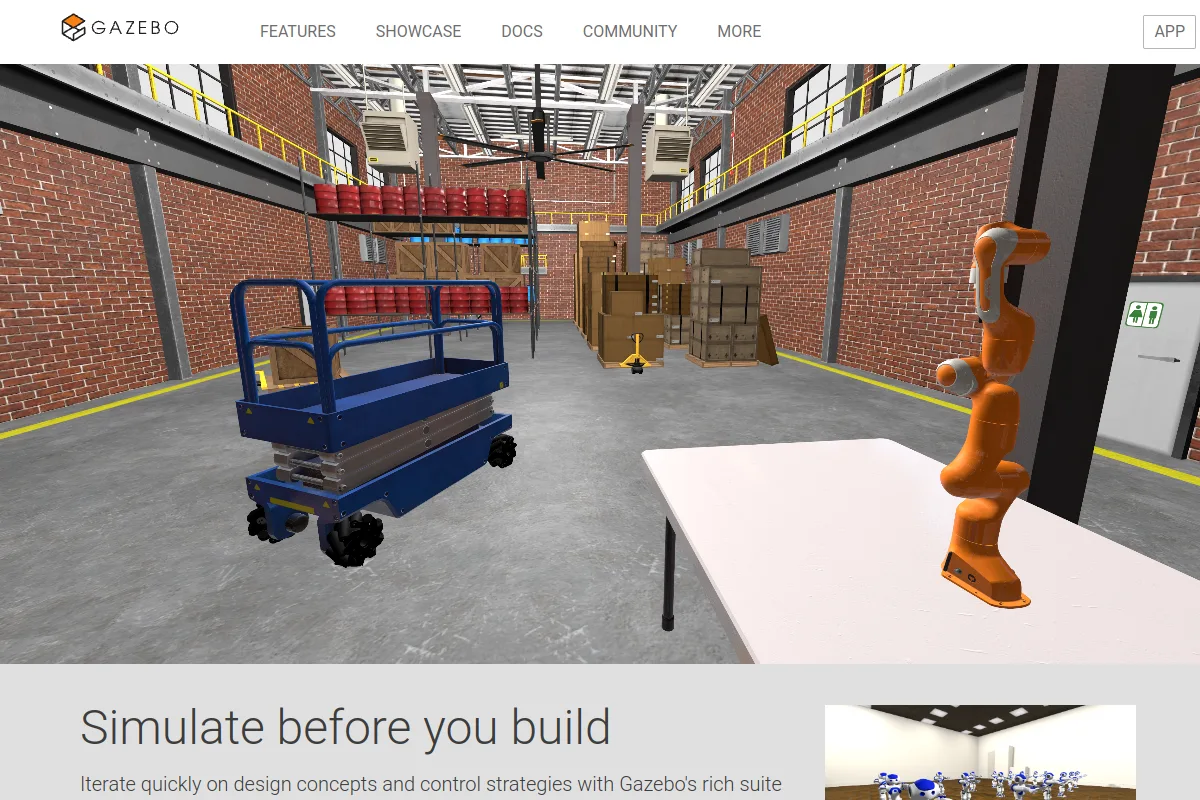 Website
 Website
 Commercial
Robotics simulation and synthetic data generation tools.
Simulation & physics Website
SELECTION NOTES
Compare physics fidelity, rendering, robot asset support and Python interfaces. MuJoCo suits physics and control experiments; Gazebo connects simulation with the ROS ecosystem; Isaac Sim supports robotics simulation and synthetic data. Check current GPU and license requirements before choosing.
Know a resource that belongs here?