 Website
 Research
Stanford IRIS
An academic lab researching intelligence in robots through interaction and learning.
Academic labsTHE EMBODIED AI DIRECTORY
Explore components, tools and organizations connected to education & research robotics. Inclusion does not certify suitability for a particular deployment.
Website
Research
An academic lab researching intelligence in robots through interaction and learning.
Academic labs Website
 Research
An academic lab working on visual understanding and embodied learning.
Academic labs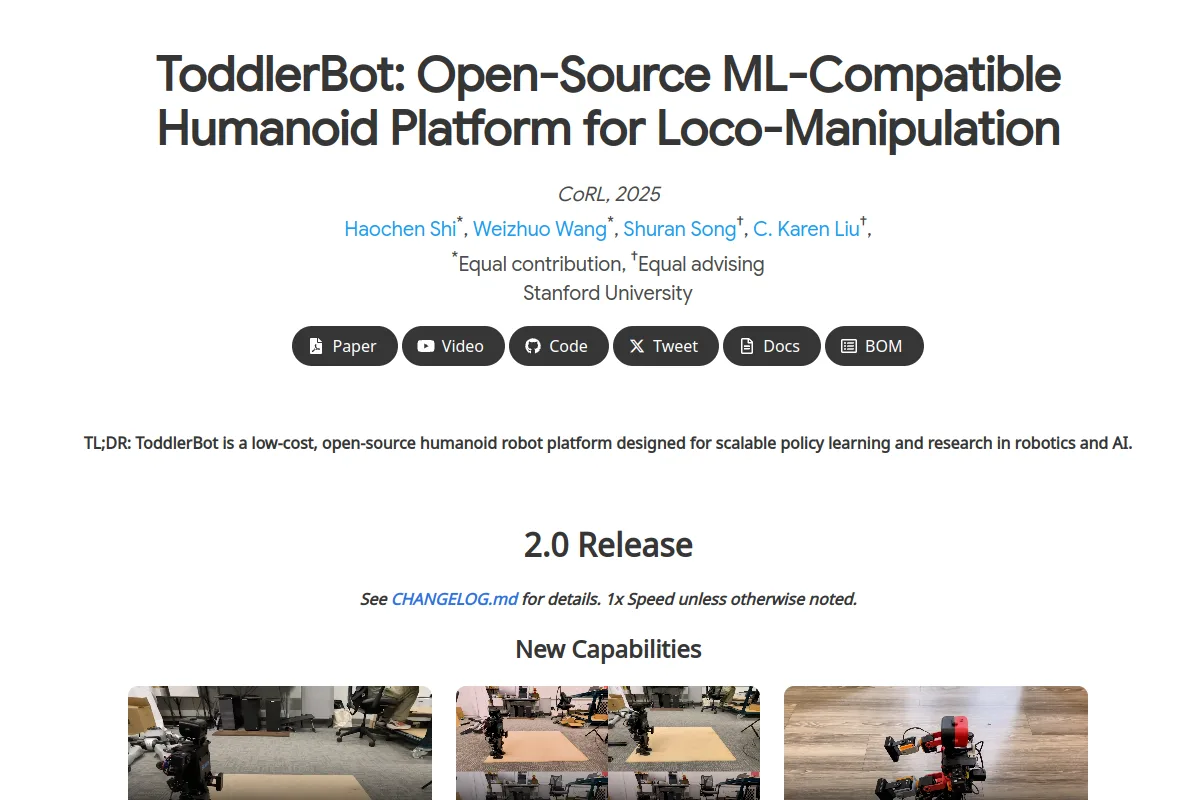 Website
 Research
A compact humanoid platform for robot learning research.
Research humanoid platforms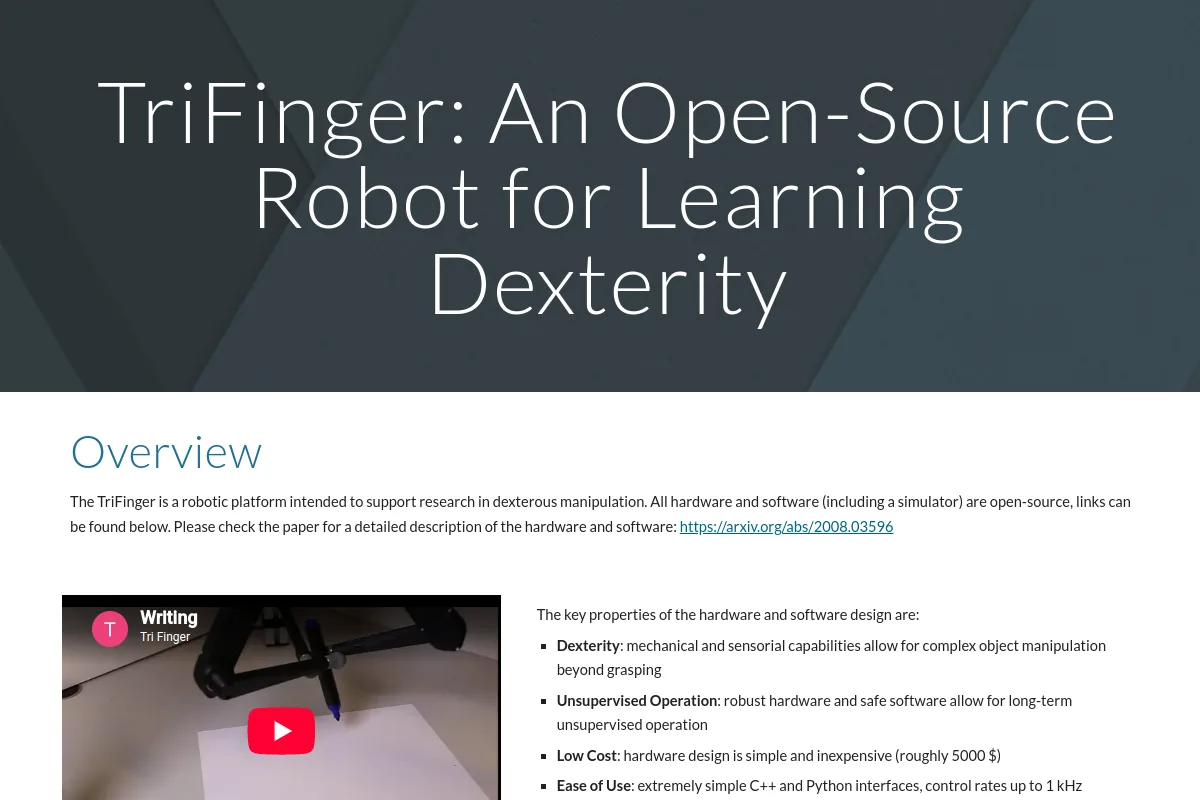 Website
 Research
A three-finger robot platform for studying dexterous manipulation.
Hands & grippers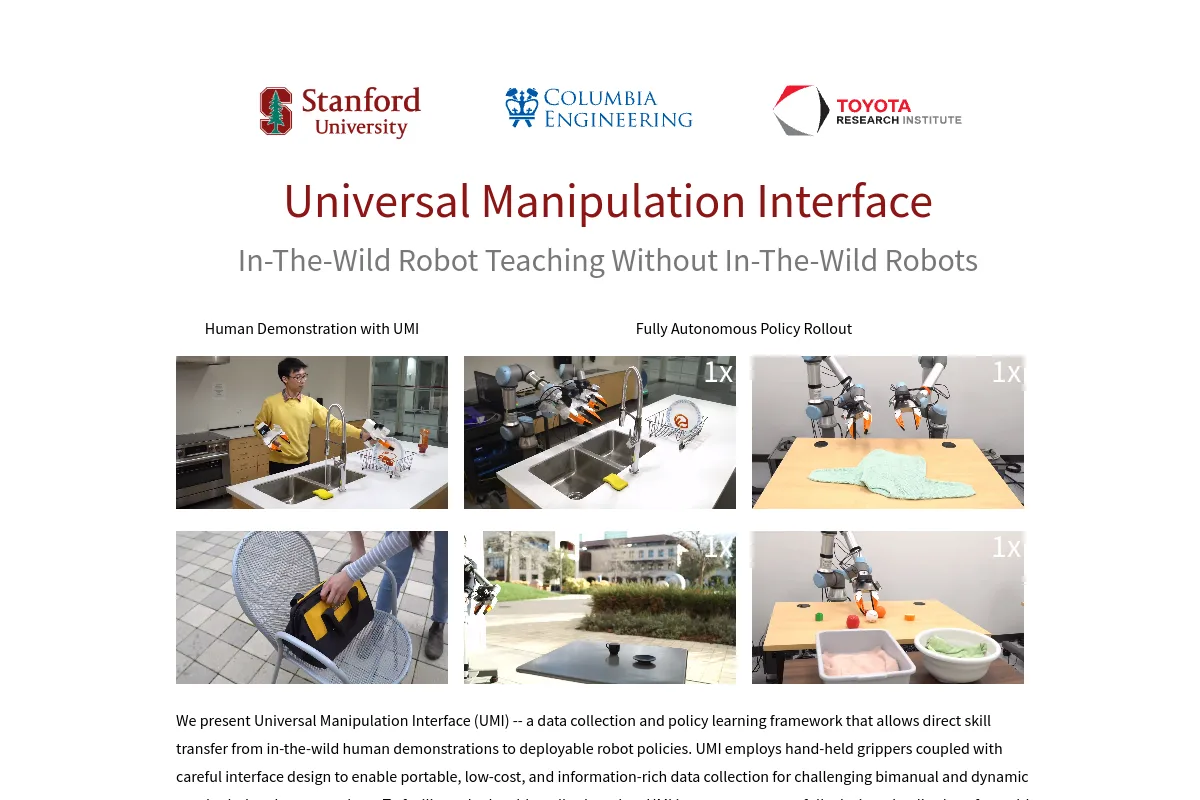 Website
 Research
A handheld interface for collecting demonstrations for robot manipulation.
Teleoperation rigs Website
 Website
 Website
 Research
A robot simulation environment with sensor models and controller interfaces.
Simulation & physics Repository
 Research
A printable robot arm project with mechanical design and assembly materials.
DIY & education hardware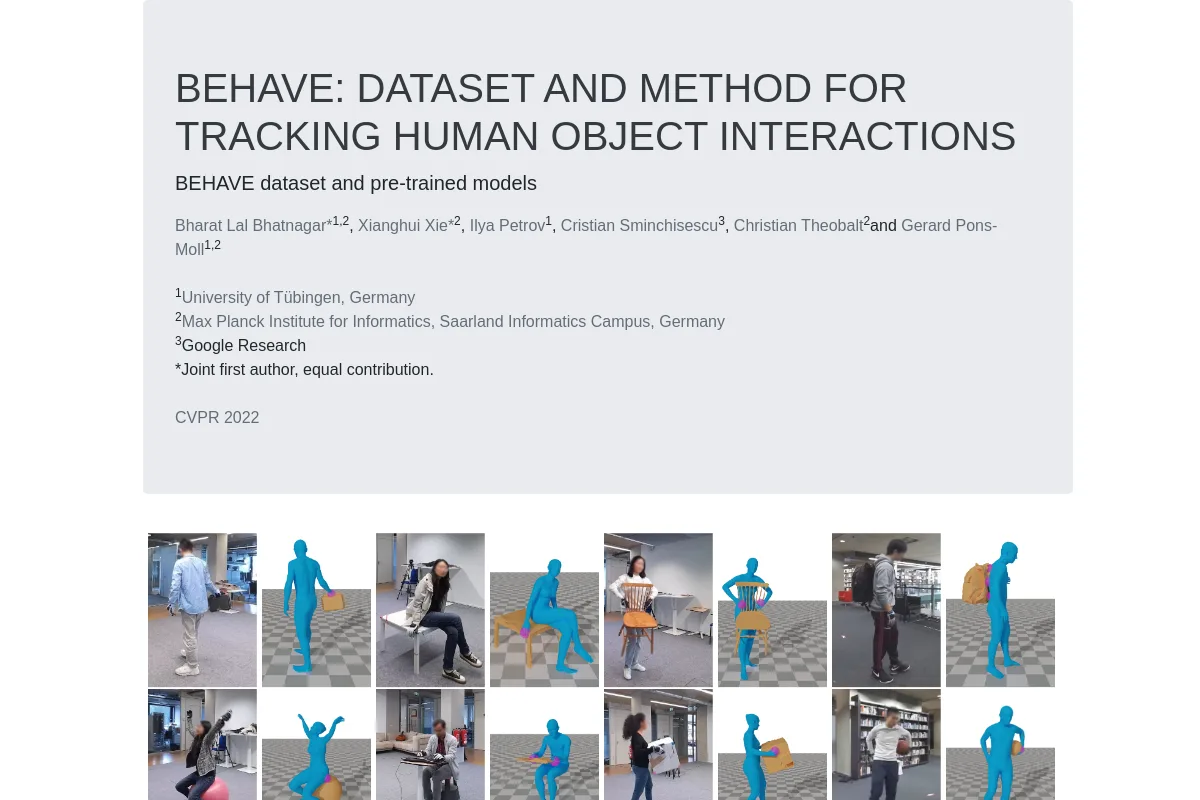 Website
 Research
Human-object interaction data for body and object reconstruction research.
Motion & interaction data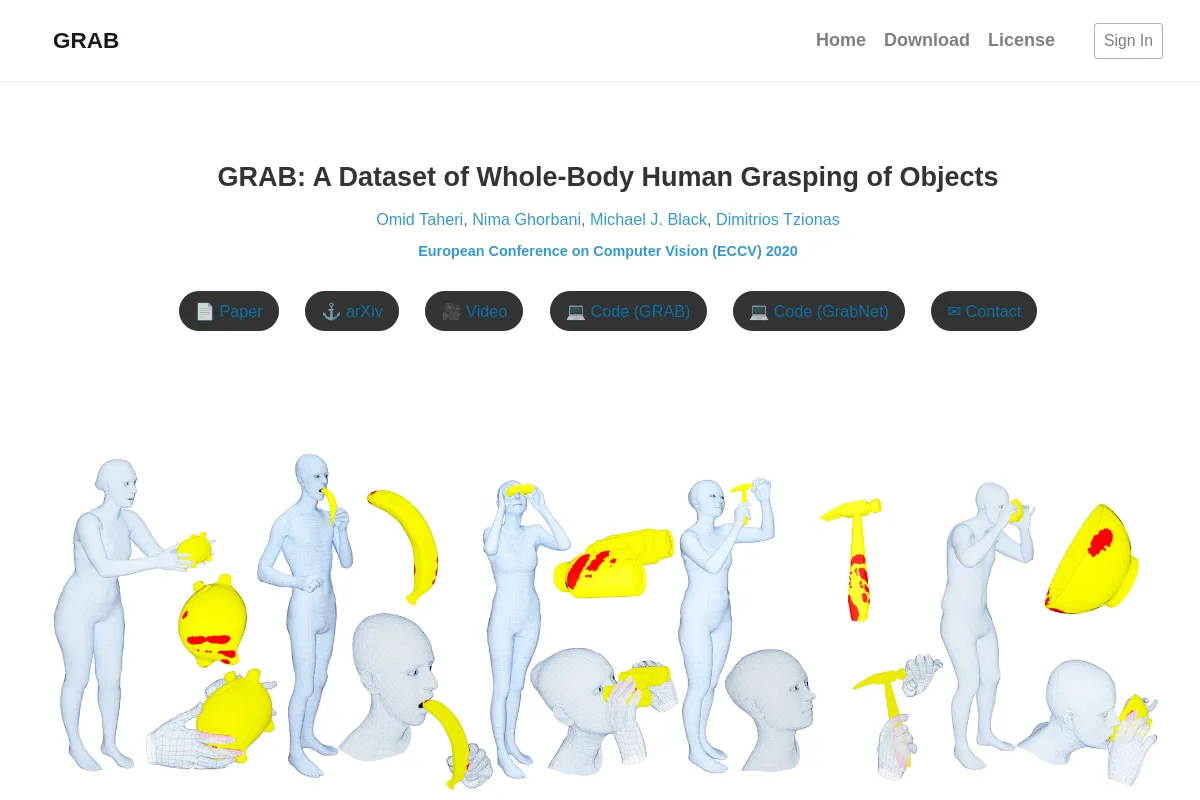 Website
 Research
Whole-body human grasping data for studying object interaction.
Motion & interaction data Website
 Website
 Research
Musculoskeletal simulation tasks for motor-control learning research.
Locomotion & whole-body control Website
 Research
3D object assets for visual learning and simulation research.
Scene & object assets Website
 Research
A demonstration collection project for robotic manipulation learning.
Robot demonstrations Website
 Research
A repository of annotated 3D shapes for perception and scene research.
Scene & object assets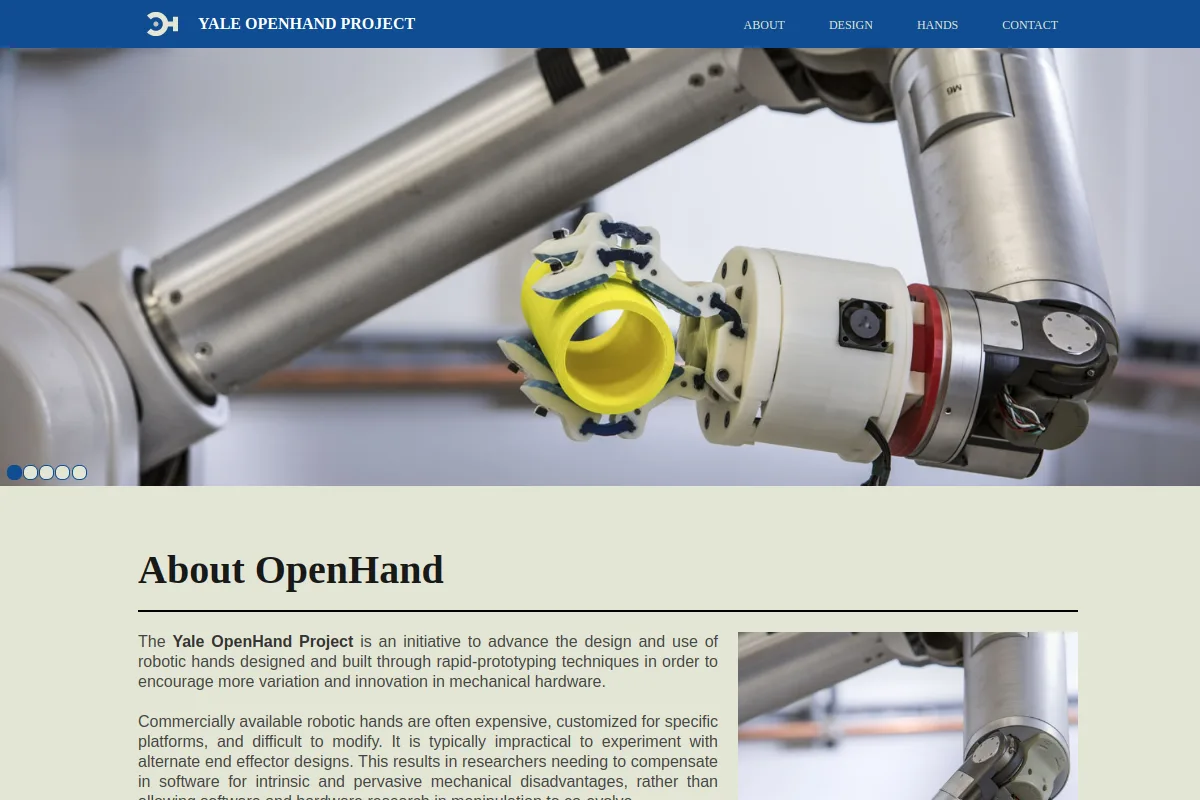 Website
 Research
Robot hand designs and resources for adaptive grasping research.
Hands & grippersExplore components, tools and organizations connected to education & research robotics. Inclusion does not certify suitability for a particular deployment.
Resources here include tools, components and organizations connected to this application. Confirm intended use and integration requirements with each publisher.
Know a resource that belongs here?