 代码仓库
 科研
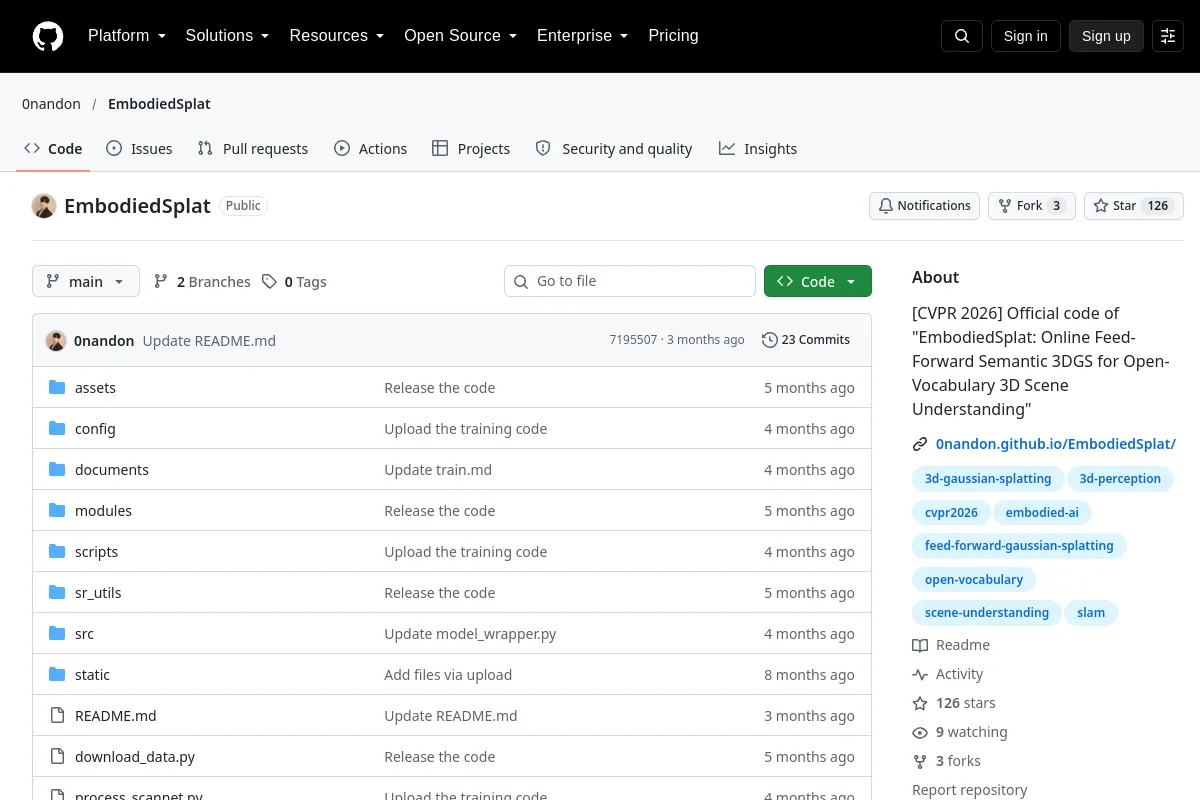
EmbodiedSplat · 0nandon
《EmbodiedSplat: Online Feed-Forward Semantic 3DGS for Open-Vocabulary 3D Scene Understanding》的官方代码
感知与几何具身智能与机器人资源导航
查找点云处理、校准和几何估计库。
代码仓库
科研
《EmbodiedSplat: Online Feed-Forward Semantic 3DGS for Open-Vocabulary 3D Scene Understanding》的官方代码
感知与几何 代码仓库
 代码仓库
 科研
集成的人形控制、规划和感知系统。由麻省理工学院和爱丁堡大学为波士顿动力 Atlas 和 NASA Valkyrie 人形机器人开发
感知与几何 代码仓库
 科研
论文:“OptiGeo: Efficient Moneye Geometry for Embodied Perception in Optically Challenging Scenes”的正式实施
感知与几何 代码仓库
 代码仓库
 代码仓库
 科研
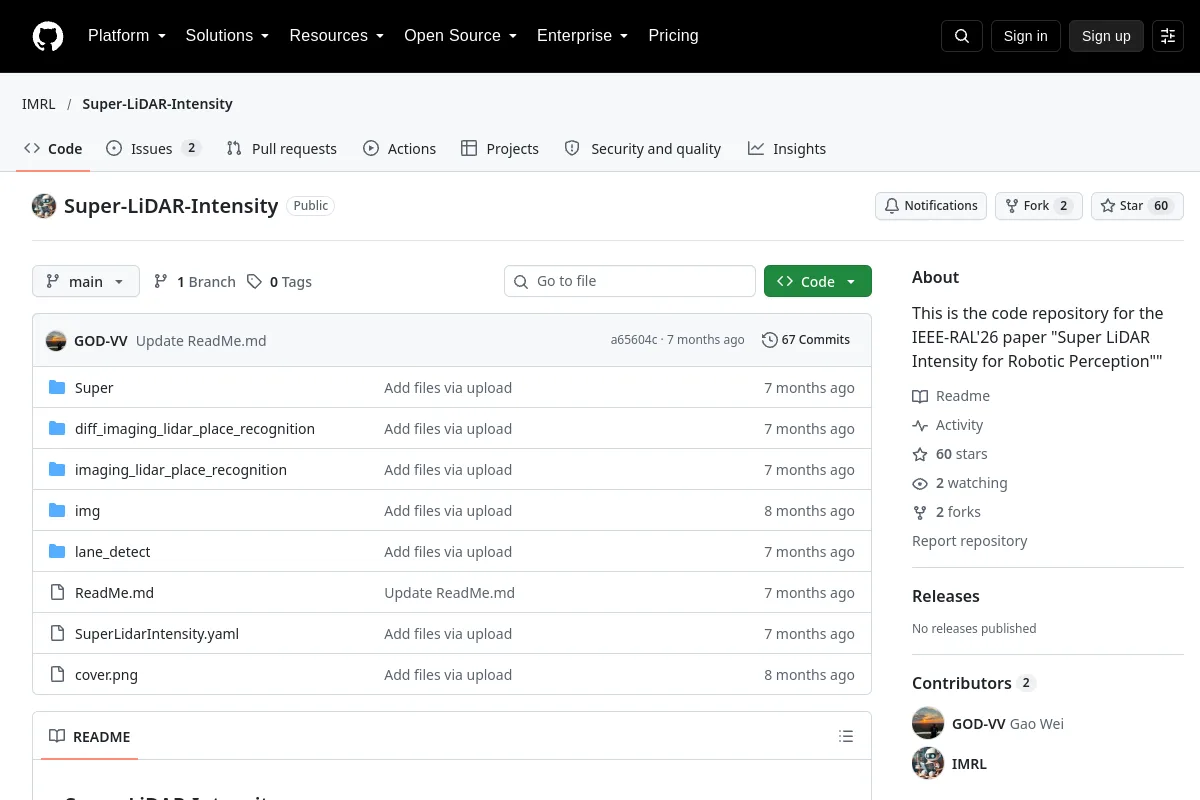
这是IEEE-RAL'26论文“Super LiDAR Intensity for Robotic Perception”的代码库
感知与几何 代码仓库
 代码仓库
 代码仓库
 代码仓库
 代码仓库
 代码仓库
选型说明
围绕传感器模态、校准假设和所需的几何输出选择工具。连接管道之前检查数值精度、运行时间要求和数据约定。
知道属于这里的资源吗?