 Repository
 Open source
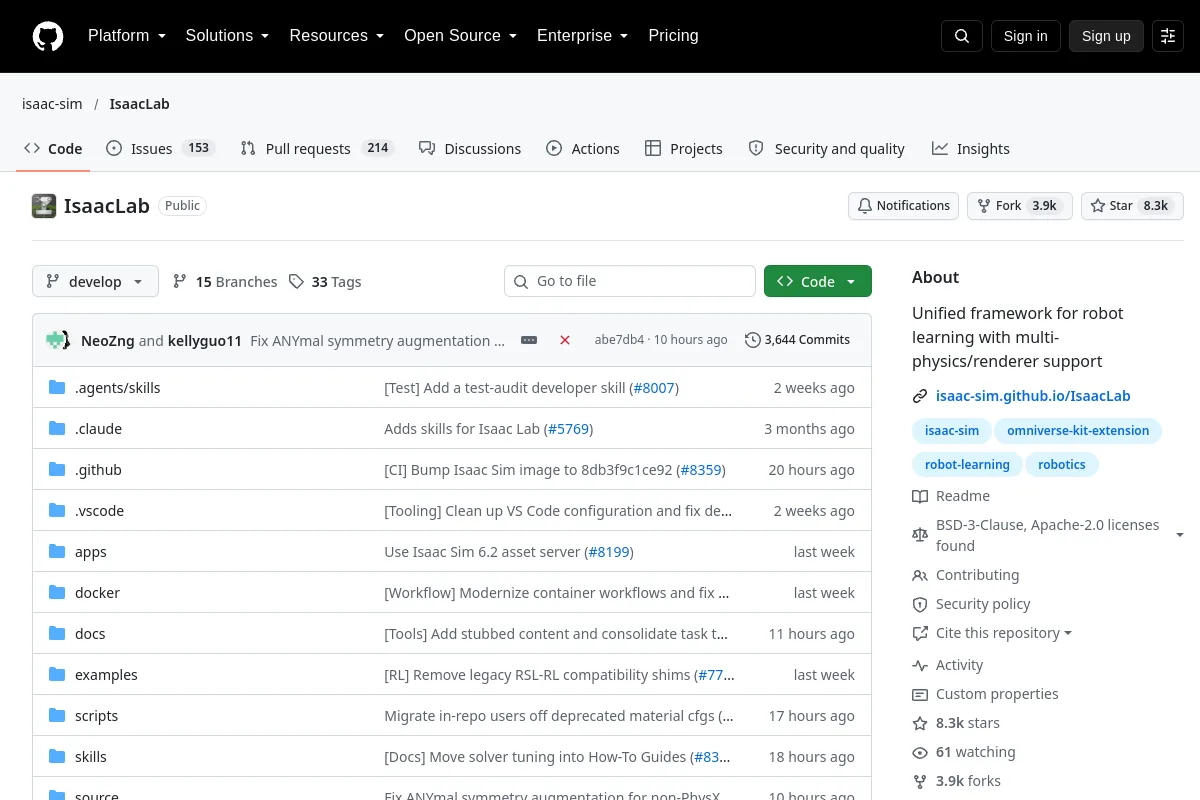
NVIDIA Isaac Lab
Robot learning tools built around the Isaac simulation ecosystem.
Simulation & physics
Research & learning / Research
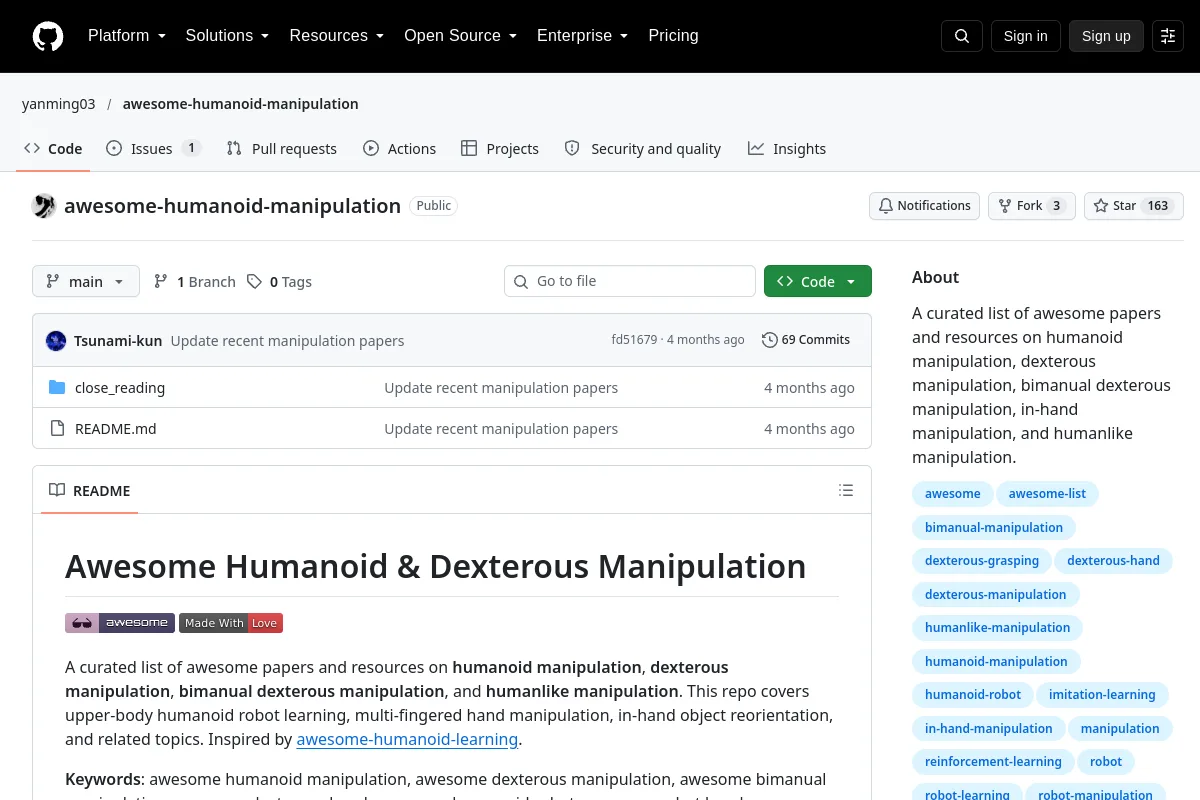
A curated list of awesome papers and resources on humanoid manipulation, dexterous manipulation, bimanual dexterous manipulation, in-hand manipulation, and humanlike manipulation.
A curated list of awesome papers and resources on humanoid manipulation, dexterous manipulation, bimanual dexterous manipulation, in-hand manipulation, and humanlike manipulation.
Use the source to explore robotics concepts, examples and references. Source material may be historical; check the applicable version and context.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
Robot learning tools built around the Isaac simulation ecosystem.
Simulation & physics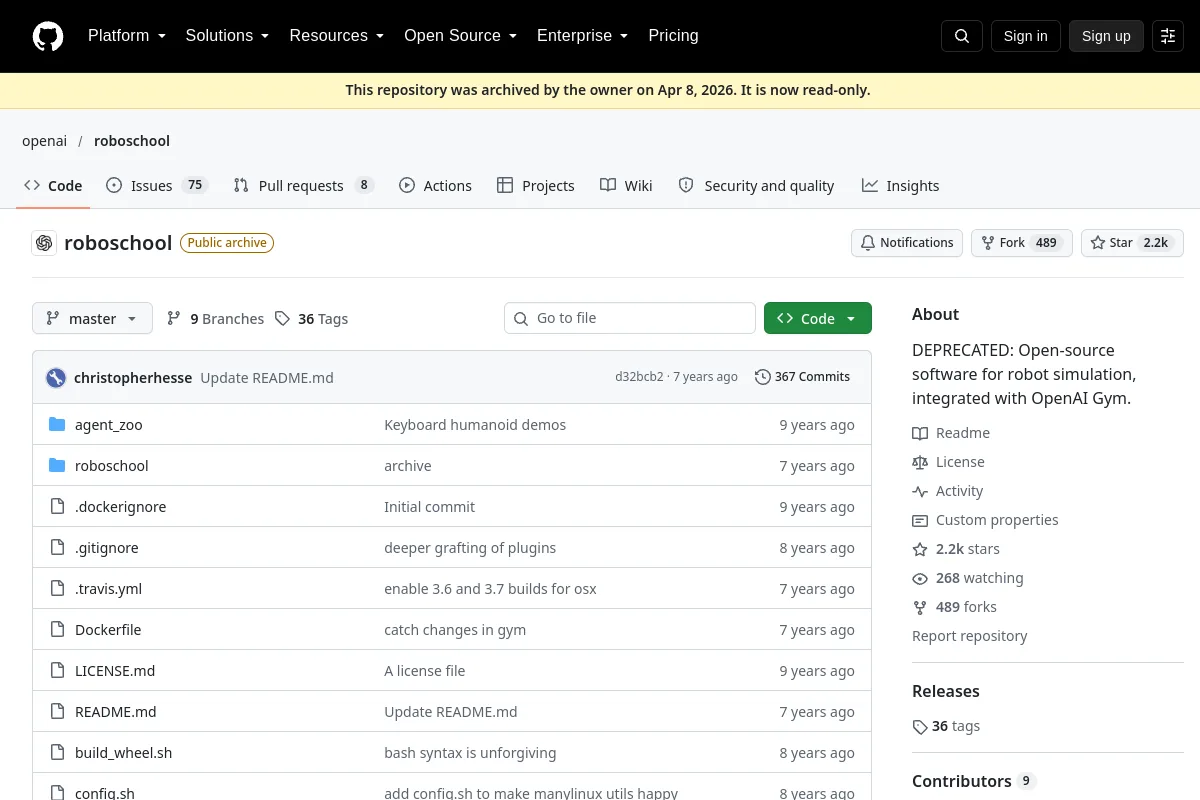 Repository
 Research
Deprecated robot simulation package integrated with OpenAI Gym.
Simulation & physics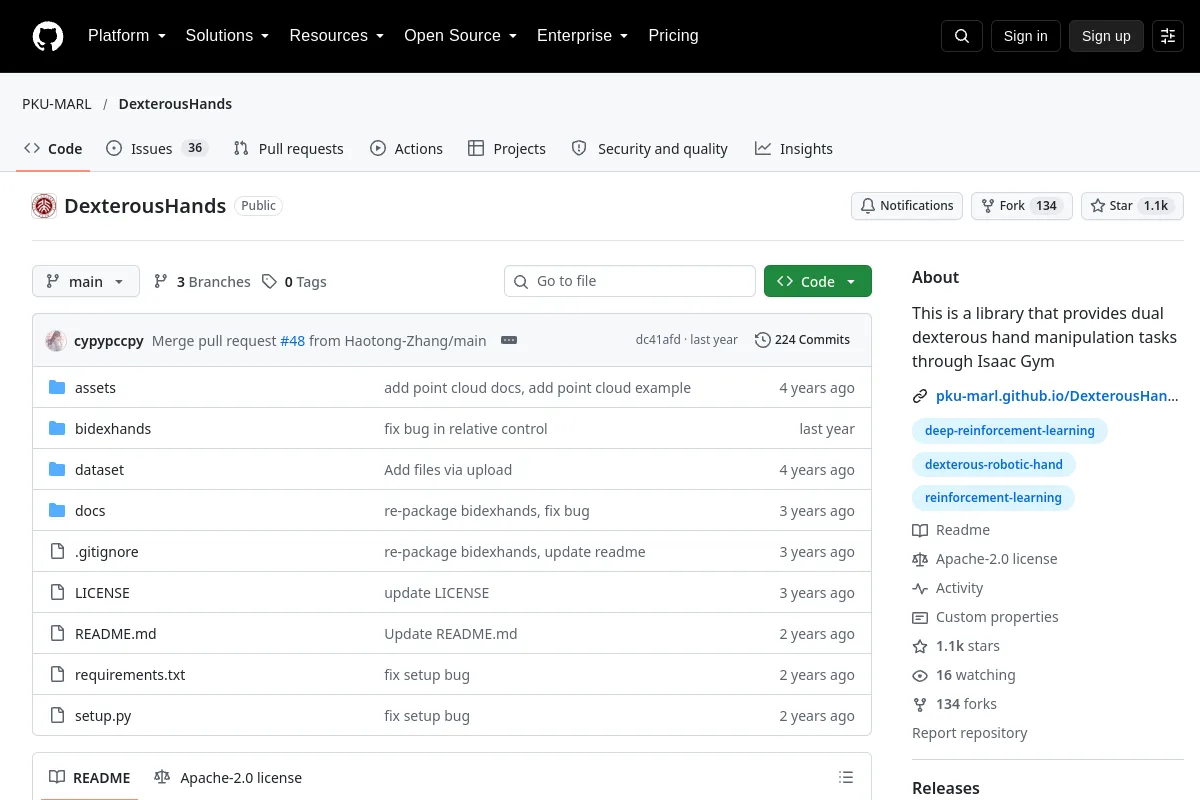 Repository
 Open source
This is a library that provides dual dexterous hand manipulation tasks through Isaac Gym
Robot learning frameworks Repository
 Research
Robot model assets for MuJoCo simulation and control experiments.
Scene & object assets Repository
 Research
Reinforcement-learning framework for humanoid control and sim-to-real research.
Motion planning & control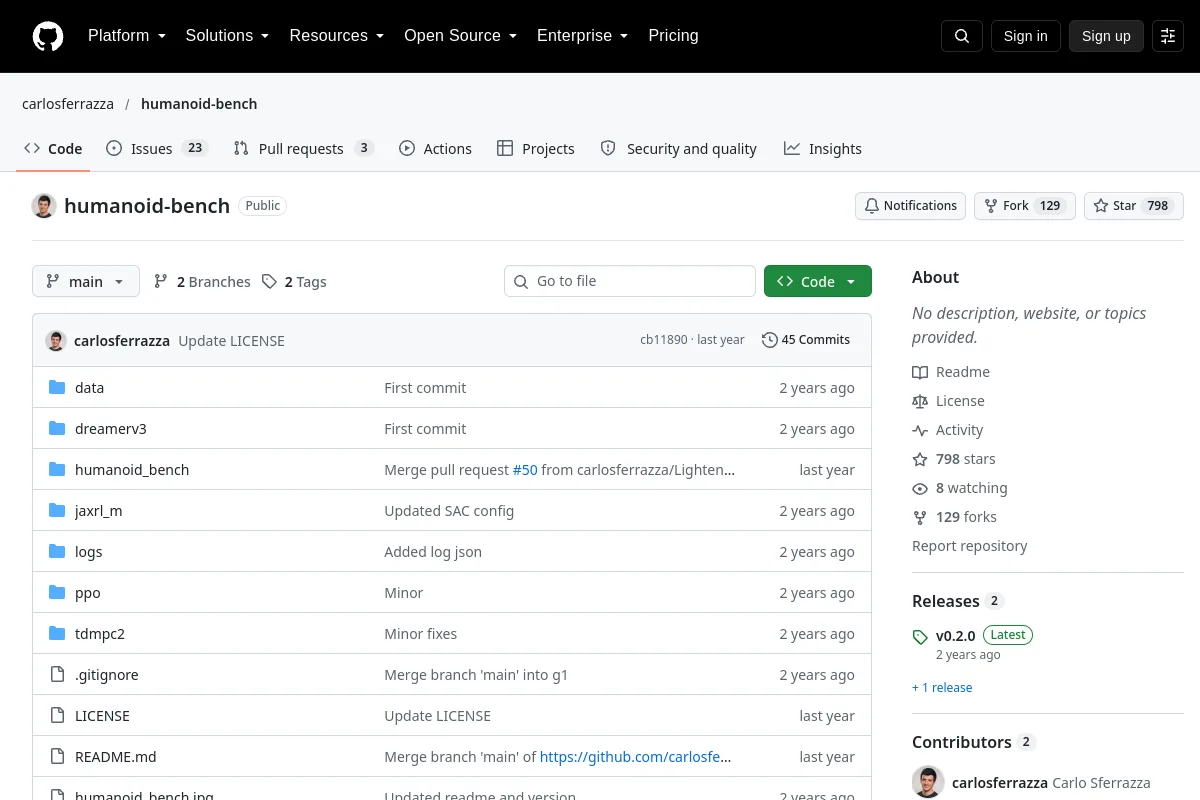 Website
 Research
Whole-body control tasks for evaluating humanoid robot learning.
Locomotion & whole-body control