 Repository
 Research
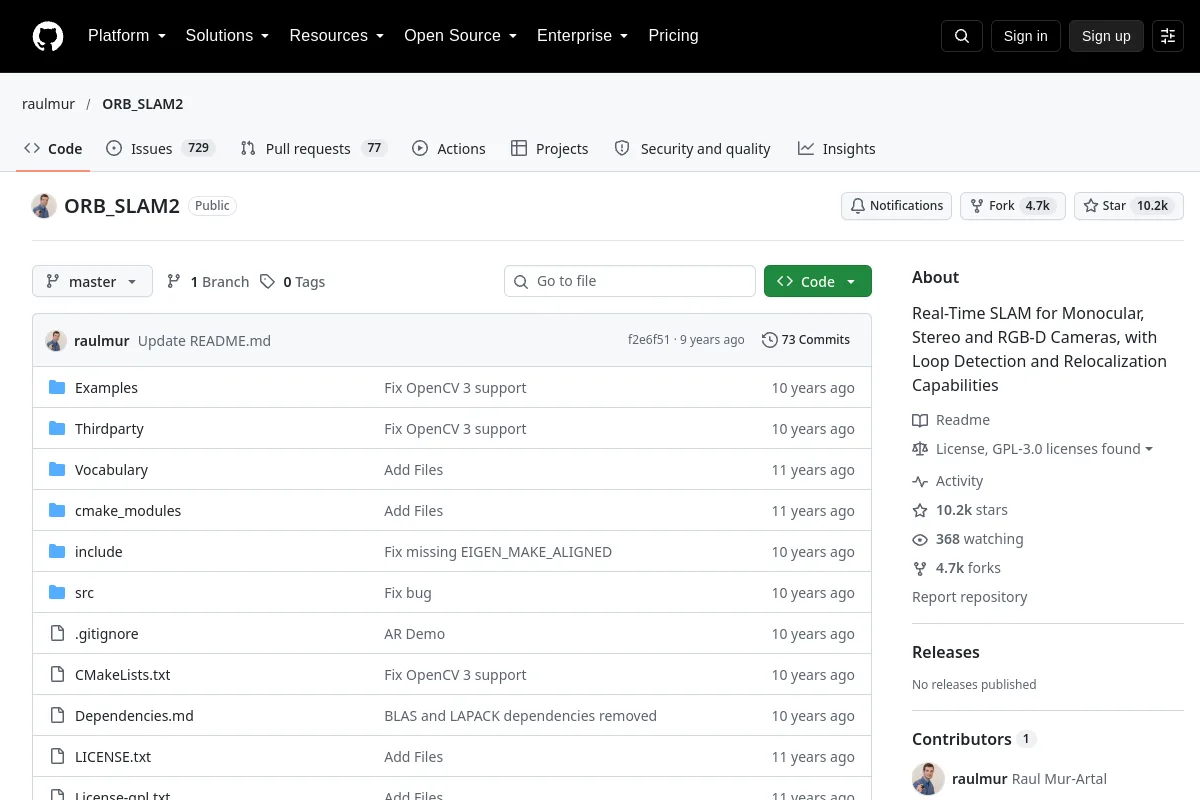
ORB SLAM2 · raulmur
Visual SLAM for monocular, stereo, and RGB-D cameras.
Navigation & SLAM
Software / Open source
pySLAM is a hybrid Python/C++ Visual SLAM pipeline supporting monocular, stereo, and RGB-D cameras. It provides a broad set of modern local and global feature extractors, multiple loop-closure…
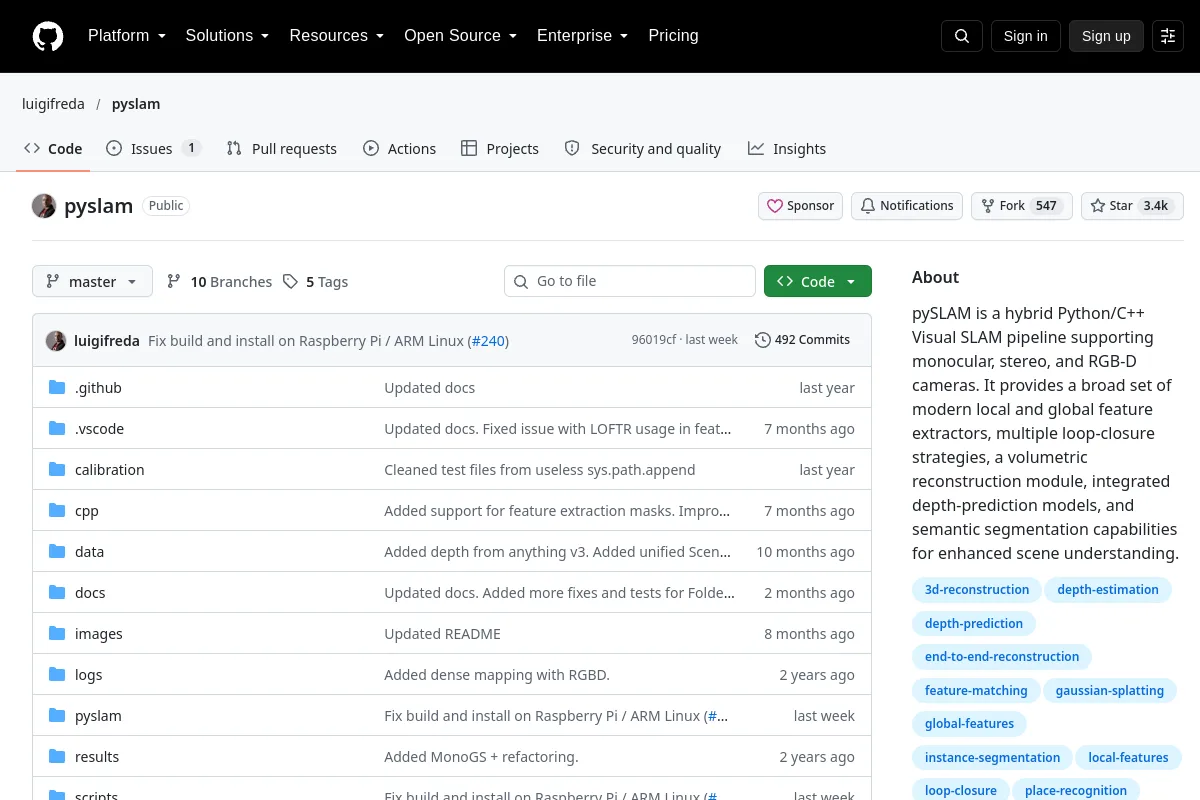
pySLAM is a hybrid Python/C++ Visual SLAM pipeline supporting monocular, stereo, and RGB-D cameras. It provides a broad set of modern local and global feature extractors, multiple loop-closure…
Publisher purpose: pySLAM is a hybrid Python/C++ Visual SLAM pipeline supporting monocular, stereo, and RGB-D cameras. It provides a broad set of modern local and global feature extractors, multiple loop-closure strategies, a volumetric reconstruction module, integrated depth-prediction models, and semantic segmentation capabilities for enhanced scene understanding.
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
Visual SLAM for monocular, stereo, and RGB-D cameras.
Navigation & SLAM Repository
 Open source
YOLO toolkit for detection, segmentation, pose estimation, and tracking.
Perception & geometry Repository
 Repository
 Research
This repository contains a set of tools that simplifies the management of docker containers and (ROS) images with transparent support of NVIDIA drivers.
Middleware & communication Repository
 Research
Official implementation of "Emergent Outlier View Rejection in Visual Geometry Grounded Transformers"
Perception & geometry Repository
 Research
Release repo for our SLAM Handbook
Courses & documentation