 Repository
 Open source
VIMA · vimalabs
Robot manipulation policy conditioned on multimodal prompts.
Robot learning frameworks
Research & learning / Research
Awesome Physical AI by keon collects VLA, world-model, embodied AI and robot foundation-model research.
Awesome Physical AI by keon collects VLA, world-model, embodied AI and robot foundation-model research.
Publisher summary: “A curated list of academic papers and resources on Physical AI — focusing on Vision-Language-Action (VLA) models, world models, embodied ai, and robotic foundation…”
Use its repository to inspect the implementation, documentation and supported workflows. This directory record identifies the maintainer, code license and related resources; it does not claim that the project has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
Robot manipulation policy conditioned on multimodal prompts.
Robot learning frameworks Website
 Research
Code and model resources for Physical Intelligence robot policies.
Vision-language-action Repository
 Research
StarVLA provides modular code for developing vision-language-action models.
Robot learning frameworks Repository
 Repository
 Research
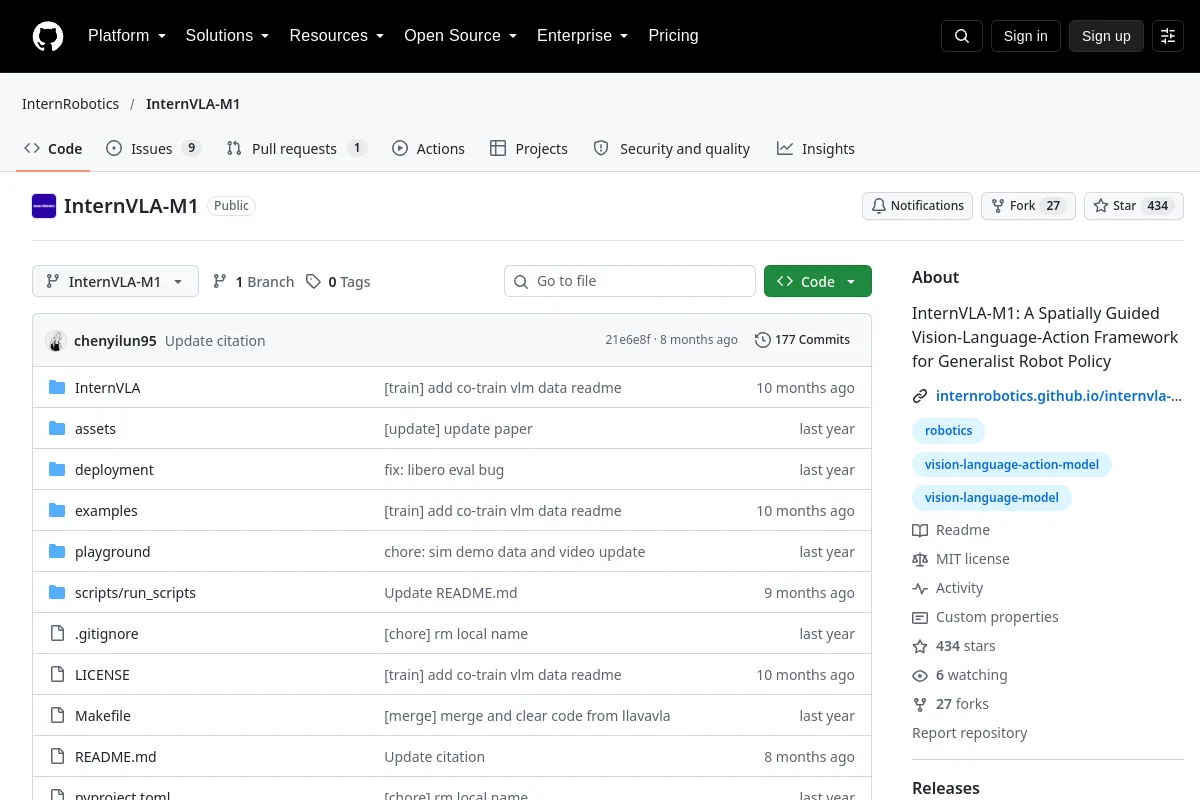
InternVLA-M1 provides a spatially guided vision-language-action framework for robot policies.
Vision-language-action Repository
 Research
GraspVLA provides grasping-model research pretrained with synthetic action data.
Vision-language-action