 Repository
Models / Research
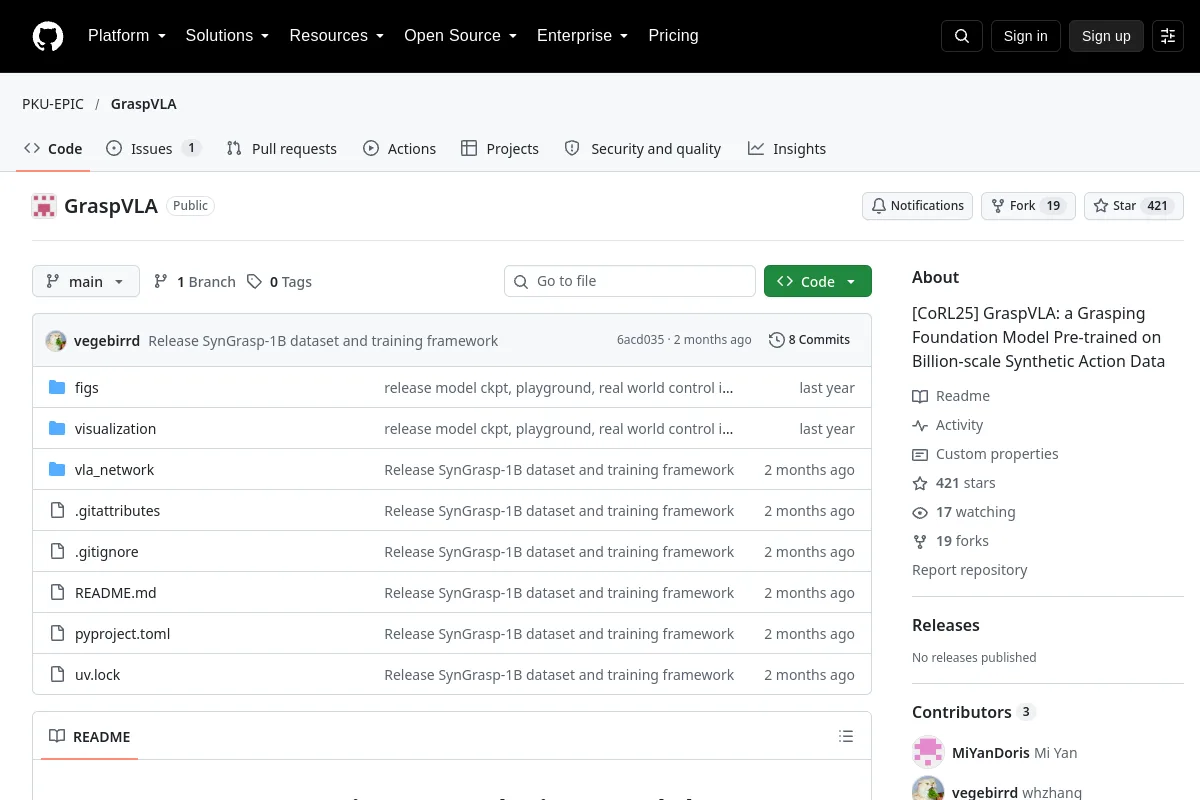
GraspVLA · PKU-EPIC
GraspVLA provides grasping-model research pretrained with synthetic action data.
Overview
GraspVLA provides grasping-model research pretrained with synthetic action data.
Publisher summary: “[CoRL25] GraspVLA: a Grasping Foundation Model Pre-trained on Billion-scale Synthetic Action Data”
Use its repository to inspect the implementation, documentation and supported workflows. This directory record identifies the maintainer, code license and related resources; it does not claim that the project has been installed or tested on your robot.
Project information
- Maintainer
- PKU-EPIC
- Primary language
- Python
- Repository code license
- Not specified
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2026-08-19
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- GraspVLA: a Grasping Foundation Model Pre-trained on Billion-scale Synthetic Action Data
- Latest Updates
- Model Server
- Step 1: Clone the Repository
- Step 2: Set Up Python Environment
- Step 3: Prepare a Checkpoint
Browse this resource’s categories
Explore related collections
Vision-language-action models ↗More in Models
Repository