 Repository
Benchmarks / Research
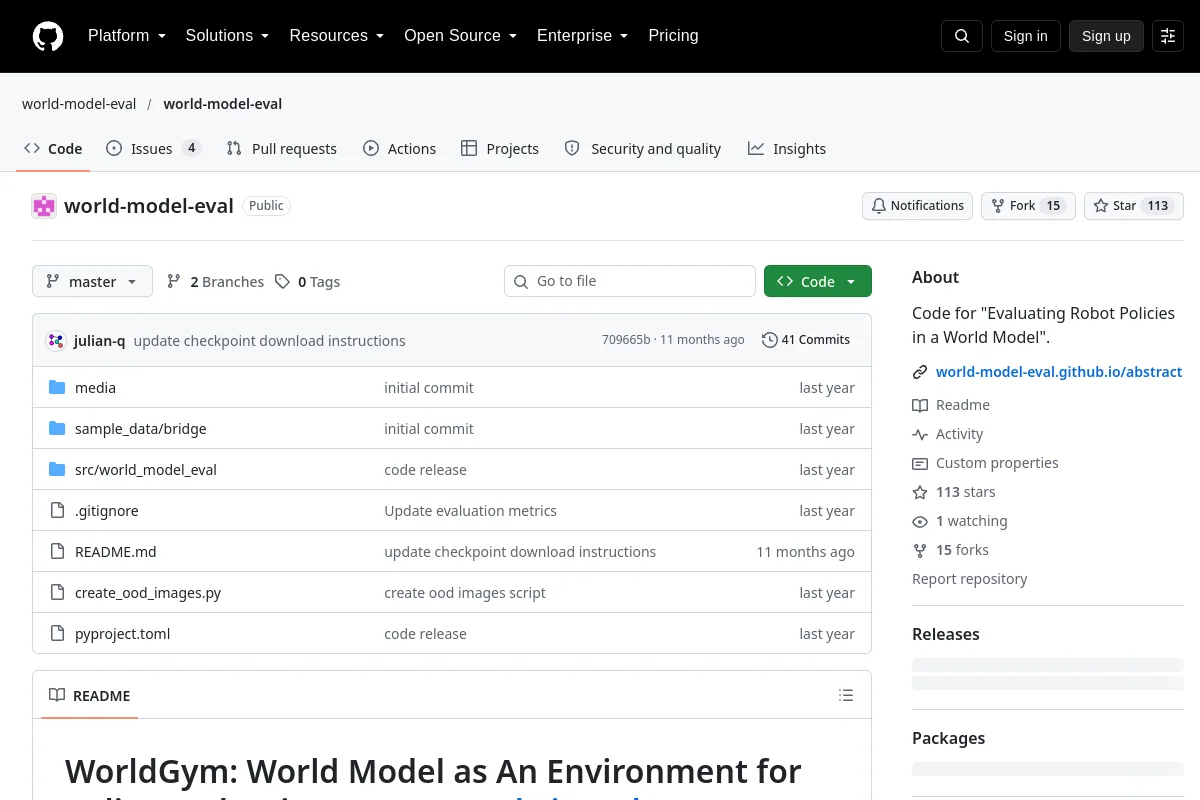
world-model-eval · world-model-eval
Code for "Evaluating Robot Policies in a World Model".
Overview
Code for "Evaluating Robot Policies in a World Model".
Compare tasks, protocols, dataset/environment versions and hardware before interpreting reported results. A benchmark repository is not a certification of a robot system.
Project information
- Maintainer
- world-model-eval
- Primary language
- Python
- Repository code license
- Not specified
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2025-11-06
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- WorldGym: World Model as An Environment for Policy Evaluation [\[paper\]](https://arxiv.org/abs/2506.00613) [\[website\]](https://world-model-eval.github.io/abstract) [\[demo\]](https://world-model-eval.github.io/)
- Overview
- Installation
- World-model checkpoint
- Prepare evaluation data
- OpenVLA
Browse this resource’s categories
Explore related collections
Browse Benchmarks →More in Benchmarks
Repository
 Repository
 Repository
 Repository
 Repository
 Research
actionshift · Archerkattri
ActionShift evaluates adaptation to hidden robot action-interface contracts on ManiSkill tasks.
Manipulation Repository
 Research
RMBench · RoboTwin-Platform
Memory-Dependent Manipulation Benchmark based on RoboTwin
Manipulation