 Repository
 Open source
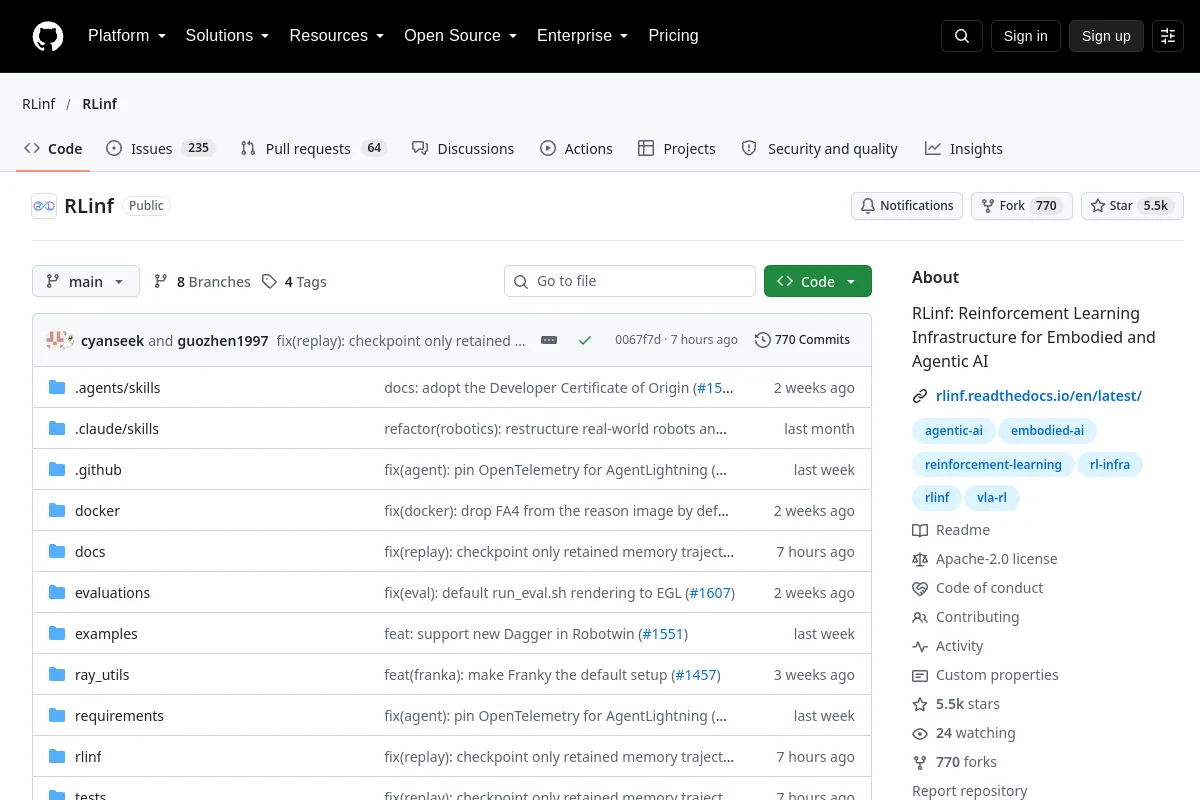
RLinf
Reinforcement-learning infrastructure for embodied models and robotic policies.
Robot learning frameworks
Research & learning / Research
Awesome World Models for Robotic Policy Learning
Awesome World Models for Robotic Policy Learning
Use the source to explore robotics concepts, examples and references. Source material may be historical; check the applicable version and context.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
Reinforcement-learning infrastructure for embodied models and robotic policies.
Robot learning frameworks Repository
 Repository
 Research
DayDreamer provides world-model methods for physical robot learning.
World models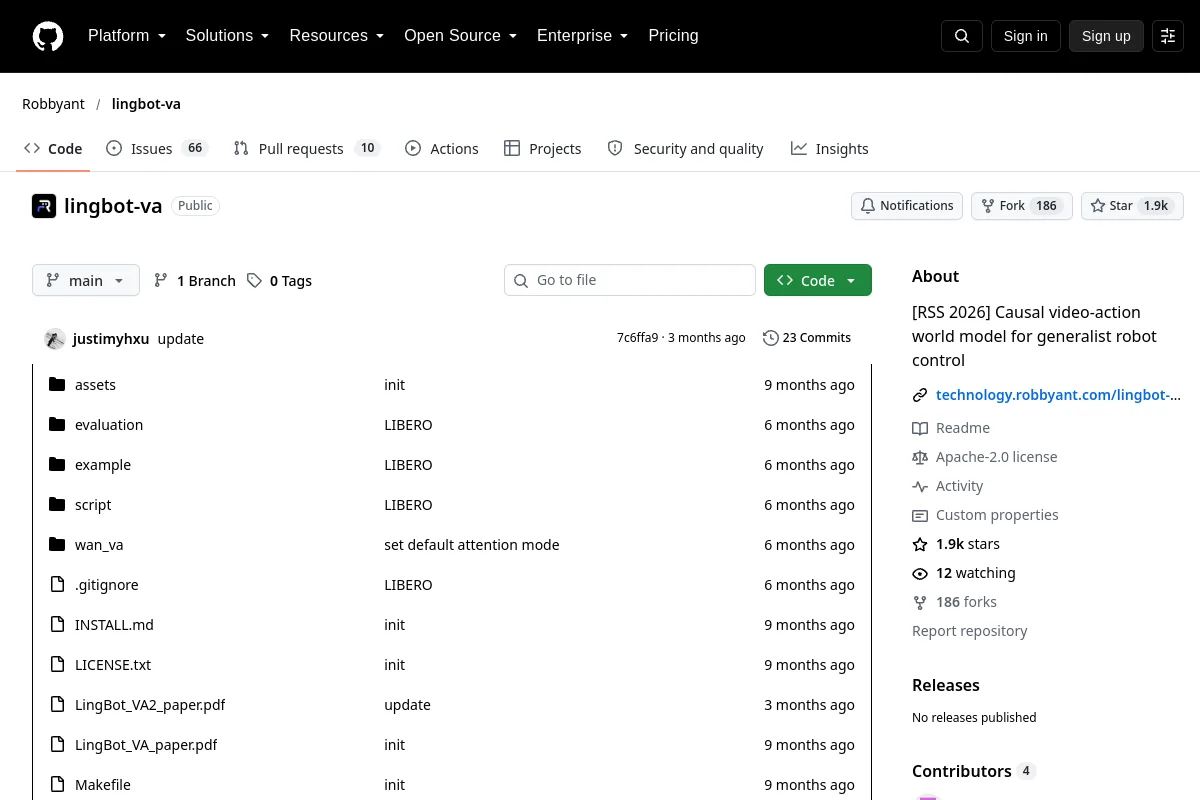 Repository
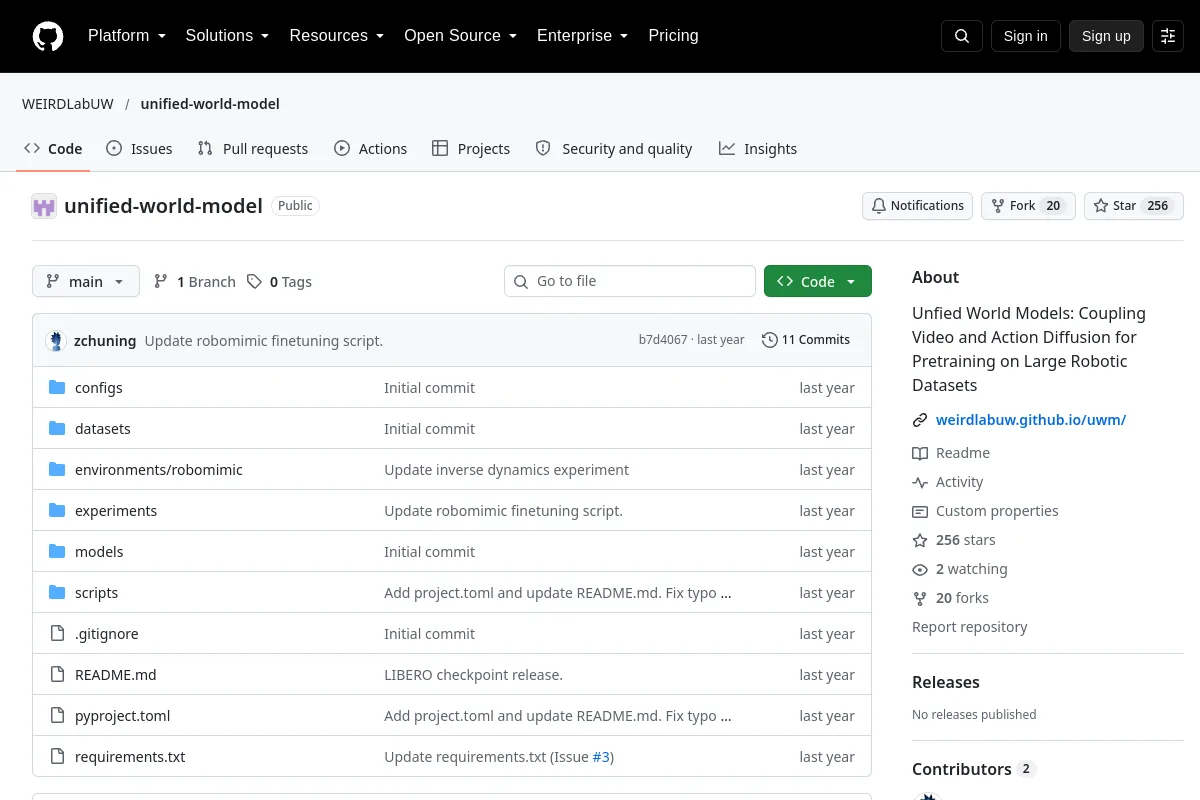 Repository
 Research
Unfied World Models: Coupling Video and Action Diffusion for Pretraining on Large Robotic Datasets
Robot demonstrations Repository
 Research
BAAI UniVLA provides a unified vision-language-action model research project.
Vision-language-action