 Repository
Models / Research
UniVLA
Robot policy research using latent action representations.
Overview
Robot policy research using latent action representations.
Compare observation inputs, action representations, adaptation data and inference requirements. Code licensing and model-weight licensing may differ; review both before deployment. A source repository may have an open code license while its checkpoints have separate terms.
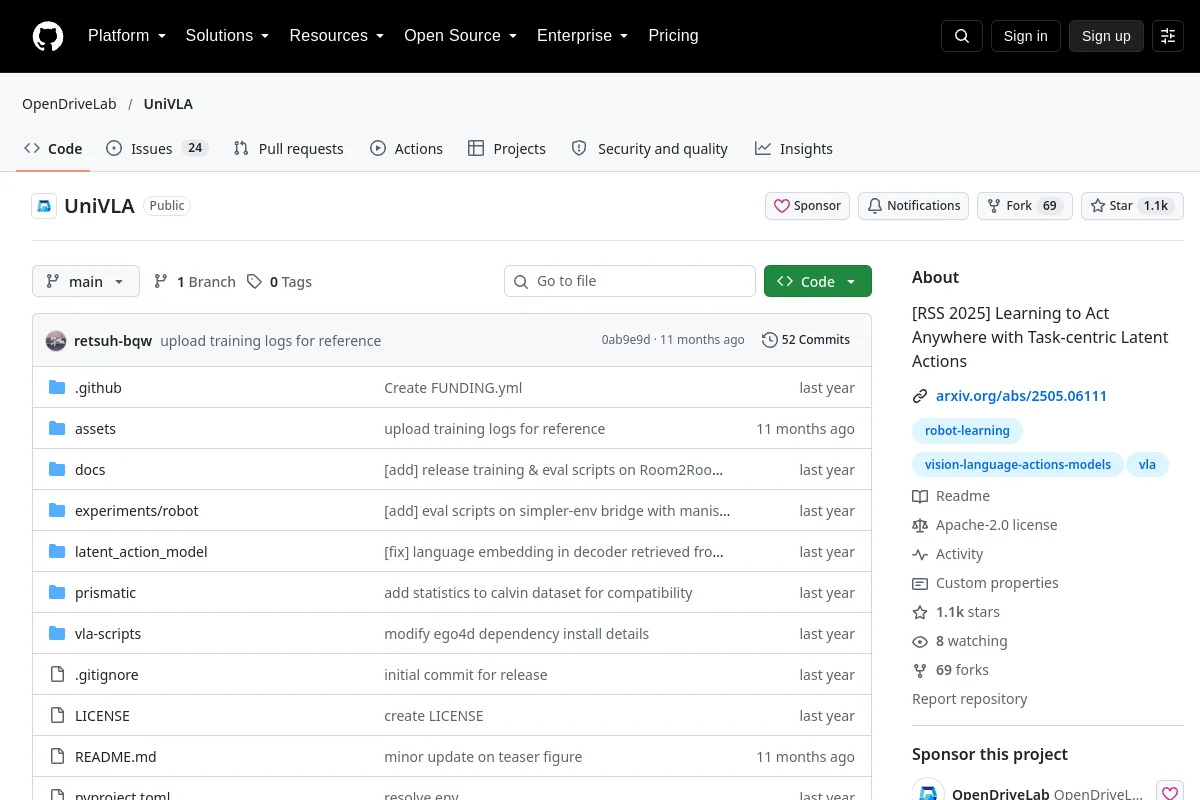
Project information
- Maintainer
- OpenDriveLab
- Primary language
- Python
- Repository code license
- Apache-2.0
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2025-11-19
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- :earthasia: UniVLA
- :fire: Highlights
- Table of Contents
- :moviecamera: Demo
- :loudspeaker: News
- 🤗 Model Zoo <a name="ckpts"></a>
Browse this resource’s categories
Application areas
Education & research ↗Explore related collections
Vision-language-action models ↗More in Models
Repository
 Repository