 Repository
 Open source
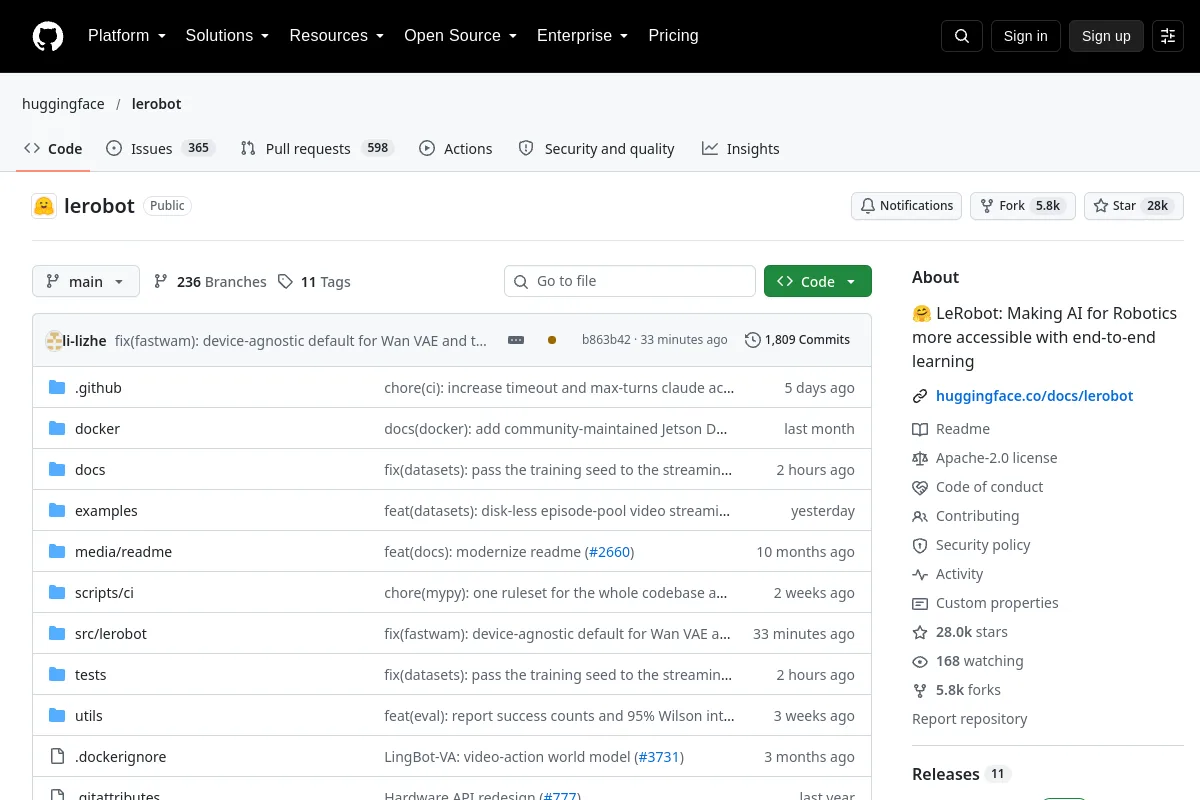
LeRobot · huggingface
LeRobot tools for robot control, datasets and end-to-end learning.
Robot learning frameworks
Software / Open source
Code accompanying the RA-L / ICRA 2020 paper: "Online Trajectory Generation with Distributed Model Predictive Control for Multi-Robot Motion Planning"
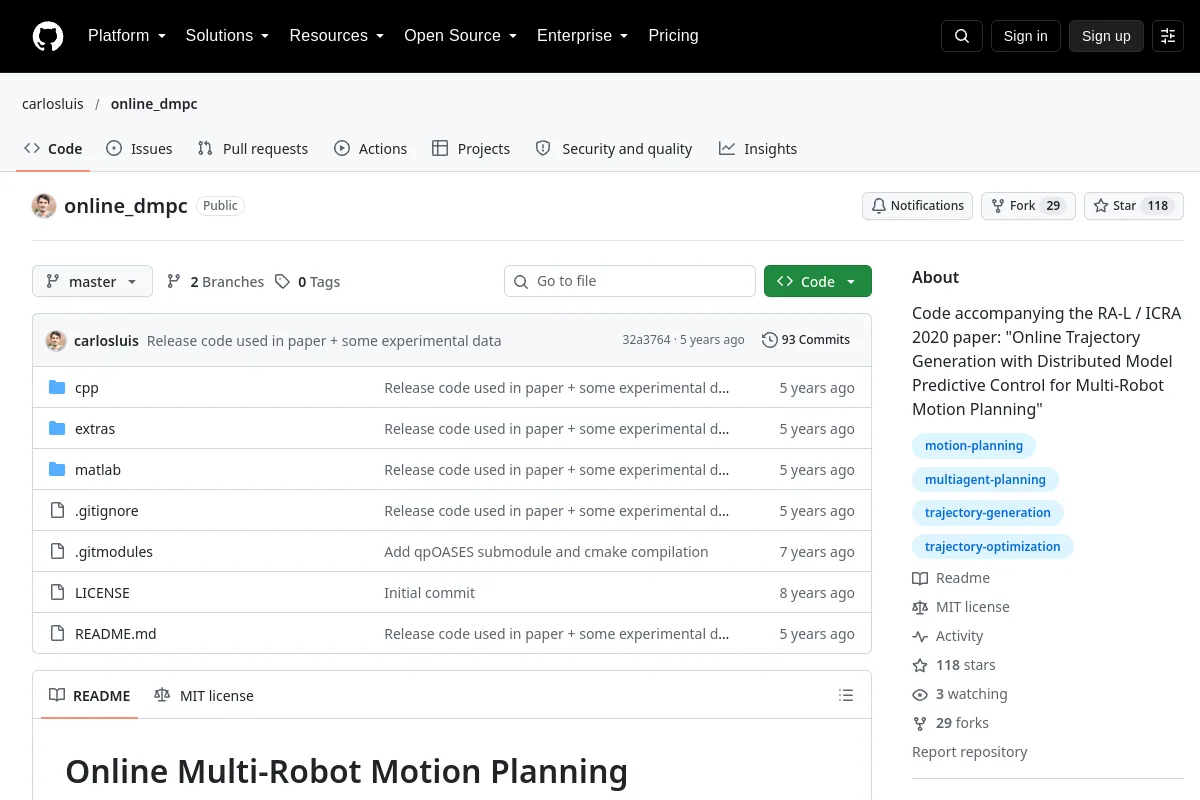
Code accompanying the RA-L / ICRA 2020 paper: "Online Trajectory Generation with Distributed Model Predictive Control for Multi-Robot Motion Planning"
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
LeRobot tools for robot control, datasets and end-to-end learning.
Robot learning frameworks Repository
 Open source
MuJoCo physics simulator for multijoint dynamics and contact.
Motion planning & control Repository
 Open source
Robot learning tools built around the Isaac simulation ecosystem.
Simulation & physics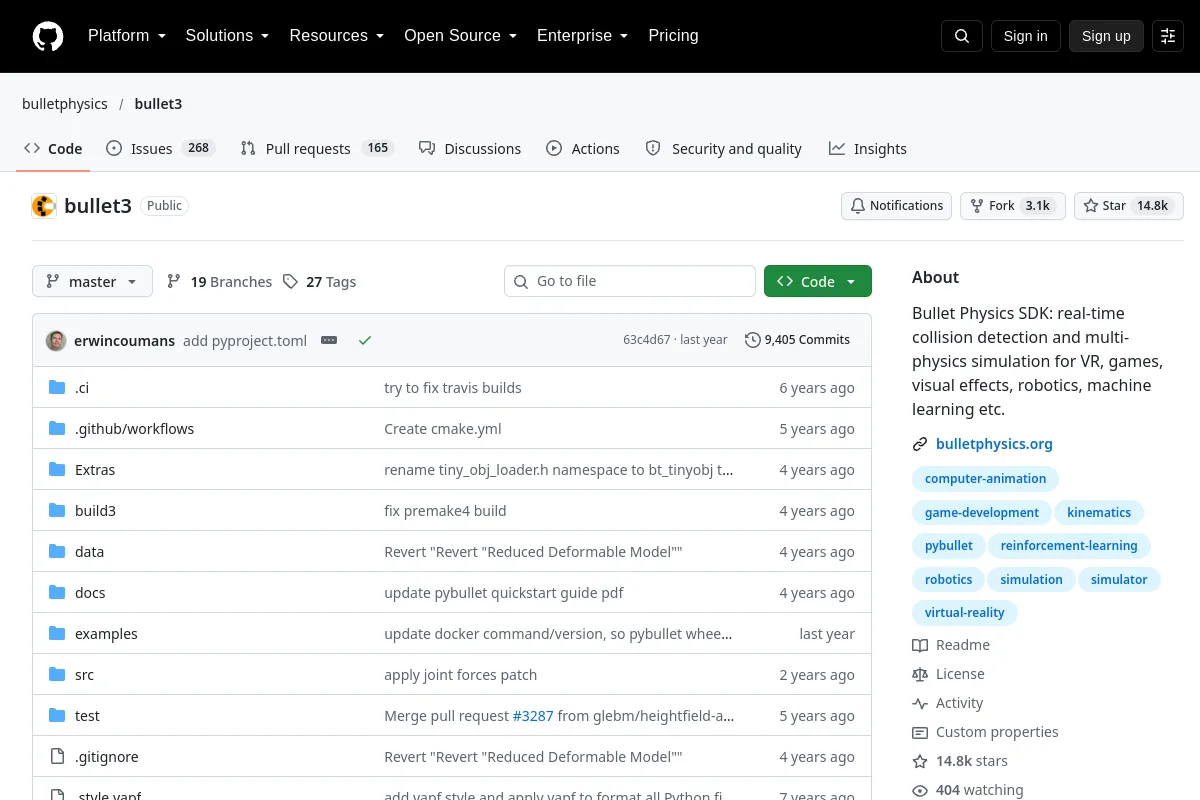 Repository
 Research
A physics SDK for collision detection and multi-physics simulation.
Robot SDKs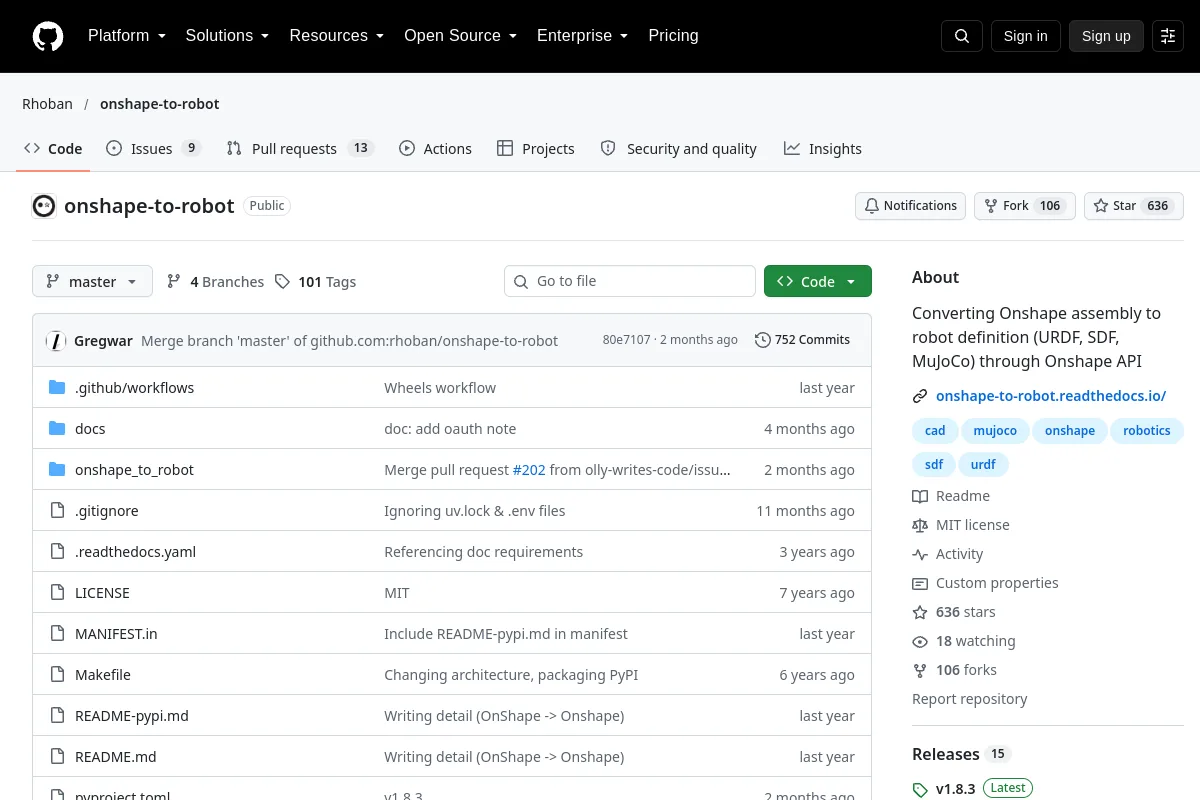 Repository
 Open source
Converts Onshape assemblies into URDF, SDF, and MuJoCo robot descriptions.
Simulation & physics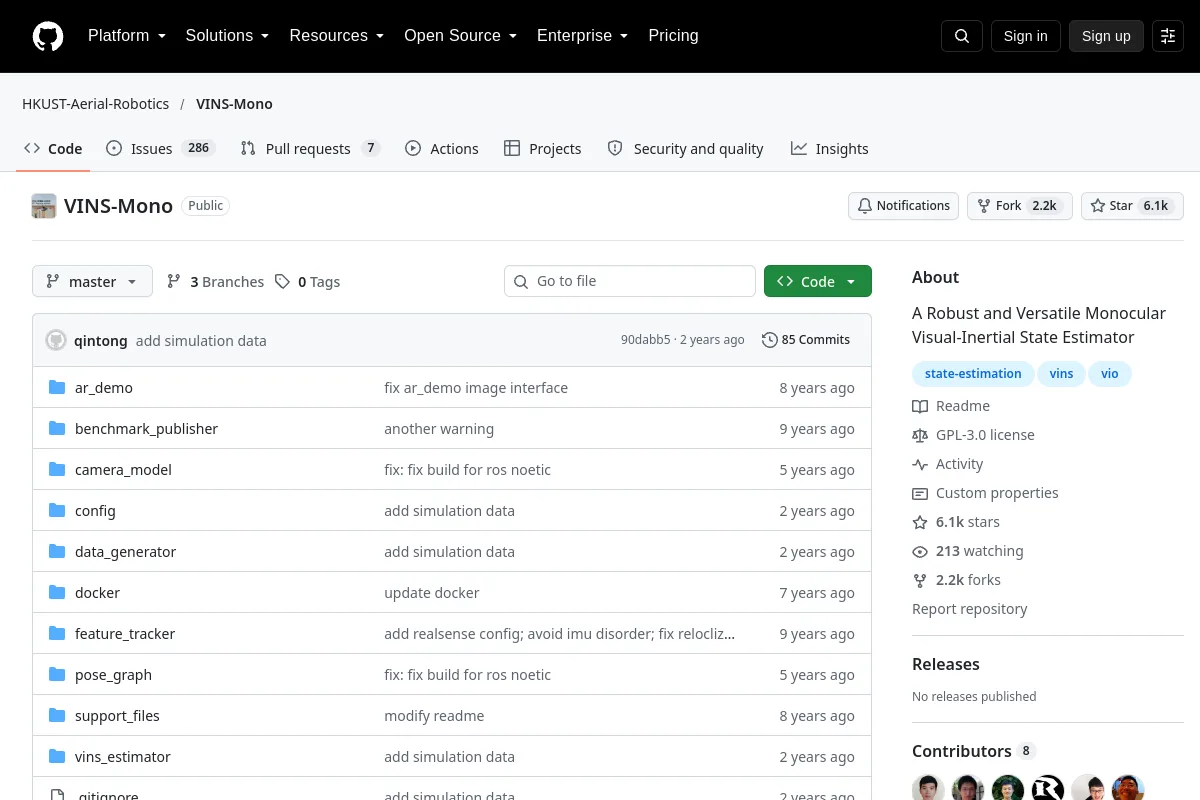 Repository
 Open source
A Robust and Versatile Monocular Visual-Inertial State Estimator
Navigation & SLAM