 Repository
Models / Research
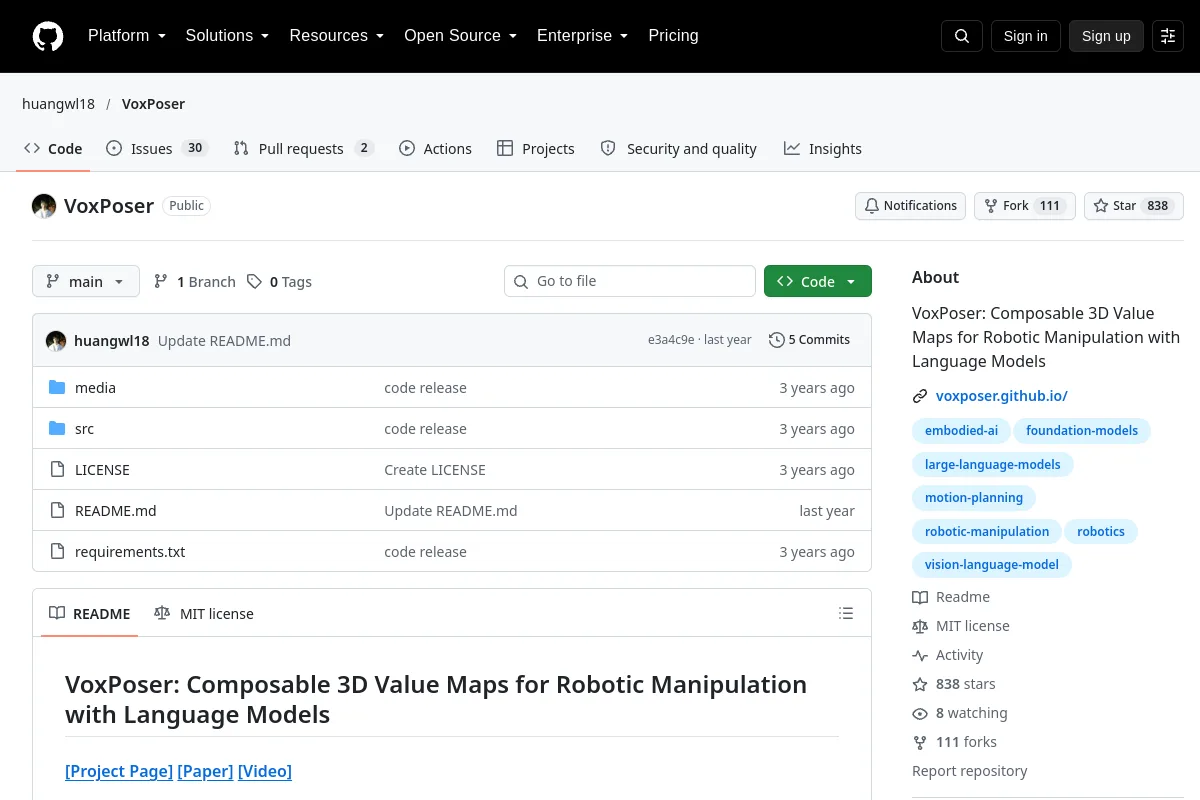
VoxPoser
Language-guided 3D value-map planning for robot manipulation.
Overview
Language-guided 3D value-map planning for robot manipulation.
Compare observation inputs, action representations, adaptation data and inference requirements. Code licensing and model-weight licensing may differ; review both before deployment. A source repository may have an open code license while its checkpoints have separate terms.
Project information
- Maintainer
- huangwl18
- Primary language
- Python
- Repository code license
- MIT
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2025-02-20
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- VoxPoser: Composable 3D Value Maps for Robotic Manipulation with Language Models
- Setup Instructions
- Running Demo
- Code Structure
- Real-World Deployment
- Acknowledgments
Browse this resource’s categories
Explore related collections
Browse Models →More in Models
Repository