 Repository
 Research
Unity Robotics Hub · Unity-Technologies
Unity Robotics Hub provides tools, tutorials and documentation for robotics simulation in Unity.
Standards & reference collections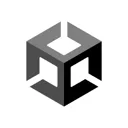
Software / Open source
A complete end-to-end demonstration in which we collect training data in Unity and use that data to train a deep neural network to predict the pose of a cube. This model is then deployed in a…
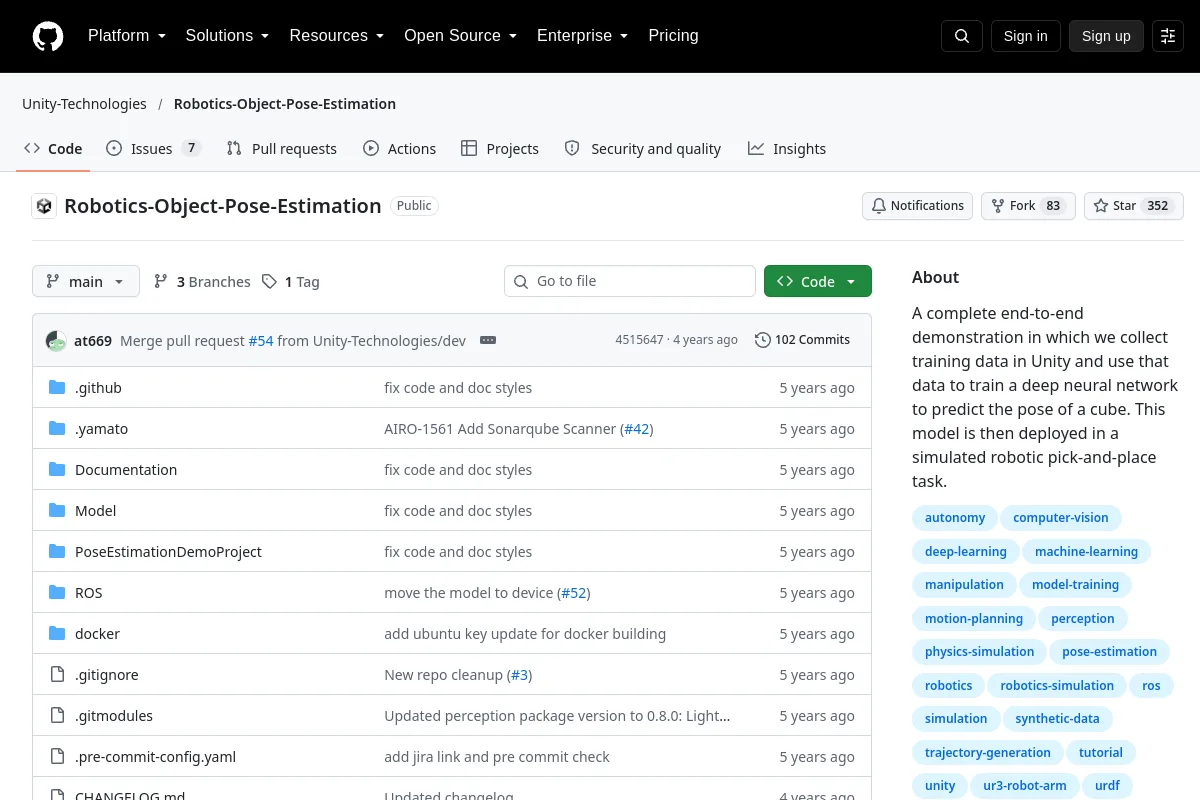
A complete end-to-end demonstration in which we collect training data in Unity and use that data to train a deep neural network to predict the pose of a cube. This model is then deployed in a…
Publisher purpose: A complete end-to-end demonstration in which we collect training data in Unity and use that data to train a deep neural network to predict the pose of a cube. This model is then deployed in a simulated robotic pick-and-place task.
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
Unity Robotics Hub provides tools, tutorials and documentation for robotics simulation in Unity.
Standards & reference collections Repository
 Open source
Import URDF robot descriptions into Unity for robot visualisation and simulation.
Visualization & data tools