 Repository
 Open source
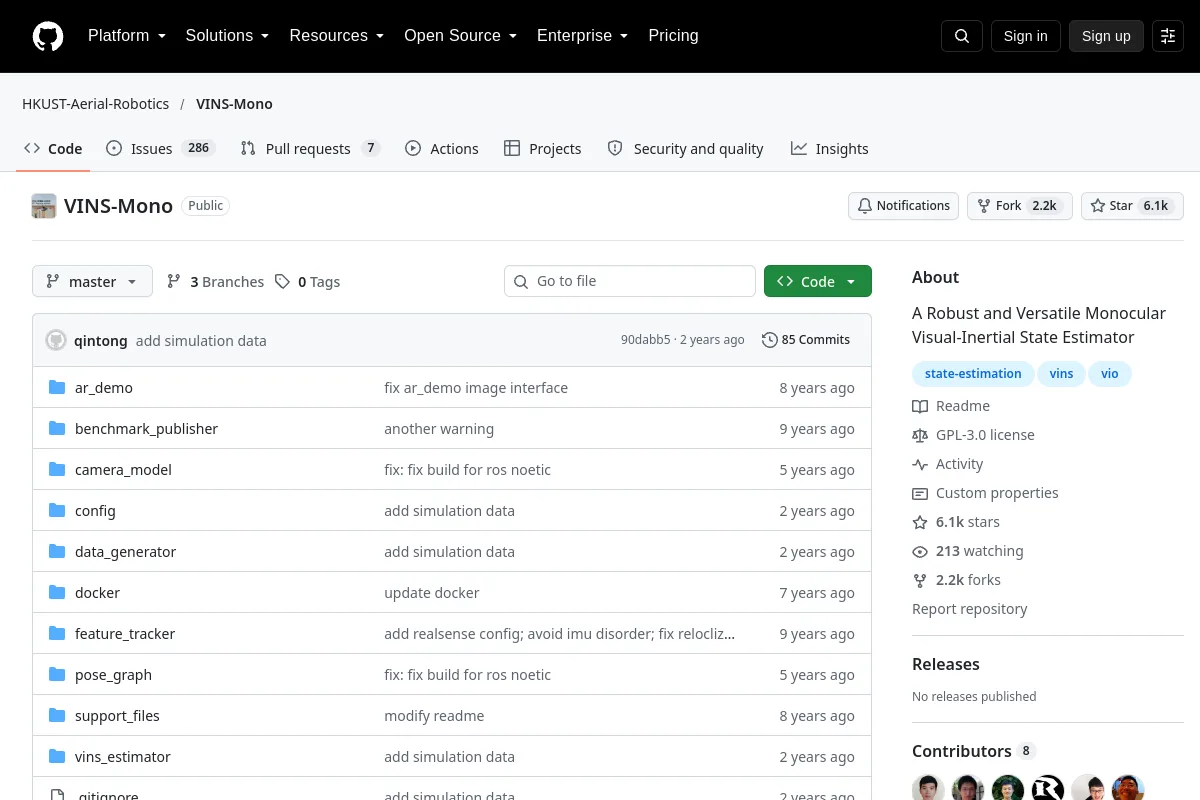
VINS-Mono · HKUST-Aerial-Robotics
A Robust and Versatile Monocular Visual-Inertial State Estimator
Navigation & SLAM
Research & learning / Research
😎 A curated list of awesome mobile robots study resources based on ROS (including SLAM, odometry and navigation, manipulation)
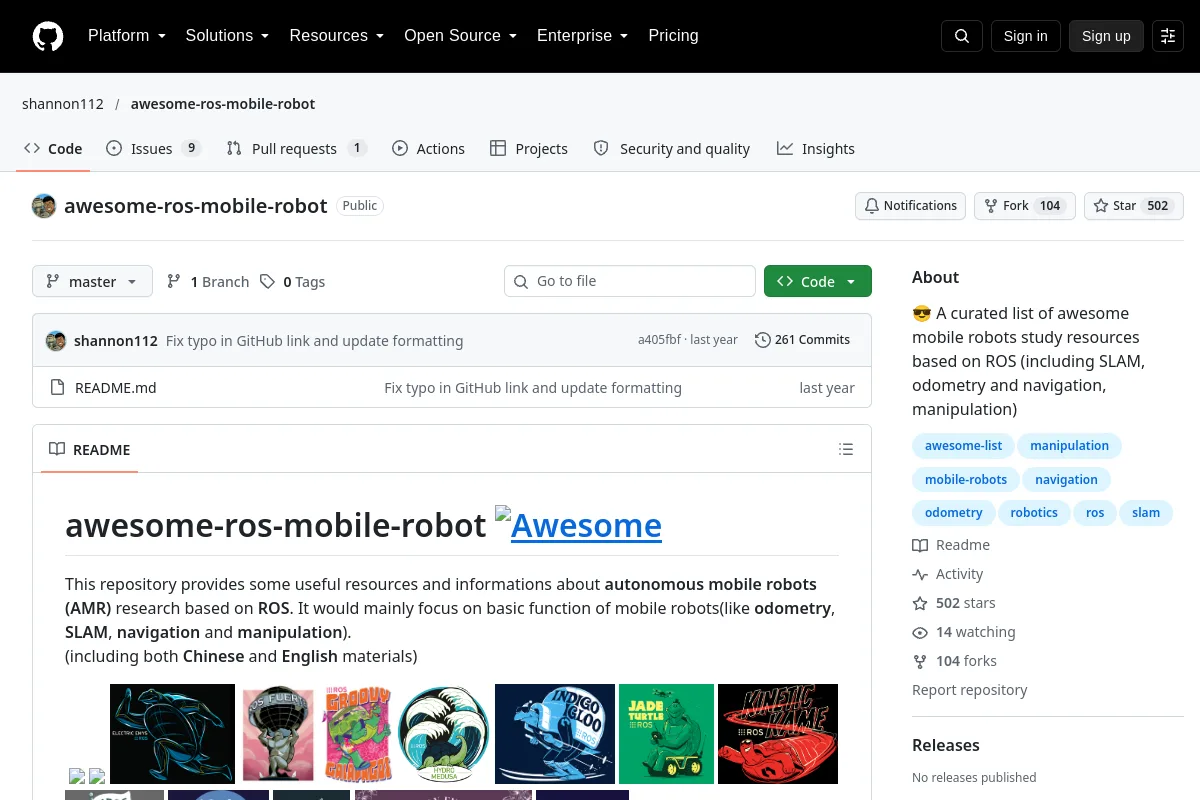
😎 A curated list of awesome mobile robots study resources based on ROS (including SLAM, odometry and navigation, manipulation)
Publisher purpose: 😎 A curated list of awesome mobile robots study resources based on ROS (including SLAM, odometry and navigation, manipulation)
Use the source to explore robotics concepts, examples and references. Source material may be historical; check the applicable version and context.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
A Robust and Versatile Monocular Visual-Inertial State Estimator
Navigation & SLAM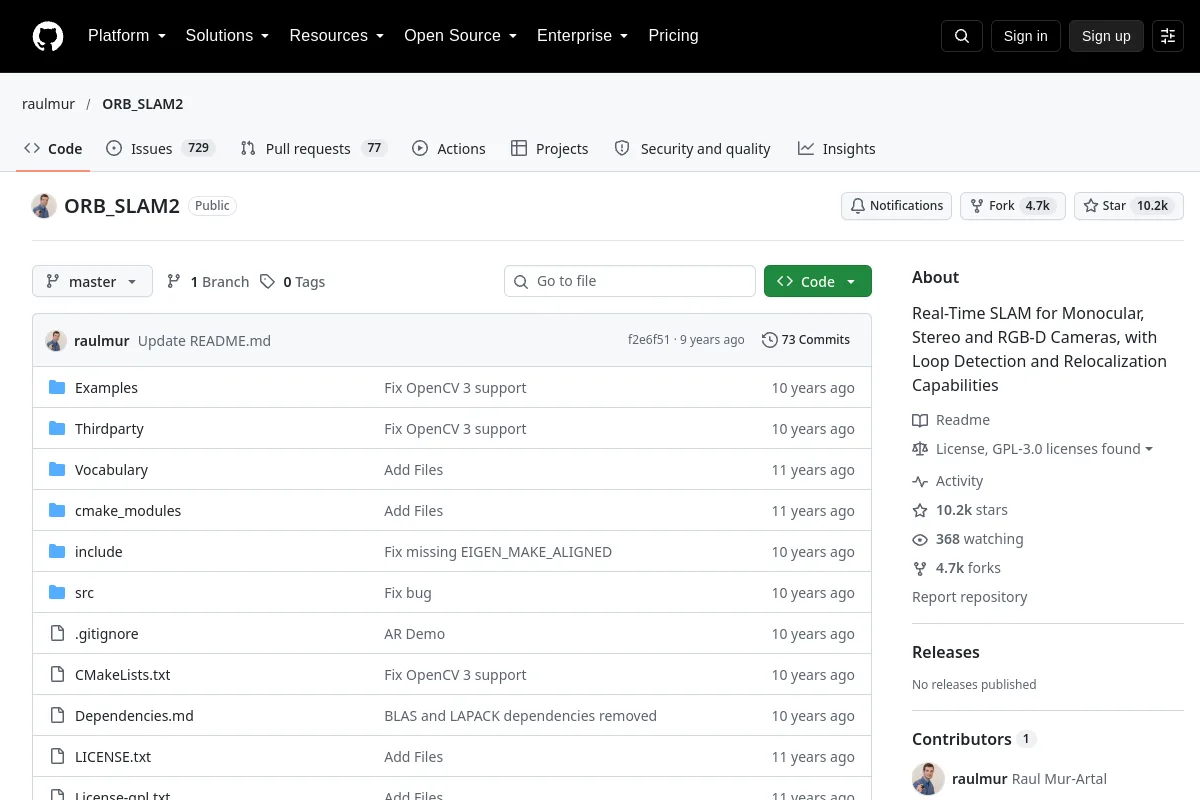 Repository
 Research
Visual SLAM for monocular, stereo, and RGB-D cameras.
Navigation & SLAM Repository
 Open source
An optimization-based multi-sensor state estimator
Navigation & SLAM Repository
 Repository
 Repository
 Open source
Visual and visual-inertial localization and mapping software.
Navigation & SLAM