 Repository
Datasets / Research
peract_bimanual · markusgrotz
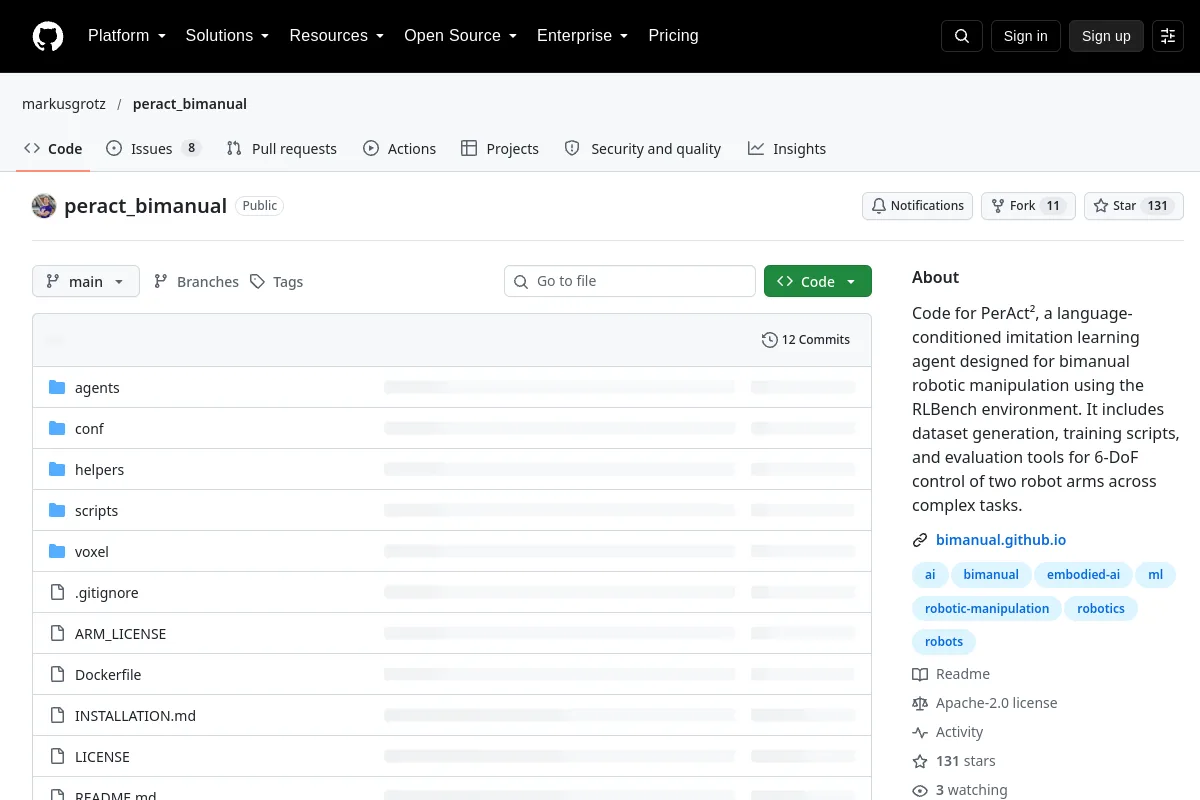
Code for PerAct², a language-conditioned imitation learning agent designed for bimanual robotic manipulation using the RLBench environment. It includes dataset generation, training scripts, and…
Overview
Code for PerAct², a language-conditioned imitation learning agent designed for bimanual robotic manipulation using the RLBench environment. It includes dataset generation, training scripts, and…
Publisher purpose: Code for PerAct², a language-conditioned imitation learning agent designed for bimanual robotic manipulation using the RLBench environment. It includes dataset generation, training scripts, and evaluation tools for 6-DoF control of two robot arms across complex tasks.
Review the data card, embodiment, schema, collection conditions and dataset-specific license before use. Data access and fit for a particular training setup need separate confirmation.
Project information
- Maintainer
- markusgrotz
- Primary language
- Python
- Repository code license
- Apache-2.0
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2025-02-23
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- Perceiver-Actor^2: A Multi-Task Transformer for Bimanual Robotic Manipulation Tasks
- Installation
- Prerequisites
- 1. Environment
- 2. Dependencies
- Pre-Generated Datasets
Browse this resource’s categories
Explore related collections
Browse Datasets →More in Datasets
Repository