 Repository
 Research
DeeR VLA · yueyang130
DeeR-VLA studies dynamic multimodal-model inference for robot execution.
Vision-language-action
Research & learning / Research
Awesome VLM based VLA for Robotic Manipulation collects VLA models built on large vision-language models.
Awesome VLM based VLA for Robotic Manipulation collects VLA models built on large vision-language models.
Publisher summary: “A curated list of large VLM-based VLA models for robotic manipulation.”
Use its repository to inspect the implementation, documentation and supported workflows. This directory record identifies the maintainer, code license and related resources; it does not claim that the project has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
DeeR-VLA studies dynamic multimodal-model inference for robot execution.
Vision-language-action Website
 Research
Fine-tuning tools for adapting OpenVLA action prediction.
Vision-language-action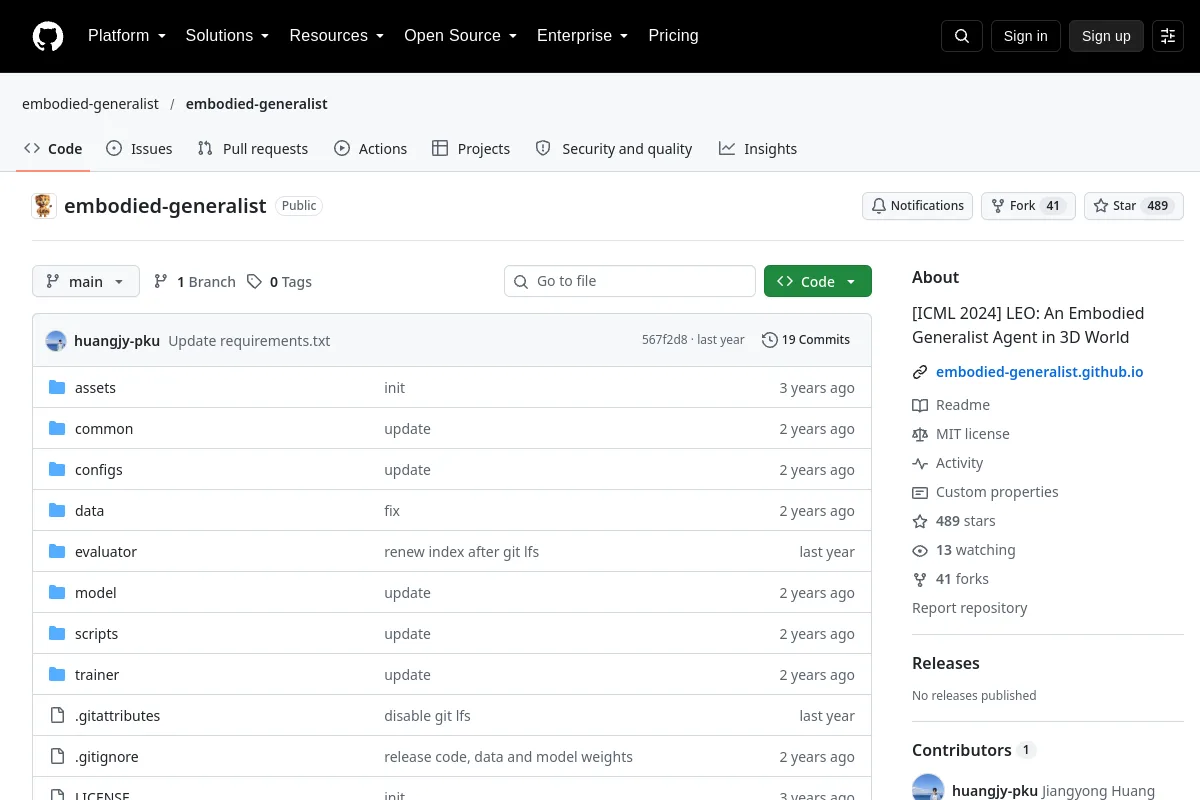 Repository
 Open source
LEO research implementation for a generalist embodied agent in 3D environments.
Robot learning frameworks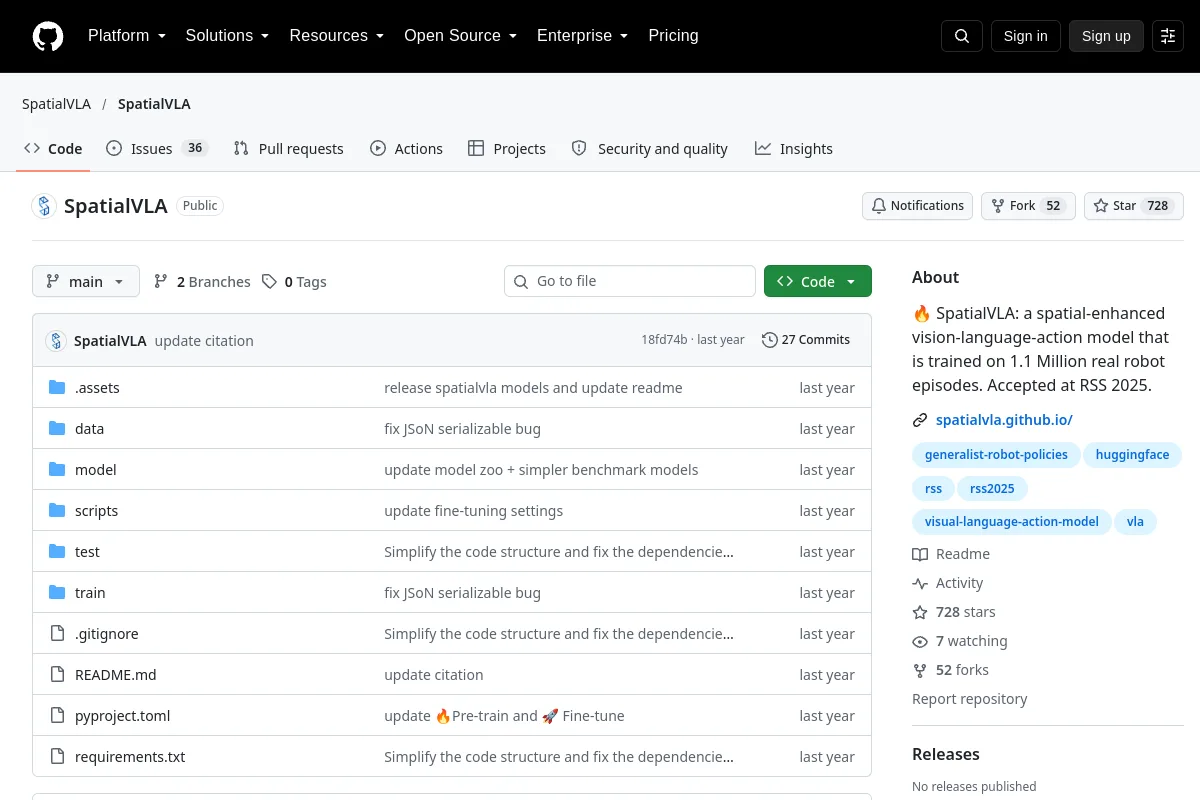 Repository
 Research
🔥 SpatialVLA: a spatial-enhanced vision-language-action model that is trained on 1.1 Million real robot episodes. Accepted at RSS 2025.
Vision-language-action Repository
 Research
Official code for MoLe-VLA: Dynamic Layer-skipping Vision Language Action Model via Mixture-of-Layers for Efficient Robot Manipulation
Vision-language-action Repository
 Research
BAAI UniVLA provides a unified vision-language-action model research project.
Vision-language-action